mirror of
https://github.com/firestar5683/StarPilot.git
synced 2026-11-05 03:54:04 +08:00
Compare commits
182 Commits
| Author | SHA1 | Date | |
|---|---|---|---|
 Willem Melching |
59bd58c940 | ||
|
Willem Melching
|
105b95ffd7 | ||
|
Willem Melching
|
fdabd57e7e | ||
|
Willem Melching
|
719e0572e1 | ||
|
Adeeb
|
0ad5715255 | ||
|
Adeeb
|
30dffb486a | ||
|
Harald Schafer
|
0728e57578 | ||
|
Harald Schafer
|
c2d5deeccc | ||
|
robbederks
|
d0c1f9a864 | ||
|
Harald Schafer
|
920572442b | ||
|
George Hotz
|
c50c718293 | ||
|
Harald Schafer
|
6b1506740e | ||
|
Harald Schafer
|
f50e016c12 | ||
|
Harald Schafer
|
bc725b98c9 | ||
|
George Hotz
|
9c5e035838 | ||
|
Harald Schafer
|
6d5cde3412 | ||
|
Willem Melching
|
07264699b7 | ||
|
Willem Melching
|
37a73d5c94 | ||
|
Andy Haden
|
79c149f42d | ||
|
Andy Haden
|
47f4396d7d | ||
|
Andy Haden
|
e8959e6b1a | ||
|
Willem Melching
|
c770f54103 | ||
|
Willem Melching
|
a98000849e | ||
|
Willem Melching
|
e32e754a74 | ||
|
Willem Melching
|
118198605f | ||
|
Willem Melching
|
0fb9971728 | ||
|
Willem Melching
|
2fe75cb7d0 | ||
|
George Hotz
|
6797910ab0 | ||
|
Willem Melching
|
5ea95c3d87 | ||
|
Harald Schafer
|
fe250d6a9e | ||
|
Willem Melching
|
58f4f5aac4 | ||
|
Willem Melching
|
0e1fc45bc3 | ||
|
Willem Melching
|
64feca5692 | ||
|
Harald Schafer
|
1db7b43870 | ||
|
Andy Haden
|
9b1f2d5c64 | ||
|
Willem Melching
|
a53577ed35 | ||
|
Willem Melching
|
77cb0b1464 | ||
|
Willem Melching
|
f609507afd | ||
|
Willem Melching
|
98f5d30455 | ||
|
HaraldSchafer
|
f610e596c4 | ||
|
Willem Melching
|
7c94b36171 | ||
|
illumiN8i
|
39c9c85562 | ||
|
illumiN8i
|
831cb68a64 | ||
|
Drew Hintz
|
5aff2b6885 | ||
|
George Hotz
|
811b3b7a9a | ||
|
George Hotz
|
c42e2ecc50 | ||
|
cfranhonda
|
0470b25071 | ||
|
George Hotz
|
f72f78f2b9 | ||
|
Willem Melching
|
df6fa7acbd | ||
|
Adeeb
|
d4c3c7f6f8 | ||
|
illumiN8i
|
a7efc8a897 | ||
|
Willem Melching
|
822b32656b | ||
|
Willem Melching
|
bfa2d030d2 | ||
|
robbederks
|
3f92bc2061 | ||
|
Andrew Valish
|
770903520d | ||
|
Arne Schwarck
|
75fdebb1ee | ||
|
illumiN8i
|
c9d49b8e4a | ||
|
ZwX1616
|
6322a275d6 | ||
|
Willem Melching
|
b7aeb5d64d | ||
|
Comma Device
|
58262bac9d | ||
|
Willem Melching
|
a75891f099 | ||
|
Willem Melching
|
a053244a5a | ||
|
Willem Melching
|
356f353489 | ||
|
Willem Melching
|
c9501cc164 | ||
|
Willem Melching
|
4dac1128f1 | ||
|
Willem Melching
|
3a65206c8d | ||
|
Willem Melching
|
4d5957432e | ||
|
illumiN8i
|
3ebb0bc46f | ||
|
Willem Melching
|
a2fe62ce77 | ||
|
Willem Melching
|
a97ebc28b5 | ||
|
Willem Melching
|
ada141e5e3 | ||
|
Willem Melching
|
0319861700 | ||
|
Drew Hintz
|
f81a43381f | ||
|
Adeeb
|
44e97ead7b | ||
|
Comma Device
|
8507e683ae | ||
|
Comma Device
|
05cbd3d58c | ||
|
Willem Melching
|
1de0b9c233 | ||
|
Willem Melching
|
b552a627e1 | ||
|
illumiN8i
|
277b187a29 | ||
|
Andy Haden
|
6762447ae7 | ||
|
Andy Haden
|
41e4ad5d1d | ||
|
Andy Haden
|
e400aa0205 | ||
|
Willem Melching
|
393c4987c8 | ||
|
Willem Melching
|
47492e77eb | ||
|
Willem Melching
|
fe9ccb27b1 | ||
|
Willem Melching
|
25f799bb8e | ||
|
Willem Melching
|
413a432b13 | ||
|
Willem Melching
|
2571453a54 | ||
|
illumiN8i
|
0c06f15ea9 | ||
|
Nelson Chen
|
d658767236 | ||
|
Adeeb
|
361be2630f | ||
|
illumiN8i
|
9a05283566 | ||
|
Harald Schafer
|
a06bb77f6b | ||
|
Arne Schwarck
|
3c6ba22931 | ||
|
robbederks
|
339e6986cf | ||
|
Willem Melching
|
0c1d70ac92 | ||
|
illumiN8i
|
21af1bad2b | ||
|
Willem Melching
|
b9b90267c5 | ||
|
Willem Melching
|
ba4bf07db2 | ||
|
Willem Melching
|
09a1691caf | ||
|
Willem Melching
|
09283f4d6a | ||
|
Willem Melching
|
e2c784740a | ||
|
Harald Schafer
|
9ff1a54c8d | ||
|
Willem Melching
|
61c104b392 | ||
|
Willem Melching
|
fb8efbed2d | ||
|
ga
|
7f6c9ebaf7 | ||
|
mosh-een
|
53933ebf5b | ||
|
Harald Schafer
|
48b4a57980 | ||
|
Willem Melching
|
50e859e6b1 | ||
|
Harald Schafer
|
ba6fd511b6 | ||
|
Harald Schafer
|
c32ebcb2c6 | ||
|
Harald Schafer
|
bbb37309fc | ||
|
Harald Schafer
|
df6b16c7f6 | ||
|
Willem Melching
|
ec6e83ca2d | ||
|
ZwX1616
|
cf70368f67 | ||
|
Adeeb
|
28af44d199 | ||
|
Arne Schwarck
|
855abbd99e | ||
|
Adeeb
|
f13c5d74aa | ||
|
Willem Melching
|
6f703eaf4e | ||
|
illumiN8i
|
689d49f3f8 | ||
|
Adeeb
|
87f9e14e9c | ||
|
Adeeb
|
7129dc8c6a | ||
|
Willem Melching
|
20745fe1d7 | ||
|
Willem Melching
|
f6835e9490 | ||
|
Harald Schafer
|
deef19ff19 | ||
|
Willem Melching
|
6adbe24d4c | ||
|
andyh2
|
79122ae662 | ||
|
andyh2
|
8d7bb87e7e | ||
|
illumiN8i
|
5560ef0521 | ||
|
Willem Melching
|
53d9975947 | ||
|
Willem Melching
|
d9e054477b | ||
|
cfranhonda
|
a93375882a | ||
|
Adeeb
|
dafdb79db2 | ||
|
Comma Device
|
0fa10e4dd7 | ||
|
Bar Harel
|
f1d6f68625 | ||
|
Willem Melching
|
757c29e1ae | ||
|
Comma Device
|
1989df2fac | ||
|
Willem Melching
|
65a40149d8 | ||
|
George Hotz
|
adb5fe1fa9 | ||
|
George Hotz
|
c7bc8ee00f | ||
|
George Hotz
|
dcd0807d7e | ||
|
George Hotz
|
013166a34e | ||
|
George Hotz
|
6ceffe68d0 | ||
|
George Hotz
|
c26d893a77 | ||
|
George Hotz
|
a3dde4e7fe | ||
|
Harald Schafer
|
e4472d0d46 | ||
|
Willem Melching
|
f3c1992b10 | ||
|
ZwX1616
|
12f72fb8e2 | ||
|
ZwX1616
|
2f19eed023 | ||
|
Willem Melching
|
dfded79673 | ||
|
ZwX1616
|
b013a00095 | ||
|
Willem Melching
|
7f813d23ce | ||
|
George Hotz
|
59b3d06417 | ||
|
George Hotz
|
b0260dadba | ||
|
George Hotz
|
fcf8efb826 | ||
|
Willem Melching
|
5f2a5e5bad | ||
|
George Hotz
|
f467642a1c | ||
|
George Hotz
|
da079d47d7 | ||
|
George Hotz
|
5c9afcc785 | ||
|
George Hotz
|
c0bfbc12c7 | ||
|
George Hotz
|
aeb2fff068 | ||
|
George Hotz
|
2f9379a139 | ||
|
George Hotz
|
368a956b96 | ||
|
George Hotz
|
71ead9adea | ||
|
George Hotz
|
978e0eb986 | ||
|
George Hotz
|
341c0da987 | ||
|
George Hotz
|
84560ccd55 | ||
|
George Hotz
|
ef93a715e1 | ||
|
George Hotz
|
41d99c3b70 | ||
|
George Hotz
|
d4d57ed7fe | ||
|
George Hotz
|
d2a564b9c7 | ||
|
George Hotz
|
da6863f427 | ||
|
George Hotz
|
6abffe0ede | ||
|
George Hotz
|
23c2d02682 | ||
|
George Hotz
|
e8d888c45b | ||
|
George Hotz
|
c4e5ce685e | ||
|
George Hotz
|
c8a04d25c9 | ||
|
George Hotz
|
012535a84e | ||
|
George Hotz
|
3fe9bbe665 | ||
|
George Hotz
|
29ac3da7b8 | ||
|
George Hotz
|
80d6953862 | ||
|
George Hotz
|
6c33a5c1f3 |
@@ -0,0 +1,3 @@
|
||||
((c++-mode (flycheck-gcc-language-standard . "c++11")
|
||||
(flycheck-clang-language-standard . "c++11")
|
||||
))
|
||||
@@ -0,0 +1,24 @@
|
||||
.git
|
||||
.DS_Store
|
||||
notebooks
|
||||
phone
|
||||
massivemap
|
||||
neos
|
||||
installer
|
||||
chffr/app2
|
||||
chffr/backend/env
|
||||
selfdrive/nav
|
||||
selfdrive/baseui
|
||||
chffr/lib/vidindex/vidindex
|
||||
chffr/lib/index_log/index_log
|
||||
selfdrive/test/simulator2
|
||||
**/cache_data
|
||||
xx/chffr/lib/index_log/index_log
|
||||
xx/chffr/lib/vidindex/vidindex
|
||||
xx/plus
|
||||
xx/community
|
||||
xx/projects
|
||||
!xx/projects/eon_testing_master
|
||||
!xx/projects/map3d
|
||||
xx/ops
|
||||
xx/junk
|
||||
+1
-1
@@ -5,7 +5,7 @@ end_of_line = lf
|
||||
insert_final_newline = true
|
||||
trim_trailing_whitespace = true
|
||||
|
||||
[*.{py,pyx,pxd}]
|
||||
[{*.py, *.pyx, *pxd}]
|
||||
charset = utf-8
|
||||
indent_style = space
|
||||
indent_size = 2
|
||||
|
||||
+27
-44
@@ -1,44 +1,27 @@
|
||||
* text=auto eol=lf
|
||||
|
||||
# Binary resources are ordinary Git blobs.
|
||||
*.onnx -text
|
||||
openpilot/selfdrive/modeld/models/big_*_tinygrad.pkl -text
|
||||
*.svg -text
|
||||
*.png -text
|
||||
*.gif -text
|
||||
*.ttf -text
|
||||
*.otf -text
|
||||
*.woff -text
|
||||
*.woff2 -text
|
||||
*.wav -text
|
||||
openpilot/starpilot/galaxy/web/vendor/vue/vue.esm-browser.js -text
|
||||
|
||||
openpilot/selfdrive/car/tests/test_models_segs.txt -text
|
||||
openpilot/common/hardware/comma/updater -text
|
||||
|
||||
# Dependency snapshots keep their own storage attributes.
|
||||
msgq_repo/** !filter !diff !merge -text
|
||||
opendbc_repo/** !filter !diff !merge -text
|
||||
panda/** !filter !diff !merge -text
|
||||
rednose_repo/** !filter !diff !merge -text
|
||||
teleoprtc_repo/** !filter !diff !merge -text
|
||||
tinygrad_repo/** !filter !diff !merge -text
|
||||
|
||||
# Compiled model parts must retain exact binary bytes.
|
||||
*.pkl.chunk* -text
|
||||
*.pkl -text
|
||||
|
||||
# Native release artifacts must retain exact binary bytes.
|
||||
*.a -text
|
||||
*.so -text
|
||||
*.so.* -text
|
||||
openpilot/cereal/messaging/bridge -text
|
||||
openpilot/selfdrive/pandad/pandad -text
|
||||
openpilot/tools/replay/replay -text
|
||||
openpilot/system/camerad/camerad -text
|
||||
openpilot/system/loggerd/bootlog -text
|
||||
openpilot/system/loggerd/encoderd -text
|
||||
openpilot/system/loggerd/loggerd -text
|
||||
openpilot/starpilot/galaxy/bin/frpc_linux_arm64 -text
|
||||
openpilot/starpilot/maps/provider/mapd -text
|
||||
openpilot/selfdrive/test/process_replay/refs/starpilot/*.zst -text
|
||||
*.keras filter=lfs diff=lfs merge=lfs -text
|
||||
*.dlc filter=lfs diff=lfs merge=lfs -text
|
||||
*.pb filter=lfs diff=lfs merge=lfs -text
|
||||
*.bin filter=lfs diff=lfs merge=lfs -text
|
||||
*.apk filter=lfs diff=lfs merge=lfs -text
|
||||
*.ipynb filter=nbstripout -diff
|
||||
external/ffmpeg/bin/ffmpeg_cuda filter=lfs diff=lfs merge=lfs -text
|
||||
models/segnet.keras filter=lfs diff=lfs merge=lfs -text
|
||||
external/zmq/lib/libzmq.a filter=lfs diff=lfs merge=lfs -text
|
||||
external/zmq/lib/libczmq.a filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/x64/lib/libacado_toolkit.a filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/x64/lib/libacado_toolkit_s.so.1.2.2beta filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/x64/lib/libacado_casadi.a filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/x64/lib/libacado_csparse.a filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/x64/lib/libacado_qpoases.a filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/aarch64/lib/libacado_toolkit.a filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/aarch64/lib/libacado_toolkit_s.so.1.2.2beta filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/aarch64/lib/libacado_casadi.a filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/aarch64/lib/libacado_csparse.a filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/acado/aarch64/lib/libacado_qpoases.a filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/fastcv/aarch64/libfastcvopt.so filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/fastcv/aarch64/libfastcvadsp_stub.so filter=lfs diff=lfs merge=lfs -text
|
||||
external/mac/MP4Box filter=lfs diff=lfs merge=lfs -text
|
||||
models/segnet2.keras filter=lfs diff=lfs merge=lfs -text
|
||||
external/opencl/*.deb filter=lfs diff=lfs merge=lfs -text
|
||||
phonelibs/zmq/aarch64-linux/lib/libzmq.a filter=lfs diff=lfs merge=lfs -text
|
||||
external/azcopy/azcopy filter=lfs diff=lfs merge=lfs -text
|
||||
|
||||
@@ -0,0 +1,25 @@
|
||||
---
|
||||
name: Bug report
|
||||
about: Create a report to help us improve openpilot
|
||||
title: ''
|
||||
labels: ''
|
||||
assignees: ''
|
||||
|
||||
---
|
||||
|
||||
**Describe the bug**
|
||||
A clear and concise description of what the bug is.
|
||||
|
||||
**How to reproduce or log data**
|
||||
Steps to reproduce the behavior, or a explorer/cabana link to the exact drive and timestamp of when the bug occurred.
|
||||
|
||||
**Expected behavior**
|
||||
A clear and concise description of what you expected to happen.
|
||||
|
||||
**Device/Version information (please complete the following information):**
|
||||
- Device: [e.g. EON/EON Gold]
|
||||
- Version: [e.g. 0.6.4], or commit hash when on devel
|
||||
- Car make/model [e.g. Toyota Prius 2016]
|
||||
|
||||
**Additional context**
|
||||
Add any other context about the problem here.
|
||||
@@ -1,47 +0,0 @@
|
||||
name: Bug report
|
||||
description: For issues with running openpilot on your comma device
|
||||
labels: ["bug"]
|
||||
body:
|
||||
|
||||
- type: markdown
|
||||
attributes:
|
||||
value: >
|
||||
Before creating a **bug report**, please check the following:
|
||||
* If the issue likely only affects your car model or make, go back and open a **car bug report** instead.
|
||||
* If the issue is related to the driving or driver monitoring models, you should open a [discussion](https://github.com/commaai/openpilot/discussions/categories/model-feedback) instead.
|
||||
* Ensure you're running the latest openpilot release.
|
||||
* Ensure you're using officially supported hardware. Issues running on PCs have a different issue template.
|
||||
* Ensure there isn't an existing issue for your bug. If there is, leave a comment on the existing issue.
|
||||
* Ensure you're running stock openpilot. We cannot look into bug reports from forks.
|
||||
|
||||
If you're unsure whether you've hit a bug, check out the #installation-help channel in the [community Discord server](https://discord.comma.ai).
|
||||
|
||||
- type: textarea
|
||||
attributes:
|
||||
label: Describe the bug
|
||||
description: Also include a description of how to reproduce the bug
|
||||
validations:
|
||||
required: true
|
||||
|
||||
- type: input
|
||||
id: route
|
||||
attributes:
|
||||
label: Provide a route where the issue occurs
|
||||
description: Ensure the route is fully uploaded at https://useradmin.comma.ai. We cannot look into issues without routes, or at least a Dongle ID.
|
||||
placeholder: 77611a1fac303767|2020-05-11--16-37-07
|
||||
validations:
|
||||
required: true
|
||||
|
||||
- type: input
|
||||
id: version
|
||||
attributes:
|
||||
label: openpilot version
|
||||
description: If you're not on release, provide the commit hash
|
||||
placeholder: 0.8.10
|
||||
validations:
|
||||
required: true
|
||||
|
||||
- type: textarea
|
||||
attributes:
|
||||
label: Additional info
|
||||
|
||||
@@ -1,14 +0,0 @@
|
||||
blank_issues_enabled: false
|
||||
contact_links:
|
||||
- name: Car bug report
|
||||
url: https://github.com/commaai/opendbc/issues/new
|
||||
about: For issues with a particular car make or model
|
||||
- name: Join the Discord
|
||||
url: https://discord.comma.ai
|
||||
about: The community Discord is for both openpilot development and experience discussion
|
||||
- name: Report driving behavior feedback
|
||||
url: https://discord.com/channels/469524606043160576/1254834193066623017
|
||||
about: Feedback for the driving and driver monitoring models goes in the #driving-feedback in Discord
|
||||
- name: Community Wiki
|
||||
url: https://github.com/commaai/openpilot/wiki
|
||||
about: Check out our community wiki
|
||||
@@ -1,42 +0,0 @@
|
||||
name: PC bug report
|
||||
description: For issues with running openpilot on PC
|
||||
labels: ["PC"]
|
||||
body:
|
||||
|
||||
- type: markdown
|
||||
attributes:
|
||||
value: >
|
||||
Before creating a **bug report**, please check the following:
|
||||
* Ensure you're running the latest openpilot release.
|
||||
* Ensure there isn't an existing issue for your bug. If there is, leave a comment on the existing issue.
|
||||
* Ensure you're running stock openpilot. We cannot look into bug reports from forks.
|
||||
|
||||
If you're unsure whether you've hit a bug, check out the #installation-help channel in the [community Discord server](https://discord.comma.ai).
|
||||
|
||||
- type: textarea
|
||||
attributes:
|
||||
label: Describe the bug
|
||||
description: Also include a description of how to reproduce the bug
|
||||
validations:
|
||||
required: true
|
||||
|
||||
- type: input
|
||||
id: os-version
|
||||
attributes:
|
||||
label: OS Version
|
||||
placeholder: Ubuntu 24.04
|
||||
validations:
|
||||
required: true
|
||||
|
||||
- type: input
|
||||
id: version
|
||||
attributes:
|
||||
label: openpilot version or commit
|
||||
placeholder: bd36f2ec8d3559909678eff2690c10a520938367
|
||||
validations:
|
||||
required: false
|
||||
|
||||
- type: textarea
|
||||
attributes:
|
||||
label: Additional info
|
||||
|
||||
@@ -1,27 +0,0 @@
|
||||
CI / testing:
|
||||
- changed-files:
|
||||
- any-glob-to-all-files: "{.github/**,**/test_*,**/test/**,Jenkinsfile}"
|
||||
|
||||
car:
|
||||
- changed-files:
|
||||
- any-glob-to-all-files: '{openpilot/selfdrive/car/**,opendbc_repo}'
|
||||
|
||||
simulation:
|
||||
- changed-files:
|
||||
- any-glob-to-all-files: 'openpilot/tools/sim/**'
|
||||
|
||||
ui:
|
||||
- changed-files:
|
||||
- any-glob-to-all-files: '{openpilot/selfdrive/assets/**,openpilot/selfdrive/ui/**,openpilot/system/ui/**}'
|
||||
|
||||
tools:
|
||||
- changed-files:
|
||||
- any-glob-to-all-files: 'openpilot/tools/**'
|
||||
|
||||
multilanguage:
|
||||
- changed-files:
|
||||
- any-glob-to-all-files: 'openpilot/selfdrive/ui/translations/**'
|
||||
|
||||
autonomy:
|
||||
- changed-files:
|
||||
- any-glob-to-all-files: "{openpilot/selfdrive/modeld/models/**,openpilot/selfdrive/test/process_replay/model_replay_ref_commit}"
|
||||
@@ -1,33 +0,0 @@
|
||||
name: "PR review"
|
||||
on:
|
||||
pull_request_target:
|
||||
types: [opened, reopened, synchronize, edited]
|
||||
|
||||
jobs:
|
||||
labeler:
|
||||
name: review
|
||||
permissions:
|
||||
contents: read
|
||||
pull-requests: write
|
||||
runs-on: ubuntu-latest
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
|
||||
# Label PRs
|
||||
- uses: actions/labeler@v6
|
||||
with:
|
||||
dot: true
|
||||
configuration-path: .github/labeler.yaml
|
||||
|
||||
# Check PR target branch
|
||||
- name: check branch
|
||||
uses: Vankka/pr-target-branch-action@5da68a42bcb7b43d39104295a876a6f3f8d7908b
|
||||
if: github.repository == 'commaai/openpilot'
|
||||
env:
|
||||
GITHUB_TOKEN: ${{ secrets.GITHUB_TOKEN }}
|
||||
with:
|
||||
target: /^(?!master$).*/
|
||||
exclude: /commaai:.*/
|
||||
change-to: ${{ github.base_ref }}
|
||||
already-exists-action: close_this
|
||||
already-exists-comment: "Your PR should be made against the `master` branch"
|
||||
@@ -1,58 +0,0 @@
|
||||
name: diff report
|
||||
|
||||
on:
|
||||
pull_request_target:
|
||||
types: [opened, synchronize, reopened]
|
||||
|
||||
jobs:
|
||||
comment:
|
||||
name: comment
|
||||
runs-on: ubuntu-latest
|
||||
timeout-minutes: 10
|
||||
permissions:
|
||||
contents: read
|
||||
pull-requests: write
|
||||
actions: read
|
||||
steps:
|
||||
- name: Wait for process replay
|
||||
id: wait
|
||||
continue-on-error: true
|
||||
uses: lewagon/wait-on-check-action@1d57e2c51a58d812d2765e036a028b6bdb5a6154
|
||||
with:
|
||||
ref: ${{ github.event.pull_request.head.sha }}
|
||||
check-name: process replay
|
||||
repo-token: ${{ secrets.GITHUB_TOKEN }}
|
||||
allowed-conclusions: success,failure
|
||||
wait-interval: 20
|
||||
- name: Get tests run ID
|
||||
if: steps.wait.outcome == 'success'
|
||||
id: tests-run
|
||||
env:
|
||||
GH_TOKEN: ${{ secrets.GITHUB_TOKEN }}
|
||||
run: |
|
||||
run_id=$(gh api \
|
||||
"repos/${{ github.repository }}/actions/workflows/tests.yaml/runs?event=pull_request&head_sha=${{ github.event.pull_request.head.sha }}&per_page=1" \
|
||||
--jq '.workflow_runs[0].id // empty')
|
||||
if [ -z "$run_id" ]; then
|
||||
echo "No tests.yaml run found for ${{ github.event.pull_request.head.sha }}" >&2
|
||||
exit 1
|
||||
fi
|
||||
echo "run-id=$run_id" >> "$GITHUB_OUTPUT"
|
||||
- name: Download diff
|
||||
if: steps.wait.outcome == 'success'
|
||||
continue-on-error: true
|
||||
uses: actions/download-artifact@3e5f45b2cfb9172054b4087a40e8e0b5a5461e7c
|
||||
with:
|
||||
github-token: ${{ secrets.GITHUB_TOKEN }}
|
||||
repository: ${{ github.repository }}
|
||||
run-id: ${{ steps.tests-run.outputs.run-id }}
|
||||
name: diff_report_${{ github.event.number }}
|
||||
path: .
|
||||
- name: Comment on PR
|
||||
if: steps.wait.outcome == 'success' && hashFiles('diff_report.txt') != ''
|
||||
uses: thollander/actions-comment-pull-request@24bffb9b452ba05a4f3f77933840a6a841d1b32b
|
||||
with:
|
||||
file-path: diff_report.txt
|
||||
comment-tag: diff_report
|
||||
pr-number: ${{ github.event.number }}
|
||||
github-token: ${{ secrets.GITHUB_TOKEN }}
|
||||
@@ -1,67 +0,0 @@
|
||||
name: docs
|
||||
|
||||
on:
|
||||
push:
|
||||
branches:
|
||||
- master
|
||||
- Domathon
|
||||
- SecretGoodStarPilot
|
||||
pull_request:
|
||||
workflow_call:
|
||||
inputs:
|
||||
run_number:
|
||||
default: '1'
|
||||
required: false
|
||||
type: string
|
||||
concurrency:
|
||||
group: docs-tests-ci-run-${{ inputs.run_number }}-${{ github.event_name == 'push' && github.ref == 'refs/heads/master' && github.run_id || github.head_ref || github.ref }}-${{ github.workflow }}-${{ github.event_name }}
|
||||
cancel-in-progress: true
|
||||
|
||||
jobs:
|
||||
docs:
|
||||
name: build docs
|
||||
runs-on: ${{
|
||||
(github.repository == 'commaai/openpilot') &&
|
||||
((github.event_name != 'pull_request') ||
|
||||
(github.event.pull_request.head.repo.full_name == 'commaai/openpilot'))
|
||||
&& fromJSON('["namespace-profile-amd64-8x16"]')
|
||||
|| fromJSON('["ubuntu-24.04"]') }}
|
||||
steps:
|
||||
- uses: commaai/timeout@v1
|
||||
- uses: actions/checkout@v7
|
||||
- run: ./tools/op.sh setup
|
||||
|
||||
# Build
|
||||
- name: Build docs
|
||||
run: ./tools/op.sh docs --build
|
||||
|
||||
# Push to docs.comma.ai
|
||||
- uses: actions/checkout@v7
|
||||
if: github.ref == 'refs/heads/master' && github.repository == 'commaai/openpilot'
|
||||
with:
|
||||
path: openpilot-docs
|
||||
ssh-key: ${{ secrets.OPENPILOT_DOCS_KEY }}
|
||||
repository: commaai/openpilot-docs
|
||||
- name: Push
|
||||
if: github.ref == 'refs/heads/master' && github.repository == 'commaai/openpilot'
|
||||
run: |
|
||||
set -x
|
||||
|
||||
source tools/release/identity.sh
|
||||
|
||||
cd openpilot-docs
|
||||
git checkout --orphan tmp
|
||||
git rm -rf .
|
||||
|
||||
# copy over docs
|
||||
cp -r ../docs/_site/ docs/
|
||||
|
||||
# GitHub pages config
|
||||
touch docs/.nojekyll
|
||||
echo -n docs.comma.ai > docs/CNAME
|
||||
|
||||
git add -f .
|
||||
git commit -m "build docs"
|
||||
|
||||
# docs live in different repo to not bloat openpilot's full clone size
|
||||
git push -f origin tmp:gh-pages
|
||||
@@ -1,96 +0,0 @@
|
||||
name: jenkins scan
|
||||
|
||||
on:
|
||||
issue_comment:
|
||||
types: [created, edited]
|
||||
|
||||
jobs:
|
||||
cleanup-branches:
|
||||
runs-on: ubuntu-latest
|
||||
permissions:
|
||||
contents: write
|
||||
steps:
|
||||
- name: Delete stale Jenkins branches
|
||||
uses: actions/github-script@v9
|
||||
with:
|
||||
script: |
|
||||
const cutoff = Date.now() - 24 * 60 * 60 * 1000;
|
||||
const prefixes = ['tmp-jenkins', '__jenkins'];
|
||||
|
||||
for await (const response of github.paginate.iterator(github.rest.repos.listBranches, {
|
||||
owner: context.repo.owner,
|
||||
repo: context.repo.repo,
|
||||
per_page: 100,
|
||||
})) {
|
||||
for (const branch of response.data) {
|
||||
if (!prefixes.some(p => branch.name.startsWith(p))) continue;
|
||||
|
||||
const { data: commit } = await github.rest.repos.getCommit({
|
||||
owner: context.repo.owner,
|
||||
repo: context.repo.repo,
|
||||
ref: branch.commit.sha,
|
||||
});
|
||||
|
||||
const commitDate = new Date(commit.commit.committer.date).getTime();
|
||||
if (commitDate < cutoff) {
|
||||
console.log(`Deleting branch: ${branch.name} (last commit: ${commit.commit.committer.date})`);
|
||||
await github.rest.git.deleteRef({
|
||||
owner: context.repo.owner,
|
||||
repo: context.repo.repo,
|
||||
ref: `heads/${branch.name}`,
|
||||
});
|
||||
}
|
||||
}
|
||||
}
|
||||
|
||||
scan-comments:
|
||||
runs-on: ubuntu-latest
|
||||
if: ${{ github.event.issue.pull_request }}
|
||||
permissions:
|
||||
contents: write
|
||||
issues: write
|
||||
steps:
|
||||
- name: Check for trigger phrase
|
||||
id: check_comment
|
||||
uses: actions/github-script@v9
|
||||
with:
|
||||
script: |
|
||||
const triggerPhrase = "trigger-jenkins";
|
||||
const comment = context.payload.comment.body;
|
||||
const commenter = context.payload.comment.user.login;
|
||||
|
||||
const { data: permissions } = await github.rest.repos.getCollaboratorPermissionLevel({
|
||||
owner: context.repo.owner,
|
||||
repo: context.repo.repo,
|
||||
username: commenter
|
||||
});
|
||||
|
||||
const hasWriteAccess = permissions.permission === 'write' || permissions.permission === 'admin';
|
||||
|
||||
return (hasWriteAccess && comment.includes(triggerPhrase));
|
||||
result-encoding: json
|
||||
|
||||
- name: Checkout repository
|
||||
if: steps.check_comment.outputs.result == 'true'
|
||||
uses: actions/checkout@v7
|
||||
with:
|
||||
ref: refs/pull/${{ github.event.issue.number }}/head
|
||||
|
||||
- name: Push to tmp-jenkins branch
|
||||
if: steps.check_comment.outputs.result == 'true'
|
||||
run: |
|
||||
git config --global user.name "github-actions[bot]"
|
||||
git config --global user.email "github-actions[bot]@users.noreply.github.com"
|
||||
git checkout -b tmp-jenkins-${{ github.event.issue.number }}
|
||||
git push -f origin tmp-jenkins-${{ github.event.issue.number }}
|
||||
|
||||
- name: Delete trigger comment
|
||||
if: steps.check_comment.outputs.result == 'true' && always()
|
||||
uses: actions/github-script@v9
|
||||
with:
|
||||
script: |
|
||||
await github.rest.issues.deleteComment({
|
||||
owner: context.repo.owner,
|
||||
repo: context.repo.repo,
|
||||
comment_id: context.payload.comment.id,
|
||||
});
|
||||
@@ -1,33 +0,0 @@
|
||||
name: release
|
||||
on:
|
||||
schedule:
|
||||
- cron: '0 9 * * *'
|
||||
workflow_dispatch:
|
||||
|
||||
jobs:
|
||||
build_masterci:
|
||||
name: build master-ci
|
||||
runs-on: ubuntu-latest
|
||||
if: github.repository == 'commaai/openpilot'
|
||||
permissions:
|
||||
checks: read
|
||||
contents: write
|
||||
steps:
|
||||
- name: Wait for green check mark
|
||||
if: ${{ github.event_name == 'schedule' }}
|
||||
uses: lewagon/wait-on-check-action@1d57e2c51a58d812d2765e036a028b6bdb5a6154
|
||||
with:
|
||||
ref: master
|
||||
wait-interval: 30
|
||||
running-workflow-name: 'build master-ci'
|
||||
repo-token: ${{ secrets.GITHUB_TOKEN }}
|
||||
check-regexp: ^((?!.*(build prebuilt|create badges).*).)*$
|
||||
- uses: actions/checkout@v4 # checkout version > v4 breaks nightly release script
|
||||
with:
|
||||
fetch-depth: 0
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Push master-ci
|
||||
run: BRANCH=__nightly tools/release/build_stripped.sh
|
||||
- name: Push chestnut nightly
|
||||
run: |
|
||||
INCLUDE_BIG_MODEL=1 BRANCH=__nightly-chestnut tools/release/build_stripped.sh
|
||||
@@ -1,121 +0,0 @@
|
||||
name: repo maintenance
|
||||
|
||||
on:
|
||||
schedule:
|
||||
- cron: "0 14 * * 1" # every Monday at 2am UTC (6am PST)
|
||||
pull_request:
|
||||
types: [closed]
|
||||
workflow_dispatch:
|
||||
|
||||
env:
|
||||
PYTHONPATH: ${{ github.workspace }}
|
||||
|
||||
jobs:
|
||||
package_updates:
|
||||
name: package_updates
|
||||
runs-on: ubuntu-latest
|
||||
if: >-
|
||||
github.repository == 'commaai/openpilot' &&
|
||||
(github.event_name == 'schedule' || github.event_name == 'workflow_dispatch')
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- run: ./tools/op.sh setup
|
||||
- name: uv lock
|
||||
run: uv lock --upgrade
|
||||
- name: uv pip tree
|
||||
id: pip_tree
|
||||
run: |
|
||||
echo 'PIP_TREE<<EOF' >> $GITHUB_OUTPUT
|
||||
uv pip tree >> $GITHUB_OUTPUT
|
||||
echo 'EOF' >> $GITHUB_OUTPUT
|
||||
- name: venv size
|
||||
id: venv_size
|
||||
run: |
|
||||
echo 'VENV_SIZE<<EOF' >> $GITHUB_OUTPUT
|
||||
echo "Total: $(du -sh .venv | cut -f1)" >> $GITHUB_OUTPUT
|
||||
echo "" >> $GITHUB_OUTPUT
|
||||
echo "Top 10 by size:" >> $GITHUB_OUTPUT
|
||||
du -sh .venv/lib/python*/site-packages/* 2>/dev/null \
|
||||
| grep -v '\.dist-info' \
|
||||
| grep -v '__pycache__' \
|
||||
| sort -rh \
|
||||
| head -10 \
|
||||
| while IFS=$'\t' read size path; do echo "$size ${path##*/}"; done >> $GITHUB_OUTPUT
|
||||
echo 'EOF' >> $GITHUB_OUTPUT
|
||||
- name: Check tracked dependencies
|
||||
run: python3 tools/vendor/check.py
|
||||
- name: update car docs
|
||||
run: |
|
||||
python openpilot/selfdrive/car/docs.py
|
||||
git add docs/CARS.md
|
||||
- name: Create Pull Request
|
||||
uses: peter-evans/create-pull-request@5f6978faf089d4d20b00c7766989d076bb2fc7f1
|
||||
with:
|
||||
author: Vehicle Researcher <user@comma.ai>
|
||||
token: ${{ secrets.ACTIONS_CREATE_PR_PAT }}
|
||||
commit-message: Update Python packages
|
||||
title: '[bot] Update Python packages'
|
||||
branch: auto-package-updates
|
||||
base: master
|
||||
delete-branch: true
|
||||
body: |
|
||||
Automatic PR from repo-maintenance -> package_updates
|
||||
|
||||
```
|
||||
$ du -sh .venv && du -sh .venv/lib/python*/site-packages/* | sort -rh | head -10
|
||||
${{ steps.venv_size.outputs.VENV_SIZE }}
|
||||
```
|
||||
|
||||
```
|
||||
$ uv pip tree
|
||||
${{ steps.pip_tree.outputs.PIP_TREE }}
|
||||
```
|
||||
labels: bot
|
||||
|
||||
cleanup_closed_branches:
|
||||
if: github.repository == 'commaai/openpilot' && github.event_name == 'pull_request'
|
||||
runs-on: ubuntu-latest
|
||||
permissions:
|
||||
contents: write
|
||||
pull-requests: read
|
||||
steps:
|
||||
- uses: actions/github-script@v9
|
||||
with:
|
||||
script: |
|
||||
const { owner, repo } = context.repo;
|
||||
const upstream = `${owner}/${repo}`;
|
||||
|
||||
const closed = context.payload.pull_request;
|
||||
if (closed) {
|
||||
if (closed.head.repo?.full_name === upstream) {
|
||||
await github.rest.git.deleteRef({ owner, repo, ref: `heads/${closed.head.ref}` }).catch(console.log);
|
||||
}
|
||||
return;
|
||||
}
|
||||
|
||||
for await (const response of github.paginate.iterator(github.rest.pulls.list, {
|
||||
owner,
|
||||
repo,
|
||||
state: 'closed',
|
||||
per_page: 100,
|
||||
})) {
|
||||
for (const pr of response.data) {
|
||||
if (pr.head.repo?.full_name !== upstream) continue;
|
||||
|
||||
const branch = pr.head.ref;
|
||||
try {
|
||||
await github.rest.git.deleteRef({
|
||||
owner,
|
||||
repo,
|
||||
ref: `heads/${branch}`,
|
||||
});
|
||||
console.log(`Deleted branch ${branch} (PR #${pr.number})`);
|
||||
} catch (error) {
|
||||
if (error.status === 422 || error.status === 403) {
|
||||
console.log(`Skipping branch ${branch} (PR #${pr.number}): ${error.message}`);
|
||||
continue;
|
||||
}
|
||||
throw error;
|
||||
}
|
||||
}
|
||||
}
|
||||
@@ -1,32 +0,0 @@
|
||||
name: safety qualification
|
||||
|
||||
on:
|
||||
push:
|
||||
branches: [master, Domathon, SecretGoodStarPilot]
|
||||
pull_request:
|
||||
workflow_dispatch:
|
||||
|
||||
permissions:
|
||||
contents: read
|
||||
|
||||
jobs:
|
||||
host_gates:
|
||||
name: ${{ matrix.gate }}
|
||||
runs-on: ubuntu-24.04
|
||||
timeout-minutes: 100
|
||||
strategy:
|
||||
fail-fast: false
|
||||
matrix:
|
||||
gate: [coverage, opendbc-misra, panda-misra, panda-host]
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Run isolated source-pinned gate
|
||||
run: .venv/bin/python tools/ci/run_safety_qualification.py --gate "${{ matrix.gate }}" --output "ci-results/safety-${{ matrix.gate }}"
|
||||
- name: Save full gate evidence
|
||||
if: always()
|
||||
uses: actions/upload-artifact@v4
|
||||
with:
|
||||
name: safety-${{ matrix.gate }}
|
||||
path: ci-results/safety-${{ matrix.gate }}/
|
||||
if-no-files-found: error
|
||||
@@ -1,28 +0,0 @@
|
||||
name: simulator driving (manual)
|
||||
|
||||
on:
|
||||
workflow_dispatch:
|
||||
|
||||
permissions:
|
||||
contents: read
|
||||
|
||||
env:
|
||||
CI: 1
|
||||
PYTHONPATH: ${{ github.workspace }}
|
||||
|
||||
jobs:
|
||||
simulator_driving:
|
||||
name: simulator driving
|
||||
runs-on: ubuntu-24.04
|
||||
timeout-minutes: 30
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Build openpilot
|
||||
run: scons
|
||||
- name: Driving test
|
||||
timeout-minutes: 2
|
||||
env:
|
||||
# MetaDrive renders offscreen through panda3d's EGL pipe on llvmpipe
|
||||
EGL_PLATFORM: surfaceless
|
||||
run: python openpilot/tools/sim/tests/test_metadrive_bridge.py
|
||||
@@ -1,52 +0,0 @@
|
||||
name: stale
|
||||
on:
|
||||
schedule:
|
||||
- cron: '30 1 * * *'
|
||||
workflow_dispatch:
|
||||
|
||||
env:
|
||||
DAYS_BEFORE_PR_CLOSE: 7
|
||||
DAYS_BEFORE_PR_STALE: 24
|
||||
DAYS_BEFORE_PR_STALE_DRAFT: 30
|
||||
|
||||
jobs:
|
||||
stale:
|
||||
runs-on: ubuntu-latest
|
||||
steps:
|
||||
- uses: actions/stale@v10
|
||||
with:
|
||||
exempt-all-milestones: true
|
||||
|
||||
# pull request config
|
||||
stale-pr-message: 'This PR has had no activity for ${{ env.DAYS_BEFORE_PR_STALE }} days. It will be automatically closed in ${{ env.DAYS_BEFORE_PR_CLOSE }} days if there is no activity.'
|
||||
close-pr-message: 'This PR has been automatically closed due to inactivity. Feel free to re-open once activity resumes.'
|
||||
stale-pr-label: stale
|
||||
delete-branch: ${{ github.event.pull_request.head.repo.full_name == 'commaai/openpilot' }} # only delete branches on the main repo
|
||||
exempt-pr-labels: "ignore stale,needs testing" # if wip or it needs testing from the community, don't mark as stale
|
||||
days-before-pr-stale: ${{ env.DAYS_BEFORE_PR_STALE }}
|
||||
days-before-pr-close: ${{ env.DAYS_BEFORE_PR_CLOSE }}
|
||||
exempt-draft-pr: false
|
||||
|
||||
# issue config
|
||||
days-before-issue-stale: -1 # ignore issues for now
|
||||
|
||||
# same as above, but give draft PRs more time
|
||||
stale_drafts:
|
||||
runs-on: ubuntu-latest
|
||||
steps:
|
||||
- uses: actions/stale@v10
|
||||
with:
|
||||
exempt-all-milestones: true
|
||||
|
||||
# pull request config
|
||||
stale-pr-message: 'This PR has had no activity for ${{ env.DAYS_BEFORE_PR_STALE_DRAFT }} days. It will be automatically closed in ${{ env.DAYS_BEFORE_PR_CLOSE }} days if there is no activity.'
|
||||
close-pr-message: 'This PR has been automatically closed due to inactivity. Feel free to re-open once activity resumes.'
|
||||
stale-pr-label: stale
|
||||
delete-branch: ${{ github.event.pull_request.head.repo.full_name == 'commaai/openpilot' }} # only delete branches on the main repo
|
||||
exempt-pr-labels: "ignore stale,needs testing" # if wip or it needs testing from the community, don't mark as stale
|
||||
days-before-pr-stale: ${{ env.DAYS_BEFORE_PR_STALE_DRAFT }}
|
||||
days-before-pr-close: ${{ env.DAYS_BEFORE_PR_CLOSE }}
|
||||
exempt-draft-pr: true
|
||||
|
||||
# issue config
|
||||
days-before-issue-stale: -1 # ignore issues for now
|
||||
@@ -0,0 +1,125 @@
|
||||
name: Openpilot Tests
|
||||
on: [push, pull_request]
|
||||
|
||||
env:
|
||||
RUN: docker run --shm-size 1G --rm tmppilot /bin/sh -c
|
||||
LOAD: docker load -i tmppilot.tar.gz/tmppilot.tar.gz
|
||||
UNIT_TEST: cd /tmp/openpilot && python -m unittest discover
|
||||
|
||||
jobs:
|
||||
build:
|
||||
name: build
|
||||
runs-on: ubuntu-16.04
|
||||
steps:
|
||||
- uses: actions/checkout@v2
|
||||
- name: Checkout submodules
|
||||
run: |
|
||||
git submodule update --init
|
||||
- run: |
|
||||
docker pull $(grep -ioP '(?<=^from)\s+\S+' Dockerfile.openpilot) || true
|
||||
docker pull docker.io/commaai/openpilot:latest || true
|
||||
|
||||
docker build --cache-from docker.io/commaai/openpilot:latest -t tmppilot -f Dockerfile.openpilot .
|
||||
docker save tmppilot:latest | gzip > tmppilot.tar.gz
|
||||
- uses: actions/upload-artifact@v1
|
||||
with:
|
||||
name: tmppilot.tar.gz
|
||||
path: tmppilot.tar.gz
|
||||
|
||||
linter:
|
||||
name: linter
|
||||
runs-on: ubuntu-16.04
|
||||
needs: build
|
||||
steps:
|
||||
- uses: actions/download-artifact@v1
|
||||
with:
|
||||
name: tmppilot.tar.gz
|
||||
- name: Load image
|
||||
run: $LOAD
|
||||
- name: flake8
|
||||
run: $RUN "cd /tmp/openpilot/ && ./flake8_openpilot.sh"
|
||||
- name: pylint
|
||||
run: $RUN "cd /tmp/openpilot/ && ./pylint_openpilot.sh"
|
||||
|
||||
unit_tests:
|
||||
name: unit tests
|
||||
runs-on: ubuntu-16.04
|
||||
needs: build
|
||||
steps:
|
||||
- uses: actions/download-artifact@v1
|
||||
with:
|
||||
name: tmppilot.tar.gz
|
||||
- name: Load image
|
||||
run: $LOAD
|
||||
- name: Run unit tests
|
||||
run: |
|
||||
$RUN cd /tmp/openpilot/selfdrive/test/test_fingerprints.py
|
||||
$RUN "$UNIT_TEST common"
|
||||
$RUN "$UNIT_TEST opendbc/can"
|
||||
$RUN "$UNIT_TEST selfdrive/boardd"
|
||||
$RUN "$UNIT_TEST selfdrive/controls"
|
||||
$RUN "$UNIT_TEST selfdrive/loggerd"
|
||||
$RUN "$UNIT_TEST selfdrive/car"
|
||||
$RUN "$UNIT_TEST selfdrive/locationd"
|
||||
$RUN "$UNIT_TEST selfdrive/athena"
|
||||
|
||||
process_replay:
|
||||
name: process replay
|
||||
runs-on: ubuntu-16.04
|
||||
needs: build
|
||||
timeout-minutes: 30
|
||||
steps:
|
||||
- uses: actions/download-artifact@v1
|
||||
with:
|
||||
name: tmppilot.tar.gz
|
||||
- name: Load image
|
||||
run: $LOAD
|
||||
- name: Run replay
|
||||
run: |
|
||||
CONTAINER_NAME="tmppilot_${GITHUB_SHA}"
|
||||
docker run --shm-size 1G --name ${CONTAINER_NAME} tmppilot /bin/sh -c "cd /tmp/openpilot/selfdrive/test/process_replay && CI=1 ./test_processes.py"
|
||||
docker cp $CONTAINER_NAME:/tmp/openpilot/selfdrive/test/process_replay/diff.txt diff.txt
|
||||
docker rm $CONTAINER_NAME
|
||||
- uses: actions/upload-artifact@v1
|
||||
if: always()
|
||||
with:
|
||||
name: process_replay_diff.txt
|
||||
path: diff.txt
|
||||
|
||||
test_longitudinal:
|
||||
name: longitudinal
|
||||
runs-on: ubuntu-16.04
|
||||
needs: build
|
||||
timeout-minutes: 30
|
||||
steps:
|
||||
- uses: actions/download-artifact@v1
|
||||
with:
|
||||
name: tmppilot.tar.gz
|
||||
- name: Load image
|
||||
run: $LOAD
|
||||
- name: Test longitudinal
|
||||
run: |
|
||||
CONTAINER_NAME="tmppilot_${GITHUB_SHA}"
|
||||
docker run --shm-size 1G --name ${CONTAINER_NAME} tmppilot /bin/sh -c "cd /tmp/openpilot/selfdrive/test/longitudinal_maneuvers && OPTEST=1 ./test_longitudinal.py"
|
||||
mkdir out
|
||||
docker cp $CONTAINER_NAME:/tmp/openpilot/selfdrive/test/longitudinal_maneuvers/out/longitudinal/ out/
|
||||
docker rm $CONTAINER_NAME
|
||||
- uses: actions/upload-artifact@v1
|
||||
if: always()
|
||||
with:
|
||||
name: longitudinal
|
||||
path: out
|
||||
|
||||
test_car_models:
|
||||
name: test car models
|
||||
runs-on: ubuntu-16.04
|
||||
needs: build
|
||||
timeout-minutes: 30
|
||||
steps:
|
||||
- uses: actions/download-artifact@v1
|
||||
with:
|
||||
name: tmppilot.tar.gz
|
||||
- name: Load image
|
||||
run: $LOAD
|
||||
- name: Test car models
|
||||
run: $RUN "mkdir -p /data/params && cd /tmp/openpilot/selfdrive/test/ && ./test_car_models.py"
|
||||
@@ -1,453 +0,0 @@
|
||||
name: tests
|
||||
|
||||
on:
|
||||
push:
|
||||
branches:
|
||||
- master
|
||||
- Domathon
|
||||
- SecretGoodStarPilot
|
||||
pull_request:
|
||||
workflow_dispatch:
|
||||
workflow_call:
|
||||
inputs:
|
||||
run_number:
|
||||
default: '1'
|
||||
required: false
|
||||
type: string
|
||||
|
||||
concurrency:
|
||||
group: tests-ci-run-${{ inputs.run_number }}-${{ github.event_name == 'push' && github.ref == 'refs/heads/master' && github.run_id || github.head_ref || github.ref }}-${{ github.workflow }}-${{ github.event_name }}
|
||||
cancel-in-progress: true
|
||||
|
||||
permissions:
|
||||
contents: read
|
||||
|
||||
env:
|
||||
CI: 1
|
||||
PYTHONPATH: ${{ github.workspace }}
|
||||
|
||||
jobs:
|
||||
source_integrity:
|
||||
name: source integrity
|
||||
runs-on: ubuntu-24.04
|
||||
permissions:
|
||||
contents: read
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- name: Validate tracked dependencies
|
||||
run: python3 tools/vendor/check.py --revision HEAD
|
||||
- run: ./tools/op.sh setup
|
||||
id: setup
|
||||
- name: Build native dependencies for packaging tests
|
||||
id: build
|
||||
run: scons -j2 openpilot/common/libparams_c.so msgq_repo/msgq/ipc_pyx.so
|
||||
- name: Test dependency tools
|
||||
if: ${{ !cancelled() && steps.build.outcome == 'success' }}
|
||||
run: python3 -m unittest discover -s tools/vendor/tests -v
|
||||
- name: Test release packaging
|
||||
if: ${{ !cancelled() && steps.build.outcome == 'success' }}
|
||||
run: python3 -m pytest -q tools/release/tests
|
||||
- name: Test CI tools
|
||||
if: ${{ !cancelled() && steps.build.outcome == 'success' }}
|
||||
run: python3 -m unittest discover -s tools/ci/tests -v
|
||||
- name: Test updater
|
||||
if: ${{ !cancelled() && steps.build.outcome == 'success' }}
|
||||
run: python3 -m unittest discover -s openpilot/system/updated/tests -v
|
||||
- name: Check setup and release shell syntax
|
||||
if: ${{ !cancelled() && steps.setup.outcome == 'success' }}
|
||||
run: |
|
||||
for script in tools/op.sh tools/release/*.sh openpilot/selfdrive/test/setup_device_ci.sh; do
|
||||
bash -n "$script"
|
||||
done
|
||||
|
||||
build_release:
|
||||
name: build release
|
||||
runs-on: ubuntu-24.04-arm
|
||||
env:
|
||||
STRIPPED_DIR: /tmp/releasepilot
|
||||
PYTHONPATH: /tmp/releasepilot
|
||||
STARPILOT_CI_BUILD_MANIFEST: /tmp/starpilot-release-build-${{ github.run_id }}-${{ github.run_attempt }}.json
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- uses: actions/setup-go@v7
|
||||
with:
|
||||
go-version: '1.25.1'
|
||||
cache-dependency-path: mapd_repo/go.sum
|
||||
- name: Build the pinned release map provider
|
||||
env:
|
||||
GOTOOLCHAIN: local
|
||||
run: |
|
||||
sudo apt-get update && sudo apt-get install -y --no-install-recommends pkg-config zlib1g-dev
|
||||
(cd mapd_repo && go mod download)
|
||||
PYTHONPATH="$GITHUB_WORKSPACE" python3 -m openpilot.starpilot.maps.package_shadow
|
||||
- name: Build devel
|
||||
timeout-minutes: 1
|
||||
run: TARGET_DIR=$STRIPPED_DIR tools/release/build_stripped.sh
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Build openpilot and run checks
|
||||
timeout-minutes: 30
|
||||
working-directory: ${{ env.STRIPPED_DIR }}
|
||||
run: python3 openpilot/system/manager/build.py
|
||||
- name: Run tests
|
||||
timeout-minutes: 1
|
||||
working-directory: ${{ env.STRIPPED_DIR }}
|
||||
run: tools/release/check-dirty.sh
|
||||
- name: Check tracked dependencies
|
||||
timeout-minutes: 3
|
||||
run: python3 tools/vendor/check.py --revision HEAD
|
||||
|
||||
developer_commands:
|
||||
name: developer commands (${{ matrix.os }})
|
||||
strategy:
|
||||
fail-fast: false
|
||||
matrix:
|
||||
os: [ubuntu-24.04, macos-latest]
|
||||
runs-on: ${{ matrix.os }}
|
||||
permissions:
|
||||
contents: read
|
||||
timeout-minutes: 30
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- name: Install developer prerequisites
|
||||
run: tools/setup_dependencies.sh
|
||||
- name: Check launchers without starting tools
|
||||
run: |
|
||||
./build --help
|
||||
./dev help
|
||||
./test --help
|
||||
./tool help
|
||||
./tools/host help
|
||||
./c3 --help
|
||||
./c4 --help
|
||||
./onroad --help
|
||||
- name: Test commands through the isolated host environment
|
||||
run: |
|
||||
./dev pytest -q tools/ci/tests/test_dev_runtime.py tools/ci/tests/test_dev_runtime_review.py tools/ci/tests/test_build_entry.py openpilot/starpilot/ui/tests/test_host_launch.py openpilot/tools/replay/tests/test_onroad_host.py openpilot/starpilot/ui/tests/test_host_window_failure.py
|
||||
- name: Build both desktop UI entrypoints without a display
|
||||
run: |
|
||||
SP_C3_COMPILE_ONLY=1 ./c3
|
||||
SP_C4_COMPILE_ONLY=1 ./c4
|
||||
|
||||
build_mac:
|
||||
name: build macOS
|
||||
runs-on: ${{ ((github.repository == 'commaai/openpilot') && ((github.event_name != 'pull_request') || (github.event.pull_request.head.repo.full_name == 'commaai/openpilot'))) && 'namespace-profile-macos-8x14' || 'macos-latest' }}
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- name: Remove Homebrew from environment
|
||||
run: |
|
||||
FILTERED=$(echo "$PATH" | tr ':' '\n' | grep -v '/opt/homebrew' | tr '\n' ':')
|
||||
echo "PATH=${FILTERED}/usr/local/bin:/usr/bin:/bin:/usr/sbin:/sbin" >> $GITHUB_ENV
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Building openpilot
|
||||
run: scons
|
||||
|
||||
static_analysis:
|
||||
name: static analysis
|
||||
runs-on: ${{
|
||||
(github.repository == 'commaai/openpilot') &&
|
||||
((github.event_name != 'pull_request') ||
|
||||
(github.event.pull_request.head.repo.full_name == 'commaai/openpilot'))
|
||||
&& fromJSON('["namespace-profile-amd64-8x16"]')
|
||||
|| fromJSON('["ubuntu-24.04"]') }}
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Static analysis
|
||||
timeout-minutes: 1
|
||||
run: scripts/lint/lint.sh
|
||||
|
||||
unit_tests:
|
||||
name: unit tests
|
||||
runs-on: ${{
|
||||
(github.repository == 'commaai/openpilot') &&
|
||||
((github.event_name != 'pull_request') ||
|
||||
(github.event.pull_request.head.repo.full_name == 'commaai/openpilot'))
|
||||
&& fromJSON('["namespace-profile-amd64-8x16"]')
|
||||
|| fromJSON('["ubuntu-24.04"]') }}
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- name: Provide JavaScript runtime for Galaxy contract tests
|
||||
uses: actions/setup-node@v7
|
||||
with:
|
||||
node-version: '24'
|
||||
package-manager-cache: false
|
||||
- name: Provide pinned map provider toolchain
|
||||
uses: actions/setup-go@v7
|
||||
with:
|
||||
go-version: '1.25.1'
|
||||
cache-dependency-path: mapd_repo/go.sum
|
||||
- name: Fetch pinned map provider dependencies
|
||||
working-directory: mapd_repo
|
||||
env:
|
||||
GOTOOLCHAIN: local
|
||||
run: go mod download
|
||||
- run: ./tools/op.sh setup
|
||||
id: setup
|
||||
- name: Build openpilot
|
||||
id: build
|
||||
run: scons
|
||||
- name: Run unit tests
|
||||
if: ${{ !cancelled() && steps.build.outcome == 'success' }}
|
||||
timeout-minutes: ${{ contains(runner.name, 'nsc') && 2 || 20 }}
|
||||
env:
|
||||
RAYLIB_BACKEND: headless
|
||||
run: tools/op.sh test --json-output unit-test-results.json
|
||||
- name: Test custom module-level pytest cases
|
||||
if: ${{ !cancelled() && steps.build.outcome == 'success' }}
|
||||
timeout-minutes: 10
|
||||
env:
|
||||
RAYLIB_BACKEND: headless
|
||||
run: python3 tools/ci/run_host_tests.py --pytest
|
||||
- name: Test GM vehicle configurations and CAN behavior
|
||||
if: ${{ !cancelled() && steps.build.outcome == 'success' }}
|
||||
timeout-minutes: 5
|
||||
run: tools/op.sh test opendbc_repo/opendbc/car/gm/tests --json-output gm-test-results.json
|
||||
- name: Test native independent-axis protocol
|
||||
if: ${{ !cancelled() && steps.build.outcome == 'success' }}
|
||||
run: |
|
||||
openpilot/selfdrive/pandad/tests/test_panda_usb
|
||||
openpilot/selfdrive/pandad/tests/test_pandad_canprotocol
|
||||
openpilot/selfdrive/pandad/tests/test_aol_protocol
|
||||
openpilot/selfdrive/pandad/tests/test_aol_wire
|
||||
openpilot/selfdrive/pandad/tests/test_producer_timing
|
||||
openpilot/selfdrive/pandad/tests/test_producer_sink
|
||||
- name: Test map provider to host messaging
|
||||
if: ${{ !cancelled() && steps.build.outcome == 'success' }}
|
||||
working-directory: mapd_repo
|
||||
timeout-minutes: 5
|
||||
env:
|
||||
GOTOOLCHAIN: local
|
||||
STARPILOT_SHADOW_IPC_REQUIRED: '1'
|
||||
STARPILOT_SHADOW_EXEC_REQUIRED: '1'
|
||||
STARPILOT_PYTHON: ${{ github.workspace }}/.venv/bin/python
|
||||
run: go test -mod=readonly -race -run '^Test(MsgqNativeLayout|Shadow(GoPythonIPC|ExecutableHostGpsIPC))$' -count=1 -v
|
||||
- name: Save complete unit test results
|
||||
if: ${{ always() && (hashFiles('unit-test-results.json') != '' || hashFiles('gm-test-results.json') != '') }}
|
||||
uses: actions/upload-artifact@v4
|
||||
with:
|
||||
name: unit-test-results
|
||||
path: |
|
||||
unit-test-results.json
|
||||
gm-test-results.json
|
||||
if-no-files-found: error
|
||||
|
||||
map_provider:
|
||||
name: map provider
|
||||
runs-on: ubuntu-24.04
|
||||
timeout-minutes: 15
|
||||
permissions:
|
||||
contents: read
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- uses: actions/setup-go@v7
|
||||
with:
|
||||
go-version: '1.25.1'
|
||||
cache-dependency-path: mapd_repo/go.sum
|
||||
- name: Install native build dependencies
|
||||
run: sudo apt-get update && sudo apt-get install -y --no-install-recommends pkg-config zlib1g-dev
|
||||
- name: Test and build pinned map provider
|
||||
run: python3 tools/ci/run_map_tests.py --output ci-results/map-provider
|
||||
- name: Save test and build evidence
|
||||
if: always()
|
||||
uses: actions/upload-artifact@v4
|
||||
with:
|
||||
name: map-provider
|
||||
path: ci-results/map-provider/
|
||||
if-no-files-found: error
|
||||
|
||||
vehicle_contracts:
|
||||
name: vehicle contracts (${{ matrix.suite }})
|
||||
runs-on: ubuntu-24.04
|
||||
timeout-minutes: 35
|
||||
permissions:
|
||||
contents: read
|
||||
strategy:
|
||||
fail-fast: false
|
||||
matrix:
|
||||
suite: [interfaces, safety-debug, safety-release]
|
||||
env:
|
||||
FUZZ_SEED: '0'
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Build native host dependencies
|
||||
run: scons
|
||||
- name: Run explicit vehicle suite and record every result
|
||||
timeout-minutes: 20
|
||||
run: python3 tools/ci/run_vehicle_tests.py --suite "${{ matrix.suite }}" --output "ci-results/${{ matrix.suite }}"
|
||||
- name: Require current complete interface regression coverage
|
||||
if: ${{ always() && matrix.suite == 'interfaces' }}
|
||||
run: |
|
||||
python3 tools/ci/fleet_coverage.py --require interfaces \
|
||||
--interface-coverage ci-results/interfaces/coverage.json \
|
||||
--interface-results ci-results/interfaces/results.json \
|
||||
--output ci-results/interfaces/fleet-coverage.json
|
||||
- name: Save collection, outcomes, and native build evidence
|
||||
if: always()
|
||||
uses: actions/upload-artifact@v4
|
||||
with:
|
||||
name: vehicle-contracts-${{ matrix.suite }}
|
||||
path: ci-results/${{ matrix.suite }}/
|
||||
if-no-files-found: error
|
||||
|
||||
recorded_vehicles:
|
||||
name: recorded vehicles (${{ matrix.variant }})
|
||||
runs-on: ubuntu-24.04
|
||||
timeout-minutes: 30
|
||||
permissions:
|
||||
contents: read
|
||||
strategy:
|
||||
fail-fast: false
|
||||
matrix:
|
||||
variant: [debug, release]
|
||||
env:
|
||||
FUZZ_SEED: '0'
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- name: Install host prerequisites
|
||||
run: tools/setup_dependencies.sh
|
||||
- name: Replay pinned public CAN recordings
|
||||
timeout-minutes: 20
|
||||
run: |
|
||||
./dev python tools/ci/run_recorded_vehicle_tests.py \
|
||||
--variant "${{ matrix.variant }}" \
|
||||
--cache "${{ runner.temp }}/recorded-fixtures" \
|
||||
--output "$GITHUB_WORKSPACE/ci-results/recorded-${{ matrix.variant }}" \
|
||||
--download
|
||||
- name: Save recorded results and native build evidence
|
||||
if: always()
|
||||
uses: actions/upload-artifact@v4
|
||||
with:
|
||||
name: recorded-vehicles-${{ matrix.variant }}
|
||||
path: ci-results/recorded-${{ matrix.variant }}/
|
||||
if-no-files-found: error
|
||||
|
||||
panda_build_variants:
|
||||
name: Panda compile (${{ matrix.variant }})
|
||||
runs-on: ubuntu-24.04
|
||||
timeout-minutes: 35
|
||||
permissions:
|
||||
contents: read
|
||||
strategy:
|
||||
fail-fast: false
|
||||
matrix:
|
||||
variant: [debug, release]
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Compile firmware with the checked-in development certificate
|
||||
timeout-minutes: 15
|
||||
shell: bash
|
||||
run: |
|
||||
set -euo pipefail
|
||||
mkdir -p ci-results/firmware
|
||||
if [[ "${{ matrix.variant }}" == release ]]; then
|
||||
export RELEASE=1
|
||||
export CERT="$PWD/panda/board/crypto/certs/debug"
|
||||
else
|
||||
unset RELEASE
|
||||
fi
|
||||
scons --verbose panda/board/obj/version panda/board/obj/panda.bin.signed panda/board/obj/bootstub.panda.bin panda/board/obj/panda_h7.bin.signed panda/board/obj/bootstub.panda_h7.bin 2>&1 | tee ci-results/firmware/build.log
|
||||
python3 tools/ci/record_firmware.py --variant "${{ matrix.variant }}" --build-log ci-results/firmware/build.log --output ci-results/firmware/provenance.json
|
||||
- name: Save compile evidence
|
||||
if: always()
|
||||
uses: actions/upload-artifact@v4
|
||||
with:
|
||||
name: panda-compile-${{ matrix.variant }}
|
||||
path: ci-results/firmware/
|
||||
if-no-files-found: error
|
||||
|
||||
process_replay:
|
||||
name: process replay
|
||||
runs-on: ${{
|
||||
(github.repository == 'commaai/openpilot') &&
|
||||
((github.event_name != 'pull_request') ||
|
||||
(github.event.pull_request.head.repo.full_name == 'commaai/openpilot'))
|
||||
&& fromJSON('["namespace-profile-amd64-8x16"]')
|
||||
|| fromJSON('["ubuntu-24.04"]') }}
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Build openpilot
|
||||
run: scons
|
||||
- name: Run replay
|
||||
timeout-minutes: ${{ contains(runner.name, 'nsc') && 2 || 20 }}
|
||||
run: openpilot/selfdrive/test/process_replay/test_processes.py -j$(nproc)
|
||||
- name: Print diff
|
||||
id: print-diff
|
||||
if: ${{ always() && hashFiles('openpilot/selfdrive/test/process_replay/diff.txt') != '' }}
|
||||
run: cat openpilot/selfdrive/test/process_replay/diff.txt
|
||||
- name: Save process replay input coverage
|
||||
if: always()
|
||||
uses: actions/upload-artifact@v4
|
||||
with:
|
||||
name: process-replay-coverage
|
||||
path: openpilot/selfdrive/test/process_replay/coverage.json
|
||||
if-no-files-found: error
|
||||
- name: Print diff report
|
||||
if: ${{ always() && hashFiles('openpilot/selfdrive/test/process_replay/diff_report.txt') != '' }}
|
||||
run: cat openpilot/selfdrive/test/process_replay/diff_report.txt
|
||||
- uses: actions/upload-artifact@v7
|
||||
if: always()
|
||||
continue-on-error: true
|
||||
with:
|
||||
name: process_replay_diff.txt
|
||||
path: openpilot/selfdrive/test/process_replay/diff.txt
|
||||
- name: Upload diff report
|
||||
uses: actions/upload-artifact@v7
|
||||
if: always() && github.event_name == 'pull_request'
|
||||
continue-on-error: true
|
||||
with:
|
||||
name: diff_report_${{ github.event.number }}
|
||||
path: openpilot/selfdrive/test/process_replay/diff_report.txt
|
||||
- name: Checkout ci-artifacts
|
||||
if: github.repository == 'commaai/openpilot' && github.ref == 'refs/heads/master'
|
||||
uses: actions/checkout@v7
|
||||
with:
|
||||
repository: commaai/ci-artifacts
|
||||
ssh-key: ${{ secrets.CI_ARTIFACTS_DEPLOY_KEY }}
|
||||
path: ${{ github.workspace }}/ci-artifacts
|
||||
- name: Prepare refs
|
||||
if: github.repository == 'commaai/openpilot' && github.ref == 'refs/heads/master'
|
||||
working-directory: ${{ github.workspace }}/ci-artifacts
|
||||
run: |
|
||||
git config user.name "GitHub Actions Bot"
|
||||
git config user.email "<>"
|
||||
git fetch origin process-replay || true
|
||||
git checkout process-replay 2>/dev/null || git checkout --orphan process-replay
|
||||
cp ${{ github.workspace }}/openpilot/selfdrive/test/process_replay/fakedata/*.zst .
|
||||
echo "${{ github.sha }}" > ref_commit
|
||||
git add .
|
||||
git commit -m "process-replay refs for ${{ github.repository }}@${{ github.sha }}" || echo "No changes to commit"
|
||||
- name: Push refs
|
||||
if: github.repository == 'commaai/openpilot' && github.ref == 'refs/heads/master'
|
||||
uses: nick-fields/retry@ad984534de44a9489a53aefd81eb77f87c70dc60
|
||||
with:
|
||||
timeout_minutes: 2
|
||||
max_attempts: 3
|
||||
command: cd ${{ github.workspace }}/ci-artifacts && git push origin process-replay --force
|
||||
|
||||
create_ui_report:
|
||||
name: Create UI Report
|
||||
runs-on: ${{
|
||||
(github.repository == 'commaai/openpilot') &&
|
||||
((github.event_name != 'pull_request') ||
|
||||
(github.event.pull_request.head.repo.full_name == 'commaai/openpilot'))
|
||||
&& fromJSON('["namespace-profile-amd64-8x16"]')
|
||||
|| fromJSON('["ubuntu-24.04"]') }}
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
- run: ./tools/op.sh setup
|
||||
- name: Build openpilot
|
||||
run: scons
|
||||
- name: Create UI Report
|
||||
env:
|
||||
RAYLIB_BACKEND: headless
|
||||
run: |
|
||||
python3 openpilot/selfdrive/ui/tests/diff/replay.py
|
||||
python3 openpilot/selfdrive/ui/tests/diff/replay.py --big
|
||||
- name: Upload UI Report
|
||||
uses: actions/upload-artifact@v7
|
||||
with:
|
||||
name: ui-report-${{ inputs.run_number || '1' }}-${{ github.event_name == 'push' && github.ref == 'refs/heads/master' && 'master' || github.event.number }}
|
||||
path: openpilot/selfdrive/ui/tests/diff/report
|
||||
@@ -1,174 +0,0 @@
|
||||
name: "ui preview"
|
||||
on:
|
||||
push:
|
||||
branches:
|
||||
- master
|
||||
pull_request_target:
|
||||
types: [assigned, opened, synchronize, reopened, edited]
|
||||
branches:
|
||||
- 'master'
|
||||
paths:
|
||||
- 'openpilot/selfdrive/assets/**'
|
||||
- 'openpilot/selfdrive/ui/**'
|
||||
- 'openpilot/system/ui/**'
|
||||
workflow_dispatch:
|
||||
|
||||
env:
|
||||
UI_JOB_NAME: "Create UI Report"
|
||||
REPORT_NAME: ${{ github.event_name == 'push' && github.ref == 'refs/heads/master' && 'master' || github.event.number }}
|
||||
SHA: ${{ github.event_name == 'push' && github.ref == 'refs/heads/master' && github.sha || github.event.pull_request.head.sha }}
|
||||
BRANCH_NAME: "openpilot/pr-${{ github.event.number }}-ui-preview"
|
||||
REPORT_FILES_BRANCH_NAME: "mici-raylib-ui-reports"
|
||||
|
||||
# variant:video_prefix:master_branch
|
||||
VARIANTS: "mici:mici_ui_replay:openpilot_master_ui_mici_raylib big:tizi_ui_replay:openpilot_master_ui_big_raylib"
|
||||
|
||||
jobs:
|
||||
preview:
|
||||
if: false # tmp disable due to GH API rate limiting flakiness
|
||||
#if: github.repository == 'commaai/openpilot'
|
||||
name: preview
|
||||
runs-on: ubuntu-latest
|
||||
timeout-minutes: 20
|
||||
permissions:
|
||||
contents: read
|
||||
pull-requests: write
|
||||
actions: read
|
||||
steps:
|
||||
- uses: actions/checkout@v7
|
||||
|
||||
- name: Waiting for ui generation to end
|
||||
uses: lewagon/wait-on-check-action@1d57e2c51a58d812d2765e036a028b6bdb5a6154
|
||||
with:
|
||||
ref: ${{ env.SHA }}
|
||||
check-name: ${{ env.UI_JOB_NAME }}
|
||||
repo-token: ${{ secrets.GITHUB_TOKEN }}
|
||||
allowed-conclusions: success
|
||||
wait-interval: 20
|
||||
|
||||
- name: Getting workflow run ID
|
||||
id: get_run_id
|
||||
run: |
|
||||
echo "run_id=$(curl https://api.github.com/repos/${{ github.repository }}/commits/${{ env.SHA }}/check-runs | jq -r '.check_runs[] | select(.name == "${{ env.UI_JOB_NAME }}") | .html_url | capture("(?<number>[0-9]+)") | .number')" >> $GITHUB_OUTPUT
|
||||
|
||||
- name: Getting proposed ui
|
||||
uses: dawidd6/action-download-artifact@b6e2e70617bc3265edd6dab6c906732b2f1ae151
|
||||
with:
|
||||
github_token: ${{ secrets.GITHUB_TOKEN }}
|
||||
run_id: ${{ steps.get_run_id.outputs.run_id }}
|
||||
search_artifacts: true
|
||||
name: ui-report-1-${{ env.REPORT_NAME }}
|
||||
path: ${{ github.workspace }}/pr_ui
|
||||
|
||||
- name: Getting mici master ui
|
||||
uses: actions/checkout@v7
|
||||
with:
|
||||
repository: commaai/ci-artifacts
|
||||
ssh-key: ${{ secrets.CI_ARTIFACTS_DEPLOY_KEY }}
|
||||
path: ${{ github.workspace }}/master_mici
|
||||
ref: openpilot_master_ui_mici_raylib
|
||||
|
||||
- name: Getting big master ui
|
||||
uses: actions/checkout@v7
|
||||
with:
|
||||
repository: commaai/ci-artifacts
|
||||
ssh-key: ${{ secrets.CI_ARTIFACTS_DEPLOY_KEY }}
|
||||
path: ${{ github.workspace }}/master_big
|
||||
ref: openpilot_master_ui_big_raylib
|
||||
|
||||
- name: Saving new master ui
|
||||
if: github.ref == 'refs/heads/master' && github.event_name == 'push'
|
||||
run: |
|
||||
for variant in $VARIANTS; do
|
||||
IFS=':' read -r name video branch <<< "$variant"
|
||||
master_dir="${{ github.workspace }}/master_${name}"
|
||||
cd "$master_dir"
|
||||
git checkout --orphan=new_branch
|
||||
git rm -rf *
|
||||
git branch -D "$branch"
|
||||
git branch -m "$branch"
|
||||
git config user.name "GitHub Actions Bot"
|
||||
git config user.email "<>"
|
||||
cp "${{ github.workspace }}/pr_ui/${video}.mp4" .
|
||||
git add .
|
||||
git commit -m "${name} video for commit ${{ env.SHA }}"
|
||||
git push origin "$branch" --force
|
||||
done
|
||||
|
||||
- name: Setup FFmpeg
|
||||
uses: AnimMouse/setup-ffmpeg@178e0b4a408f06ce40d896c3cd79f50fa6f8b0c3
|
||||
|
||||
- name: Finding diffs
|
||||
if: github.event_name == 'pull_request_target'
|
||||
id: find_diff
|
||||
run: |
|
||||
export PYTHONPATH=${{ github.workspace }}
|
||||
baseurl="https://github.com/commaai/ci-artifacts/raw/refs/heads/${{ env.BRANCH_NAME }}"
|
||||
|
||||
COMMENT=""
|
||||
for variant in $VARIANTS; do
|
||||
IFS=':' read -r name video _ <<< "$variant"
|
||||
diff_name="${name}_diff"
|
||||
|
||||
mv "${{ github.workspace }}/pr_ui/${video}.mp4" "${{ github.workspace }}/pr_ui/${video}_proposed.mp4"
|
||||
cp "${{ github.workspace }}/master_${name}/${video}.mp4" "${{ github.workspace }}/pr_ui/${video}_master.mp4"
|
||||
|
||||
diff_exit_code=0
|
||||
python3 ${{ github.workspace }}/openpilot/selfdrive/ui/tests/diff/diff.py \
|
||||
"${{ github.workspace }}/pr_ui/${video}_master.mp4" \
|
||||
"${{ github.workspace }}/pr_ui/${video}_proposed.mp4" \
|
||||
"${diff_name}.html" --basedir "$baseurl" --no-open || diff_exit_code=$?
|
||||
|
||||
cp "${{ github.workspace }}/openpilot/selfdrive/ui/tests/diff/report/${diff_name}.html" "${{ github.workspace }}/pr_ui/"
|
||||
cp "${{ github.workspace }}/openpilot/selfdrive/ui/tests/diff/report/${diff_name}.mp4" "${{ github.workspace }}/pr_ui/"
|
||||
|
||||
REPORT_URL="https://commaai.github.io/ci-artifacts/${diff_name}_pr_${{ github.event.number }}.html"
|
||||
if [ $diff_exit_code -eq 0 ]; then
|
||||
COMMENT+="**${name}**: Videos are identical! [View Diff Report]($REPORT_URL)"$'\n'
|
||||
else
|
||||
COMMENT+="**${name}**: ⚠️ <strong>Videos differ!</strong> [View Diff Report]($REPORT_URL)"$'\n'
|
||||
fi
|
||||
done
|
||||
|
||||
{
|
||||
echo "COMMENT<<EOF"
|
||||
echo "$COMMENT"
|
||||
echo "EOF"
|
||||
} >> "$GITHUB_OUTPUT"
|
||||
|
||||
- name: Saving proposed ui
|
||||
if: github.event_name == 'pull_request_target'
|
||||
working-directory: ${{ github.workspace }}/master_mici
|
||||
run: |
|
||||
git config user.name "GitHub Actions Bot"
|
||||
git config user.email "<>"
|
||||
git checkout --orphan=${{ env.BRANCH_NAME }}
|
||||
git rm -rf *
|
||||
mv ${{ github.workspace }}/pr_ui/* .
|
||||
git add .
|
||||
git commit -m "ui videos for PR #${{ github.event.number }}"
|
||||
git push origin ${{ env.BRANCH_NAME }} --force
|
||||
|
||||
# Append diff reports to report files branch
|
||||
git fetch origin ${{ env.REPORT_FILES_BRANCH_NAME }}
|
||||
git checkout ${{ env.REPORT_FILES_BRANCH_NAME }}
|
||||
for variant in $VARIANTS; do
|
||||
IFS=':' read -r name _ _ <<< "$variant"
|
||||
diff_name="${name}_diff"
|
||||
cp "${{ github.workspace }}/openpilot/selfdrive/ui/tests/diff/report/${diff_name}.html" "${diff_name}_pr_${{ github.event.number }}.html"
|
||||
git add "${diff_name}_pr_${{ github.event.number }}.html"
|
||||
done
|
||||
git commit -m "ui diff reports for PR #${{ github.event.number }}" || echo "No changes to commit"
|
||||
git push origin ${{ env.REPORT_FILES_BRANCH_NAME }}
|
||||
|
||||
- name: Comment on PR
|
||||
if: github.event_name == 'pull_request_target'
|
||||
uses: thollander/actions-comment-pull-request@24bffb9b452ba05a4f3f77933840a6a841d1b32b
|
||||
with:
|
||||
message: |
|
||||
<!-- _(run_id_ui_preview **${{ github.run_id }}**)_ -->
|
||||
## UI Preview
|
||||
${{ steps.find_diff.outputs.COMMENT }}
|
||||
comment-tag: run_id_ui_preview
|
||||
pr-number: ${{ github.event.number }}
|
||||
github-token: ${{ secrets.GITHUB_TOKEN }}
|
||||
+26
-107
@@ -1,8 +1,4 @@
|
||||
venv/
|
||||
.venv/
|
||||
.ci_cache
|
||||
.env
|
||||
.clang-format
|
||||
.DS_Store
|
||||
.tags
|
||||
.ipynb_checkpoints
|
||||
@@ -10,28 +6,13 @@ venv/
|
||||
.overlay_init
|
||||
.overlay_consistent
|
||||
.sconsign.dblite
|
||||
.vscode
|
||||
model2.png
|
||||
a.out
|
||||
.hypothesis
|
||||
.cache/
|
||||
.host_runtime/
|
||||
.comma_sysroot/
|
||||
.venv-linux-arm64/
|
||||
bin/
|
||||
!openpilot/starpilot/galaxy/bin/
|
||||
|
||||
# created at launch for comma hardware PYTHONPATH (PC uses editable installs via pyproject.toml)
|
||||
/msgq
|
||||
/opendbc
|
||||
/rednose
|
||||
/teleoprtc
|
||||
/tinygrad
|
||||
/jetlink
|
||||
|
||||
*.mp4
|
||||
*.dylib
|
||||
*.DSYM
|
||||
*.d
|
||||
*.pem
|
||||
*.pyc
|
||||
*.pyo
|
||||
.*.swp
|
||||
@@ -39,102 +20,40 @@ bin/
|
||||
.*.un~
|
||||
*.tmp
|
||||
*.o
|
||||
*.o-*
|
||||
*.os
|
||||
*.os-*
|
||||
*.so
|
||||
!openpilot/tools/replay/libmedia_mux.so
|
||||
*.a
|
||||
st[0-9A-Za-z][0-9A-Za-z][0-9A-Za-z][0-9A-Za-z][0-9A-Za-z][0-9A-Za-z]
|
||||
*.unchunked
|
||||
*.clb
|
||||
*.class
|
||||
*.pyxbldc
|
||||
*.vcd
|
||||
*.mo
|
||||
*_pyx.cpp
|
||||
*.stats
|
||||
*.pkl
|
||||
*.pkl*
|
||||
config.json
|
||||
compile_commands.json
|
||||
compare_runtime*.html
|
||||
openpilot/selfdrive/modeld/models/tg_input_devices.json
|
||||
clcache
|
||||
|
||||
# build artifacts
|
||||
docs/_site/
|
||||
openpilot/selfdrive/pandad/pandad
|
||||
openpilot/selfdrive/pandad/tests/test_aol_protocol
|
||||
openpilot/selfdrive/pandad/tests/test_aol_wire
|
||||
openpilot/selfdrive/pandad/tests/test_panda_usb
|
||||
openpilot/cereal/services.h
|
||||
openpilot/cereal/gen
|
||||
openpilot/cereal/messaging/bridge
|
||||
openpilot/selfdrive/ui/translations/tmp
|
||||
openpilot/selfdrive/car/tests/cars_dump
|
||||
openpilot/system/camerad/camerad
|
||||
openpilot/system/camerad/test/ae_gray_test
|
||||
persist
|
||||
board/obj/
|
||||
selfdrive/boardd/boardd
|
||||
selfdrive/logcatd/logcatd
|
||||
selfdrive/mapd/default_speeds_by_region.json
|
||||
selfdrive/proclogd/proclogd
|
||||
selfdrive/ui/_ui
|
||||
selfdrive/test/longitudinal_maneuvers/out
|
||||
selfdrive/visiond/visiond
|
||||
selfdrive/loggerd/loggerd
|
||||
selfdrive/sensord/_gpsd
|
||||
selfdrive/sensord/_sensord
|
||||
selfdrive/camerad/camerad
|
||||
selfdrive/modeld/_modeld
|
||||
selfdrive/modeld/_dmonitoringmodeld
|
||||
/src/
|
||||
|
||||
one
|
||||
openpilot
|
||||
notebooks
|
||||
xx
|
||||
panda_jungle
|
||||
|
||||
.coverage*
|
||||
coverage.xml
|
||||
htmlcov
|
||||
pandaextra
|
||||
|
||||
# openpilot log files
|
||||
*.bz2
|
||||
*.zst
|
||||
*.rlog
|
||||
|
||||
build/
|
||||
|
||||
!**/.gitkeep
|
||||
|
||||
|
||||
### VisualStudioCode ###
|
||||
*.vsix
|
||||
.history
|
||||
.ionide
|
||||
.vscode/*
|
||||
.history/
|
||||
!.vscode/settings.json
|
||||
!.vscode/tasks.json
|
||||
!.vscode/launch.json
|
||||
!.vscode/extensions.json
|
||||
!.vscode/*.code-snippets
|
||||
|
||||
# agents
|
||||
.claude/
|
||||
.context/
|
||||
PLAN.md
|
||||
TASK.md
|
||||
|
||||
# Disk-backed model cache reconstructed from published numbered parts.
|
||||
openpilot/selfdrive/modeld/models/*.unchunked
|
||||
|
||||
# Publish only small compiled model packages, never raw pickles or caches.
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunk[0-9][0-9]of[0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunk[0-9][0-9]of[0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunk[0-9][0-9]of[0-9][0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunk[0-9][0-9][0-9]of[0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunk[0-9][0-9][0-9]of[0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunk[0-9][0-9][0-9]of[0-9][0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunk[0-9][0-9][0-9][0-9]of[0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunk[0-9][0-9][0-9][0-9]of[0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunk[0-9][0-9][0-9][0-9]of[0-9][0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunkmanifest
|
||||
!openpilot/selfdrive/modeld/models/dmonitoring_model_tinygrad.pkl.chunksha256
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunk[0-9][0-9]of[0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunk[0-9][0-9]of[0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunk[0-9][0-9]of[0-9][0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunk[0-9][0-9][0-9]of[0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunk[0-9][0-9][0-9]of[0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunk[0-9][0-9][0-9]of[0-9][0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunk[0-9][0-9][0-9][0-9]of[0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunk[0-9][0-9][0-9][0-9]of[0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunk[0-9][0-9][0-9][0-9]of[0-9][0-9][0-9][0-9]
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunkmanifest
|
||||
!openpilot/selfdrive/modeld/models/rdf43_driving_tinygrad.pkl.chunksha256
|
||||
|
||||
# Jetlink editable-install metadata.
|
||||
/jetlink_repo/jetlink.egg-info/
|
||||
|
||||
# Local Google Play resolver build output (source and lockfile are versioned).
|
||||
|
||||
+16
@@ -0,0 +1,16 @@
|
||||
[submodule "panda"]
|
||||
path = panda
|
||||
url = ../../commaai/panda.git
|
||||
[submodule "opendbc"]
|
||||
path = opendbc
|
||||
url = ../../commaai/opendbc.git
|
||||
[submodule "laika_repo"]
|
||||
path = laika_repo
|
||||
url = ../../commaai/laika.git
|
||||
[submodule "apks"]
|
||||
path = apks
|
||||
url = ../../commaai/openpilot-apks.git
|
||||
[submodule "cereal"]
|
||||
path = cereal
|
||||
url = ../../commaai/cereal.git
|
||||
|
||||
@@ -3,11 +3,11 @@
|
||||
# A comma-separated list of package or module names from where C extensions may
|
||||
# be loaded. Extensions are loading into the active Python interpreter and may
|
||||
# run arbitrary code
|
||||
extension-pkg-whitelist=scipy,cereal.messaging.messaging_pyx,PyQt5,av
|
||||
extension-pkg-whitelist=scipy
|
||||
|
||||
# Add files or directories to the blacklist. They should be base names, not
|
||||
# paths.
|
||||
ignore=CVS,autogen,msm_kgsl.py,runtime,.venv
|
||||
ignore=CVS
|
||||
|
||||
# Add files or directories matching the regex patterns to the blacklist. The
|
||||
# regex matches against base names, not paths.
|
||||
@@ -30,6 +30,10 @@ persistent=yes
|
||||
# Specify a configuration file.
|
||||
#rcfile=
|
||||
|
||||
# When enabled, pylint would attempt to guess common misconfiguration and emit
|
||||
# user-friendly hints instead of false-positive error messages
|
||||
suggestion-mode=yes
|
||||
|
||||
# Allow loading of arbitrary C extensions. Extensions are imported into the
|
||||
# active Python interpreter and may run arbitrary code.
|
||||
unsafe-load-any-extension=no
|
||||
@@ -50,18 +54,128 @@ confidence=
|
||||
# --enable=similarities". If you want to run only the classes checker, but have
|
||||
# no Warning level messages displayed, use"--disable=all --enable=classes
|
||||
# --disable=W"
|
||||
disable=C,R,W0613,W0511,W0212,W0201,W0106,W0603,W0621,W0703,W1201,W1203,E1136,W1514,E1101,W0221,W0105,E0401,abstract-method,W0707
|
||||
# E1101 for function binding
|
||||
# W0221 for Function class
|
||||
# W0105 for comment strings
|
||||
# E0401 for missing imports
|
||||
# W0707 for not reraising
|
||||
disable=print-statement,
|
||||
parameter-unpacking,
|
||||
unpacking-in-except,
|
||||
old-raise-syntax,
|
||||
backtick,
|
||||
long-suffix,
|
||||
old-ne-operator,
|
||||
old-octal-literal,
|
||||
import-star-module-level,
|
||||
non-ascii-bytes-literal,
|
||||
raw-checker-failed,
|
||||
bad-inline-option,
|
||||
locally-disabled,
|
||||
locally-enabled,
|
||||
file-ignored,
|
||||
suppressed-message,
|
||||
useless-suppression,
|
||||
deprecated-pragma,
|
||||
apply-builtin,
|
||||
basestring-builtin,
|
||||
buffer-builtin,
|
||||
cmp-builtin,
|
||||
coerce-builtin,
|
||||
execfile-builtin,
|
||||
file-builtin,
|
||||
long-builtin,
|
||||
raw_input-builtin,
|
||||
reduce-builtin,
|
||||
standarderror-builtin,
|
||||
unicode-builtin,
|
||||
xrange-builtin,
|
||||
coerce-method,
|
||||
delslice-method,
|
||||
getslice-method,
|
||||
setslice-method,
|
||||
no-absolute-import,
|
||||
old-division,
|
||||
dict-iter-method,
|
||||
dict-view-method,
|
||||
next-method-called,
|
||||
metaclass-assignment,
|
||||
indexing-exception,
|
||||
raising-string,
|
||||
reload-builtin,
|
||||
oct-method,
|
||||
hex-method,
|
||||
nonzero-method,
|
||||
cmp-method,
|
||||
input-builtin,
|
||||
round-builtin,
|
||||
intern-builtin,
|
||||
unichr-builtin,
|
||||
map-builtin-not-iterating,
|
||||
zip-builtin-not-iterating,
|
||||
range-builtin-not-iterating,
|
||||
filter-builtin-not-iterating,
|
||||
using-cmp-argument,
|
||||
eq-without-hash,
|
||||
div-method,
|
||||
idiv-method,
|
||||
rdiv-method,
|
||||
exception-message-attribute,
|
||||
invalid-str-codec,
|
||||
sys-max-int,
|
||||
bad-python3-import,
|
||||
deprecated-string-function,
|
||||
deprecated-str-translate-call,
|
||||
deprecated-itertools-function,
|
||||
deprecated-types-field,
|
||||
next-method-defined,
|
||||
dict-items-not-iterating,
|
||||
dict-keys-not-iterating,
|
||||
dict-values-not-iterating,
|
||||
bad-indentation,
|
||||
line-too-long,
|
||||
missing-docstring,
|
||||
multiple-statements,
|
||||
bad-continuation,
|
||||
invalid-name,
|
||||
too-many-arguments,
|
||||
too-many-locals,
|
||||
superfluous-parens,
|
||||
bad-whitespace,
|
||||
too-many-instance-attributes,
|
||||
wrong-import-position,
|
||||
ungrouped-imports,
|
||||
wrong-import-order,
|
||||
protected-access,
|
||||
trailing-whitespace,
|
||||
too-many-branches,
|
||||
too-few-public-methods,
|
||||
too-many-statements,
|
||||
trailing-newlines,
|
||||
attribute-defined-outside-init,
|
||||
too-many-return-statements,
|
||||
too-many-public-methods,
|
||||
unused-argument,
|
||||
old-style-class,
|
||||
no-init,
|
||||
len-as-condition,
|
||||
unneeded-not,
|
||||
no-self-use,
|
||||
multiple-imports,
|
||||
no-else-return,
|
||||
logging-not-lazy,
|
||||
fixme,
|
||||
redefined-outer-name,
|
||||
unused-variable,
|
||||
unsubscriptable-object,
|
||||
expression-not-assigned,
|
||||
too-many-boolean-expressions,
|
||||
consider-using-ternary,
|
||||
invalid-unary-operand-type,
|
||||
relative-import,
|
||||
deprecated-lambda
|
||||
|
||||
|
||||
# Enable the message, report, category or checker with the given id(s). You can
|
||||
# either give multiple identifier separated by comma (,) or put this option
|
||||
# multiple time (only on the command line, not in the configuration file where
|
||||
# it should appear only once). See also the "--disable" option for examples.
|
||||
enable=c-extension-no-member,use-a-generator, no-else-return
|
||||
enable=c-extension-no-member
|
||||
|
||||
|
||||
[REPORTS]
|
||||
@@ -161,7 +275,7 @@ contextmanager-decorators=contextlib.contextmanager
|
||||
# List of members which are set dynamically and missed by pylint inference
|
||||
# system, and so shouldn't trigger E1101 when accessed. Python regular
|
||||
# expressions are accepted.
|
||||
generated-members=capnp.* cereal.* pygame.* zmq.* setproctitle.* smbus2.* usb1.* serial.* cv2.* ft4222.* carla.*
|
||||
generated-members=capnp.* cereal.* pygame.* zmq.* setproctitle.* smbus2.* usb1.* serial.* cv2.*
|
||||
|
||||
# Tells whether missing members accessed in mixin class should be ignored. A
|
||||
# mixin class is detected if its name ends with "mixin" (case insensitive).
|
||||
@@ -245,11 +359,18 @@ indent-after-paren=4
|
||||
indent-string=' '
|
||||
|
||||
# Maximum number of characters on a single line.
|
||||
max-line-length=150
|
||||
max-line-length=100
|
||||
|
||||
# Maximum number of lines in a module
|
||||
max-module-lines=1000
|
||||
|
||||
# List of optional constructs for which whitespace checking is disabled. `dict-
|
||||
# separator` is used to allow tabulation in dicts, etc.: {1 : 1,\n222: 2}.
|
||||
# `trailing-comma` allows a space between comma and closing bracket: (a, ).
|
||||
# `empty-line` allows space-only lines.
|
||||
no-space-check=trailing-comma,
|
||||
dict-separator
|
||||
|
||||
# Allow the body of a class to be on the same line as the declaration if body
|
||||
# contains single statement.
|
||||
single-line-class-stmt=no
|
||||
@@ -456,14 +577,9 @@ known-standard-library=
|
||||
# Force import order to recognize a module as part of a third party library.
|
||||
known-third-party=enchant
|
||||
|
||||
[STRING]
|
||||
|
||||
# This flag controls whether the implicit-str-concat should generate a warning
|
||||
# on implicit string concatenation in sequences defined over several lines.
|
||||
check-str-concat-over-line-jumps=yes
|
||||
|
||||
[EXCEPTIONS]
|
||||
|
||||
# Exceptions that will emit a warning when being caught. Defaults to
|
||||
# "Exception"
|
||||
overgeneral-exceptions=builtins.Exception
|
||||
overgeneral-exceptions=Exception
|
||||
@@ -1 +0,0 @@
|
||||
3.12.13
|
||||
Vendored
-8
@@ -1,8 +0,0 @@
|
||||
{
|
||||
"recommendations": [
|
||||
"ms-python.python",
|
||||
"ms-vscode.cpptools",
|
||||
"elagil.pre-commit-helper",
|
||||
"charliermarsh.ruff",
|
||||
]
|
||||
}
|
||||
Vendored
-88
@@ -1,88 +0,0 @@
|
||||
{
|
||||
"version": "0.2.0",
|
||||
"inputs": [
|
||||
{
|
||||
"id": "python_process",
|
||||
"type": "pickString",
|
||||
"description": "Select the process to debug",
|
||||
"options": [
|
||||
"openpilot/selfdrive/controls/controlsd.py",
|
||||
"openpilot/system/timed/timed.py",
|
||||
"openpilot/tools/sim/run_bridge.py"
|
||||
]
|
||||
},
|
||||
{
|
||||
"id": "cpp_process",
|
||||
"type": "pickString",
|
||||
"description": "Select the process to debug",
|
||||
"options": [
|
||||
"openpilot/selfdrive/ui/ui"
|
||||
]
|
||||
},
|
||||
{
|
||||
"id": "args",
|
||||
"description": "Arguments to pass to the process",
|
||||
"type": "promptString"
|
||||
},
|
||||
{
|
||||
"id": "replayArg",
|
||||
"type": "promptString",
|
||||
"description": "Enter route or segment to replay."
|
||||
}
|
||||
],
|
||||
"configurations": [
|
||||
{
|
||||
"name": "Python: openpilot Process",
|
||||
"type": "debugpy",
|
||||
"request": "launch",
|
||||
"program": "${input:python_process}",
|
||||
"console": "integratedTerminal",
|
||||
"justMyCode": true,
|
||||
"args": "${input:args}"
|
||||
},
|
||||
{
|
||||
"name": "C++: openpilot Process",
|
||||
"type": "cppdbg",
|
||||
"request": "launch",
|
||||
"program": "${workspaceFolder}/${input:cpp_process}",
|
||||
"cwd": "${workspaceFolder}"
|
||||
},
|
||||
{
|
||||
"name": "Attach LLDB to Replay drive",
|
||||
"type": "lldb",
|
||||
"request": "attach",
|
||||
"pid": "${command:pickMyProcess}",
|
||||
"sourceMap": {
|
||||
".": "${workspaceFolder}/opendbc/safety"
|
||||
},
|
||||
"initCommands": [
|
||||
"script import time; time.sleep(3)"
|
||||
]
|
||||
},
|
||||
{
|
||||
"name": "Replay drive",
|
||||
"type": "debugpy",
|
||||
"request": "launch",
|
||||
"program": "${workspaceFolder}/opendbc/safety/tests/safety_replay/replay_drive.py",
|
||||
"args": [
|
||||
"${input:replayArg}"
|
||||
],
|
||||
"console": "integratedTerminal",
|
||||
"justMyCode": false,
|
||||
"env": {
|
||||
"PYTHONPATH": "${workspaceFolder}"
|
||||
},
|
||||
"subProcess": true,
|
||||
"stopOnEntry": false
|
||||
}
|
||||
],
|
||||
"compounds": [
|
||||
{
|
||||
"name": "Replay drive + Safety LLDB",
|
||||
"configurations": [
|
||||
"Replay drive",
|
||||
"Attach LLDB to Replay drive"
|
||||
]
|
||||
}
|
||||
]
|
||||
}
|
||||
Vendored
-21
@@ -1,21 +0,0 @@
|
||||
{
|
||||
"editor.tabSize": 2,
|
||||
"editor.insertSpaces": true,
|
||||
"editor.renderWhitespace": "trailing",
|
||||
"files.trimTrailingWhitespace": true,
|
||||
"search.exclude": {
|
||||
"**/.git": true,
|
||||
"**/.venv": true,
|
||||
"**/__pycache__": true
|
||||
},
|
||||
"files.exclude": {
|
||||
"**/.git": true,
|
||||
"**/.venv": true,
|
||||
"**/__pycache__": true
|
||||
},
|
||||
"python.analysis.exclude": [
|
||||
"**/.git",
|
||||
"**/.venv",
|
||||
"**/__pycache__",
|
||||
]
|
||||
}
|
||||
@@ -0,0 +1,40 @@
|
||||
# How to contribute
|
||||
|
||||
Our software is open source so you can solve your own problems without needing help from others. And if you solve a problem and are so kind, you can upstream it for the rest of the world to use.
|
||||
|
||||
Most open source development activity is coordinated through our [Discord](https://discord.comma.ai). A lot of documentation is available on our [medium](https://medium.com/@comma_ai/)
|
||||
|
||||
## Getting Started
|
||||
|
||||
* Join our [Discord](https://discord.comma.ai)
|
||||
* Make sure you have a [GitHub account](https://github.com/signup/free)
|
||||
* Fork [our repositories](https://github.com/commaai) on GitHub
|
||||
|
||||
## Testing
|
||||
|
||||
### Local Testing
|
||||
|
||||
You can test your changes on your machine by running `run_docker_tests.sh`. This will run some automated tests in docker against your code.
|
||||
|
||||
### Automated Testing
|
||||
|
||||
All PRs are automatically checked by travis. Check out `.travis.yml` for what travis runs. Any new tests sould be added to travis.
|
||||
|
||||
### Code Style and Linting
|
||||
|
||||
Code is automatically check for style by travis as part of the automated tests. You can also run these yourself by running `check_code_quality.sh`.
|
||||
|
||||
## Car Ports (openpilot)
|
||||
|
||||
We've released a [Model Port guide](https://medium.com/@comma_ai/openpilot-port-guide-for-toyota-models-e5467f4b5fe6) for porting to Toyota/Lexus models.
|
||||
|
||||
If you port openpilot to a substantially new car brand, see this more generic [Brand Port guide](https://medium.com/@comma_ai/how-to-write-a-car-port-for-openpilot-7ce0785eda84). You might also be eligible for a bounty. See our bounties at [comma.ai/bounties.html](https://comma.ai/bounties.html)
|
||||
|
||||
## Pull Requests
|
||||
|
||||
Pull requests should be against the master branch. Before running master on in-car hardware, you'll need to run
|
||||
```
|
||||
git submodule init
|
||||
git submodule update
|
||||
```
|
||||
in order to pull down the submodules, such as `panda` and `opendbc`.
|
||||
-27
@@ -1,27 +0,0 @@
|
||||
# Source provenance
|
||||
|
||||
## Jetlink external inference
|
||||
|
||||
The comma-side Jetlink client and USB transport in `jetlink_repo` are by Zeph Leggett and the [Jetlink contributors](https://github.com/zoompilot/jetlink). They are vendored from revision `c17cd5c52be0ee83b9a6265b7da69d24ad6c5d02` under the MIT license, retained in [jetlink_repo/LICENSE](jetlink_repo/LICENSE). StarPilot owns the adapter to its model runner, settings and process lifecycle. Companion applications and inference servers remain distributed by Jetlink.
|
||||
|
||||
## MRR35 Hyundai angle and radar
|
||||
|
||||
The four MRR35 angle platforms (2026 Genesis GV70, second-generation electrified GV70, 2025 Genesis GV80, and Hyundai Ioniq 9) adapt Hyundai CAN FD angle-control design and the MRR35 radar DBC generator from the locally frozen StarPilot source snapshot `678af783`. That snapshot traces its Hyundai extension work to sunnypilot/opendbc `hkg-angle-steering-2025` at `cc4b08625a98e94b318cab15e45e05dad58042bd`; its historical import revision is not established. The relevant upstream contributors include Haibin (Jason) Wen, Shane Smiskol, and DevTekVE. Their authorship remains attributable to the upstream history; they do not maintain or endorse this port.
|
||||
|
||||
The copied MRR35 generator source and DBC definition are at `opendbc_repo/opendbc/dbc/generator/hyundai/hyundai_mrr35_radar.py` and `.dbc`. The host angle adapter and native safety profile are adaptations, not copies of a generic DBC or of unrelated vehicle support. Applicable upstream notices are preserved in [THIRD_PARTY_NOTICES.md](THIRD_PARTY_NOTICES.md).
|
||||
|
||||
## Ford support adapted from BluePilot
|
||||
|
||||
The Ford lateral strategies, extended CAN constructors, camera-radar filtering and native checks are adapted from StarPilot `2efe6017bfe14cee4807833e05f9a7f6ba255cdb`. Their lineage includes BluePilot's `bp-7.0` Ford work, principally by Alan Polk, with contributions from John Christman, Jacob Neulight, tonesto7, Haibin Wen and other sunnypilot and BluePilot contributors. The reference snapshot is [`e1d051d7ba270261b4455068bd68f1a58db15a4a`](https://github.com/BluePilotDev/bluepilot/commit/e1d051d7ba270261b4455068bd68f1a58db15a4a); the exact checkout used for the earlier StarPilot import was not recorded.
|
||||
|
||||
Relevant lineage includes the controller and integration work in [`db2bdff05`](https://github.com/BluePilotDev/bluepilot/commit/db2bdff05df103d71df62f45c2a3cb5211aba6e6) and [`d0aac605f`](https://github.com/BluePilotDev/bluepilot/commit/d0aac605f99d37e9da205e419f7989c1e9eaa386), extended CAN and safety work in [`8f8d6d15f`](https://github.com/BluePilotDev/bluepilot/commit/8f8d6d15f0a590f42b78de964ffb0d0af7f5d63d), and manual-turn detection in [`97867c1eb`](https://github.com/BluePilotDev/bluepilot/commit/97867c1eb57b7472f6fc3de62f0fef576e5a5497).
|
||||
|
||||
The vehicle strategy and CAN/native owners preserve that attribution while adapting to the current controller interfaces and shared safety limits. Upstream contributors do not maintain or endorse this adaptation. Applicable notices are retained in [THIRD_PARTY_NOTICES.md](THIRD_PARTY_NOTICES.md).
|
||||
|
||||
## Optional Ford angle controller
|
||||
|
||||
The vendored `opendbc_repo/opendbc/bluepilot_lateral` angle core, codecs and Ford-only safety hooks are adapted directly from [BluePilot bp-7.0 e1d051d7ba270261b4455068bd68f1a58db15a4a](https://github.com/BluePilotDev/bluepilot/commit/e1d051d7ba270261b4455068bd68f1a58db15a4a), principally by Alan Polk, with John Christman, Jacob Neulight, Nathan Ingraham, Praeuner and other BluePilot, sunnypilot and comma contributors. Exact source paths and intentionally stricter safety checks are recorded in that folder. Both upstream `LICENSE` and `LICENSE.md` notices are retained. Its layout follows Alan Polk's September 2026 library proposal; this is a StarPilot adapter, not a published BluePilot library release.
|
||||
|
||||
## RAV4 Continental ARS510 receiver
|
||||
|
||||
The optional ACC-target and fused-track receivers and DBC preserve firestar5683's Dom integration from `b220a37f4bd119e402225a7aa16a7cd84878d0af` (Sea Turtles, 2026-10-13) and its ARS510 source attribution to ds-sebastian/ars510-radar `fb5b29c2b5999f34afeb6f7ac494a73949d66c67`, copyright 2026 ARS510 radar contributors. The complete MIT permission and warranty notice is retained in THIRD_PARTY_NOTICES.md. Startup/settings ownership is adapted to the current StarPilot architecture; no original firmware binaries or safety permissions are copied.
|
||||
@@ -0,0 +1,88 @@
|
||||
FROM ubuntu:16.04
|
||||
ENV PYTHONUNBUFFERED 1
|
||||
|
||||
RUN apt-get update && apt-get install -y \
|
||||
autoconf \
|
||||
build-essential \
|
||||
bzip2 \
|
||||
clang \
|
||||
cmake \
|
||||
curl \
|
||||
ffmpeg \
|
||||
git \
|
||||
libarchive-dev \
|
||||
libbz2-dev \
|
||||
libcurl4-openssl-dev \
|
||||
libeigen3-dev \
|
||||
libffi-dev \
|
||||
libglew-dev \
|
||||
libgles2-mesa-dev \
|
||||
libglfw3-dev \
|
||||
libglib2.0-0 \
|
||||
liblzma-dev \
|
||||
libmysqlclient-dev \
|
||||
libomp-dev \
|
||||
libopencv-dev \
|
||||
libssl-dev \
|
||||
libsqlite3-dev \
|
||||
libtool \
|
||||
libusb-1.0-0-dev \
|
||||
libzmq5-dev \
|
||||
locales \
|
||||
ocl-icd-libopencl1 \
|
||||
ocl-icd-opencl-dev \
|
||||
opencl-headers \
|
||||
python-dev \
|
||||
python-pip \
|
||||
screen \
|
||||
sudo \
|
||||
vim \
|
||||
wget
|
||||
|
||||
|
||||
RUN sed -i -e 's/# en_US.UTF-8 UTF-8/en_US.UTF-8 UTF-8/' /etc/locale.gen && locale-gen
|
||||
ENV LANG en_US.UTF-8
|
||||
ENV LANGUAGE en_US:en
|
||||
ENV LC_ALL en_US.UTF-8
|
||||
|
||||
RUN curl -L https://github.com/pyenv/pyenv-installer/raw/master/bin/pyenv-installer | bash
|
||||
|
||||
ENV PATH="/root/.pyenv/bin:/root/.pyenv/shims:${PATH}"
|
||||
RUN pyenv install 3.7.3
|
||||
RUN pyenv global 3.7.3
|
||||
RUN pyenv rehash
|
||||
|
||||
RUN pip install pipenv==2018.11.26
|
||||
|
||||
COPY Pipfile /tmp/
|
||||
COPY Pipfile.lock /tmp/
|
||||
|
||||
RUN python --version
|
||||
RUN cd /tmp && pipenv install --system --deploy
|
||||
|
||||
# Install subset of dev dependencies needed for CI
|
||||
RUN pip install matplotlib==3.1.1 dictdiffer==0.8.0 fastcluster==1.1.25 aenum==2.2.1 scipy==1.3.1 lru-dict==1.1.6 tenacity==5.1.1 azure-common==1.1.23 azure-nspkg==3.0.2 azure-storage-blob==2.1.0 azure-storage-common==2.1.0 azure-storage-nspkg==3.1.0 pycurl==7.43.0.3
|
||||
|
||||
ENV PATH="/tmp/openpilot/external/bin:${PATH}"
|
||||
ENV PYTHONPATH /tmp/openpilot:${PYTHONPATH}
|
||||
|
||||
RUN mkdir -p /tmp/openpilot
|
||||
COPY ./flake8_openpilot.sh /tmp/openpilot/
|
||||
COPY ./pylint_openpilot.sh /tmp/openpilot/
|
||||
COPY ./.pylintrc /tmp/openpilot/
|
||||
|
||||
COPY ./release /tmp/openpilot/release
|
||||
COPY ./common /tmp/openpilot/common
|
||||
COPY ./cereal /tmp/openpilot/cereal
|
||||
COPY ./opendbc /tmp/openpilot/opendbc
|
||||
COPY ./selfdrive /tmp/openpilot/selfdrive
|
||||
COPY ./phonelibs /tmp/openpilot/phonelibs
|
||||
COPY ./pyextra /tmp/openpilot/pyextra
|
||||
COPY ./panda /tmp/openpilot/panda
|
||||
COPY ./external /tmp/openpilot/external
|
||||
COPY ./tools /tmp/openpilot/tools
|
||||
|
||||
COPY SConstruct /tmp/openpilot/SConstruct
|
||||
|
||||
RUN mkdir -p /tmp/openpilot/selfdrive/test/out
|
||||
RUN cd /tmp/openpilot && scons -j$(nproc)
|
||||
Vendored
+14
-311
@@ -1,120 +1,19 @@
|
||||
def retryWithDelay(int maxRetries, int delay, Closure body) {
|
||||
for (int i = 0; i < maxRetries; i++) {
|
||||
try {
|
||||
return body()
|
||||
} catch (Exception e) {
|
||||
sleep(delay)
|
||||
pipeline {
|
||||
agent {
|
||||
docker {
|
||||
image 'python:3.7.3'
|
||||
args '--user=root'
|
||||
}
|
||||
|
||||
}
|
||||
throw Exception("Failed after ${maxRetries} retries")
|
||||
}
|
||||
|
||||
def device(String ip, String step_label, String cmd) {
|
||||
withCredentials([file(credentialsId: 'id_rsa', variable: 'key_file')]) {
|
||||
def ssh_cmd = """
|
||||
ssh -o ControlMaster=no -o ControlPath=none -o ConnectTimeout=5 -o ServerAliveInterval=5 -o ServerAliveCountMax=12 -o BatchMode=yes -o StrictHostKeyChecking=no -i ${key_file} 'comma@${ip}' exec setpriv --pdeathsig HUP /usr/bin/bash <<'END'
|
||||
|
||||
set -e
|
||||
|
||||
export TERM=xterm-256color
|
||||
|
||||
trap 'kill 0' HUP # stop this process group on SSH disconnect
|
||||
|
||||
export CI=1
|
||||
export PYTHONWARNINGS=error
|
||||
export PYTHONFAULTHANDLER=1
|
||||
export COMMA_CACHE=/data/tmp/comma_download_cache
|
||||
#export LOGPRINT=debug # this has gotten too spammy...
|
||||
export TEST_DIR=${env.TEST_DIR}
|
||||
export SOURCE_DIR=${env.SOURCE_DIR}
|
||||
export GIT_BRANCH=${env.GIT_BRANCH}
|
||||
export GIT_COMMIT=${env.GIT_COMMIT}
|
||||
export CI_ARTIFACTS_TOKEN=${env.CI_ARTIFACTS_TOKEN}
|
||||
export GITHUB_COMMENTS_TOKEN=${env.GITHUB_COMMENTS_TOKEN}
|
||||
export AZURE_TOKEN='${env.AZURE_TOKEN}'
|
||||
# only use 1 thread since most require real hardware that can't be shared
|
||||
export PYTEST_ADDOPTS="-n0 -s"
|
||||
|
||||
|
||||
export GIT_SSH_COMMAND="ssh -i /data/gitkey"
|
||||
|
||||
source ~/.bash_profile
|
||||
if [ -f /AGNOS ]; then
|
||||
source /etc/profile
|
||||
|
||||
rm -rf /tmp/tmp*
|
||||
rm -rf ~/.commacache
|
||||
rm -rf /dev/shm/*
|
||||
rm -rf /dev/tmp/tmp*
|
||||
|
||||
if ! systemctl is-active --quiet systemd-resolved; then
|
||||
echo "restarting resolved"
|
||||
sudo systemctl start systemd-resolved
|
||||
sleep 3
|
||||
fi
|
||||
|
||||
# restart aux USB
|
||||
if [ -e /sys/bus/usb/drivers/hub/3-0:1.0 ]; then
|
||||
echo "restarting aux usb"
|
||||
echo "3-0:1.0" | sudo tee /sys/bus/usb/drivers/hub/unbind
|
||||
sleep 0.5
|
||||
echo "3-0:1.0" | sudo tee /sys/bus/usb/drivers/hub/bind
|
||||
fi
|
||||
fi
|
||||
if [ -f /data/openpilot/launch_env.sh ]; then
|
||||
source /data/openpilot/launch_env.sh
|
||||
fi
|
||||
|
||||
export LD_LIBRARY_PATH="\$(python -c 'import ffmpeg; print(ffmpeg.LIB_DIR)'):/usr/local/lib:\${LD_LIBRARY_PATH:-}"
|
||||
|
||||
ln -snf ${env.TEST_DIR} /data/pythonpath
|
||||
|
||||
cd ${env.TEST_DIR} || true
|
||||
time ( ${cmd} ) &
|
||||
wait \$!
|
||||
END"""
|
||||
|
||||
sh script: ssh_cmd, label: step_label
|
||||
}
|
||||
}
|
||||
|
||||
def deviceStage(String stageName, String deviceType, List extra_env, def steps) {
|
||||
stage(stageName) {
|
||||
if (currentBuild.result != null) {
|
||||
return
|
||||
}
|
||||
|
||||
if (isReplay()) {
|
||||
error("REPLAYING TESTS IS NOT ALLOWED. FIX THEM INSTEAD.")
|
||||
}
|
||||
|
||||
def extra = extra_env.collect { "export ${it}" }.join('\n');
|
||||
def branch = env.BRANCH_NAME ?: 'master';
|
||||
def gitDiff = sh returnStdout: true, script: 'curl -s -H "Authorization: Bearer ${GITHUB_COMMENTS_TOKEN}" https://api.github.com/repos/commaai/openpilot/compare/master...${GIT_BRANCH} | jq .files[].filename || echo "/"', label: 'Getting changes'
|
||||
|
||||
lock(resource: "", label: deviceType, inversePrecedence: true, variable: 'device_ip', quantity: 1, resourceSelectStrategy: 'random') {
|
||||
docker.image('ghcr.io/commaai/alpine-ssh').inside('--user=root') {
|
||||
timeout(time: 35, unit: 'MINUTES') {
|
||||
retry (3) {
|
||||
def date = sh(script: 'date', returnStdout: true).trim();
|
||||
device(device_ip, "set time", "date -s '" + date + "'")
|
||||
device(device_ip, "git checkout", extra + "\n" + readFile("openpilot/selfdrive/test/setup_device_ci.sh"))
|
||||
}
|
||||
steps.each { item ->
|
||||
def name = item[0]
|
||||
def cmd = item[1]
|
||||
|
||||
def args = item[2]
|
||||
def diffPaths = args.diffPaths ?: []
|
||||
def cmdTimeout = args.timeout ?: 9999
|
||||
|
||||
if (branch != "master" && !branch.contains("__jenkins_loop_") && diffPaths && !hasPathChanged(gitDiff, diffPaths)) {
|
||||
println "Skipping ${name}: no changes in ${diffPaths}."
|
||||
return
|
||||
} else {
|
||||
timeout(time: cmdTimeout, unit: 'SECONDS') {
|
||||
device(device_ip, name, cmd)
|
||||
}
|
||||
stages {
|
||||
stage('EON Build/Test') {
|
||||
steps {
|
||||
lock(resource: "", label: 'eon', inversePrecedence: true, variable: 'eon_name', quantity: 1){
|
||||
timeout(time: 30, unit: 'MINUTES') {
|
||||
dir(path: 'release') {
|
||||
sh 'pip install paramiko'
|
||||
sh 'python remote_build.py'
|
||||
}
|
||||
}
|
||||
}
|
||||
@@ -122,199 +21,3 @@ def deviceStage(String stageName, String deviceType, List extra_env, def steps)
|
||||
}
|
||||
}
|
||||
}
|
||||
|
||||
def hasPathChanged(String gitDiff, List<String> paths) {
|
||||
for (path in paths) {
|
||||
if (gitDiff.contains(path)) {
|
||||
return true
|
||||
}
|
||||
}
|
||||
return false
|
||||
}
|
||||
|
||||
def isReplay() {
|
||||
def replayClass = "org.jenkinsci.plugins.workflow.cps.replay.ReplayCause"
|
||||
return currentBuild.rawBuild.getCauses().any{ cause -> cause.toString().contains(replayClass) }
|
||||
}
|
||||
|
||||
def setupCredentials() {
|
||||
withCredentials([
|
||||
string(credentialsId: 'azure_token', variable: 'AZURE_TOKEN'),
|
||||
]) {
|
||||
env.AZURE_TOKEN = "${AZURE_TOKEN}"
|
||||
}
|
||||
|
||||
withCredentials([
|
||||
string(credentialsId: 'ci_artifacts_pat', variable: 'CI_ARTIFACTS_TOKEN'),
|
||||
]) {
|
||||
env.CI_ARTIFACTS_TOKEN = "${CI_ARTIFACTS_TOKEN}"
|
||||
}
|
||||
|
||||
withCredentials([
|
||||
string(credentialsId: 'post_comments_github_pat', variable: 'GITHUB_COMMENTS_TOKEN'),
|
||||
]) {
|
||||
env.GITHUB_COMMENTS_TOKEN = "${GITHUB_COMMENTS_TOKEN}"
|
||||
}
|
||||
}
|
||||
|
||||
def step(String name, String cmd, Map args = [:]) {
|
||||
return [name, cmd, args]
|
||||
}
|
||||
|
||||
def chestnutStage(String name = "chestnut") {
|
||||
deviceStage(name, "mici-chestnut-ci", ["UNSAFE=1", "CHESTNUT=1"], [
|
||||
step("build", "./openpilot/selfdrive/test/chestnut.sh"),
|
||||
step("model replay", "openpilot/selfdrive/test/process_replay/model_replay.py --chestnut"),
|
||||
step("onroad tests", "./openpilot/selfdrive/test/test_onroad.py TestChestnutOnroad", [timeout: 120]),
|
||||
])
|
||||
}
|
||||
|
||||
node {
|
||||
env.CI = "1"
|
||||
env.PYTHONWARNINGS = "error"
|
||||
env.TEST_DIR = "/data/openpilot"
|
||||
env.SOURCE_DIR = "/data/openpilot_source/"
|
||||
setupCredentials()
|
||||
|
||||
env.GIT_BRANCH = checkout(scm).GIT_BRANCH
|
||||
env.GIT_COMMIT = checkout(scm).GIT_COMMIT
|
||||
|
||||
if (env.JOB_BASE_NAME == 'chestnut-stresstest') {
|
||||
sh 'git fetch --no-tags origin nightly-chestnut'
|
||||
env.GIT_COMMIT = sh(script: 'git show FETCH_HEAD:git_src_commit', returnStdout: true).trim()
|
||||
if (!(env.GIT_COMMIT ==~ /[0-9a-f]{40}/)) {
|
||||
error("invalid nightly-chestnut source commit")
|
||||
}
|
||||
def results = []
|
||||
try {
|
||||
timeout(time: 12, unit: 'HOURS') {
|
||||
for (int run = 1; run <= 100; run++) {
|
||||
results << "run ${run}: INCOMPLETE"
|
||||
try {
|
||||
chestnutStage("chestnut ${run}/100")
|
||||
results[run - 1] = "run ${run}: PASS"
|
||||
} catch (hudson.AbortException e) {
|
||||
results[run - 1] = "run ${run}: FAIL"
|
||||
echo e.toString()
|
||||
}
|
||||
}
|
||||
}
|
||||
} finally {
|
||||
writeFile file: 'chestnut_stress_report.txt', text: "commit: ${env.GIT_COMMIT}\ncompleted: ${results.count { !it.endsWith('INCOMPLETE') }}/100\n" + results.join('\n') + '\n'
|
||||
archiveArtifacts artifacts: 'chestnut_stress_report.txt'
|
||||
}
|
||||
if (results.any { !it.endsWith('PASS') }) {
|
||||
error("chestnut stress test failed")
|
||||
}
|
||||
return
|
||||
}
|
||||
|
||||
def excludeBranches = ['__nightly', '__nightly-chestnut', 'devel', 'devel-staging',
|
||||
'release-tizi', 'release-tizi-staging', 'release-mici', 'release-mici-staging', 'testing-closet*', 'hotfix-*']
|
||||
def excludeRegex = excludeBranches.join('|').replaceAll('\\*', '.*')
|
||||
|
||||
if (env.BRANCH_NAME != 'master' && !env.BRANCH_NAME.contains('__jenkins_loop_')) {
|
||||
properties([
|
||||
disableConcurrentBuilds(abortPrevious: true)
|
||||
])
|
||||
}
|
||||
|
||||
try {
|
||||
if (env.BRANCH_NAME == 'devel-staging') {
|
||||
deviceStage("build release-tizi-staging", "tizi-needs-can", [], [
|
||||
step("build release-tizi-staging", "RELEASE_BRANCH=release-tizi-staging,release-mici-staging $SOURCE_DIR/tools/release/build_release.sh"),
|
||||
])
|
||||
}
|
||||
|
||||
if (env.BRANCH_NAME == '__nightly') {
|
||||
parallel (
|
||||
'nightly': {
|
||||
deviceStage("build nightly", "tizi-needs-can", [], [
|
||||
step("build nightly", "RELEASE_BRANCH=nightly $SOURCE_DIR/tools/release/build_release.sh"),
|
||||
])
|
||||
},
|
||||
'nightly-dev': {
|
||||
deviceStage("build nightly-dev", "tizi-needs-can", [], [
|
||||
step("build nightly-dev", "PANDA_DEBUG_BUILD=1 RELEASE_BRANCH=nightly-dev $SOURCE_DIR/tools/release/build_release.sh"),
|
||||
])
|
||||
},
|
||||
)
|
||||
}
|
||||
|
||||
if (env.BRANCH_NAME == '__nightly-chestnut') {
|
||||
parallel (
|
||||
'nightly-chestnut': {
|
||||
deviceStage("build nightly-chestnut", "mici-chestnut-ci", ["CHESTNUT=1"], [
|
||||
step("build nightly-chestnut", "SCONSFLAGS=-j4 INCLUDE_BIG_MODEL=1 RELEASE_BRANCH=nightly-chestnut $SOURCE_DIR/tools/release/build_release.sh TestChestnutOnroad"),
|
||||
])
|
||||
},
|
||||
'nightly-chestnut-dev': {
|
||||
deviceStage("build nightly-chestnut-dev", "mici-chestnut-ci", ["CHESTNUT=1"], [
|
||||
step("build nightly-chestnut-dev", "SCONSFLAGS=-j4 INCLUDE_BIG_MODEL=1 PANDA_DEBUG_BUILD=1 RELEASE_BRANCH=nightly-chestnut-dev $SOURCE_DIR/tools/release/build_release.sh TestChestnutOnroad"),
|
||||
])
|
||||
},
|
||||
)
|
||||
}
|
||||
|
||||
if (!env.BRANCH_NAME.matches(excludeRegex)) {
|
||||
parallel (
|
||||
'onroad tests': {
|
||||
deviceStage("onroad", "tizi-needs-can", ["UNSAFE=1"], [
|
||||
step("build openpilot", "cd openpilot/system/manager && ./build.py"),
|
||||
step("check dirty", "tools/release/check-dirty.sh"),
|
||||
step("onroad tests", "./openpilot/selfdrive/test/test_onroad.py", [timeout: 60]),
|
||||
])
|
||||
},
|
||||
'HW + Unit Tests': {
|
||||
deviceStage("tizi-hardware", "tizi-common", ["UNSAFE=1"], [
|
||||
step("build", "cd openpilot/system/manager && ./build.py"),
|
||||
step("test power draw", "./openpilot/selfdrive/test/test_power_draw.py"),
|
||||
step("test encoder", "./openpilot/system/loggerd/tests/test_encoder.py", [diffPaths: ["openpilot/system/loggerd/"]]),
|
||||
step("test manager", "./openpilot/system/manager/test/test_manager.py"),
|
||||
])
|
||||
},
|
||||
'camerad OX03C10': {
|
||||
deviceStage("OX03C10", "tizi-ox03c10", ["UNSAFE=1"], [
|
||||
step("build", "cd openpilot/system/manager && ./build.py"),
|
||||
step("test pandad", "./openpilot/selfdrive/pandad/tests/test_pandad.py"),
|
||||
step("test camerad", "./openpilot/system/camerad/test/test_camerad.py", [timeout: 90]),
|
||||
])
|
||||
},
|
||||
'camerad OS04C10': {
|
||||
deviceStage("OS04C10", "tici-os04c10", ["UNSAFE=1"], [
|
||||
step("build", "cd openpilot/system/manager && ./build.py"),
|
||||
step("test pandad", "./openpilot/selfdrive/pandad/tests/test_pandad.py"),
|
||||
step("test camerad", "./openpilot/system/camerad/test/test_camerad.py", [timeout: 90]),
|
||||
])
|
||||
},
|
||||
'sensord': {
|
||||
deviceStage("LSM + MMC", "tizi-lsmc", ["UNSAFE=1"], [
|
||||
step("build", "cd openpilot/system/manager && ./build.py"),
|
||||
step("test sensord", "./openpilot/system/sensord/tests/test_sensord.py"),
|
||||
])
|
||||
},
|
||||
'replay': {
|
||||
deviceStage("model-replay", "tizi-replay", ["UNSAFE=1"], [
|
||||
step("build", "cd openpilot/system/manager && ./build.py", [diffPaths: ["openpilot/selfdrive/modeld/", "tinygrad_repo", "openpilot/selfdrive/test/process_replay/model_replay.py"]]),
|
||||
step("model replay", "openpilot/selfdrive/test/process_replay/model_replay.py", [diffPaths: ["openpilot/selfdrive/modeld/", "tinygrad_repo", "openpilot/selfdrive/test/process_replay/model_replay.py"]]),
|
||||
])
|
||||
},
|
||||
'tizi': {
|
||||
deviceStage("tizi", "tizi", ["UNSAFE=1"], [
|
||||
step("build openpilot", "cd openpilot/system/manager && ./build.py"),
|
||||
step("test pandad loopback", "./openpilot/selfdrive/pandad/tests/test_pandad_loopback.py"),
|
||||
step("test pandad spi", "./openpilot/selfdrive/pandad/tests/test_pandad_spi.py"),
|
||||
step("test amp", "./openpilot/common/hardware/comma/tests/test_amplifier.py"),
|
||||
])
|
||||
},
|
||||
'chestnut': {
|
||||
chestnutStage()
|
||||
},
|
||||
|
||||
)
|
||||
}
|
||||
} catch (Exception e) {
|
||||
currentBuild.result = 'FAILED'
|
||||
throw e
|
||||
}
|
||||
}
|
||||
|
||||
@@ -0,0 +1,130 @@
|
||||
[[source]]
|
||||
name = "pypi"
|
||||
url = "https://pypi.org/simple"
|
||||
verify_ssl = true
|
||||
|
||||
[dev-packages]
|
||||
opencv-python= "==3.4.2.17"
|
||||
PyQt5 = "*"
|
||||
ipython = "*"
|
||||
networkx = "==2.3"
|
||||
azure-core = "==1.1.1"
|
||||
azure-common = "==1.1.24"
|
||||
azure-nspkg = "==3.0.2"
|
||||
azure-storage-blob = "==2.1.0"
|
||||
azure-storage-common = "==2.1.0"
|
||||
azure-storage-nspkg = "==3.1.0"
|
||||
boto = "*"
|
||||
"boto3" = "*"
|
||||
control = "*"
|
||||
datadog = "*"
|
||||
dlib = "*"
|
||||
elasticsearch = "*"
|
||||
future = "*"
|
||||
futures = "*"
|
||||
pycocotools = {git = "https://github.com/cocodataset/cocoapi.git",subdirectory = "PythonAPI"}
|
||||
gunicorn = "*"
|
||||
"h5py" = "*"
|
||||
hexdump = "*"
|
||||
"html5lib" = "*"
|
||||
imageio = "*"
|
||||
ipykernel = "*"
|
||||
joblib = "*"
|
||||
json-logging-py = "*"
|
||||
jupyter = "*"
|
||||
libarchive = "*"
|
||||
lru-dict = "*"
|
||||
"mpld3" = "*"
|
||||
msgpack-python = "*"
|
||||
nbstripout = "*"
|
||||
numpy = "*"
|
||||
osmium = "*"
|
||||
pbr = "*"
|
||||
percache = "*"
|
||||
pprofile = "*"
|
||||
pycurl = "*"
|
||||
git-pylint-commit-hook = "*"
|
||||
pymongo = "*"
|
||||
"pynmea2" = "*"
|
||||
pypolyline = "*"
|
||||
python-logstash = "*"
|
||||
redis = "*"
|
||||
"s2sphere" = "*"
|
||||
scikit-image = "*"
|
||||
"subprocess32" = "*"
|
||||
tenacity = "*"
|
||||
tensorflow-gpu = "==2.0"
|
||||
PyJWT = "==1.4.1"
|
||||
PyMySQL = "==0.9.2"
|
||||
Werkzeug = "*"
|
||||
"backports.lzma" = "*"
|
||||
Flask-Cors = "*"
|
||||
Flask-SocketIO = "*"
|
||||
"GeoAlchemy2" = "*"
|
||||
Pygments = "*"
|
||||
PyNaCl = "*"
|
||||
"PySDL2" = "*"
|
||||
reverse_geocoder = "*"
|
||||
Shapely = "*"
|
||||
SQLAlchemy = "*"
|
||||
scipy = "*"
|
||||
fastcluster = "*"
|
||||
backports-abc = "*"
|
||||
pygame = "*"
|
||||
simplejson = "*"
|
||||
python-logstash-async = "*"
|
||||
seaborn = "*"
|
||||
pyproj = "*"
|
||||
mock = "*"
|
||||
matplotlib = "*"
|
||||
dictdiffer = "*"
|
||||
aenum = "*"
|
||||
coverage = "*"
|
||||
azure-cli-core = "*"
|
||||
paramiko = "*"
|
||||
aiohttp = "*"
|
||||
|
||||
[packages]
|
||||
overpy = {git = "https://github.com/commaai/python-overpy.git",ref = "f86529af402d4642e1faeb146671c40284007323"}
|
||||
atomicwrites = "*"
|
||||
cffi = "*"
|
||||
crcmod = "*"
|
||||
hexdump = "*"
|
||||
libusb1 = "*"
|
||||
numpy = "*"
|
||||
psutil = "*"
|
||||
pycapnp = "*"
|
||||
cryptography = "*"
|
||||
pyserial = "*"
|
||||
python-dateutil = "*"
|
||||
pyzmq = "*"
|
||||
raven = "*"
|
||||
requests = "*"
|
||||
setproctitle = "*"
|
||||
six = "*"
|
||||
smbus2 = "*"
|
||||
sympy = "*"
|
||||
tqdm = "*"
|
||||
Cython = "*"
|
||||
PyYAML = "*"
|
||||
websocket_client = "*"
|
||||
Logentries = {git = "https://github.com/commaai/le_python.git",ref = "feaeacb48f7f4bdb02c0a8fc092326d4e101b7f2"}
|
||||
urllib3 = "*"
|
||||
chardet = "*"
|
||||
idna = "*"
|
||||
gunicorn = "*"
|
||||
utm = "*"
|
||||
json-rpc = "*"
|
||||
Flask = "*"
|
||||
PyJWT = "*"
|
||||
"Jinja2" = "*"
|
||||
nose = "*"
|
||||
flake8 = "*"
|
||||
pylint = "*"
|
||||
pycryptodome = "*"
|
||||
pillow = "*"
|
||||
scons = "*"
|
||||
cysignals = "*"
|
||||
|
||||
[requires]
|
||||
python_version = "3.7.3"
|
||||
Generated
+2970
File diff suppressed because it is too large
Load Diff
@@ -1,43 +1,306 @@
|
||||
# StarPilot
|
||||
[](#)
|
||||
|
||||
StarPilot is an independent fork of [openpilot](https://github.com/commaai/openpilot), with custom driving controls, vehicle integrations, raylib interfaces for comma 3 and comma four, and the Galaxy companion interface.
|
||||
Table of Contents
|
||||
=======================
|
||||
|
||||
**Domathon is the development branch for StarPilot 7.0.** It rebuilds StarPilot on a current openpilot foundation. Feature migration and vehicle qualification are still in progress; this branch is not a completed replacement for the existing Dom release.
|
||||
* [What is openpilot?](#what-is-openpilot)
|
||||
* [Integration with Stock Features](#integration-with-stock-features)
|
||||
* [Supported Hardware](#supported-hardware)
|
||||
* [Supported Cars](#supported-cars)
|
||||
* [Community Maintained Cars and Features](#community-maintained-cars-and-features)
|
||||
* [Installation Instructions](#installation-instructions)
|
||||
* [Limitations of openpilot ALC and LDW](#limitations-of-openpilot-alc-and-ldw)
|
||||
* [Limitations of openpilot ACC and FCW](#limitations-of-openpilot-acc-and-fcw)
|
||||
* [Limitations of openpilot DM](#limitations-of-openpilot-dm)
|
||||
* [User Data and comma Account](#user-data-and-comma-account)
|
||||
* [Safety and Testing](#safety-and-testing)
|
||||
* [Testing on PC](#testing-on-pc)
|
||||
* [Community and Contributing](#community-and-contributing)
|
||||
* [Directory Structure](#directory-structure)
|
||||
* [Licensing](#licensing)
|
||||
|
||||
## Explore the project
|
||||
---
|
||||
|
||||
- [Developer commands](tools/STARPILOT_DEVELOPMENT.md): host tools, replay, and device builds.
|
||||
- [Driving interfaces](openpilot/starpilot/ui/README.md) and [Galaxy](openpilot/starpilot/galaxy/README.md): native and companion controls.
|
||||
- [Driving models](openpilot/starpilot/models/README.md): model management, artifact compatibility, and Model Laboratory status.
|
||||
- [Builds and developer tools](docs/how-to/laptop-device-build.md): local development and device builds.
|
||||
- [Dependency maintenance](tools/vendor/README.md): tracked source folders and upstream sync records.
|
||||
What is openpilot?
|
||||
------
|
||||
|
||||
## Development
|
||||
[openpilot](http://github.com/commaai/openpilot) is an open source driver assistance system. Currently, openpilot performs the functions of Adaptive Cruise Control (ACC), Automated Lane Centering (ALC), Forward Collision Warning (FCW) and Lane Departure Warning (LDW) for a growing variety of supported [car makes, models and model years](#supported-cars). In addition, while openpilot is engaged, a camera based Driver Monitoring (DM) feature alerts distracted and asleep drivers.
|
||||
|
||||
Dependencies are included as ordinary source folders. No recursive submodule checkout is needed. [upstream-sync.json](upstream-sync.json) records the openpilot baseline and the source revisions used for vendored dependencies.
|
||||
<table>
|
||||
<tr>
|
||||
<td><a href="https://www.youtube.com/watch?v=mgAbfr42oI8" title="YouTube" rel="noopener"><img src="https://i.imgur.com/kAtT6Ei.png"></a></td>
|
||||
<td><a href="https://www.youtube.com/watch?v=394rJKeh76k" title="YouTube" rel="noopener"><img src="https://i.imgur.com/lTt8cS2.png"></a></td>
|
||||
<td><a href="https://www.youtube.com/watch?v=1iNOc3cq8cs" title="YouTube" rel="noopener"><img src="https://i.imgur.com/ANnuSpe.png"></a></td>
|
||||
<td><a href="https://www.youtube.com/watch?v=Vr6NgrB-zHw" title="YouTube" rel="noopener"><img src="https://i.imgur.com/Qypanuq.png"></a></td>
|
||||
</tr>
|
||||
<tr>
|
||||
<td><a href="https://www.youtube.com/watch?v=Ug41KIKF0oo" title="YouTube" rel="noopener"><img src="https://i.imgur.com/3caZ7xM.png"></a></td>
|
||||
<td><a href="https://www.youtube.com/watch?v=NVR_CdG1FRg" title="YouTube" rel="noopener"><img src="https://i.imgur.com/bAZOwql.png"></a></td>
|
||||
<td><a href="https://www.youtube.com/watch?v=tkEvIdzdfUE" title="YouTube" rel="noopener"><img src="https://i.imgur.com/EFINEzG.png"></a></td>
|
||||
<td><a href="https://www.youtube.com/watch?v=_P-N1ewNne4" title="YouTube" rel="noopener"><img src="https://i.imgur.com/gAyAq22.png"></a></td>
|
||||
</tr>
|
||||
</table>
|
||||
|
||||
The familiar development entry points are retained:
|
||||
Integration with Stock Features
|
||||
------
|
||||
|
||||
| Command | Purpose |
|
||||
| --- | --- |
|
||||
| `./build` | Build the device software using the matching AGNOS environment |
|
||||
| `./build --panda` | Build the supported Panda firmware targets |
|
||||
| `./c3` | Open the comma 3 interface on a development host |
|
||||
| `./c4` | Open the comma four interface on a development host |
|
||||
| `./onroad` | Open the onroad development view |
|
||||
| `./dev` | Use the isolated host development environment |
|
||||
| `./test` | Run local pre-push regression checks without changing device artifacts |
|
||||
In all supported cars:
|
||||
* Stock Lane Keep Assist (LKA) and stock ALC are replaced by openpilot ALC, which only functions when openpilot is engaged by the user.
|
||||
* Stock LDW is replaced by openpilot LDW.
|
||||
|
||||
See the [build guide](docs/how-to/laptop-device-build.md) for setup, prerequisites, and target-specific behavior. The [UI guide](openpilot/starpilot/ui/README.md) describes desktop previews and their limits.
|
||||
Additionally, on specific supported cars (see ACC column in [supported cars](#supported-cars)):
|
||||
* Stock ACC is replaced by openpilot ACC.
|
||||
* openpilot FCW operates in addition to stock FCW.
|
||||
|
||||
## Testing and vehicle support
|
||||
openpilot should preserve all other vehicle's stock features, including, but are not limited to: FCW, Automatic Emergency Braking (AEB), auto high-beam, blind spot warning, and side collision warning.
|
||||
|
||||
StarPilot retains upstream vehicle and Panda safety interfaces and adds regression coverage for its custom behavior. The [safety workflow](.github/workflows/safety.yaml) and feature tests cover distinct parts of the system. A passing interface test, model comparison, or bench run does not establish driving support for every configuration.
|
||||
Supported Hardware
|
||||
------
|
||||
|
||||
Support depends on the vehicle configuration and enabled feature. An existing vehicle identifier or settings page does not by itself establish driving support. Model Laboratory currently exposes management controls, but paired driving inference remains unavailable pending integration and Chestnut validation.
|
||||
At the moment, openpilot supports the [EON DevKit](https://comma.ai/shop/products/eon-dashcam-devkit) and the [comma two](https://comma.ai/shop/products/comma-two-devkit). A [car harness](https://comma.ai/shop/products/car-harness) is recommended to connect the EON or comma two to the car. In the future, we'd like to support other platforms as well, like gaming PCs.
|
||||
|
||||
## Upstream and attribution
|
||||
Supported Cars
|
||||
------
|
||||
|
||||
The current openpilot baseline is [`78dccf0b482ea1298fd1f6fa59b0554187b02ce6`](https://github.com/commaai/openpilot/commit/78dccf0b482ea1298fd1f6fa59b0554187b02ce6). Its history remains intact, followed by the StarPilot foundation and feature commits. Upstream development continues independently; the baseline changes only after an update has been integrated and checked.
|
||||
| Make | Model (US Market Reference) | Supported Package | ACC | No ACC accel below | No ALC below |
|
||||
| ----------| ------------------------------| ------------------| -----------------| -------------------| -------------|
|
||||
| Acura | ILX 2016-18 | AcuraWatch Plus | openpilot | 25mph<sup>5</sup> | 25mph |
|
||||
| Acura | RDX 2016-18 | AcuraWatch Plus | openpilot | 25mph<sup>5</sup> | 12mph |
|
||||
| Chrysler | Pacifica 2017-18 | Adaptive Cruise | Stock | 0mph | 9mph |
|
||||
| Chrysler | Pacifica Hybrid 2017-18 | Adaptive Cruise | Stock | 0mph | 9mph |
|
||||
| Chrysler | Pacifica Hybrid 2019-20 | Adaptive Cruise | Stock | 0mph | 39mph |
|
||||
| Honda | Accord 2018-19 | All | Stock | 0mph | 3mph |
|
||||
| Honda | Accord Hybrid 2018-19 | All | Stock | 0mph | 3mph |
|
||||
| Honda | Civic Hatchback 2017-19 | Honda Sensing | Stock | 0mph | 12mph |
|
||||
| Honda | Civic Sedan/Coupe 2016-18 | Honda Sensing | openpilot | 0mph | 12mph |
|
||||
| Honda | Civic Sedan/Coupe 2019 | Honda Sensing | Stock | 0mph | 2mph |
|
||||
| Honda | CR-V 2015-16 | Touring | openpilot | 25mph<sup>5</sup> | 12mph |
|
||||
| Honda | CR-V 2017-19 | Honda Sensing | Stock | 0mph | 12mph |
|
||||
| Honda | CR-V Hybrid 2017-2019 | Honda Sensing | Stock | 0mph | 12mph |
|
||||
| Honda | Fit 2018-19 | Honda Sensing | openpilot | 25mph<sup>5</sup> | 12mph |
|
||||
| Honda | Odyssey 2018-20 | Honda Sensing | openpilot | 25mph<sup>5</sup> | 0mph |
|
||||
| Honda | Passport 2019 | All | openpilot | 25mph<sup>5</sup> | 12mph |
|
||||
| Honda | Pilot 2016-18 | Honda Sensing | openpilot | 25mph<sup>5</sup> | 12mph |
|
||||
| Honda | Pilot 2019 | All | openpilot | 25mph<sup>5</sup> | 12mph |
|
||||
| Honda | Ridgeline 2017-19 | Honda Sensing | openpilot | 25mph<sup>5</sup> | 12mph |
|
||||
| Hyundai | Elantra 2017-19<sup>1</sup> | SCC + LKAS | Stock | 19mph | 34mph |
|
||||
| Hyundai | Genesis 2018<sup>1</sup> | All | Stock | 19mph | 34mph |
|
||||
| Hyundai | Santa Fe 2019<sup>1</sup> | All | Stock | 0mph | 0mph |
|
||||
| Jeep | Grand Cherokee 2016-18 | Adaptive Cruise | Stock | 0mph | 9mph |
|
||||
| Jeep | Grand Cherokee 2019 | Adaptive Cruise | Stock | 0mph | 39mph |
|
||||
| Kia | Optima 2019<sup>1</sup> | SCC + LKAS | Stock | 0mph | 0mph |
|
||||
| Kia | Sorento 2018<sup>1</sup> | All | Stock | 0mph | 0mph |
|
||||
| Kia | Stinger 2018<sup>1</sup> | SCC + LKAS | Stock | 0mph | 0mph |
|
||||
| Lexus | CT Hybrid 2017-18 | All | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Lexus | ES 2019 | All | openpilot | 0mph | 0mph |
|
||||
| Lexus | ES Hybrid 2019 | All | openpilot | 0mph | 0mph |
|
||||
| Lexus | IS 2017-2019 | All | Stock | 22mph | 0mph |
|
||||
| Lexus | IS Hybrid 2017 | All | Stock | 0mph | 0mph |
|
||||
| Lexus | RX 2016-17 | All | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Lexus | RX 2020 | All | openpilot | 0mph | 0mph |
|
||||
| Lexus | RX Hybrid 2016-19 | All | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Subaru | Crosstrek 2018-19 | EyeSight | Stock | 0mph | 0mph |
|
||||
| Subaru | Impreza 2019-20 | EyeSight | Stock | 0mph | 0mph |
|
||||
| Toyota | Avalon 2016 | TSS-P | Stock<sup>4</sup>| 20mph<sup>5</sup> | 0mph |
|
||||
| Toyota | Avalon 2017-18 | All | Stock<sup>4</sup>| 20mph<sup>5</sup> | 0mph |
|
||||
| Toyota | Camry 2018-19 | All | Stock | 0mph<sup>2</sup> | 0mph |
|
||||
| Toyota | Camry Hybrid 2018-19 | All | Stock | 0mph<sup>2</sup> | 0mph |
|
||||
| Toyota | C-HR 2017-19 | All | Stock | 0mph | 0mph |
|
||||
| Toyota | C-HR Hybrid 2017-19 | All | Stock | 0mph | 0mph |
|
||||
| Toyota | Corolla 2017-19 | All | Stock<sup>4</sup>| 20mph<sup>5</sup> | 0mph |
|
||||
| Toyota | Corolla 2020 | All | openpilot | 0mph | 0mph |
|
||||
| Toyota | Corolla Hatchback 2019-20 | All | openpilot | 0mph | 0mph |
|
||||
| Toyota | Corolla Hybrid 2020 | All | openpilot | 0mph | 0mph |
|
||||
| Toyota | Highlander 2017-19 | All | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Toyota | Highlander Hybrid 2017-19 | All | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Toyota | Prius 2016 | TSS-P | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Toyota | Prius 2017-19 | All | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Toyota | Prius Prime 2017-20 | All | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Toyota | Rav4 2016 | TSS-P | Stock<sup>4</sup>| 20mph<sup>5</sup> | 0mph |
|
||||
| Toyota | Rav4 2017-18 | All | Stock<sup>4</sup>| 20mph<sup>5</sup> | 0mph |
|
||||
| Toyota | Rav4 2019 | All | openpilot | 0mph | 0mph |
|
||||
| Toyota | Rav4 Hybrid 2016 | TSS-P | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Toyota | Rav4 Hybrid 2017-18 | All | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Toyota | Rav4 Hybrid 2019-20 | All | openpilot | 0mph | 0mph |
|
||||
| Toyota | Sienna 2018 | All | Stock<sup>4</sup>| 0mph | 0mph |
|
||||
| Volkswagen| Golf 2016-19<sup>3</sup> | Driver Assistance | Stock | 0mph | 0mph |
|
||||
|
||||
See [LICENSE](LICENSE), [THIRD_PARTY_NOTICES.md](THIRD_PARTY_NOTICES.md), and [CREDITS.md](CREDITS.md) for licensing and source attribution. Component licenses remain with their source folders. StarPilot is maintained independently of comma.
|
||||
<sup>1</sup>Requires a [panda](https://comma.ai/shop/products/panda-obd-ii-dongle) and open sourced [Hyundai giraffe](https://github.com/commaai/neo/tree/master/giraffe/hyundai), designed for the 2019 Sante Fe; pinout may differ for other Hyundai and Kia models. <br />
|
||||
<sup>2</sup>28mph for Camry 4CYL L, 4CYL LE and 4CYL SE which don't have Full-Speed Range Dynamic Radar Cruise Control. <br />
|
||||
<sup>3</sup>Requires a [custom connector](https://community.comma.ai/wiki/index.php/Volkswagen#Integration_at_R242_Camera) for the [car harness](https://comma.ai/shop/products/car-harness) <br />
|
||||
|
||||
Community Maintained Cars and Features
|
||||
------
|
||||
|
||||
| Make | Model (US Market Reference) | Supported Package | ACC | No ACC accel below | No ALC below |
|
||||
| ----------| ------------------------------| ------------------| -----------------| -------------------| -------------|
|
||||
| Buick | Regal 2018<sup>6</sup> | Adaptive Cruise | openpilot | 0mph | 7mph |
|
||||
| Cadillac | ATS 2018<sup>6</sup> | Adaptive Cruise | openpilot | 0mph | 7mph |
|
||||
| Chevrolet | Malibu 2017<sup>6</sup> | Adaptive Cruise | openpilot | 0mph | 7mph |
|
||||
| Chevrolet | Volt 2017-18<sup>6</sup> | Adaptive Cruise | openpilot | 0mph | 7mph |
|
||||
| GMC | Acadia Denali 2018<sup>6</sup>| Adaptive Cruise | openpilot | 0mph | 7mph |
|
||||
| Holden | Astra 2017<sup>6</sup> | Adaptive Cruise | openpilot | 0mph | 7mph |
|
||||
|
||||
<sup>4</sup>When disconnecting the Driver Support Unit (DSU), openpilot ACC will replace stock ACC. For DSU locations, see [Toyota Wiki page](https://community.comma.ai/wiki/index.php/Toyota). ***NOTE: disconnecting the DSU disables Automatic Emergency Braking (AEB).*** <br />
|
||||
<sup>5</sup>[Comma Pedal](https://community.comma.ai/wiki/index.php/Comma_Pedal) is used to provide stop-and-go capability to some of the openpilot-supported cars that don't currently support stop-and-go. Here is how to [build a Comma Pedal](https://medium.com/@jfrux/comma-pedal-building-with-macrofab-6328bea791e8). ***NOTE: The Comma Pedal is not officially supported by [comma](https://comma.ai).*** <br />
|
||||
<sup>6</sup>Requires a [panda](https://comma.ai/shop/products/panda-obd-ii-dongle) and [community built giraffe](https://zoneos.com/volt/). ***NOTE: disconnecting the ASCM disables Automatic Emergency Braking (AEB).*** <br />
|
||||
|
||||
Community Maintained Cars and Features are not verified by comma to meet our [safety model](SAFETY.md). Be extra cautious using them. They are only available after enabling the toggle in `Settings->Developer->Enable Community Features`.
|
||||
|
||||
Installation Instructions
|
||||
------
|
||||
|
||||
Install openpilot on a EON by entering ``https://openpilot.comma.ai`` during the installer setup.
|
||||
|
||||
Follow this [video instructions](https://youtu.be/3nlkomHathI) to properly mount the EON on the windshield. Note: openpilot features an automatic pose calibration routine and openpilot performance should not be affected by small pitch and yaw misalignments caused by imprecise EON mounting.
|
||||
|
||||
Before placing the device on your windshield, check the state and local laws and ordinances where you drive. Some state laws prohibit or restrict the placement of objects on the windshield of a motor vehicle.
|
||||
|
||||
You will be able to engage openpilot after reviewing the onboarding screens and finishing the calibration procedure.
|
||||
|
||||
Limitations of openpilot ALC and LDW
|
||||
------
|
||||
|
||||
openpilot ALC and openpilot LDW do not automatically drive the vehicle or reduce the amount of attention that must be paid to operate your vehicle. The driver must always keep control of the steering wheel and be ready to correct the openpilot ALC action at all times.
|
||||
|
||||
While changing lanes, openpilot is not capable of looking next to you or checking your blind spot. Only nudge the wheel to initiate a lane change after you have confirmed it's safe to do so.
|
||||
|
||||
Many factors can impact the performance of openpilot ALC and openpilot LDW, causing them to be unable to function as intended. These include, but are not limited to:
|
||||
|
||||
* Poor visibility (heavy rain, snow, fog, etc.) or weather conditions that may interfere with sensor operation.
|
||||
* The road facing camera is obstructed, covered or damaged by mud, ice, snow, etc.
|
||||
* Obstruction caused by applying excessive paint or adhesive products (such as wraps, stickers, rubber coating, etc.) onto the vehicle.
|
||||
* The EON is mounted incorrectly.
|
||||
* When in sharp curves, like on-off ramps, intersections etc...; openpilot is designed to be limited in the amount of steering torque it can produce.
|
||||
* In the presence of restricted lanes or construction zones.
|
||||
* When driving on highly banked roads or in presence of strong cross-wind.
|
||||
* Extremely hot or cold temperatures.
|
||||
* Bright light (due to oncoming headlights, direct sunlight, etc.).
|
||||
* Driving on hills, narrow, or winding roads.
|
||||
|
||||
The list above does not represent an exhaustive list of situations that may interfere with proper operation of openpilot components. It is the driver's responsibility to be in control of the vehicle at all times.
|
||||
|
||||
Limitations of openpilot ACC and FCW
|
||||
------
|
||||
|
||||
openpilot ACC and openpilot FCW are not systems that allow careless or inattentive driving. It is still necessary for the driver to pay close attention to the vehicle’s surroundings and to be ready to re-take control of the gas and the brake at all times.
|
||||
|
||||
Many factors can impact the performance of openpilot ACC and openpilot FCW, causing them to be unable to function as intended. These include, but are not limited to:
|
||||
|
||||
* Poor visibility (heavy rain, snow, fog, etc.) or weather conditions that may interfere with sensor operation.
|
||||
* The road facing camera or radar are obstructed, covered, or damaged by mud, ice, snow, etc.
|
||||
* Obstruction caused by applying excessive paint or adhesive products (such as wraps, stickers, rubber coating, etc.) onto the vehicle.
|
||||
* The EON is mounted incorrectly.
|
||||
* Approaching a toll booth, a bridge or a large metal plate.
|
||||
* When driving on roads with pedestrians, cyclists, etc...
|
||||
* In presence of traffic signs or stop lights, which are not detected by openpilot at this time.
|
||||
* When the posted speed limit is below the user selected set speed. openpilot does not detect speed limits at this time.
|
||||
* In presence of vehicles in the same lane that are not moving.
|
||||
* When abrupt braking maneuvers are required. openpilot is designed to be limited in the amount of deceleration and acceleration that it can produce.
|
||||
* When surrounding vehicles perform close cut-ins from neighbor lanes.
|
||||
* Driving on hills, narrow, or winding roads.
|
||||
* Extremely hot or cold temperatures.
|
||||
* Bright light (due to oncoming headlights, direct sunlight, etc.).
|
||||
* Interference from other equipment that generates radar waves.
|
||||
|
||||
The list above does not represent an exhaustive list of situations that may interfere with proper operation of openpilot components. It is the driver's responsibility to be in control of the vehicle at all times.
|
||||
|
||||
Limitations of openpilot DM
|
||||
------
|
||||
|
||||
openpilot DM should not be considered an exact measurements of the status of alertness of the driver.
|
||||
|
||||
Many factors can impact the performance of openpilot DM, causing it to be unable to function as intended. These include, but are not limited to:
|
||||
|
||||
* Low light conditions, such as driving at night or in dark tunnels.
|
||||
* Bright light (due to oncoming headlights, direct sunlight, etc.).
|
||||
* The driver face is partially or completely outside field of view of the driver facing camera.
|
||||
* Right hand driving vehicles.
|
||||
* The driver facing camera is obstructed, covered, or damaged.
|
||||
|
||||
The list above does not represent an exhaustive list of situations that may interfere with proper operation of openpilot components. A driver should not rely on openpilot DM to assess their level of attention.
|
||||
|
||||
User Data and comma Account
|
||||
------
|
||||
|
||||
By default, openpilot uploads the driving data to our servers. You can also access your data by pairing with the comma connect app ([iOS](https://apps.apple.com/us/app/comma-connect/id1456551889), [Android](https://play.google.com/store/apps/details?id=ai.comma.connect&hl=en_US)). We use your data to train better models and improve openpilot for everyone.
|
||||
|
||||
openpilot is open source software: the user is free to disable data collection if they wish to do so.
|
||||
|
||||
openpilot logs the road facing camera, CAN, GPS, IMU, magnetometer, thermal sensors, crashes, and operating system logs.
|
||||
The driver facing camera is only logged if you explicitly opt-in in settings. The microphone is not recorded.
|
||||
|
||||
By using openpilot, you agree to [our Privacy Policy](https://my.comma.ai/privacy). You understand that use of this software or its related services will generate certain types of user data, which may be logged and stored at the sole discretion of comma. By accepting this agreement, you grant an irrevocable, perpetual, worldwide right to comma for the use of this data.
|
||||
|
||||
Safety and Testing
|
||||
----
|
||||
|
||||
* openpilot observes ISO26262 guidelines, see [SAFETY.md](SAFETY.md) for more detail.
|
||||
* openpilot has software in the loop [tests](run_docker_tests.sh) that run on every commit.
|
||||
* The safety model code lives in panda and is written in C, see [code rigor](https://github.com/commaai/panda#code-rigor) for more details.
|
||||
* panda has software in the loop [safety tests](https://github.com/commaai/panda/tree/master/tests/safety).
|
||||
* Internally, we have a hardware in the loop Jenkins test suite that builds and unit tests the various processes.
|
||||
* panda has additional hardware in the loop [tests](https://github.com/commaai/panda/blob/master/Jenkinsfile).
|
||||
* We run the latest openpilot in a testing closet containing 10 EONs continuously replaying routes.
|
||||
|
||||
Testing on PC
|
||||
------
|
||||
|
||||
Check out the tools directory in master: lots of tools you can use to replay driving data, test and develop openpilot from your pc.
|
||||
|
||||
Community and Contributing
|
||||
------
|
||||
|
||||
openpilot is developed by [comma](https://comma.ai/) and by users like you. We welcome both pull requests and issues on [GitHub](http://github.com/commaai/openpilot). Bug fixes and new car ports are encouraged.
|
||||
|
||||
You can add support for your car by following guides we have written for [Brand](https://medium.com/@comma_ai/how-to-write-a-car-port-for-openpilot-7ce0785eda84) and [Model](https://medium.com/@comma_ai/openpilot-port-guide-for-toyota-models-e5467f4b5fe6) ports. Generally, a car with adaptive cruise control and lane keep assist is a good candidate. [Join our Discord](https://discord.comma.ai) to discuss car ports: most car makes have a dedicated channel.
|
||||
|
||||
Want to get paid to work on openpilot? [comma is hiring](https://comma.ai/jobs/). We also have a [bounty program](https://comma.ai/bounties.html).
|
||||
|
||||
And [follow us on Twitter](https://twitter.com/comma_ai).
|
||||
|
||||
Directory Structure
|
||||
------
|
||||
.
|
||||
├── apk # The apk files used for the UI
|
||||
├── cereal # The messaging spec and libs used for all logs on EON
|
||||
├── common # Library like functionality we've developed here
|
||||
├── installer/updater # Manages auto-updates of openpilot
|
||||
├── opendbc # Files showing how to interpret data from cars
|
||||
├── panda # Code used to communicate on CAN
|
||||
├── phonelibs # Libraries used on EON
|
||||
├── pyextra # Libraries used on EON
|
||||
└── selfdrive # Code needed to drive the car
|
||||
├── assets # Fonts and images for UI
|
||||
├── athena # Allows communication with the app
|
||||
├── boardd # Daemon to talk to the board
|
||||
├── camerad # Driver to capture images from the camera sensors
|
||||
├── car # Car specific code to read states and control actuators
|
||||
├── common # Shared C/C++ code for the daemons
|
||||
├── controls # Perception, planning and controls
|
||||
├── debug # Tools to help you debug and do car ports
|
||||
├── locationd # Soon to be home of precise location
|
||||
├── logcatd # Android logcat as a service
|
||||
├── loggerd # Logger and uploader of car data
|
||||
├── modeld # Driving and monitoring model runners
|
||||
├── proclogd # Logs information from proc
|
||||
├── sensord # IMU / GPS interface code
|
||||
├── tests # Unit tests, system tests and a car simulator
|
||||
└── ui # The UI
|
||||
|
||||
To understand how the services interact, see `cereal/service_list.yaml`.
|
||||
|
||||
Licensing
|
||||
------
|
||||
|
||||
openpilot is released under the MIT license. Some parts of the software are released under other licenses as specified.
|
||||
|
||||
Any user of this software shall indemnify and hold harmless comma.ai, Inc. and its directors, officers, employees, agents, stockholders, affiliates, subcontractors and customers from and against all allegations, claims, actions, suits, demands, damages, liabilities, obligations, losses, settlements, judgments, costs and expenses (including without limitation attorneys’ fees and costs) which arise out of, relate to or result from any use of this software by user.
|
||||
|
||||
**THIS IS ALPHA QUALITY SOFTWARE FOR RESEARCH PURPOSES ONLY. THIS IS NOT A PRODUCT.
|
||||
YOU ARE RESPONSIBLE FOR COMPLYING WITH LOCAL LAWS AND REGULATIONS.
|
||||
NO WARRANTY EXPRESSED OR IMPLIED.**
|
||||
|
||||
---
|
||||
|
||||
<img src="https://d1qb2nb5cznatu.cloudfront.net/startups/i/1061157-bc7e9bf3b246ece7322e6ffe653f6af8-medium_jpg.jpg?buster=1458363130" width="75"></img> <img src="https://cdn-images-1.medium.com/max/1600/1*C87EjxGeMPrkTuVRVWVg4w.png" width="225"></img>
|
||||
|
||||
+54
-685
@@ -1,634 +1,3 @@
|
||||
# StarPilot 7.0 — Domathon development
|
||||
|
||||
The openpilot rebase is in progress. Domathon is not yet a completed StarPilot release, and feature or vehicle presence alone does not establish full parity with Dom.
|
||||
|
||||
See the [project overview](README.md) for the current development entry points and the [history guide](docs/DEVELOPMENT_HISTORY.md) for the upstream boundary and feature organization. Release-specific support and validation will be recorded when a release is prepared.
|
||||
|
||||
# Upstream openpilot release history
|
||||
|
||||
The entries below are retained upstream release notes. They describe openpilot releases, not completed StarPilot 7.0 milestones.
|
||||
|
||||
Version 0.11.2 (2026-08-12)
|
||||
=======================
|
||||
* New driving model
|
||||
* Big model with 880M parameters
|
||||
* Support for big models running on an external GPU
|
||||
* Live stream cameras from comma connect
|
||||
* Generate dashcam clips from comma connect
|
||||
* Remote comma body control from comma connect
|
||||
* New alert sounds
|
||||
* CUPRA Born 2021-2023 support thanks to DaHansi!
|
||||
* Volkswagen ID.4 2021-2025 support thanks to DaHansi!
|
||||
|
||||
Version 0.11.1 (2026-05-18)
|
||||
========================
|
||||
* New driver monitoring model
|
||||
* Improved image processing pipeline for driver camera
|
||||
* Improved thermal policy for comma four
|
||||
* Acura MDX 2022-24 support thanks to mvl-boston!
|
||||
* Rivian R1S and R1T 2025 support thanks to lukasloetkolben!
|
||||
|
||||
Version 0.11.0 (2026-03-17)
|
||||
========================
|
||||
* New driving model #36798
|
||||
* Fully trained using a learned simulator
|
||||
* Improved longitudinal performance in Experimental mode
|
||||
* Reduce comma four standby power usage by 77% to 52 mW
|
||||
* Kia K7 2017 support thanks to royjr!
|
||||
* Lexus LS 2018 support thanks to Hacheoy!
|
||||
|
||||
Version 0.10.3 (2025-12-17)
|
||||
========================
|
||||
* New driving model #36249
|
||||
* New temporal policy architecture
|
||||
* New on-policy training physics noise model
|
||||
* New driver monitoring model #36409
|
||||
* Trained on a new dataset, including comma four data
|
||||
* Improved inter-process communication memory efficiency
|
||||
|
||||
Version 0.10.2 (2025-11-19)
|
||||
========================
|
||||
* comma four support
|
||||
|
||||
Version 0.10.1 (2025-09-08)
|
||||
========================
|
||||
* New driving model #36276
|
||||
* World Model: removed global localization inputs
|
||||
* World Model: 2x the number of parameters
|
||||
* World Model: trained on 4x the number of segments
|
||||
* VAE Compression Model: new architecture and training objective
|
||||
* Driving Vision Model: trained on 4x the number of segments
|
||||
* New Driver Monitoring model #36198
|
||||
* Acura TLX 2021 support thanks to MVL!
|
||||
* Honda City 2023 support thanks to vanillagorillaa and drFritz!
|
||||
* Honda N-Box 2018 support thanks to miettal!
|
||||
* Honda Odyssey 2021-25 support thanks to csouers and MVL!
|
||||
* Honda Passport 2026 support thanks to vanillagorillaa and MVL!
|
||||
|
||||
Version 0.10.0 (2025-08-05)
|
||||
========================
|
||||
* New driving model
|
||||
* New training architecture
|
||||
* Described in our CVPR paper: "Learning to Drive from a World Model"
|
||||
* Longitudinal MPC replaced by E2E planning from World Model in Experimental Mode
|
||||
* Action from lateral MPC as training objective replaced by E2E planning from World Model
|
||||
* Low-speed lead car ground-truth fixes
|
||||
* Enable live-learned steering actuation delay
|
||||
* Opt-in audio recording for dashcam video
|
||||
* Acura MDX 2025 support thanks to vanillagorillaa and MVL!
|
||||
* Honda Accord 2023-25 support thanks to vanillagorillaa and MVL!
|
||||
* Honda CR-V 2023-25 support thanks to vanillagorillaa and MVL!
|
||||
* Honda Pilot 2023-25 support thanks to vanillagorillaa and MVL!
|
||||
|
||||
Version 0.9.9 (2025-05-23)
|
||||
========================
|
||||
* New driving model
|
||||
* New training architecture using parts from MLSIM
|
||||
* Steering actuation delay is now learned online
|
||||
* Ford Escape 2023-24 support thanks to incognitojam!
|
||||
* Ford Kuga 2024 support thanks to incognitojam!
|
||||
* Hyundai Nexo 2021 support thanks to sunnyhaibin!
|
||||
* Tesla Model 3 and Y support thanks to lukasloetkolben!
|
||||
* Lexus RC 2023 support thanks to nelsonjchen!
|
||||
|
||||
Version 0.9.8 (2025-02-28)
|
||||
========================
|
||||
* New driving model
|
||||
* Model now gates applying positive acceleration in Chill mode
|
||||
* New driver monitoring model
|
||||
* Reduced false positives related to passengers
|
||||
* Image processing pipeline moved to the ISP
|
||||
* More GPU time for bigger driving models
|
||||
* Power draw reduced 0.5W, which means your device runs cooler
|
||||
* Added toggle to enable driver monitoring even when openpilot is not engaged
|
||||
* Localizer rewritten to remove GPS dependency at runtime
|
||||
* Firehose Mode for maximizing your training data uploads
|
||||
* Enable openpilot longitudinal control for Ford Q3 vehicles
|
||||
* New Toyota TSS2 longitudinal tune
|
||||
* Rivian R1S and R1T support thanks to lukasloetkolben!
|
||||
* Ford F-150, F-150 Hybrid, Mach-E, and Ranger support
|
||||
|
||||
Version 0.9.7 (2024-06-13)
|
||||
========================
|
||||
* New driving model
|
||||
* Inputs the past curvature for smoother and more accurate lateral control
|
||||
* Simplified neural network architecture in the model's last layers
|
||||
* Minor fixes to desire augmentation and weight decay
|
||||
* New driver monitoring model
|
||||
* Improved end-to-end bit for phone detection
|
||||
* Adjust driving personality with the follow distance button
|
||||
* Support for hybrid variants of supported Ford models
|
||||
* Fingerprinting without the OBD-II port on all cars
|
||||
* Improved fuzzy fingerprinting for Ford and Volkswagen
|
||||
|
||||
Version 0.9.6 (2024-02-27)
|
||||
========================
|
||||
* New driving model
|
||||
* Vision model trained on more data
|
||||
* Improved driving performance
|
||||
* Directly outputs curvature for lateral control
|
||||
* New driver monitoring model
|
||||
* Trained on larger dataset
|
||||
* Model path UI
|
||||
* Shows where driving model wants to be
|
||||
* Shows what model is seeing more clearly, but more jittery
|
||||
* AGNOS 9
|
||||
* comma body streaming and controls over WebRTC
|
||||
* Improved fuzzy fingerprinting for many makes and models
|
||||
* Alpha longitudinal support for new Toyota models
|
||||
* Chevrolet Equinox 2019-22 support thanks to JasonJShuler and nworb-cire!
|
||||
* Dodge Durango 2020-21 support
|
||||
* Hyundai Staria 2023 support thanks to sunnyhaibin!
|
||||
* Kia Niro Plug-in Hybrid 2022 support thanks to sunnyhaibin!
|
||||
* Lexus LC 2024 support thanks to nelsonjchen!
|
||||
* Toyota RAV4 2023-24 support
|
||||
* Toyota RAV4 Hybrid 2023-24 support
|
||||
|
||||
Version 0.9.5 (2023-11-17)
|
||||
========================
|
||||
* New driving model
|
||||
* Improved navigate on openpilot performance using navigation instructions as an additional model input
|
||||
* Do lateral planning inside the model
|
||||
* New vision transformer architecture
|
||||
* Cadillac Escalade ESV 2019 support thanks to twilsonco!
|
||||
* Hyundai Azera 2022 support thanks to sunnyhaibin!
|
||||
* Hyundai Azera Hybrid 2020 support thanks to chanhojung and haram-KONA!
|
||||
* Hyundai Custin 2023 support thanks to sunnyhaibin and Saber422!
|
||||
* Hyundai Ioniq 6 2023 support thanks to sunnyhaibin and alamo3!
|
||||
* Hyundai Kona Electric 2023 (Korean version) support thanks to sunnyhaibin and haram-KONA!
|
||||
* Kia K8 Hybrid (with HDA II) 2023 support thanks to sunnyhaibin!
|
||||
* Kia Optima Hybrid 2019 support
|
||||
* Kia Sorento Hybrid 2023 support thanks to sunnyhaibin!
|
||||
* Lexus GS F 2016 support thanks to snyperifle!
|
||||
* Lexus IS 2023 support thanks to L3R5!
|
||||
|
||||
Version 0.9.4 (2023-07-27)
|
||||
========================
|
||||
* comma 3X support
|
||||
* Navigate on openpilot in Experimental mode
|
||||
* When navigation has a destination, openpilot will input the map information into the model, which provides useful context to help the model understand the scene
|
||||
* When navigating on openpilot, openpilot will keep left or right appropriately at forks and exits
|
||||
* When navigating on openpilot, lane change behavior is unchanged and still activated by the driver
|
||||
* When navigate on openpilot is active, the path on the map is green
|
||||
* UI updates
|
||||
* Navigation settings moved to home screen and map
|
||||
* Border color always shows engagement status. Blue means disengaged, green means engaged, and grey means engaged with human overriding
|
||||
* Alerts are shown inside the border. Black means info, orange means warning, and red means critical alert
|
||||
* Bookmarked segments are preserved on the device's storage
|
||||
* Ford Focus 2018 support
|
||||
* Kia Carnival 2023 support thanks to sunnyhaibin!
|
||||
|
||||
Version 0.9.3 (2023-06-29)
|
||||
========================
|
||||
* New driving model
|
||||
* Improved height estimation and added height tracking in liveCalibration
|
||||
* Model inputs refactor
|
||||
* New driving personality setting
|
||||
* Three settings: aggressive, standard, and relaxed
|
||||
* Standard is recommended and the default
|
||||
* In aggressive mode, lead follow distance is shorter and acceleration response is quicker
|
||||
* In relaxed mode, lead follow distance is longer
|
||||
* Improved fuzzy fingerprinting for Hyundai, Kia, and Genesis
|
||||
* Improved thermal management logic
|
||||
|
||||
Version 0.9.2 (2023-05-22)
|
||||
========================
|
||||
* New driving model
|
||||
* Reduced turn diving
|
||||
* Trained on a new dataset
|
||||
* UI updates
|
||||
* New experimental mode visualization
|
||||
* Draw MPC path instead of model-predicted path
|
||||
* AGNOS 7
|
||||
* Faster boot time
|
||||
* Fixes rare no sounds bug
|
||||
* Fixes bootsplash bug at extreme temperatures
|
||||
* Buick LaCrosse 2017-19 support thanks to koch-cf!
|
||||
* Chevrolet Trailblazer 2021-22 support thanks to TurboCE!
|
||||
* Ford Bronco Sport 2021-22 support
|
||||
* Ford Escape 2020-22 support
|
||||
* Ford Explorer 2020-22 support
|
||||
* Ford Kuga 2020-22 support
|
||||
* Ford Maverick 2022-23 support
|
||||
* Genesis GV80 2023 support thanks to JWingate80!
|
||||
* Honda HR-V 2023 support thanks to AlexandreSato and galegozi!
|
||||
* Kia Niro EV 2023 support thanks to JosselinLecocq!
|
||||
* Lexus ES 2017-18 support
|
||||
* Lincoln Aviator 2021 support
|
||||
* Škoda Fabia 2022-23 support thanks to jyoung8607!
|
||||
|
||||
|
||||
Version 0.9.1 (2023-02-28)
|
||||
========================
|
||||
* New driving model
|
||||
* 30% improved height estimation resulting in better driving performance for tall cars
|
||||
* Driver monitoring: removed timer resetting on user interaction if distracted
|
||||
* UI updates
|
||||
* Adjust alert volume using ambient noise level
|
||||
* Driver monitoring icon shows driver's head pose
|
||||
* German translation thanks to Vrabetz and CzokNorris!
|
||||
* Cadillac Escalade 2017 support thanks to rickygilleland!
|
||||
* Chevrolet Bolt EV 2022-23 support thanks to JasonJShuler!
|
||||
* Genesis GV60 2023 support thanks to sunnyhaibin!
|
||||
* Hyundai Tucson 2022-23 support
|
||||
* Kia K5 Hybrid 2020 support thanks to sunnyhaibin!
|
||||
* Kia Niro Hybrid 2023 support thanks to sunnyhaibin!
|
||||
* Kia Sorento 2022-23 support thanks to sunnyhaibin!
|
||||
* Kia Sorento Plug-in Hybrid 2022 support thanks to sunnyhaibin!
|
||||
* Toyota C-HR 2021 support thanks to eFiniLan!
|
||||
* Toyota C-HR Hybrid 2022 support thanks to Korben00!
|
||||
* Volkswagen Crafter and MAN TGE 2017-23 support thanks to jyoung8607!
|
||||
|
||||
Version 0.9.0 (2022-11-21)
|
||||
========================
|
||||
* New driving model
|
||||
* Internal feature space information content increased tenfold during training to ~700 bits, which makes the model dramatically more accurate
|
||||
* Less reliance on previous frames makes model more reactive and snappy
|
||||
* Trained in new reprojective simulator
|
||||
* Trained in 36 hours from scratch, compared to one week for previous releases
|
||||
* Training now simulates both lateral and longitudinal behavior, which allows openpilot to slow down for turns, stop at traffic lights, and more in experimental mode
|
||||
* Experimental driving mode
|
||||
* End-to-end longitudinal control
|
||||
* Stops for traffic lights and stop signs
|
||||
* Slows down for turns
|
||||
* openpilot defaults to chill mode, enable experimental mode in settings
|
||||
* Driver monitoring updates
|
||||
* New bigger model with added end-to-end distracted trigger
|
||||
* Reduced false positives during driver calibration
|
||||
* Self-tuning torque controller: learns parameters live for each car
|
||||
* Torque controller used on all Toyota, Lexus, Hyundai, Kia, and Genesis models
|
||||
* UI updates
|
||||
* Matched speeds shown on car's dash
|
||||
* Multi-language in navigation
|
||||
* Improved update experience
|
||||
* Border turns grey while overriding steering
|
||||
* Bookmark events while driving; view them in comma connect
|
||||
* New onroad visualization for experimental mode
|
||||
* tools: new and improved cabana thanks to deanlee!
|
||||
* Experimental longitudinal support for Volkswagen, CAN-FD Hyundai, and new GM models
|
||||
* Genesis GV70 2022-23 support thanks to zunichky and sunnyhaibin!
|
||||
* Hyundai Santa Cruz 2021-22 support thanks to sunnyhaibin!
|
||||
* Kia Sportage 2023 support thanks to sunnyhaibin!
|
||||
* Kia Sportage Hybrid 2023 support thanks to sunnyhaibin!
|
||||
* Kia Stinger 2022 support thanks to sunnyhaibin!
|
||||
|
||||
Version 0.8.16 (2022-08-26)
|
||||
========================
|
||||
* New driving model
|
||||
* Reduced turn cutting
|
||||
* Auto-detect right hand drive setting with driver monitoring model
|
||||
* Improved fan controller for comma three
|
||||
* New translations
|
||||
* Japanese thanks to cydia2020!
|
||||
* Brazilian Portuguese thanks to AlexandreSato!
|
||||
* Chevrolet Bolt EUV 2022-23 support thanks to JasonJShuler!
|
||||
* Chevrolet Silverado 1500 2020-21 support thanks to JasonJShuler!
|
||||
* GMC Sierra 1500 2020-21 support thanks to JasonJShuler!
|
||||
* Hyundai Ioniq 5 2022 support thanks to sunnyhaibin!
|
||||
* Hyundai Kona Electric 2022 support thanks to sunnyhaibin!
|
||||
* Hyundai Tucson Hybrid 2022 support thanks to sunnyhaibin!
|
||||
* Subaru Legacy 2020-22 support thanks to martinl!
|
||||
* Subaru Outback 2020-22 support
|
||||
|
||||
Version 0.8.15 (2022-07-20)
|
||||
========================
|
||||
* New driving model
|
||||
* Path planning uses end-to-end output instead of lane lines at all times
|
||||
* Reduced ping pong
|
||||
* Improved lane centering
|
||||
* New lateral controller based on physical wheel torque model
|
||||
* Much smoother control that's consistent across the speed range
|
||||
* Effective feedforward that uses road roll
|
||||
* Simplified tuning, all car-specific parameters can be derived from data
|
||||
* Used on select Toyota and Hyundai models at first
|
||||
* Significantly improved control on TSS-P Prius
|
||||
* New driver monitoring model
|
||||
* Bigger model, covering full interior view from driver camera
|
||||
* Works with a wider variety of mounting angles
|
||||
* 3x more unique comma three training data than previous
|
||||
* Navigation improvements
|
||||
* Speed limits shown while navigating
|
||||
* Faster position fix by using raw GPS measurements
|
||||
* UI updates
|
||||
* Multilanguage support for settings and home screen
|
||||
* New font
|
||||
* Refreshed max speed design
|
||||
* More consistent camera view perspective across cars
|
||||
* Reduced power usage: device runs cooler and fan spins less
|
||||
* AGNOS 5
|
||||
* Support VSCode remote SSH target
|
||||
* Support for delta updates to reduce data usage on future OS updates
|
||||
* Chrysler ECU firmware fingerprinting thanks to realfast!
|
||||
* Honda Civic 2022 support
|
||||
* Hyundai Tucson 2021 support thanks to bluesforte!
|
||||
* Kia EV6 2022 support
|
||||
* Lexus NX Hybrid 2020 support thanks to AlexandreSato!
|
||||
* Ram 1500 2019-21 support thanks to realfast!
|
||||
|
||||
Version 0.8.14 (2022-06-01)
|
||||
========================
|
||||
* New driving model
|
||||
* Bigger model, using both of comma three's road-facing cameras
|
||||
* Better at cut-in detection and tight turns
|
||||
* New driver monitoring model
|
||||
* Tweaked network structure to improve output resolution for DSP
|
||||
* Fixed bug in quantization aware training to reduce quantizing errors
|
||||
* Resulted in 7x less MSE and no more random biases at runtime
|
||||
* Added toggle to disable disengaging on the accelerator pedal
|
||||
* comma body support
|
||||
* Audi RS3 support thanks to jyoung8607!
|
||||
* Hyundai Ioniq Plug-in Hybrid 2019 support thanks to sunnyhaibin!
|
||||
* Hyundai Tucson Diesel 2019 support thanks to sunnyhaibin!
|
||||
* Toyota Alphard Hybrid 2021 support
|
||||
* Toyota Avalon Hybrid 2022 support
|
||||
* Toyota RAV4 2022 support
|
||||
* Toyota RAV4 Hybrid 2022 support
|
||||
|
||||
Version 0.8.13 (2022-02-18)
|
||||
========================
|
||||
* Improved driver monitoring
|
||||
* Re-tuned driver pose learner for relaxed driving positions
|
||||
* Added reliance on driving model to be more scene adaptive
|
||||
* Matched strictness between comma two and comma three
|
||||
* Improved performance in turns by compensating for the road bank angle
|
||||
* Improved camera focus on the comma two
|
||||
* AGNOS 4
|
||||
* ADB support
|
||||
* improved cell auto configuration
|
||||
* NEOS 19
|
||||
* package updates
|
||||
* stability improvements
|
||||
* Subaru ECU firmware fingerprinting thanks to martinl!
|
||||
* Hyundai Santa Fe Plug-in Hybrid 2022 support thanks to sunnyhaibin!
|
||||
* Mazda CX-5 2022 support thanks to Jafaral!
|
||||
* Subaru Impreza 2020 support thanks to martinl!
|
||||
* Toyota Avalon 2022 support thanks to sshane!
|
||||
* Toyota Prius v 2017 support thanks to CT921!
|
||||
* Volkswagen Caravelle 2020 support thanks to jyoung8607!
|
||||
|
||||
Version 0.8.12 (2021-12-15)
|
||||
========================
|
||||
* New driving model
|
||||
* Improved behavior around exits
|
||||
* Better pose accuracy at high speeds, allowing max speed of 90mph
|
||||
* Fully incorporated comma three data into all parts of training stack
|
||||
* Improved follow distance
|
||||
* Better longitudinal policy, especially in low speed traffic
|
||||
* New alert sounds
|
||||
* AGNOS 3
|
||||
* Display burn in mitigation
|
||||
* Improved audio amplifier configuration
|
||||
* System reliability improvements
|
||||
* Update Python to 3.8.10
|
||||
* Raw logs upload moved to connect.comma.ai
|
||||
* Fixed HUD alerts on newer Honda Bosch thanks to csouers!
|
||||
* Audi Q3 2020-21 support thanks to jyoung8607!
|
||||
* Lexus RC 2020 support thanks to ErichMoraga!
|
||||
|
||||
Version 0.8.11 (2021-11-29)
|
||||
========================
|
||||
* Support for CAN FD on the red panda
|
||||
* Support for an external panda on the comma three
|
||||
* Navigation: Show more detailed instructions when approaching maneuver
|
||||
* Fixed occasional steering faults on GM cars thanks to jyoung8607!
|
||||
* Nissan ECU firmware fingerprinting thanks to robin-reckmann, martinl, and razem-io!
|
||||
* Cadillac Escalade ESV 2016 support thanks to Gibby!
|
||||
* Genesis G70 2020 support thanks to tecandrew!
|
||||
* Hyundai Santa Fe Hybrid 2022 support thanks to sunnyhaibin!
|
||||
* Mazda CX-9 2021 support thanks to Jacar!
|
||||
* Volkswagen Polo 2020 support thanks to jyoung8607!
|
||||
* Volkswagen T-Roc 2021 support thanks to jyoung8607!
|
||||
|
||||
Version 0.8.10 (2021-11-01)
|
||||
========================
|
||||
* New driving model
|
||||
* Trained on one million minutes!!!
|
||||
* Fixed lead training making lead predictions significantly more accurate
|
||||
* Fixed several localizer dataset bugs and loss function bugs, overall improved accuracy
|
||||
* New driver monitoring model
|
||||
* Trained on latest data from both comma two and comma three
|
||||
* Increased model field of view by 40% on comma three
|
||||
* Improved model stability on masked users
|
||||
* Improved pose prediction with reworked ground-truth stack
|
||||
* Lateral and longitudinal planning MPCs now in ACADOS
|
||||
* Combined longitudinal MPCs
|
||||
* All longitudinal planning now happens in a single MPC system
|
||||
* Fixed instability in MPC problem to prevent sporadic CPU usage
|
||||
* AGNOS 2: minor stability improvements and builder repo open sourced
|
||||
* tools: new and improved replay thanks to deanlee!
|
||||
* Moved community-supported cars outside of the Community Features toggle
|
||||
* Improved FW fingerprinting reliability for Hyundai/Kia/Genesis
|
||||
* Added prerequisites for longitudinal control on Hyundai/Kia/Genesis and Honda Bosch
|
||||
* Audi S3 2015 support thanks to jyoung8607!
|
||||
* Honda Freed 2020 support thanks to belm0!
|
||||
* Hyundai Ioniq Hybrid 2020-2022 support thanks to sunnyhaibin!
|
||||
* Hyundai Santa Fe 2022 support thanks to sunnyhaibin!
|
||||
* Kia K5 2021 support thanks to sunnyhaibin!
|
||||
* Škoda Kamiq 2021 support thanks to jyoung8607!
|
||||
* Škoda Karoq 2019 support thanks to jyoung8607!
|
||||
* Volkswagen Arteon 2021 support thanks to jyoung8607!
|
||||
* Volkswagen California 2021 support thanks to jyoung8607!
|
||||
* Volkswagen Taos 2022 support thanks to jyoung8607!
|
||||
|
||||
Version 0.8.9 (2021-09-14)
|
||||
========================
|
||||
* Improved fan control on comma three
|
||||
* AGNOS 1.5: improved stability
|
||||
* Honda e 2020 support
|
||||
|
||||
Version 0.8.8 (2021-08-27)
|
||||
========================
|
||||
* New driving model with improved laneless performance
|
||||
* Trained on 5000+ hours of diverse driving data from 3000+ users in 40+ countries
|
||||
* Better anti-cheating methods during simulator training ensure the model hugs less when in laneless mode
|
||||
* All new desire ground-truthing stack makes the model better at lane changes
|
||||
* New driver monitoring model: improved performance on comma three
|
||||
* NEOS 18 for comma two: update packages
|
||||
* AGNOS 1.3 for comma three: fix display init at high temperatures
|
||||
* Improved auto-exposure on comma three
|
||||
* Improved longitudinal control on Honda Nidec cars
|
||||
* Hyundai Kona Hybrid 2020 support thanks to haram-KONA!
|
||||
* Hyundai Sonata Hybrid 2021 support thanks to Matt-Wash-Burn!
|
||||
* Kia Niro Hybrid 2021 support thanks to tetious!
|
||||
|
||||
Version 0.8.7 (2021-07-31)
|
||||
========================
|
||||
* comma three support!
|
||||
* Navigation alpha for the comma three!
|
||||
* Volkswagen T-Cross 2021 support thanks to jyoung8607!
|
||||
|
||||
Version 0.8.6 (2021-07-21)
|
||||
========================
|
||||
* Revamp lateral and longitudinal planners
|
||||
* Refactor planner output API to be more readable and verbose
|
||||
* Planners now output desired trajectories for speed, acceleration, curvature, and curvature rate
|
||||
* Use MPC for longitudinal planning when no lead car is present, makes accel and decel smoother
|
||||
* Remove "CHECK DRIVER FACE VISIBILITY" warning
|
||||
* Fixed cruise fault on some TSS2.5 Camrys and international Toyotas
|
||||
* Hyundai Elantra Hybrid 2021 support thanks to tecandrew!
|
||||
* Hyundai Ioniq PHEV 2020 support thanks to YawWashout!
|
||||
* Kia Niro Hybrid 2019 support thanks to jyoung8607!
|
||||
* Škoda Octavia RS 2016 support thanks to jyoung8607!
|
||||
* Toyota Alphard 2020 support thanks to belm0!
|
||||
* Volkswagen Golf SportWagen 2015 support thanks to jona96!
|
||||
* Volkswagen Touran 2017 support thanks to jyoung8607!
|
||||
|
||||
Version 0.8.5 (2021-06-11)
|
||||
========================
|
||||
* NEOS update: improved reliability and stability with better voltage regulator configuration
|
||||
* Smart model-based Forward Collision Warning
|
||||
* CAN-based fingerprinting moved behind community features toggle
|
||||
* Improved longitudinal control on Toyotas with a comma pedal
|
||||
* Improved auto-brightness using road-facing camera
|
||||
* Added "Software" settings page with updater controls
|
||||
* Audi Q2 2018 support thanks to jyoung8607!
|
||||
* Hyundai Elantra 2021 support thanks to CruiseBrantley!
|
||||
* Lexus UX Hybrid 2019-2020 support thanks to brianhaugen2!
|
||||
* Toyota Avalon Hybrid 2019 support thanks to jbates9011!
|
||||
* SEAT Leon 2017 & 2020 support thanks to jyoung8607!
|
||||
* Škoda Octavia 2015 & 2019 support thanks to jyoung8607!
|
||||
|
||||
Version 0.8.4 (2021-05-17)
|
||||
========================
|
||||
* Delay controls start until system is ready
|
||||
* Fuzzy car identification, enabled with Community Features toggle
|
||||
* Localizer optimized for increased precision and less CPU usage
|
||||
* Re-tuned lateral control to be more aggressive when model is confident
|
||||
* Toyota Mirai 2021 support
|
||||
* Lexus NX 300 2020 support thanks to goesreallyfast!
|
||||
* Volkswagen Atlas 2018-19 support thanks to jyoung8607!
|
||||
|
||||
Version 0.8.3 (2021-04-01)
|
||||
========================
|
||||
* New model
|
||||
* Trained on new diverse dataset from 2000+ users from 30+ countries
|
||||
* Trained with improved segnet from the comma-pencil community project
|
||||
* 🥬 Dramatically improved end-to-end lateral performance 🥬
|
||||
* Toggle added to disable the use of lanelines
|
||||
* NEOS update: update packages and support for new UI
|
||||
* New offroad UI based on Qt
|
||||
* Default SSH key only used for setup
|
||||
* Kia Ceed 2019 support thanks to ZanZaD13!
|
||||
* Kia Seltos 2021 support thanks to speedking456!
|
||||
* Added support for many Volkswagen and Škoda models thanks to jyoung8607!
|
||||
|
||||
Version 0.8.2 (2021-02-26)
|
||||
========================
|
||||
* Use model points directly in MPC (no more polyfits), making lateral planning more accurate
|
||||
* Use model heading prediction for smoother lateral control
|
||||
* Smarter actuator delay compensation
|
||||
* Improve qcamera resolution for improved video in explorer and connect
|
||||
* Adjust maximum engagement speed to better fit the model's training distribution
|
||||
* New driver monitoring model trained with 3x more diverse data
|
||||
* Improved face detection with masks
|
||||
* More predictable DM alerts when visibility is bad
|
||||
* Rewritten video streaming between openpilot processes
|
||||
* Improved longitudinal tuning on TSS2 Corolla and Rav4 thanks to briskspirit!
|
||||
* Audi A3 2015 and 2017 support thanks to keeleysam!
|
||||
* Nissan Altima 2020 support thanks to avolmensky!
|
||||
* Lexus ES Hybrid 2018 support thanks to TheInventorMan!
|
||||
* Toyota Camry Hybrid 2021 support thanks to alancyau!
|
||||
|
||||
Version 0.8.1 (2020-12-21)
|
||||
========================
|
||||
* Original EON is deprecated, upgrade to comma two
|
||||
* Better model performance in heavy rain
|
||||
* Better lane positioning in turns
|
||||
* Fixed bug where model would cut turns on empty roads at night
|
||||
* Fixed issue where some Toyotas would not completely stop thanks to briskspirit!
|
||||
* Toyota Camry 2021 with TSS2.5 support
|
||||
* Hyundai Ioniq Electric 2020 support thanks to baldwalker!
|
||||
|
||||
Version 0.8.0 (2020-11-30)
|
||||
========================
|
||||
* New driving model: fully 3D and improved cut-in detection
|
||||
* UI draws 2 road edges, 4 lanelines and paths in 3D
|
||||
* Major fixes to cut-in detection for openpilot longitudinal
|
||||
* Grey panda is no longer supported, upgrade to comma two or black panda
|
||||
* Lexus NX 2018 support thanks to matt12eagles!
|
||||
* Kia Niro EV 2020 support thanks to nickn17!
|
||||
* Toyota Prius 2021 support thanks to rav4kumar!
|
||||
* Improved lane positioning with uncertain lanelines, wide lanes and exits
|
||||
* Improved lateral control for Prius and Subaru
|
||||
|
||||
Version 0.7.10 (2020-10-29)
|
||||
========================
|
||||
* Grey panda is deprecated, upgrade to comma two or black panda
|
||||
* NEOS update: update to Python 3.8.2 and lower CPU frequency
|
||||
* Improved thermals due to reduced CPU frequency
|
||||
* Update SNPE to 1.41.0
|
||||
* Reduced offroad power consumption
|
||||
* Various system stability improvements
|
||||
* Acura RDX 2020 support thanks to csouers!
|
||||
|
||||
Version 0.7.9 (2020-10-09)
|
||||
========================
|
||||
* Improved car battery power management
|
||||
* Improved updater robustness
|
||||
* Improved realtime performance
|
||||
* Reduced UI and modeld lags
|
||||
* Increased torque on 2020 Hyundai Sonata and Palisade
|
||||
|
||||
Version 0.7.8 (2020-08-19)
|
||||
========================
|
||||
* New driver monitoring model: improved face detection and better compatibility with sunglasses
|
||||
* Download NEOS operating system updates in the background
|
||||
* Improved updater reliability and responsiveness
|
||||
* Hyundai Kona 2020, Veloster 2019, and Genesis G70 2018 support thanks to xps-genesis!
|
||||
|
||||
Version 0.7.7 (2020-07-20)
|
||||
========================
|
||||
* White panda is no longer supported, upgrade to comma two or black panda
|
||||
* Improved vehicle model estimation using high precision localizer
|
||||
* Improved thermal management on comma two
|
||||
* Improved autofocus for road-facing camera
|
||||
* Improved noise performance for driver-facing camera
|
||||
* Block lane change start using blindspot monitor on select Toyota, Hyundai, and Subaru
|
||||
* Fix GM ignition detection
|
||||
* Code cleanup and smaller release sizes
|
||||
* Hyundai Sonata 2020 promoted to officially supported car
|
||||
* Hyundai Ioniq Electric Limited 2019 and Ioniq SE 2020 support thanks to baldwalker!
|
||||
* Subaru Forester 2019 and Ascent 2019 support thanks to martinl!
|
||||
|
||||
Version 0.7.6.1 (2020-06-16)
|
||||
========================
|
||||
* Hotfix: update kernel on some comma twos (orders #8570-#8680)
|
||||
|
||||
Version 0.7.6 (2020-06-05)
|
||||
========================
|
||||
* White panda is deprecated, upgrade to comma two or black panda
|
||||
* 2017 Nissan X-Trail, 2018-19 Leaf and 2019 Rogue support thanks to avolmensky!
|
||||
* 2017 Mazda CX-5 support in dashcam mode thanks to Jafaral!
|
||||
* Huge CPU savings in modeld by using thneed!
|
||||
* Lots of code cleanup and refactors
|
||||
|
||||
Version 0.7.5 (2020-05-13)
|
||||
========================
|
||||
* Right-Hand Drive support for both driving and driver monitoring!
|
||||
* New driving model: improved at sharp turns and lead speed estimation
|
||||
* New driver monitoring model: overall improvement on comma two
|
||||
* Driver camera preview in settings to improve mounting position
|
||||
* Added support for many Hyundai, Kia, Genesis models thanks to xx979xx!
|
||||
* Improved lateral tuning for 2020 Toyota Rav 4 (hybrid)
|
||||
|
||||
Version 0.7.4 (2020-03-20)
|
||||
========================
|
||||
* New driving model: improved lane changes and lead car detection
|
||||
* Improved driver monitoring model: improve eye detection
|
||||
* Improved calibration stability
|
||||
* Improved lateral control on some 2019 and 2020 Toyota Prius
|
||||
* Improved lateral control on VW Golf: 20% more steering torque
|
||||
* Fixed bug where some 2017 and 2018 Toyota C-HR would use the wrong steering angle sensor
|
||||
* Support for Honda Insight thanks to theantihero!
|
||||
* Code cleanup in car abstraction layers and ui
|
||||
|
||||
Version 0.7.3 (2020-02-21)
|
||||
========================
|
||||
* Support for 2020 Highlander thanks to che220!
|
||||
* Support for 2018 Lexus NX 300h thanks to kengggg!
|
||||
* Speed up ECU firmware query
|
||||
* Fix bug where manager would sometimes hang after shutting down the car
|
||||
|
||||
Version 0.7.2 (2020-02-07)
|
||||
========================
|
||||
* ECU firmware version based fingerprinting for Honda & Toyota
|
||||
@@ -658,7 +27,7 @@ Version 0.7 (2019-12-13)
|
||||
* Improve GM longitudinal control: proper computations for 15Hz radar
|
||||
* Move GM port, Toyota with DSU removed, comma pedal in community features; toggle switch required
|
||||
* Remove upload over cellular toggle: only upload qlog and qcamera files if not on wifi
|
||||
* Refactor Panda code towards ISO26262 and SIL2 compliance
|
||||
* Refactor Panda code towards ISO26262 and SIL2 compliancy
|
||||
* Forward stock FCW for Honda Nidec
|
||||
* Volkswagen port now standard: comma Harness intercepts stock camera
|
||||
|
||||
@@ -749,7 +118,7 @@ Version 0.5.13 (2019-05-31)
|
||||
* Reduce CPU utilization by 20% and improve stability
|
||||
* Temporarily remove mapd functionalities to improve stability
|
||||
* Add openpilot record-only mode for unsupported cars
|
||||
* Synchronize controlsd to pandad to reduce latency
|
||||
* Synchronize controlsd to boardd to reduce latency
|
||||
* Remove panda support for Subaru giraffe
|
||||
|
||||
Version 0.5.12 (2019-05-16)
|
||||
@@ -789,7 +158,7 @@ Version 0.5.10 (2019-03-19)
|
||||
* New Driver Monitoring Model
|
||||
* Support QR codes for login using comma connect
|
||||
* Refactor comma pedal FW and use CRC-8 checksum algorithm for safety. Reflashing pedal is required.
|
||||
Please see `#hw-pedal` on [discord](https://discord.comma.ai) for assistance updating comma pedal.
|
||||
Please see `#hw-pedal` on [discord](discord.comma.ai) for assistance updating comma pedal.
|
||||
* Additional speed limit rules for Germany thanks to arne182
|
||||
* Allow negative speed limit offsets
|
||||
|
||||
@@ -1045,96 +414,96 @@ Version 0.3.4 (2017-07-28)
|
||||
|
||||
Version 0.3.3 (2017-06-28)
|
||||
===========================
|
||||
* Improved model trained on more data
|
||||
* Alpha CR-V support thanks to energee and johnnwvs!
|
||||
* Using the opendbc project for DBC files
|
||||
* Minor performance improvements
|
||||
* UI update thanks to pjlao307
|
||||
* Power off button
|
||||
* 6% more torque on the Civic
|
||||
* Improved model trained on more data
|
||||
* Alpha CR-V support thanks to energee and johnnwvs!
|
||||
* Using the opendbc project for DBC files
|
||||
* Minor performance improvements
|
||||
* UI update thanks to pjlao307
|
||||
* Power off button
|
||||
* 6% more torque on the Civic
|
||||
|
||||
Version 0.3.2 (2017-05-22)
|
||||
===========================
|
||||
* Minor stability bugfixes
|
||||
* Added metrics and rear view mirror disable to settings
|
||||
* Update model with more crowdsourced data
|
||||
* Minor stability bugfixes
|
||||
* Added metrics and rear view mirror disable to settings
|
||||
* Update model with more crowdsourced data
|
||||
|
||||
Version 0.3.1 (2017-05-17)
|
||||
===========================
|
||||
* visiond stability bugfix
|
||||
* Add logging for angle and flashing
|
||||
* visiond stability bugfix
|
||||
* Add logging for angle and flashing
|
||||
|
||||
Version 0.3.0 (2017-05-12)
|
||||
===========================
|
||||
* Add CarParams struct to improve the abstraction layer
|
||||
* Refactor visiond IPC to support multiple clients
|
||||
* Add raw GPS and beginning support for navigation
|
||||
* Improve model in visiond using crowdsourced data
|
||||
* Add improved system logging to diagnose instability
|
||||
* Rewrite baseui in React Native
|
||||
* Moved calibration to the cloud
|
||||
* Add CarParams struct to improve the abstraction layer
|
||||
* Refactor visiond IPC to support multiple clients
|
||||
* Add raw GPS and beginning support for navigation
|
||||
* Improve model in visiond using crowdsourced data
|
||||
* Add improved system logging to diagnose instability
|
||||
* Rewrite baseui in React Native
|
||||
* Moved calibration to the cloud
|
||||
|
||||
Version 0.2.9 (2017-03-01)
|
||||
===========================
|
||||
* Retain compatibility with NEOS v1
|
||||
* Retain compatibility with NEOS v1
|
||||
|
||||
Version 0.2.8 (2017-02-27)
|
||||
===========================
|
||||
* Fix bug where frames were being dropped in minute 71
|
||||
* Fix bug where frames were being dropped in minute 71
|
||||
|
||||
Version 0.2.7 (2017-02-08)
|
||||
===========================
|
||||
* Better performance and pictures at night
|
||||
* Fix ptr alignment issue in pandad
|
||||
* Fix brake error light, fix crash if too cold
|
||||
* Better performance and pictures at night
|
||||
* Fix ptr alignment issue in boardd
|
||||
* Fix brake error light, fix crash if too cold
|
||||
|
||||
Version 0.2.6 (2017-01-31)
|
||||
===========================
|
||||
* Fix bug in visiond model execution
|
||||
* Fix bug in visiond model execution
|
||||
|
||||
Version 0.2.5 (2017-01-30)
|
||||
===========================
|
||||
* Fix race condition in manager
|
||||
* Fix race condition in manager
|
||||
|
||||
Version 0.2.4 (2017-01-27)
|
||||
===========================
|
||||
* OnePlus 3T support
|
||||
* Enable installation as NEOS app
|
||||
* Various minor bugfixes
|
||||
* OnePlus 3T support
|
||||
* Enable installation as NEOS app
|
||||
* Various minor bugfixes
|
||||
|
||||
Version 0.2.3 (2017-01-11)
|
||||
===========================
|
||||
* Reduce space usage by 80%
|
||||
* Add better logging
|
||||
* Add Travis CI
|
||||
* Reduce space usage by 80%
|
||||
* Add better logging
|
||||
* Add Travis CI
|
||||
|
||||
Version 0.2.2 (2017-01-10)
|
||||
===========================
|
||||
* Board triggers started signal on CAN messages
|
||||
* Improved autoexposure
|
||||
* Handle out of space, improve upload status
|
||||
* Board triggers started signal on CAN messages
|
||||
* Improved autoexposure
|
||||
* Handle out of space, improve upload status
|
||||
|
||||
Version 0.2.1 (2016-12-14)
|
||||
===========================
|
||||
* Performance improvements, removal of more numpy
|
||||
* Fix pandad process priority
|
||||
* Make counter timer reset on use of steering wheel
|
||||
* Performance improvements, removal of more numpy
|
||||
* Fix boardd process priority
|
||||
* Make counter timer reset on use of steering wheel
|
||||
|
||||
Version 0.2 (2016-12-12)
|
||||
=========================
|
||||
* Car/Radar abstraction layers have shipped, see openpilot/cereal/car.capnp
|
||||
* controlsd has been refactored
|
||||
* Shipped plant model and testing maneuvers
|
||||
* visiond exits more gracefully now
|
||||
* Hardware encoder in visiond should always init
|
||||
* ui now turns off the screen after 30 seconds
|
||||
* Switch to openpilot release branch for future releases
|
||||
* Added preliminary Docker container to run tests on PC
|
||||
* Car/Radar abstraction layers have shipped, see cereal/car.capnp
|
||||
* controlsd has been refactored
|
||||
* Shipped plant model and testing maneuvers
|
||||
* visiond exits more gracefully now
|
||||
* Hardware encoder in visiond should always init
|
||||
* ui now turns off the screen after 30 seconds
|
||||
* Switch to openpilot release branch for future releases
|
||||
* Added preliminary Docker container to run tests on PC
|
||||
|
||||
Version 0.1 (2016-11-29)
|
||||
=========================
|
||||
* Initial release of openpilot
|
||||
* Adaptive cruise control is working
|
||||
* Lane keep assist is working
|
||||
* Support for Acura ILX 2016 with AcuraWatch Plus
|
||||
* Support for Honda Civic 2016 Touring Edition
|
||||
* Initial release of openpilot
|
||||
* Adaptive cruise control is working
|
||||
* Lane keep assist is working
|
||||
* Support for Acura ILX 2016 with AcuraWatch Plus
|
||||
* Support for Honda Civic 2016 Touring Edition
|
||||
|
||||
@@ -0,0 +1,34 @@
|
||||
openpilot Safety
|
||||
======
|
||||
|
||||
openpilot is an Adaptive Cruise Control (ACC) and Automated Lane Centering (ALC) system.
|
||||
Like other ACC and ALC systems, openpilot is a failsafe passive system and it requires the
|
||||
driver to be alert and to pay attention at all times.
|
||||
|
||||
In order to enforce driver alertness, openpilot includes a driver monitoring feature
|
||||
that alerts the driver when distracted.
|
||||
|
||||
However, even with an attentive driver, we must make further efforts for the system to be
|
||||
safe. We repeat, **driver alertness is necessary, but not sufficient, for openpilot to be
|
||||
used safely** and openpilot is provided with no warranty of fitness for any purpose.
|
||||
|
||||
openpilot is developed in good faith to be compliant with FMVSS requirements and to follow
|
||||
industry standards of safety for Level 2 Driver Assistance Systems. In particular, we observe
|
||||
ISO26262 guidelines, including those from [pertinent documents](https://www.nhtsa.gov/sites/nhtsa.dot.gov/files/documents/13498a_812_573_alcsystemreport.pdf)
|
||||
released by NHTSA. In addition, we impose strict coding guidelines (like [MISRA C : 2012](https://www.misra.org.uk/MISRAHome/MISRAC2012/tabid/196/Default.aspx))
|
||||
on parts of openpilot that are safety relevant. We also perform software-in-the-loop,
|
||||
hardware-in-the-loop and in-vehicle tests before each software release.
|
||||
|
||||
Following Hazard and Risk Analysis and FMEA, at a very high level, we have designed openpilot
|
||||
ensuring two main safety requirements.
|
||||
|
||||
1. The driver must always be capable to immediately retake manual control of the vehicle,
|
||||
by stepping on either pedal or by pressing the cancel button.
|
||||
2. The vehicle must not alter its trajectory too quickly for the driver to safely
|
||||
react. This means that while the system is engaged, the actuators are constrained
|
||||
to operate within reasonable limits.
|
||||
|
||||
For vehicle specific implementation of the safety concept, refer to `panda/board/safety/`.
|
||||
|
||||
**Extra note**: comma.ai strongly discourages the use of openpilot forks with safety code either missing or
|
||||
not fully meeting the above requirements.
|
||||
+202
-375
@@ -1,405 +1,232 @@
|
||||
import os
|
||||
import subprocess
|
||||
import sys
|
||||
import sysconfig
|
||||
import platform
|
||||
import shlex
|
||||
import importlib
|
||||
import re
|
||||
import stat
|
||||
import numpy as np
|
||||
|
||||
import SCons.Errors
|
||||
from SCons.Defaults import _stripixes
|
||||
AddOption('--test',
|
||||
action='store_true',
|
||||
help='build test files')
|
||||
|
||||
COMMA_HARDWARE = os.path.isfile('/AGNOS')
|
||||
AddOption('--asan',
|
||||
action='store_true',
|
||||
help='turn on ASAN')
|
||||
|
||||
SCons.Warnings.warningAsException(True)
|
||||
|
||||
Decider('MD5-timestamp')
|
||||
|
||||
SetOption('num_jobs', max(1, int(os.cpu_count()/(1 if "CI" in os.environ else 2))))
|
||||
|
||||
AddOption('--ccflags', action='store', type='string', default='', help='pass arbitrary flags over the command line')
|
||||
AddOption('--verbose', action='store_true', default=False, help='show full build commands')
|
||||
release = os.path.exists(File('#git_src_commit').abspath) # written by release packaging
|
||||
AddOption('--minimal',
|
||||
action='store_false',
|
||||
dest='extras',
|
||||
default=(not COMMA_HARDWARE and not release),
|
||||
help='the minimum build to run openpilot. no tests, tools, etc.')
|
||||
|
||||
dependency_python_paths = [
|
||||
Dir("#").abspath,
|
||||
Dir("#msgq_repo").abspath,
|
||||
Dir("#opendbc_repo").abspath,
|
||||
Dir("#rednose_repo").abspath,
|
||||
Dir("#teleoprtc_repo").abspath,
|
||||
Dir("#tinygrad_repo").abspath,
|
||||
]
|
||||
for p in reversed(dependency_python_paths):
|
||||
if p not in sys.path:
|
||||
sys.path.insert(0, p)
|
||||
|
||||
if external_pythonpath := os.environ.get("PYTHONPATH"):
|
||||
dependency_python_paths += [p for p in external_pythonpath.split(os.pathsep) if p and p not in dependency_python_paths]
|
||||
|
||||
# Detect platform
|
||||
arch = subprocess.check_output(["uname", "-m"], encoding='utf8').rstrip()
|
||||
if platform.system() == "Darwin":
|
||||
arch = "Darwin"
|
||||
elif arch == "aarch64" and COMMA_HARDWARE:
|
||||
arch = "comma_arm64"
|
||||
assert arch in [
|
||||
"comma_arm64", # linux comma hardware (AGNOS) arm64
|
||||
"aarch64", # linux pc arm64
|
||||
"x86_64", # linux pc x64
|
||||
"Darwin", # macOS arm64 (x86 not supported)
|
||||
]
|
||||
|
||||
pkg_names = ['acados', 'capnproto', 'ffmpeg', 'json11', 'ncurses', 'zeromq', 'zstd']
|
||||
if arch != 'Darwin':
|
||||
pkg_names.append('libusb')
|
||||
pkgs = [importlib.import_module(name) for name in pkg_names]
|
||||
acados = pkgs[pkg_names.index('acados')]
|
||||
ffmpeg = pkgs[pkg_names.index('ffmpeg')]
|
||||
from tools.laptop_device_build.runtime_paths import runtime_library_path
|
||||
if arch == "aarch64":
|
||||
lenv = {
|
||||
"LD_LIBRARY_PATH": '/data/data/com.termux/files/usr/lib',
|
||||
"PATH": os.environ['PATH'],
|
||||
"ANDROID_DATA": os.environ['ANDROID_DATA'],
|
||||
"ANDROID_ROOT": os.environ['ANDROID_ROOT'],
|
||||
}
|
||||
|
||||
build_sysroot = os.environ.get("COMMA_BUILD_SYSROOT") if arch == "comma_arm64" else None
|
||||
ffmpeg_runtime_dir = runtime_library_path(ffmpeg.LIB_DIR, sys.prefix, "/usr/local/venv" if build_sysroot else None)
|
||||
# Shared package ships .so/.dylib; older device venvs still have static .a only.
|
||||
# Keep static link deps (x264/z/va/drm) when the installed package is static so
|
||||
# COMMA_HARDWARE CI works without upgrading the device venv yet.
|
||||
# TODO: drop the static fallback once device venvs have comma-deps-ffmpeg>=7.1.0.post94
|
||||
_ffmpeg_lib_names = os.listdir(ffmpeg.LIB_DIR) if os.path.isdir(ffmpeg.LIB_DIR) else []
|
||||
ffmpeg_shared = any(
|
||||
n.startswith('libavcodec.so') or (n.startswith('libavcodec') and n.endswith('.dylib'))
|
||||
for n in _ffmpeg_lib_names
|
||||
)
|
||||
ffmpeg_libs = ['avformat', 'avcodec', 'swresample', 'avutil']
|
||||
if not ffmpeg_shared:
|
||||
ffmpeg_libs += ['x264', 'z']
|
||||
if arch != "Darwin":
|
||||
ffmpeg_libs += ['va', 'va-drm', 'drm']
|
||||
acados_include_dirs = [
|
||||
acados.INCLUDE_DIR,
|
||||
os.path.join(acados.INCLUDE_DIR, "blasfeo", "include"),
|
||||
os.path.join(acados.INCLUDE_DIR, "hpipm", "include"),
|
||||
]
|
||||
cpppath = [
|
||||
"#phonelibs/opencl/include",
|
||||
]
|
||||
libpath = [
|
||||
"#phonelibs/snpe/aarch64-android-clang3.8",
|
||||
"/usr/lib",
|
||||
"/data/data/com.termux/files/usr/lib",
|
||||
"/system/vendor/lib64",
|
||||
"/system/comma/usr/lib",
|
||||
"#phonelibs/nanovg",
|
||||
"#phonelibs/libyuv/lib",
|
||||
]
|
||||
|
||||
cflags = ["-DQCOM", "-mcpu=cortex-a57"]
|
||||
cxxflags = ["-DQCOM", "-mcpu=cortex-a57"]
|
||||
|
||||
# ***** enforce a whitelist of system libraries *****
|
||||
# this prevents silently relying on a 3rd party package,
|
||||
# e.g. apt-installed libusb. all libraries should either
|
||||
# be distributed with all Linux distros and macOS, or
|
||||
# vendored in commaai/dependencies.
|
||||
allowed_system_libs = {
|
||||
"EGL", "GLESv2", "GL",
|
||||
"dl", "drm", "gbm", "m", "pthread",
|
||||
}
|
||||
rpath = ["/system/vendor/lib64"]
|
||||
else:
|
||||
lenv = {
|
||||
"PATH": "#external/bin:" + os.environ['PATH'],
|
||||
}
|
||||
cpppath = [
|
||||
"#phonelibs/capnp-cpp/include",
|
||||
"#phonelibs/capnp-c/include",
|
||||
"#phonelibs/zmq/x64/include",
|
||||
"#external/tensorflow/include",
|
||||
]
|
||||
|
||||
def _resolve_lib(env, name):
|
||||
for d in env.Flatten(env.get('LIBPATH', [])):
|
||||
p = Dir(str(d)).abspath
|
||||
for ext in ('.a', '.so', '.dylib'):
|
||||
f = File(os.path.join(p, f'lib{name}{ext}'))
|
||||
if f.exists() or f.has_builder():
|
||||
return name
|
||||
if name in allowed_system_libs:
|
||||
return name
|
||||
raise SCons.Errors.UserError(f"Unexpected non-vendored library '{name}'")
|
||||
if arch == "Darwin":
|
||||
libpath = [
|
||||
"#phonelibs/capnp-cpp/mac/lib",
|
||||
"#phonelibs/capnp-c/mac/lib",
|
||||
"#phonelibs/libyuv/mac/lib",
|
||||
"#cereal",
|
||||
"#selfdrive/common",
|
||||
"/usr/local/lib",
|
||||
"/System/Library/Frameworks/OpenGL.framework/Libraries",
|
||||
]
|
||||
else:
|
||||
libpath = [
|
||||
"#phonelibs/capnp-cpp/x64/lib",
|
||||
"#phonelibs/capnp-c/x64/lib",
|
||||
"#phonelibs/snpe/x86_64-linux-clang",
|
||||
"#phonelibs/zmq/x64/lib",
|
||||
"#phonelibs/libyuv/x64/lib",
|
||||
"#external/zmq/lib",
|
||||
"#external/tensorflow/lib",
|
||||
"#cereal",
|
||||
"#selfdrive/common",
|
||||
"/usr/lib",
|
||||
"/usr/local/lib",
|
||||
]
|
||||
|
||||
def _libflags(target, source, env, for_signature):
|
||||
libs = []
|
||||
lp = env.subst('$LIBLITERALPREFIX')
|
||||
for lib in env.Flatten(env.get('LIBS', [])):
|
||||
if isinstance(lib, str):
|
||||
if os.sep in lib or lib.startswith('#'):
|
||||
libs.append(File(lib))
|
||||
elif lib.startswith('-') or (lp and lib.startswith(lp)):
|
||||
libs.append(lib)
|
||||
else:
|
||||
libs.append(_resolve_lib(env, lib))
|
||||
else:
|
||||
libs.append(lib)
|
||||
return _stripixes(env['LIBLINKPREFIX'], libs, env['LIBLINKSUFFIX'],
|
||||
env['LIBPREFIXES'], env['LIBSUFFIXES'], env, env['LIBLITERALPREFIX'])
|
||||
rpath = ["phonelibs/capnp-cpp/x64/lib",
|
||||
"phonelibs/zmq/x64/lib",
|
||||
"external/tensorflow/lib",
|
||||
"cereal",
|
||||
"selfdrive/common"]
|
||||
|
||||
# allows shared libraries to work globally
|
||||
rpath = [os.path.join(os.getcwd(), x) for x in rpath]
|
||||
|
||||
cflags = []
|
||||
cxxflags = []
|
||||
|
||||
ccflags_asan = ["-fsanitize=address", "-fno-omit-frame-pointer"] if GetOption('asan') else []
|
||||
ldflags_asan = ["-fsanitize=address"] if GetOption('asan') else []
|
||||
|
||||
# change pythonpath to this
|
||||
lenv["PYTHONPATH"] = Dir("#").path
|
||||
|
||||
env = Environment(
|
||||
ENV={
|
||||
"PATH": os.environ['PATH'],
|
||||
"PYTHONPATH": os.pathsep.join(dependency_python_paths),
|
||||
"ACADOS_SOURCE_DIR": acados.DIR,
|
||||
"ACADOS_PYTHON_INTERFACE_PATH": acados.TEMPLATE_DIR,
|
||||
"TERA_PATH": acados.TERA_PATH
|
||||
},
|
||||
ENV=lenv,
|
||||
CCFLAGS=[
|
||||
"-g",
|
||||
"-fPIC",
|
||||
"-pipe",
|
||||
"-O2",
|
||||
"-Wunused",
|
||||
"-Werror",
|
||||
"-Wshadow" if arch in ("Darwin", "comma_arm64") else "-Wshadow=local",
|
||||
"-Wno-unknown-warning-option",
|
||||
"-Wno-inconsistent-missing-override",
|
||||
"-Wno-c99-designator",
|
||||
"-Wno-reorder-init-list",
|
||||
"-Wno-vla-cxx-extension",
|
||||
],
|
||||
CFLAGS=["-std=gnu11"],
|
||||
CXXFLAGS=["-std=c++1z"],
|
||||
CPPPATH=[
|
||||
"#openpilot",
|
||||
"#msgq_repo", # #include "msgq/..."
|
||||
"#opendbc_repo", # #include "opendbc/..."
|
||||
"#rednose_repo", # #include "rednose/..."
|
||||
"#rednose_repo/rednose", # #include "logger/..." (rednose package root)
|
||||
"#openpilot/cereal/gen/cpp",
|
||||
acados_include_dirs,
|
||||
[x.INCLUDE_DIR for x in pkgs],
|
||||
"-Werror=implicit-function-declaration",
|
||||
"-Werror=incompatible-pointer-types",
|
||||
"-Werror=int-conversion",
|
||||
"-Werror=return-type",
|
||||
"-Werror=format-extra-args",
|
||||
] + cflags + ccflags_asan,
|
||||
|
||||
CPPPATH=cpppath + [
|
||||
"#",
|
||||
"#selfdrive",
|
||||
"#phonelibs/bzip2",
|
||||
"#phonelibs/libyuv/include",
|
||||
"#phonelibs/openmax/include",
|
||||
"#phonelibs/json/src",
|
||||
"#phonelibs/json11",
|
||||
"#phonelibs/eigen",
|
||||
"#phonelibs/curl/include",
|
||||
"#phonelibs/opencv/include",
|
||||
"#phonelibs/libgralloc/include",
|
||||
"#phonelibs/android_frameworks_native/include",
|
||||
"#phonelibs/android_hardware_libhardware/include",
|
||||
"#phonelibs/android_system_core/include",
|
||||
"#phonelibs/linux/include",
|
||||
"#phonelibs/snpe/include",
|
||||
"#phonelibs/nanovg",
|
||||
"#selfdrive/common",
|
||||
"#selfdrive/camerad",
|
||||
"#selfdrive/camerad/include",
|
||||
"#selfdrive/loggerd/include",
|
||||
"#selfdrive/modeld",
|
||||
"#cereal/messaging",
|
||||
"#cereal",
|
||||
"#opendbc/can",
|
||||
],
|
||||
LIBPATH=[
|
||||
"#openpilot/common",
|
||||
"#msgq_repo",
|
||||
"#openpilot/selfdrive/pandad",
|
||||
"#rednose_repo/rednose/helpers",
|
||||
[x.LIB_DIR for x in pkgs],
|
||||
],
|
||||
RPATH=[ffmpeg_runtime_dir] if ffmpeg_shared else [],
|
||||
CYTHONCFILESUFFIX=".cpp",
|
||||
COMPILATIONDB_USE_ABSPATH=True,
|
||||
REDNOSE_ROOT="#rednose_repo",
|
||||
tools=["default", "cython", "compilation_db", "rednose_filter"],
|
||||
toolpath=["#msgq_repo/site_scons/site_tools", "#rednose_repo/site_scons/site_tools"],
|
||||
|
||||
CC='clang',
|
||||
CXX='clang++',
|
||||
LINKFLAGS=ldflags_asan,
|
||||
|
||||
RPATH=rpath,
|
||||
|
||||
CFLAGS=["-std=gnu11"] + cflags,
|
||||
CXXFLAGS=["-std=c++14"] + cxxflags,
|
||||
LIBPATH=libpath +
|
||||
[
|
||||
"#cereal",
|
||||
"#selfdrive/common",
|
||||
"#phonelibs",
|
||||
]
|
||||
)
|
||||
# SCons' Darwin linker tool doesn't define the variables used to expand RPATH.
|
||||
if arch == "Darwin":
|
||||
env["RPATHPREFIX"] = "-Wl,-rpath,"
|
||||
env["RPATHSUFFIX"] = ""
|
||||
env["_RPATH"] = "${_concat(RPATHPREFIX, RPATH, RPATHSUFFIX, __env__)}"
|
||||
if arch != "comma_arm64":
|
||||
env['_LIBFLAGS'] = _libflags
|
||||
|
||||
# Arch-specific flags and paths
|
||||
if arch == "comma_arm64":
|
||||
env["CC"] = "clang"
|
||||
env["CXX"] = "clang++"
|
||||
env.Append(LIBPATH=[
|
||||
"/usr/lib/aarch64-linux-gnu",
|
||||
])
|
||||
arch_flags = ["-D__COMMA_HARDWARE__", "-mcpu=cortex-a57"]
|
||||
env.Append(CCFLAGS=arch_flags)
|
||||
env.Append(CXXFLAGS=arch_flags)
|
||||
if build_sysroot:
|
||||
if not all(os.path.isdir(os.path.join(build_sysroot, part)) for part in ("usr/include", "usr/lib/aarch64-linux-gnu", "lib/aarch64-linux-gnu")):
|
||||
raise SCons.Errors.UserError(f"Incomplete COMMA_BUILD_SYSROOT: {build_sysroot}")
|
||||
# Clang's --sysroot controls the standard headers and linker startup/libs;
|
||||
# explicit SCons paths make device libraries win over container libraries.
|
||||
env.Prepend(CPPPATH=[os.path.join(build_sysroot, part) for part in ("usr/local/include", "usr/include")])
|
||||
env.Prepend(LIBPATH=[os.path.join(build_sysroot, part) for part in ("usr/local/lib", "usr/lib/aarch64-linux-gnu", "lib/aarch64-linux-gnu")])
|
||||
env.Append(CCFLAGS=[f"--sysroot={build_sysroot}"])
|
||||
env.Append(LINKFLAGS=[f"--sysroot={build_sysroot}"])
|
||||
elif arch == "Darwin":
|
||||
env.Append(LIBPATH=[
|
||||
"/System/Library/Frameworks/OpenGL.framework/Libraries",
|
||||
])
|
||||
env.Append(CCFLAGS=["-DGL_SILENCE_DEPRECATION"])
|
||||
env.Append(CXXFLAGS=["-DGL_SILENCE_DEPRECATION"])
|
||||
|
||||
_extra_cc = shlex.split(GetOption('ccflags') or '')
|
||||
if _extra_cc:
|
||||
env.Append(CCFLAGS=_extra_cc)
|
||||
|
||||
# no --as-needed on mac linker
|
||||
if arch != "Darwin":
|
||||
env.Append(LINKFLAGS=["-Wl,--as-needed", "-Wl,--no-undefined"])
|
||||
|
||||
# Shorter build output: show brief descriptions instead of full commands.
|
||||
# Full command lines are still printed on failure by scons.
|
||||
if not GetOption('verbose'):
|
||||
for action, short in (
|
||||
("CC", "CC"),
|
||||
("CXX", "CXX"),
|
||||
("LINK", "LINK"),
|
||||
("SHCC", "CC"),
|
||||
("SHCXX", "CXX"),
|
||||
("SHLINK", "LINK"),
|
||||
("AR", "AR"),
|
||||
("RANLIB", "RANLIB"),
|
||||
("AS", "AS"),
|
||||
):
|
||||
env[f"{action}COMSTR"] = f" [{short}] $TARGET"
|
||||
|
||||
# ********** Cython build environment **********
|
||||
envCython = env.Clone()
|
||||
envCython["CPPPATH"] += [sysconfig.get_paths()['include'], np.get_include()]
|
||||
envCython["CCFLAGS"] += ["-Wno-#warnings", "-Wno-cpp", "-Wno-shadow", "-Wno-deprecated-declarations"]
|
||||
envCython["CCFLAGS"].remove("-Werror")
|
||||
|
||||
envCython["LIBS"] = []
|
||||
if arch == "Darwin":
|
||||
envCython["LINKFLAGS"] = env["LINKFLAGS"] + ["-bundle", "-undefined", "dynamic_lookup"]
|
||||
else:
|
||||
envCython["LINKFLAGS"] = ["-pthread", "-shared"]
|
||||
if build_sysroot:
|
||||
envCython.Append(LINKFLAGS=[f"--sysroot={build_sysroot}"])
|
||||
|
||||
np_version = SCons.Script.Value(np.__version__)
|
||||
Export('envCython', 'np_version')
|
||||
|
||||
Export('env', 'arch', 'acados', 'ffmpeg_libs')
|
||||
|
||||
# Setup cache dir
|
||||
cache_dir = os.environ.get('SCONS_CACHE', '/data/scons_cache' if arch == "comma_arm64" else '/tmp/scons_cache')
|
||||
cache_size_limit = 4e9 if "CI" in os.environ else 2e9
|
||||
CacheDir(cache_dir)
|
||||
Clean(["."], cache_dir)
|
||||
|
||||
def prune_cache_dir(target=None, source=None, env=None):
|
||||
cache_files = []
|
||||
cache_root = os.path.normpath(cache_dir)
|
||||
for root, _, files in os.walk(cache_root):
|
||||
shard = os.path.basename(root)
|
||||
if os.path.dirname(root) != cache_root or re.fullmatch(r'[0-9A-Fa-f]{2}', shard) is None:
|
||||
continue
|
||||
for name in files:
|
||||
if re.fullmatch(r'(?:[0-9a-f]{32}|[0-9a-f]{64})', name) is None or name[:2].lower() != shard.lower():
|
||||
continue
|
||||
path = os.path.join(root, name)
|
||||
try:
|
||||
info = os.stat(path, follow_symlinks=False)
|
||||
except FileNotFoundError:
|
||||
continue
|
||||
if stat.S_ISREG(info.st_mode):
|
||||
cache_files.append((info.st_mtime, info.st_size, path))
|
||||
cache_files.sort()
|
||||
cache_size = sum(size for _, size, _ in cache_files)
|
||||
for _, size, path in cache_files:
|
||||
if cache_size < cache_size_limit:
|
||||
break
|
||||
try:
|
||||
os.unlink(path)
|
||||
except FileNotFoundError:
|
||||
pass
|
||||
cache_size -= size
|
||||
|
||||
# ********** start building stuff **********
|
||||
|
||||
# Build common module
|
||||
SConscript(['openpilot/common/SConscript'])
|
||||
Import('_common')
|
||||
common = [_common, 'json11', 'zmq']
|
||||
Export('common')
|
||||
|
||||
# Build messaging (cereal + msgq + socketmaster + their dependencies)
|
||||
# Enable swaglog include in dependency sources
|
||||
env_swaglog = env.Clone()
|
||||
env_swaglog['CXXFLAGS'].append('-DSWAGLOG="\\"common/swaglog.h\\""')
|
||||
SConscript(['msgq_repo/SConscript'], exports={'env': env_swaglog})
|
||||
|
||||
SConscript(['openpilot/cereal/SConscript'])
|
||||
|
||||
Import('socketmaster', 'msgq')
|
||||
messaging = [socketmaster, msgq, 'capnp', 'kj',]
|
||||
Export('messaging')
|
||||
|
||||
|
||||
# Build dependency sources
|
||||
SConscript(['panda/SConscript'])
|
||||
|
||||
# Build rednose library
|
||||
SConscript(['rednose_repo/rednose/SConscript'])
|
||||
|
||||
# Build system services
|
||||
SConscript([
|
||||
'openpilot/system/loggerd/SConscript',
|
||||
])
|
||||
|
||||
if arch == "comma_arm64":
|
||||
SConscript(['openpilot/system/camerad/SConscript'])
|
||||
SConscript(['openpilot/starpilot/system/android_auto/SConscript'])
|
||||
|
||||
# Build selfdrive
|
||||
SConscript([
|
||||
'openpilot/selfdrive/pandad/SConscript',
|
||||
'openpilot/selfdrive/controls/lib/longitudinal_mpc_lib/SConscript',
|
||||
'openpilot/selfdrive/locationd/SConscript',
|
||||
'openpilot/selfdrive/modeld/SConscript',
|
||||
'openpilot/selfdrive/ui/SConscript',
|
||||
'openpilot/starpilot/audio/native/SConscript',
|
||||
])
|
||||
|
||||
# Replay is also the isolated on-device viewer engine.
|
||||
if GetOption('extras') or arch == "comma_arm64":
|
||||
SConscript(['openpilot/tools/replay/SConscript'])
|
||||
|
||||
# Build desktop-only tools
|
||||
if GetOption('extras') and arch != "comma_arm64":
|
||||
SConscript([
|
||||
'openpilot/tools/cabana/SConscript',
|
||||
'openpilot/tools/jotpluggler/SConscript',
|
||||
])
|
||||
|
||||
|
||||
env.CompilationDatabase('compile_commands.json')
|
||||
|
||||
# progress output
|
||||
def count_scons_nodes(nodes):
|
||||
seen = set()
|
||||
stack = list(nodes)
|
||||
|
||||
while stack:
|
||||
node = stack.pop().disambiguate()
|
||||
if node in seen:
|
||||
continue
|
||||
seen.add(node)
|
||||
executor = node.get_executor()
|
||||
if executor is not None:
|
||||
stack += executor.get_all_prerequisites() + executor.get_all_children()
|
||||
|
||||
return len(seen)
|
||||
|
||||
progress_interval = 5
|
||||
progress_count = 0
|
||||
progress_total = max(1, count_scons_nodes(env.arg2nodes(BUILD_TARGETS or [Dir('.')], env.fs.Entry)))
|
||||
if os.environ.get('SCONS_CACHE'):
|
||||
CacheDir('/tmp/scons_cache')
|
||||
|
||||
node_interval = 5
|
||||
node_count = 0
|
||||
def progress_function(node):
|
||||
global progress_count
|
||||
if progress_count >= progress_total:
|
||||
return
|
||||
progress_count = min(progress_count + progress_interval, progress_total)
|
||||
progress = round(100. * progress_count / progress_total, 1)
|
||||
sys.stderr.write("\rBuilding: %5.1f%%" % progress if sys.stderr.isatty() else "progress: %.1f\n" % progress)
|
||||
if progress == 100. and sys.stderr.isatty():
|
||||
sys.stderr.write("\n")
|
||||
sys.stderr.flush()
|
||||
global node_count
|
||||
node_count += node_interval
|
||||
sys.stderr.write("progress: %d\n" % node_count)
|
||||
|
||||
Progress(progress_function, interval=progress_interval)
|
||||
AddPostAction(BUILD_TARGETS or [Dir('.')], prune_cache_dir)
|
||||
if os.environ.get('SCONS_PROGRESS'):
|
||||
Progress(progress_function, interval=node_interval)
|
||||
|
||||
# Release CI rebuilds tracked device outputs for the host architecture.
|
||||
if manifest_path := os.environ.get("STARPILOT_CI_BUILD_MANIFEST"):
|
||||
from tools.release.build_manifest import capture
|
||||
manifest_nodes = env.arg2nodes(BUILD_TARGETS or [Dir('.')], env.fs.Entry)
|
||||
manifest_seen = set()
|
||||
manifest_outputs = set()
|
||||
while manifest_nodes:
|
||||
manifest_node = manifest_nodes.pop().disambiguate()
|
||||
if manifest_node in manifest_seen:
|
||||
continue
|
||||
manifest_seen.add(manifest_node)
|
||||
manifest_executor = manifest_node.get_executor()
|
||||
if manifest_executor is not None:
|
||||
manifest_nodes += manifest_executor.get_all_prerequisites() + manifest_executor.get_all_children()
|
||||
for target in manifest_executor.get_all_targets():
|
||||
if target.is_derived() and hasattr(target, 'abspath'):
|
||||
relative = os.path.relpath(target.abspath, Dir('#').abspath)
|
||||
if not relative.startswith('../'):
|
||||
manifest_outputs.add(relative)
|
||||
capture(Dir('#').abspath, manifest_path, manifest_outputs,
|
||||
{'arch': arch, 'targets': list(BUILD_TARGETS), 'extras': GetOption('extras'),
|
||||
'ccflags': GetOption('ccflags'), 'release': release, 'arguments': dict(ARGUMENTS),
|
||||
'toolchain': {key: str(env.get(key, '')) for key in
|
||||
('CC', 'CXX', 'CCFLAGS', 'CFLAGS', 'CXXFLAGS', 'LINKFLAGS')}})
|
||||
SHARED = False
|
||||
|
||||
def abspath(x):
|
||||
if arch == 'aarch64':
|
||||
pth = os.path.join("/data/pythonpath", x[0].path)
|
||||
env.Depends(pth, x)
|
||||
return File(pth)
|
||||
else:
|
||||
# rpath works elsewhere
|
||||
return x[0].path.rsplit("/", 1)[1][:-3]
|
||||
|
||||
#zmq = 'zmq'
|
||||
# still needed for apks
|
||||
zmq = FindFile("libzmq.a", libpath)
|
||||
Export('env', 'arch', 'zmq', 'SHARED')
|
||||
|
||||
# cereal and messaging are shared with the system
|
||||
SConscript(['cereal/SConscript'])
|
||||
if SHARED:
|
||||
cereal = abspath([File('cereal/libcereal_shared.so')])
|
||||
messaging = abspath([File('cereal/libmessaging_shared.so')])
|
||||
else:
|
||||
cereal = [File('#cereal/libcereal.a')]
|
||||
messaging = [File('#cereal/libmessaging.a')]
|
||||
Export('cereal', 'messaging')
|
||||
|
||||
SConscript(['selfdrive/common/SConscript'])
|
||||
Import('_common', '_visionipc', '_gpucommon', '_gpu_libs')
|
||||
|
||||
if SHARED:
|
||||
common, visionipc, gpucommon = abspath(common), abspath(visionipc), abspath(gpucommon)
|
||||
else:
|
||||
common = [_common, 'json']
|
||||
visionipc = _visionipc
|
||||
gpucommon = [_gpucommon] + _gpu_libs
|
||||
|
||||
Export('common', 'visionipc', 'gpucommon')
|
||||
|
||||
SConscript(['opendbc/can/SConscript'])
|
||||
|
||||
SConscript(['common/SConscript'])
|
||||
SConscript(['common/kalman/SConscript'])
|
||||
SConscript(['phonelibs/SConscript'])
|
||||
|
||||
if arch != "Darwin":
|
||||
SConscript(['selfdrive/camerad/SConscript'])
|
||||
SConscript(['selfdrive/modeld/SConscript'])
|
||||
|
||||
SConscript(['selfdrive/controls/lib/cluster/SConscript'])
|
||||
SConscript(['selfdrive/controls/lib/lateral_mpc/SConscript'])
|
||||
SConscript(['selfdrive/controls/lib/longitudinal_mpc/SConscript'])
|
||||
|
||||
SConscript(['selfdrive/boardd/SConscript'])
|
||||
SConscript(['selfdrive/proclogd/SConscript'])
|
||||
|
||||
SConscript(['selfdrive/ui/SConscript'])
|
||||
SConscript(['selfdrive/loggerd/SConscript'])
|
||||
|
||||
if arch == "aarch64":
|
||||
SConscript(['selfdrive/logcatd/SConscript'])
|
||||
SConscript(['selfdrive/sensord/SConscript'])
|
||||
SConscript(['selfdrive/clocksd/SConscript'])
|
||||
|
||||
SConscript(['selfdrive/locationd/SConscript'])
|
||||
|
||||
# TODO: finish cereal, dbcbuilder, MPC
|
||||
|
||||
@@ -1,5 +0,0 @@
|
||||
# Security Policy
|
||||
|
||||
## Reporting a Vulnerability
|
||||
|
||||
Suspected vulnerabilities can be reported to both `adeeb@comma.ai` and `security@comma.ai`.
|
||||
@@ -1,114 +0,0 @@
|
||||
# Third-party notices
|
||||
|
||||
## Jetlink
|
||||
|
||||
Jetlink's comma client is copyright (c) 2026 Zeph Leggett and distributed under the MIT License. Its complete license and permission notice are retained in [jetlink_repo/LICENSE](jetlink_repo/LICENSE); source and revision are recorded in [CREDITS.md](CREDITS.md#jetlink-external-inference) and `upstream-sync.json`.
|
||||
|
||||
## MRR35 Hyundai angle and radar
|
||||
|
||||
The MRR35 radar generator and related Hyundai angle integration derive from the frozen StarPilot snapshot `678af783`, with relevant sunnypilot/opendbc angle-branch ancestry at `cc4b08625a98e94b318cab15e45e05dad58042bd`. Both upstream `LICENSE` and `LICENSE.md` were published for that source. Their scope is not unambiguous, so both applicable notices and the extension-file attribution are retained here without choosing between them. See [CREDITS.md](CREDITS.md) for the narrow source map.
|
||||
|
||||
### Upstream `opendbc` `LICENSE` notice (MIT)
|
||||
|
||||
Copyright (c) 2020, Comma.ai, Inc.
|
||||
|
||||
Permission is hereby granted, free of charge, to any person obtaining a copy of this software and
|
||||
associated documentation files (the "Software"), to deal in the Software without restriction,
|
||||
including without limitation the rights to use, copy, modify, merge, publish, distribute,
|
||||
sublicense, and/or sell copies of the Software, and to permit persons to whom the Software is
|
||||
furnished to do so, subject to the following conditions:
|
||||
|
||||
The above copyright notice and this permission notice shall be included in all copies or
|
||||
substantial portions of the Software.
|
||||
|
||||
THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR IMPLIED, INCLUDING BUT
|
||||
NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY, FITNESS FOR A PARTICULAR PURPOSE AND
|
||||
NONINFRINGEMENT. IN NO EVENT SHALL THE AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM,
|
||||
DAMAGES OR OTHER LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM, OUT
|
||||
OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE SOFTWARE.
|
||||
|
||||
### Upstream extension file notice
|
||||
|
||||
> Copyright (c) 2021-, Haibin Wen, sunnypilot, and a number of other contributors.
|
||||
>
|
||||
> This file is part of sunnypilot and is licensed under the MIT License.
|
||||
> See the LICENSE.md file in the root directory for more details.
|
||||
|
||||
### Upstream `LICENSE.md` notice (published as “Custom MIT License”)
|
||||
|
||||
The following notice is reproduced verbatim from the reference branch:
|
||||
|
||||
> # Custom MIT License
|
||||
>
|
||||
> Copyright (c) 2024, Haibin Wen, SUNNYPILOT LLC
|
||||
>
|
||||
> Permission is hereby granted, free of charge, to any person obtaining a copy of this software and associated documentation files (the "Software"), to view and modify the Software, subject to the following conditions:
|
||||
>
|
||||
> 1. **Permission Required**: Permission Required for Commercial, For-Profit, or Closed Source Use: Use of the Software, in whole or in part, for any commercial purposes, for-profit projects, or in closed source projects requires explicit written permission from the original author(s).
|
||||
>
|
||||
> 2. **Redistribution**: Any redistribution of the Software, modified or unmodified, must retain this license notice and the following acknowledgment:
|
||||
> "This software is licensed under a custom license requiring permission for use."
|
||||
>
|
||||
> 3. **Visibility**: Any project that uses the Software must visibly mention the following acknowledgment:
|
||||
> "This project uses software from Haibin Wen and SUNNYPILOT LLC and is licensed under a custom license requiring permission for use."
|
||||
>
|
||||
> 4. **No Warranty**: THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY, FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM, OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE SOFTWARE.
|
||||
>
|
||||
> Contact sunnypilot Support <support@sunnypilot.ai> for permission requests.
|
||||
>
|
||||
> ---
|
||||
>
|
||||
> Haibin Wen, SUNNYPILOT LLC
|
||||
|
||||
Required upstream acknowledgments:
|
||||
|
||||
> This software is licensed under a custom license requiring permission for use.
|
||||
>
|
||||
> This project uses software from Haibin Wen and SUNNYPILOT LLC and is licensed under a custom license requiring permission for use.
|
||||
|
||||
For commercial, for-profit, or closed-source use, consult the upstream notice and obtain any
|
||||
permission it requires. The upstream repository's simultaneous publication of two differently
|
||||
scoped notices should be clarified with the relevant copyright holders before relying on one to
|
||||
the exclusion of the other.
|
||||
|
||||
## BluePilot Ford support
|
||||
|
||||
The Ford lateral strategies, CAN constructors, camera-radar filtering and native checks include work adapted from BluePilot's `bp-7.0` source, through StarPilot `2efe6017bfe14cee4807833e05f9a7f6ba255cdb`. See [CREDITS.md](CREDITS.md#ford-support-adapted-from-bluepilot) for contributors and source revisions. The upstream extension-file and `LICENSE.md` notices reproduced above also apply to the Ford extension sources; they are retained without resolving the difference between their published license descriptions.
|
||||
|
||||
## Optional BluePilot angle library adapter
|
||||
|
||||
The angle-only adapter in `opendbc_repo/opendbc/bluepilot_lateral` is sourced directly from BluePilot bp-7.0 commit e1d051d7ba270261b4455068bd68f1a58db15a4a. The complete upstream MIT notice is retained in that folder's `LICENSE`, and the simultaneously published Custom MIT notice is retained verbatim in `LICENSE.md`. The applicable SUNNYPILOT acknowledgments reproduced above are also retained in its `CREDITS.md`. This preserves the published terms without resolving their scope or representing the adapted extension as unambiguously plain MIT.
|
||||
|
||||
The optional, default-disabled angle lane-centering trim additionally derives from
|
||||
BluePilot bp-dev e22afa6be9b881fa784c92ebb316db47728a3d81. Its exact source and
|
||||
contributors are recorded in the library CREDITS.md; the same root/opendbc MIT
|
||||
and Custom MIT notices coexist unchanged at that revision. This adds attribution,
|
||||
not a license-scope decision or permission grant.
|
||||
|
||||
## Continental ARS510 radar
|
||||
|
||||
The optional RAV4 radar decoders and `toyota_tss2_ars510.dbc` are adapted from
|
||||
<https://github.com/ds-sebastian/ars510-radar> at
|
||||
`fb5b29c2b5999f34afeb6f7ac494a73949d66c67`.
|
||||
|
||||
MIT License
|
||||
|
||||
Copyright (c) 2026 ARS510 radar contributors
|
||||
|
||||
Permission is hereby granted, free of charge, to any person obtaining a copy
|
||||
of this software and associated documentation files (the "Software"), to deal
|
||||
in the Software without restriction, including without limitation the rights
|
||||
to use, copy, modify, merge, publish, distribute, sublicense, and/or sell
|
||||
copies of the Software, and to permit persons to whom the Software is
|
||||
furnished to do so, subject to the following conditions:
|
||||
|
||||
The above copyright notice and this permission notice shall be included in all
|
||||
copies or substantial portions of the Software.
|
||||
|
||||
THE SOFTWARE IS PROVIDED "AS IS", WITHOUT WARRANTY OF ANY KIND, EXPRESS OR
|
||||
IMPLIED, INCLUDING BUT NOT LIMITED TO THE WARRANTIES OF MERCHANTABILITY,
|
||||
FITNESS FOR A PARTICULAR PURPOSE AND NONINFRINGEMENT. IN NO EVENT SHALL THE
|
||||
AUTHORS OR COPYRIGHT HOLDERS BE LIABLE FOR ANY CLAIM, DAMAGES OR OTHER
|
||||
LIABILITY, WHETHER IN AN ACTION OF CONTRACT, TORT OR OTHERWISE, ARISING FROM,
|
||||
OUT OF OR IN CONNECTION WITH THE SOFTWARE OR THE USE OR OTHER DEALINGS IN THE
|
||||
SOFTWARE.
|
||||
@@ -0,0 +1,3 @@
|
||||
Place apks here that you want to be installed with the name <app>.apk
|
||||
|
||||
These won't be committed into one, but for now baseui will ship with openpilot.
|
||||
@@ -0,0 +1,3 @@
|
||||
version https://git-lfs.github.com/spec/v1
|
||||
oid sha256:309b46b7c38f10da52b18b0340eb3c57b633558a9a27c3ca4116474969ebb456
|
||||
size 84675
|
||||
@@ -0,0 +1,3 @@
|
||||
version https://git-lfs.github.com/spec/v1
|
||||
oid sha256:d563bc9d43408f78d859538b50999cd7703487bdbe1fba1b11a3810205cd26c4
|
||||
size 2856327
|
||||
@@ -0,0 +1,3 @@
|
||||
version https://git-lfs.github.com/spec/v1
|
||||
oid sha256:7513530cf08df553395f3fbe9066c42993a34e445924f0aa3e3182c68dce25a3
|
||||
size 13642104
|
||||
Submodule
+1
Submodule apks added at d4f4f07a15
@@ -1,156 +0,0 @@
|
||||
#!/usr/bin/env bash
|
||||
# Project build shortcuts. AGNOS builds natively; laptops use the ARM64 container.
|
||||
set -euo pipefail
|
||||
|
||||
ROOT_DIR="$(cd "$(dirname "${BASH_SOURCE[0]}")" && pwd)"
|
||||
if [[ "${1:-}" == -h || "${1:-}" == --help ]]; then
|
||||
cat <<'EOF'
|
||||
Usage: ./build [jobs] [scons options]
|
||||
./build [--params] [--cereal] [--panda] [jobs] [scons options]
|
||||
./build --mapd
|
||||
./build --check-startup <Params root or namespace> <recovery storage>
|
||||
|
||||
On AGNOS/aarch64, builds run natively. On laptops, builds use a Linux/ARM64 container.
|
||||
--params builds libparams_c.so; --cereal builds cereal outputs; --panda
|
||||
builds signed panda (C3), panda_h7 and body_h7 firmware only. Numeric jobs become -jN.
|
||||
RELEASE and CERT are environment variables, not trailing SCons arguments:
|
||||
RELEASE=1 CERT=/path/to/certificate ./build --panda 4
|
||||
CERT must name a readable certificate file. Omit RELEASE for DEBUG firmware.
|
||||
--mapd explicitly packages the pinned offline Linux/ARM64 Go provider; it
|
||||
does not fetch map regions or participate in the default build.
|
||||
Run scripts/laptop_device_build.sh doctor to check local prerequisites.
|
||||
Full laptop builds require a source-matched QCOM artifact package in
|
||||
.cache/qcom-artifact-package; device builds still compile models natively.
|
||||
--check-startup checks retained settings admission read-only using the local
|
||||
native developer runtime. Supply a matching Params namespace and recovery
|
||||
storage. A relocated copy can fail its path-bound profile marker.
|
||||
EOF
|
||||
exit 0
|
||||
fi
|
||||
if [[ "${1:-}" == --check-startup ]]; then
|
||||
if [[ $# -ne 3 ]]; then
|
||||
echo "Usage: ./build --check-startup <Params root or namespace> <recovery storage>" >&2
|
||||
exit 2
|
||||
fi
|
||||
exec "${ROOT_DIR}/dev" python "${ROOT_DIR}/tools/check_startup.py" "$2" "$3"
|
||||
fi
|
||||
for arg in "$@"; do
|
||||
case "${arg}" in
|
||||
RELEASE=*|CERT=*)
|
||||
echo "ERROR: RELEASE and CERT must be environment variables, not SCons arguments." >&2
|
||||
echo "Use: RELEASE=1 CERT=/path/to/certificate ./build --panda 4" >&2
|
||||
exit 2
|
||||
;;
|
||||
esac
|
||||
done
|
||||
|
||||
build_helper="${ROOT_DIR}/scripts/laptop_device_build.sh"
|
||||
if [[ -f /AGNOS && "$(uname -s)" == Linux && "$(uname -m)" == aarch64 ]]; then
|
||||
build_helper="${ROOT_DIR}/scripts/native_device_build.sh"
|
||||
fi
|
||||
if [[ $# -eq 1 && "$1" == --mapd ]]; then
|
||||
exec "${ROOT_DIR}/scripts/build_mapd_provider.sh"
|
||||
fi
|
||||
if [[ $# -gt 0 ]]; then
|
||||
for arg in "$@"; do
|
||||
if [[ "$arg" == --mapd ]]; then
|
||||
echo "ERROR: --mapd is a standalone package operation; use ./build --mapd" >&2
|
||||
exit 2
|
||||
fi
|
||||
done
|
||||
fi
|
||||
shortcut_targets=()
|
||||
passthrough_args=()
|
||||
default_args=()
|
||||
jobs_arg=""
|
||||
shortcut_includes_panda=0
|
||||
panda_generated_files=(panda/board/obj/gitversion.h panda/board/obj/version)
|
||||
|
||||
while [[ $# -gt 0 ]]; do
|
||||
case "$1" in
|
||||
--params|-params|-param)
|
||||
shortcut_targets+=(openpilot/common/libparams_c.so)
|
||||
;;
|
||||
--panda|-panda)
|
||||
shortcut_includes_panda=1
|
||||
shortcut_targets+=(panda/board/obj/panda.bin.signed panda/board/obj/panda_h7.bin.signed panda/board/obj/body_h7.bin.signed)
|
||||
;;
|
||||
--cereal|-cereal)
|
||||
shortcut_targets+=(openpilot/cereal/libcereal.a openpilot/cereal/libsocketmaster.a
|
||||
openpilot/cereal/messaging/bridge openpilot/cereal/services.h)
|
||||
;;
|
||||
-j|--jobs)
|
||||
passthrough_args+=("$1")
|
||||
default_args+=("$1")
|
||||
if [[ $# -gt 1 ]]; then
|
||||
passthrough_args+=("$2")
|
||||
default_args+=("$2")
|
||||
shift
|
||||
fi
|
||||
;;
|
||||
*)
|
||||
if [[ "$1" =~ ^[0-9]+$ ]]; then
|
||||
if [[ "$1" =~ ^0+$ ]]; then
|
||||
echo "ERROR: jobs must be positive" >&2
|
||||
exit 2
|
||||
fi
|
||||
jobs_arg="$1"
|
||||
passthrough_args+=("-j$1")
|
||||
else
|
||||
passthrough_args+=("$1")
|
||||
default_args+=("$1")
|
||||
fi
|
||||
;;
|
||||
esac
|
||||
shift
|
||||
done
|
||||
|
||||
if [[ "${#shortcut_targets[@]}" -gt 0 ]]; then
|
||||
scons_args=(--no-scrub "${shortcut_targets[@]}")
|
||||
if [[ ${passthrough_args[0]+present} ]]; then
|
||||
scons_args+=("${passthrough_args[@]}")
|
||||
fi
|
||||
if [[ "$shortcut_includes_panda" -eq 1 ]]; then
|
||||
exec "${build_helper}" scons "${scons_args[@]}"
|
||||
fi
|
||||
|
||||
# Panda/SConscript updates these even for unrelated targets. Restore their
|
||||
# prior bytes for the non-firmware shortcuts, including on build failure.
|
||||
tmpdir="$(mktemp -d)"
|
||||
restore_panda_metadata() {
|
||||
local path safe
|
||||
for path in "${panda_generated_files[@]}"; do
|
||||
safe="${path//\//__}"
|
||||
if [[ -e "${tmpdir}/${safe}.missing" ]]; then
|
||||
rm -f "${ROOT_DIR}/${path}"
|
||||
else
|
||||
cp -p "${tmpdir}/${safe}" "${ROOT_DIR}/${path}"
|
||||
fi
|
||||
done
|
||||
rm -rf "${tmpdir}"
|
||||
}
|
||||
trap restore_panda_metadata EXIT
|
||||
for path in "${panda_generated_files[@]}"; do
|
||||
safe="${path//\//__}"
|
||||
if [[ -e "${ROOT_DIR}/${path}" ]]; then
|
||||
cp -p "${ROOT_DIR}/${path}" "${tmpdir}/${safe}"
|
||||
else
|
||||
touch "${tmpdir}/${safe}.missing"
|
||||
fi
|
||||
done
|
||||
"${build_helper}" scons "${scons_args[@]}"
|
||||
exit $?
|
||||
fi
|
||||
|
||||
python3 "${ROOT_DIR}/tools/release/stage_mapd_provider.py" --source "${ROOT_DIR}" --require-tracked
|
||||
|
||||
if [[ -n "${jobs_arg}" ]]; then
|
||||
if [[ ${default_args[0]+present} ]]; then
|
||||
exec "${build_helper}" build "${jobs_arg}" "${default_args[@]}"
|
||||
fi
|
||||
exec "${build_helper}" build "${jobs_arg}"
|
||||
fi
|
||||
if [[ ${default_args[0]+present} ]]; then
|
||||
exec "${build_helper}" build "${default_args[@]}"
|
||||
fi
|
||||
exec "${build_helper}" build
|
||||
@@ -1,4 +0,0 @@
|
||||
#!/usr/bin/env bash
|
||||
set -euo pipefail
|
||||
ROOT_DIR="$(cd "$(dirname "${BASH_SOURCE[0]}")" && pwd)"
|
||||
exec "${ROOT_DIR}/scripts/host_tool_runner.sh" c3 "$@"
|
||||
@@ -1,4 +0,0 @@
|
||||
#!/usr/bin/env bash
|
||||
set -euo pipefail
|
||||
ROOT_DIR="$(cd "$(dirname "${BASH_SOURCE[0]}")" && pwd)"
|
||||
exec "${ROOT_DIR}/scripts/host_tool_runner.sh" c4 "$@"
|
||||
Submodule
+1
Submodule cereal added at ab32956aaf
@@ -0,0 +1 @@
|
||||
*.cpp
|
||||
@@ -0,0 +1,6 @@
|
||||
Import('env')
|
||||
|
||||
# parser
|
||||
env.Command(['common_pyx.so'],
|
||||
['common_pyx_setup.py', 'clock.pyx'],
|
||||
"cd common && python3 common_pyx_setup.py build_ext --inplace")
|
||||
@@ -0,0 +1,130 @@
|
||||
import os
|
||||
import binascii
|
||||
import itertools
|
||||
import re
|
||||
import struct
|
||||
import subprocess
|
||||
import random
|
||||
from cereal import log
|
||||
|
||||
NetworkType = log.ThermalData.NetworkType
|
||||
|
||||
ANDROID = os.path.isfile('/EON')
|
||||
|
||||
def getprop(key):
|
||||
if not ANDROID:
|
||||
return ""
|
||||
return subprocess.check_output(["getprop", key], encoding='utf8').strip()
|
||||
|
||||
def get_imei(slot):
|
||||
slot = str(slot)
|
||||
if slot not in ("0", "1"):
|
||||
raise ValueError("SIM slot must be 0 or 1")
|
||||
|
||||
ret = parse_service_call_string(service_call(["iphonesubinfo", "3" ,"i32", str(slot)]))
|
||||
if not ret:
|
||||
# allow non android to be identified differently
|
||||
ret = "%015d" % random.randint(0, 1<<32)
|
||||
return ret
|
||||
|
||||
def get_serial():
|
||||
ret = getprop("ro.serialno")
|
||||
if ret == "":
|
||||
ret = "cccccccc"
|
||||
return ret
|
||||
|
||||
def get_subscriber_info():
|
||||
ret = parse_service_call_string(service_call(["iphonesubinfo", "7"]))
|
||||
if ret is None or len(ret) < 8:
|
||||
return ""
|
||||
return ret
|
||||
|
||||
def reboot(reason=None):
|
||||
if reason is None:
|
||||
reason_args = ["null"]
|
||||
else:
|
||||
reason_args = ["s16", reason]
|
||||
|
||||
subprocess.check_output([
|
||||
"service", "call", "power", "16", # IPowerManager.reboot
|
||||
"i32", "0", # no confirmation,
|
||||
*reason_args,
|
||||
"i32", "1" # wait
|
||||
])
|
||||
|
||||
def service_call(call):
|
||||
if not ANDROID:
|
||||
return None
|
||||
|
||||
ret = subprocess.check_output(["service", "call", *call], encoding='utf8').strip()
|
||||
if 'Parcel' not in ret:
|
||||
return None
|
||||
|
||||
return parse_service_call_bytes(ret)
|
||||
|
||||
def parse_service_call_unpack(r, fmt):
|
||||
try:
|
||||
return struct.unpack(fmt, r)[0]
|
||||
except Exception:
|
||||
return None
|
||||
|
||||
def parse_service_call_string(r):
|
||||
try:
|
||||
r = r[8:] # Cut off length field
|
||||
r = r.decode('utf_16_be')
|
||||
|
||||
# All pairs of two characters seem to be swapped. Not sure why
|
||||
result = ""
|
||||
for a, b, in itertools.zip_longest(r[::2], r[1::2], fillvalue='\x00'):
|
||||
result += b + a
|
||||
|
||||
result = result.replace('\x00', '')
|
||||
|
||||
return result
|
||||
except Exception:
|
||||
return None
|
||||
|
||||
def parse_service_call_bytes(ret):
|
||||
try:
|
||||
r = b""
|
||||
for hex_part in re.findall(r'[ (]([0-9a-f]{8})', ret):
|
||||
r += binascii.unhexlify(hex_part)
|
||||
return r
|
||||
except Exception:
|
||||
return None
|
||||
|
||||
def get_network_type():
|
||||
if not ANDROID:
|
||||
return NetworkType.none
|
||||
|
||||
wifi_check = parse_service_call_string(service_call(["connectivity", "2"]))
|
||||
if wifi_check is None:
|
||||
return NetworkType.none
|
||||
elif 'WIFI' in wifi_check:
|
||||
return NetworkType.wifi
|
||||
else:
|
||||
cell_check = parse_service_call_unpack(service_call(['phone', '59']), ">q")
|
||||
# from TelephonyManager.java
|
||||
cell_networks = {
|
||||
0: NetworkType.none,
|
||||
1: NetworkType.cell2G,
|
||||
2: NetworkType.cell2G,
|
||||
3: NetworkType.cell3G,
|
||||
4: NetworkType.cell2G,
|
||||
5: NetworkType.cell3G,
|
||||
6: NetworkType.cell3G,
|
||||
7: NetworkType.cell3G,
|
||||
8: NetworkType.cell3G,
|
||||
9: NetworkType.cell3G,
|
||||
10: NetworkType.cell3G,
|
||||
11: NetworkType.cell2G,
|
||||
12: NetworkType.cell3G,
|
||||
13: NetworkType.cell4G,
|
||||
14: NetworkType.cell4G,
|
||||
15: NetworkType.cell3G,
|
||||
16: NetworkType.cell2G,
|
||||
17: NetworkType.cell3G,
|
||||
18: NetworkType.cell4G,
|
||||
19: NetworkType.cell4G
|
||||
}
|
||||
return cell_networks.get(cell_check, NetworkType.none)
|
||||
@@ -0,0 +1,42 @@
|
||||
import jwt
|
||||
import requests
|
||||
from datetime import datetime, timedelta
|
||||
from common.basedir import PERSIST
|
||||
from selfdrive.version import version
|
||||
|
||||
class Api():
|
||||
def __init__(self, dongle_id):
|
||||
self.dongle_id = dongle_id
|
||||
with open(PERSIST+'/comma/id_rsa') as f:
|
||||
self.private_key = f.read()
|
||||
|
||||
def get(self, *args, **kwargs):
|
||||
return self.request('GET', *args, **kwargs)
|
||||
|
||||
def post(self, *args, **kwargs):
|
||||
return self.request('POST', *args, **kwargs)
|
||||
|
||||
def request(self, method, endpoint, timeout=None, access_token=None, **params):
|
||||
return api_get(endpoint, method=method, timeout=timeout, access_token=access_token, **params)
|
||||
|
||||
def get_token(self):
|
||||
now = datetime.utcnow()
|
||||
payload = {
|
||||
'identity': self.dongle_id,
|
||||
'nbf': now,
|
||||
'iat': now,
|
||||
'exp': now + timedelta(hours=1)
|
||||
}
|
||||
return jwt.encode(payload, self.private_key, algorithm='RS256').decode('utf8')
|
||||
|
||||
def api_get(endpoint, method='GET', timeout=None, access_token=None, **params):
|
||||
backend = "https://api.commadotai.com/"
|
||||
|
||||
headers = {}
|
||||
if access_token is not None:
|
||||
headers['Authorization'] = "JWT "+access_token
|
||||
|
||||
headers['User-Agent'] = "openpilot-" + version
|
||||
|
||||
return requests.request(method, backend+endpoint, timeout=timeout, headers = headers, params=params)
|
||||
|
||||
@@ -0,0 +1,99 @@
|
||||
import os
|
||||
import subprocess
|
||||
import glob
|
||||
import hashlib
|
||||
import shutil
|
||||
from common.basedir import BASEDIR
|
||||
from selfdrive.swaglog import cloudlog
|
||||
|
||||
android_packages = ("ai.comma.plus.offroad", "ai.comma.plus.frame")
|
||||
|
||||
def get_installed_apks():
|
||||
dat = subprocess.check_output(["pm", "list", "packages", "-f"], encoding='utf8').strip().split("\n")
|
||||
ret = {}
|
||||
for x in dat:
|
||||
if x.startswith("package:"):
|
||||
v,k = x.split("package:")[1].split("=")
|
||||
ret[k] = v
|
||||
return ret
|
||||
|
||||
def install_apk(path):
|
||||
# can only install from world readable path
|
||||
install_path = "/sdcard/%s" % os.path.basename(path)
|
||||
shutil.copyfile(path, install_path)
|
||||
|
||||
ret = subprocess.call(["pm", "install", "-r", install_path])
|
||||
os.remove(install_path)
|
||||
return ret == 0
|
||||
|
||||
def start_frame():
|
||||
set_package_permissions()
|
||||
system("am start -n ai.comma.plus.frame/.MainActivity")
|
||||
|
||||
def set_package_permissions():
|
||||
pm_grant("ai.comma.plus.offroad", "android.permission.ACCESS_FINE_LOCATION")
|
||||
pm_grant("ai.comma.plus.offroad", "android.permission.READ_PHONE_STATE")
|
||||
appops_set("ai.comma.plus.offroad", "SU", "allow")
|
||||
appops_set("ai.comma.plus.offroad", "WIFI_SCAN", "allow")
|
||||
appops_set("ai.comma.plus.offroad", "READ_EXTERNAL_STORAGE", "allow")
|
||||
appops_set("ai.comma.plus.offroad", "WRITE_EXTERNAL_STORAGE", "allow")
|
||||
|
||||
def appops_set(package, op, mode):
|
||||
system(f"LD_LIBRARY_PATH= appops set {package} {op} {mode}")
|
||||
|
||||
def pm_grant(package, permission):
|
||||
system(f"pm grant {package} {permission}")
|
||||
|
||||
def system(cmd):
|
||||
try:
|
||||
cloudlog.info("running %s" % cmd)
|
||||
subprocess.check_output(cmd, stderr=subprocess.STDOUT, shell=True)
|
||||
except subprocess.CalledProcessError as e:
|
||||
cloudlog.event("running failed",
|
||||
cmd=e.cmd,
|
||||
output=e.output[-1024:],
|
||||
returncode=e.returncode)
|
||||
|
||||
# *** external functions ***
|
||||
|
||||
def update_apks():
|
||||
# install apks
|
||||
installed = get_installed_apks()
|
||||
|
||||
install_apks = glob.glob(os.path.join(BASEDIR, "apk/*.apk"))
|
||||
for apk in install_apks:
|
||||
app = os.path.basename(apk)[:-4]
|
||||
if app not in installed:
|
||||
installed[app] = None
|
||||
|
||||
cloudlog.info("installed apks %s" % (str(installed), ))
|
||||
|
||||
for app in installed.keys():
|
||||
apk_path = os.path.join(BASEDIR, "apk/"+app+".apk")
|
||||
if not os.path.exists(apk_path):
|
||||
continue
|
||||
|
||||
h1 = hashlib.sha1(open(apk_path, 'rb').read()).hexdigest()
|
||||
h2 = None
|
||||
if installed[app] is not None:
|
||||
h2 = hashlib.sha1(open(installed[app], 'rb').read()).hexdigest()
|
||||
cloudlog.info("comparing version of %s %s vs %s" % (app, h1, h2))
|
||||
|
||||
if h2 is None or h1 != h2:
|
||||
cloudlog.info("installing %s" % app)
|
||||
|
||||
success = install_apk(apk_path)
|
||||
if not success:
|
||||
cloudlog.info("needing to uninstall %s" % app)
|
||||
system("pm uninstall %s" % app)
|
||||
success = install_apk(apk_path)
|
||||
|
||||
assert success
|
||||
|
||||
def pm_apply_packages(cmd):
|
||||
for p in android_packages:
|
||||
system("pm %s %s" % (cmd, p))
|
||||
|
||||
if __name__ == "__main__":
|
||||
update_apks()
|
||||
|
||||
@@ -0,0 +1,11 @@
|
||||
import os
|
||||
BASEDIR = os.path.abspath(os.path.join(os.path.dirname(os.path.realpath(__file__)), "../"))
|
||||
|
||||
from common.android import ANDROID
|
||||
if ANDROID:
|
||||
PERSIST = "/persist"
|
||||
PARAMS = "/data/params"
|
||||
else:
|
||||
PERSIST = os.path.join(BASEDIR, "persist")
|
||||
PARAMS = os.path.join(BASEDIR, "persist", "params")
|
||||
|
||||
@@ -0,0 +1,22 @@
|
||||
from posix.time cimport clock_gettime, timespec, CLOCK_MONOTONIC_RAW, clockid_t
|
||||
|
||||
IF UNAME_SYSNAME == "Darwin":
|
||||
# Darwin doesn't have a CLOCK_BOOTTIME
|
||||
CLOCK_BOOTTIME = CLOCK_MONOTONIC_RAW
|
||||
ELSE:
|
||||
from posix.time cimport CLOCK_BOOTTIME
|
||||
|
||||
cdef double readclock(clockid_t clock_id):
|
||||
cdef timespec ts
|
||||
cdef double current
|
||||
|
||||
clock_gettime(clock_id, &ts)
|
||||
current = ts.tv_sec + (ts.tv_nsec / 1000000000.)
|
||||
return current
|
||||
|
||||
def monotonic_time():
|
||||
return readclock(CLOCK_MONOTONIC_RAW)
|
||||
|
||||
def sec_since_boot():
|
||||
return readclock(CLOCK_BOOTTIME)
|
||||
|
||||
@@ -0,0 +1,150 @@
|
||||
import os
|
||||
import numpy as np
|
||||
import collections
|
||||
from contextlib import closing
|
||||
|
||||
from common.file_helpers import mkdirs_exists_ok
|
||||
|
||||
class ColumnStoreReader():
|
||||
def __init__(self, path, mmap=False, allow_pickle=False, direct_io=False):
|
||||
if not (path and os.path.isdir(path)):
|
||||
raise ValueError("Not a column store: {}".format(path))
|
||||
|
||||
self._path = os.path.realpath(path)
|
||||
self._keys = os.listdir(self._path)
|
||||
self._mmap = mmap
|
||||
self._allow_pickle = allow_pickle
|
||||
self._direct_io = direct_io
|
||||
|
||||
@property
|
||||
def path(self):
|
||||
return self._path
|
||||
|
||||
def close(self):
|
||||
pass
|
||||
|
||||
def get(self, key):
|
||||
try:
|
||||
return self[key]
|
||||
except KeyError:
|
||||
return None
|
||||
|
||||
def keys(self):
|
||||
return list(self._keys)
|
||||
|
||||
def iteritems(self):
|
||||
for k in self:
|
||||
yield (k, self[k])
|
||||
|
||||
def itervalues(self):
|
||||
for k in self:
|
||||
yield self[k]
|
||||
|
||||
def get_npy_path(self, key):
|
||||
"""Gets a filesystem path for an npy file containing the specified array,
|
||||
or none if the column store does not contain key.
|
||||
"""
|
||||
if key in self:
|
||||
return os.path.join(self._path, key)
|
||||
else:
|
||||
return None
|
||||
|
||||
def __getitem__(self, key):
|
||||
try:
|
||||
path = os.path.join(self._path, key)
|
||||
|
||||
# TODO(mgraczyk): This implementation will need to change for zip.
|
||||
if os.path.isdir(path):
|
||||
return ColumnStoreReader(path)
|
||||
else:
|
||||
if self._mmap:
|
||||
# note that direct i/o does nothing for mmap since file read/write interface is not used
|
||||
ret = np.load(path, mmap_mode='r', allow_pickle=self._allow_pickle, fix_imports=False)
|
||||
else:
|
||||
if self._direct_io:
|
||||
opener = lambda path, flags: os.open(path, os.O_RDONLY | os.O_DIRECT)
|
||||
with open(path, 'rb', buffering=0, opener=opener) as f:
|
||||
ret = np.load(f, allow_pickle=self._allow_pickle, fix_imports=False)
|
||||
else:
|
||||
ret = np.load(path, allow_pickle=self._allow_pickle, fix_imports=False)
|
||||
if type(ret) == np.lib.npyio.NpzFile:
|
||||
# if it's saved as compressed, it has arr_0 only in the file. deref this
|
||||
return ret['arr_0']
|
||||
else:
|
||||
return ret
|
||||
except IOError:
|
||||
raise KeyError(key)
|
||||
|
||||
def __contains__(self, item):
|
||||
try:
|
||||
self[item]
|
||||
return True
|
||||
except KeyError:
|
||||
return False
|
||||
|
||||
def __len__(self):
|
||||
return len(self._keys)
|
||||
|
||||
def __bool__(self):
|
||||
return bool(self._keys)
|
||||
|
||||
def __iter__(self):
|
||||
return iter(self._keys)
|
||||
|
||||
def __str__(self):
|
||||
return "ColumnStoreReader({})".format(str({k: "..." for k in self._keys}))
|
||||
|
||||
def __enter__(self): return self
|
||||
def __exit__(self, type, value, traceback): self.close()
|
||||
|
||||
class ColumnStoreWriter():
|
||||
def __init__(self, path, allow_pickle=False):
|
||||
self._path = path
|
||||
self._allow_pickle = allow_pickle
|
||||
mkdirs_exists_ok(self._path)
|
||||
|
||||
def map_column(self, path, dtype, shape):
|
||||
npy_path = os.path.join(self._path, path)
|
||||
mkdirs_exists_ok(os.path.dirname(npy_path))
|
||||
return np.lib.format.open_memmap(npy_path, mode='w+', dtype=dtype, shape=shape)
|
||||
|
||||
def add_column(self, path, data, dtype=None, compression=False, overwrite=False):
|
||||
npy_path = os.path.join(self._path, path)
|
||||
mkdirs_exists_ok(os.path.dirname(npy_path))
|
||||
|
||||
if overwrite:
|
||||
f = open(npy_path, "wb")
|
||||
else:
|
||||
f = os.fdopen(os.open(npy_path, os.O_WRONLY | os.O_CREAT | os.O_EXCL), "wb")
|
||||
|
||||
with closing(f) as f:
|
||||
data2 = np.array(data, copy=False, dtype=dtype)
|
||||
if compression:
|
||||
np.savez_compressed(f, data2)
|
||||
else:
|
||||
np.save(f, data2, allow_pickle=self._allow_pickle, fix_imports=False)
|
||||
|
||||
def add_group(self, group_name):
|
||||
# TODO(mgraczyk): This implementation will need to change if we add zip or compression.
|
||||
return ColumnStoreWriter(os.path.join(self._path, group_name))
|
||||
|
||||
def close(self):
|
||||
pass
|
||||
|
||||
def __enter__(self): return self
|
||||
def __exit__(self, type, value, traceback): self.close()
|
||||
|
||||
|
||||
def _save_dict_as_column_store(values, writer):
|
||||
for k, v in values.items():
|
||||
if isinstance(v, collections.Mapping):
|
||||
_save_dict_as_column_store(v, writer.add_group(k))
|
||||
else:
|
||||
writer.add_column(k, v)
|
||||
|
||||
|
||||
def save_dict_as_column_store(values, output_path):
|
||||
with ColumnStoreWriter(output_path) as writer:
|
||||
_save_dict_as_column_store(values, writer)
|
||||
|
||||
|
||||
@@ -0,0 +1,20 @@
|
||||
from distutils.core import Extension, setup # pylint: disable=import-error,no-name-in-module
|
||||
from Cython.Build import cythonize
|
||||
|
||||
from common.cython_hacks import BuildExtWithoutPlatformSuffix
|
||||
|
||||
sourcefiles = ['clock.pyx']
|
||||
extra_compile_args = ["-std=c++11"]
|
||||
|
||||
setup(name='Common',
|
||||
cmdclass={'build_ext': BuildExtWithoutPlatformSuffix},
|
||||
ext_modules=cythonize(
|
||||
Extension(
|
||||
"common_pyx",
|
||||
language="c++",
|
||||
sources=sourcefiles,
|
||||
extra_compile_args=extra_compile_args,
|
||||
)
|
||||
),
|
||||
nthreads=4,
|
||||
)
|
||||
@@ -0,0 +1,3 @@
|
||||
# py2,3 compatiblity helpers
|
||||
|
||||
basestring = (str, bytes)
|
||||
@@ -0,0 +1,23 @@
|
||||
import os
|
||||
import sysconfig
|
||||
from Cython.Distutils import build_ext
|
||||
|
||||
def get_ext_filename_without_platform_suffix(filename):
|
||||
name, ext = os.path.splitext(filename)
|
||||
ext_suffix = sysconfig.get_config_var('EXT_SUFFIX')
|
||||
|
||||
if ext_suffix == ext:
|
||||
return filename
|
||||
|
||||
ext_suffix = ext_suffix.replace(ext, '')
|
||||
idx = name.find(ext_suffix)
|
||||
|
||||
if idx == -1:
|
||||
return filename
|
||||
else:
|
||||
return name[:idx] + ext
|
||||
|
||||
class BuildExtWithoutPlatformSuffix(build_ext):
|
||||
def get_ext_filename(self, ext_name):
|
||||
filename = super().get_ext_filename(ext_name)
|
||||
return get_ext_filename_without_platform_suffix(filename)
|
||||
@@ -0,0 +1,55 @@
|
||||
import os
|
||||
import sys
|
||||
import fcntl
|
||||
import hashlib
|
||||
import platform
|
||||
from cffi import FFI
|
||||
|
||||
def suffix():
|
||||
if platform.system() == "Darwin":
|
||||
return ".dylib"
|
||||
else:
|
||||
return ".so"
|
||||
|
||||
def ffi_wrap(name, c_code, c_header, tmpdir="/tmp/ccache", cflags="", libraries=None):
|
||||
if libraries is None:
|
||||
libraries = []
|
||||
|
||||
cache = name + "_" + hashlib.sha1(c_code.encode('utf-8')).hexdigest()
|
||||
try:
|
||||
os.mkdir(tmpdir)
|
||||
except OSError:
|
||||
pass
|
||||
|
||||
fd = os.open(tmpdir, 0)
|
||||
fcntl.flock(fd, fcntl.LOCK_EX)
|
||||
try:
|
||||
sys.path.append(tmpdir)
|
||||
try:
|
||||
mod = __import__(cache)
|
||||
except Exception:
|
||||
print("cache miss {0}".format(cache))
|
||||
compile_code(cache, c_code, c_header, tmpdir, cflags, libraries)
|
||||
mod = __import__(cache)
|
||||
finally:
|
||||
os.close(fd)
|
||||
|
||||
return mod.ffi, mod.lib
|
||||
|
||||
|
||||
def compile_code(name, c_code, c_header, directory, cflags="", libraries=None):
|
||||
if libraries is None:
|
||||
libraries = []
|
||||
|
||||
ffibuilder = FFI()
|
||||
ffibuilder.set_source(name, c_code, source_extension='.cpp', libraries=libraries)
|
||||
ffibuilder.cdef(c_header)
|
||||
os.environ['OPT'] = "-fwrapv -O2 -DNDEBUG -std=c++11"
|
||||
os.environ['CFLAGS'] = cflags
|
||||
ffibuilder.compile(verbose=True, debug=False, tmpdir=directory)
|
||||
|
||||
|
||||
def wrap_compiled(name, directory):
|
||||
sys.path.append(directory)
|
||||
mod = __import__(name)
|
||||
return mod.ffi, mod.lib
|
||||
@@ -0,0 +1,109 @@
|
||||
import os
|
||||
import shutil
|
||||
import tempfile
|
||||
from atomicwrites import AtomicWriter
|
||||
|
||||
def mkdirs_exists_ok(path):
|
||||
try:
|
||||
os.makedirs(path)
|
||||
except OSError:
|
||||
if not os.path.isdir(path):
|
||||
raise
|
||||
|
||||
def rm_not_exists_ok(path):
|
||||
try:
|
||||
os.remove(path)
|
||||
except OSError:
|
||||
if os.path.exists(path):
|
||||
raise
|
||||
|
||||
def rm_tree_or_link(path):
|
||||
if os.path.islink(path):
|
||||
os.unlink(path)
|
||||
elif os.path.isdir(path):
|
||||
shutil.rmtree(path)
|
||||
|
||||
def get_tmpdir_on_same_filesystem(path):
|
||||
normpath = os.path.normpath(path)
|
||||
parts = normpath.split("/")
|
||||
if len(parts) > 1 and parts[1] == "scratch":
|
||||
return "/scratch/tmp"
|
||||
elif len(parts) > 2 and parts[2] == "runner":
|
||||
return "/{}/runner/tmp".format(parts[1])
|
||||
return "/tmp"
|
||||
|
||||
class AutoMoveTempdir():
|
||||
def __init__(self, target_path, temp_dir=None):
|
||||
self._target_path = target_path
|
||||
self._path = tempfile.mkdtemp(dir=temp_dir)
|
||||
|
||||
@property
|
||||
def name(self):
|
||||
return self._path
|
||||
|
||||
def close(self):
|
||||
os.rename(self._path, self._target_path)
|
||||
|
||||
def __enter__(self): return self
|
||||
|
||||
def __exit__(self, type, value, traceback):
|
||||
if type is None:
|
||||
self.close()
|
||||
else:
|
||||
shutil.rmtree(self._path)
|
||||
|
||||
class NamedTemporaryDir():
|
||||
def __init__(self, temp_dir=None):
|
||||
self._path = tempfile.mkdtemp(dir=temp_dir)
|
||||
|
||||
@property
|
||||
def name(self):
|
||||
return self._path
|
||||
|
||||
def close(self):
|
||||
shutil.rmtree(self._path)
|
||||
|
||||
def __enter__(self): return self
|
||||
|
||||
def __exit__(self, type, value, traceback):
|
||||
self.close()
|
||||
|
||||
def _get_fileobject_func(writer, temp_dir):
|
||||
def _get_fileobject():
|
||||
file_obj = writer.get_fileobject(dir=temp_dir)
|
||||
os.chmod(file_obj.name, 0o644)
|
||||
return file_obj
|
||||
return _get_fileobject
|
||||
|
||||
def atomic_write_on_fs_tmp(path, **kwargs):
|
||||
"""Creates an atomic writer using a temporary file in a temporary directory
|
||||
on the same filesystem as path.
|
||||
"""
|
||||
# TODO(mgraczyk): This use of AtomicWriter relies on implementation details to set the temp
|
||||
# directory.
|
||||
writer = AtomicWriter(path, **kwargs)
|
||||
return writer._open(_get_fileobject_func(writer, get_tmpdir_on_same_filesystem(path)))
|
||||
|
||||
|
||||
def atomic_write_in_dir(path, **kwargs):
|
||||
"""Creates an atomic writer using a temporary file in the same directory
|
||||
as the destination file.
|
||||
"""
|
||||
writer = AtomicWriter(path, **kwargs)
|
||||
return writer._open(_get_fileobject_func(writer, os.path.dirname(path)))
|
||||
|
||||
def atomic_write_in_dir_neos(path, contents, mode=None):
|
||||
"""
|
||||
Atomically writes contents to path using a temporary file in the same directory
|
||||
as path. Useful on NEOS, where `os.link` (required by atomic_write_in_dir) is missing.
|
||||
"""
|
||||
|
||||
f = tempfile.NamedTemporaryFile(delete=False, prefix=".tmp", dir=os.path.dirname(path))
|
||||
f.write(contents)
|
||||
f.flush()
|
||||
if mode is not None:
|
||||
os.fchmod(f.fileno(), mode)
|
||||
os.fsync(f.fileno())
|
||||
f.close()
|
||||
|
||||
os.rename(f.name, path)
|
||||
@@ -0,0 +1,10 @@
|
||||
class FirstOrderFilter():
|
||||
# first order filter
|
||||
def __init__(self, x0, ts, dt):
|
||||
self.k = (dt / ts) / (1. + dt / ts)
|
||||
self.x = x0
|
||||
|
||||
def update(self, x):
|
||||
self.x = (1. - self.k) * self.x + self.k * x
|
||||
|
||||
|
||||
@@ -0,0 +1,24 @@
|
||||
import numpy as np
|
||||
import os
|
||||
import csv
|
||||
path = os.path.dirname(os.path.abspath(__file__))
|
||||
# locally cache cities from
|
||||
# https://github.com/thampiman/reverse-geocoder
|
||||
csv_file_name = path + '/rg_cities1000.csv'
|
||||
|
||||
# right hand drive is when the steering wheel is on the right of the car
|
||||
# left hand traffic is when cars driver on the left side of the road
|
||||
LHT_COUNTRIES = ['AU', 'IN', 'IE', 'JP', 'MU', 'MY', 'NZ', 'UK', 'ZA']
|
||||
|
||||
|
||||
def get_city(lat, lon):
|
||||
cities = np.array(list(csv.reader(open(csv_file_name))))[1:]
|
||||
positions = cities[:,:2].astype(np.float32)
|
||||
idx = np.argmin(np.linalg.norm((positions - np.array([lat, lon])), axis=1))
|
||||
return cities[idx]
|
||||
|
||||
|
||||
def is_lht(lat, lon):
|
||||
city = get_city(lat, lon)
|
||||
country = city[-1]
|
||||
return country in LHT_COUNTRIES
|
||||
File diff suppressed because it is too large
Load Diff
@@ -0,0 +1 @@
|
||||
simple_kalman_impl.c
|
||||
@@ -0,0 +1,6 @@
|
||||
Import('env')
|
||||
|
||||
env.Command(['simple_kalman_impl.so'],
|
||||
['simple_kalman_impl.pyx', 'simple_kalman_impl.pxd', 'simple_kalman_setup.py'],
|
||||
"cd common/kalman && python3 simple_kalman_setup.py build_ext --inplace")
|
||||
|
||||
@@ -0,0 +1,3 @@
|
||||
# pylint: skip-file
|
||||
from common.kalman.simple_kalman_impl import KF1D as KF1D
|
||||
assert KF1D
|
||||
@@ -0,0 +1,16 @@
|
||||
cdef class KF1D:
|
||||
cdef public:
|
||||
double x0_0
|
||||
double x1_0
|
||||
double K0_0
|
||||
double K1_0
|
||||
double A0_0
|
||||
double A0_1
|
||||
double A1_0
|
||||
double A1_1
|
||||
double C0_0
|
||||
double C0_1
|
||||
double A_K_0
|
||||
double A_K_1
|
||||
double A_K_2
|
||||
double A_K_3
|
||||
@@ -0,0 +1,36 @@
|
||||
# cython: language_level=3
|
||||
|
||||
cdef class KF1D:
|
||||
def __init__(self, x0, A, C, K):
|
||||
self.x0_0 = x0[0][0]
|
||||
self.x1_0 = x0[1][0]
|
||||
self.A0_0 = A[0][0]
|
||||
self.A0_1 = A[0][1]
|
||||
self.A1_0 = A[1][0]
|
||||
self.A1_1 = A[1][1]
|
||||
self.C0_0 = C[0]
|
||||
self.C0_1 = C[1]
|
||||
self.K0_0 = K[0][0]
|
||||
self.K1_0 = K[1][0]
|
||||
|
||||
self.A_K_0 = self.A0_0 - self.K0_0 * self.C0_0
|
||||
self.A_K_1 = self.A0_1 - self.K0_0 * self.C0_1
|
||||
self.A_K_2 = self.A1_0 - self.K1_0 * self.C0_0
|
||||
self.A_K_3 = self.A1_1 - self.K1_0 * self.C0_1
|
||||
|
||||
def update(self, meas):
|
||||
cdef double x0_0 = self.A_K_0 * self.x0_0 + self.A_K_1 * self.x1_0 + self.K0_0 * meas
|
||||
cdef double x1_0 = self.A_K_2 * self.x0_0 + self.A_K_3 * self.x1_0 + self.K1_0 * meas
|
||||
self.x0_0 = x0_0
|
||||
self.x1_0 = x1_0
|
||||
|
||||
return [self.x0_0, self.x1_0]
|
||||
|
||||
@property
|
||||
def x(self):
|
||||
return [[self.x0_0], [self.x1_0]]
|
||||
|
||||
@x.setter
|
||||
def x(self, x):
|
||||
self.x0_0 = x[0][0]
|
||||
self.x1_0 = x[1][0]
|
||||
@@ -0,0 +1,23 @@
|
||||
import numpy as np
|
||||
|
||||
|
||||
class KF1D:
|
||||
# this EKF assumes constant covariance matrix, so calculations are much simpler
|
||||
# the Kalman gain also needs to be precomputed using the control module
|
||||
|
||||
def __init__(self, x0, A, C, K):
|
||||
self.x = x0
|
||||
self.A = A
|
||||
self.C = C
|
||||
self.K = K
|
||||
|
||||
self.A_K = self.A - np.dot(self.K, self.C)
|
||||
|
||||
# K matrix needs to be pre-computed as follow:
|
||||
# import control
|
||||
# (x, l, K) = control.dare(np.transpose(self.A), np.transpose(self.C), Q, R)
|
||||
# self.K = np.transpose(K)
|
||||
|
||||
def update(self, meas):
|
||||
self.x = np.dot(self.A_K, self.x) + np.dot(self.K, meas)
|
||||
return self.x
|
||||
@@ -0,0 +1,9 @@
|
||||
from distutils.core import Extension, setup
|
||||
|
||||
from Cython.Build import cythonize
|
||||
|
||||
from common.cython_hacks import BuildExtWithoutPlatformSuffix
|
||||
|
||||
setup(name='Simple Kalman Implementation',
|
||||
cmdclass={'build_ext': BuildExtWithoutPlatformSuffix},
|
||||
ext_modules=cythonize(Extension("simple_kalman_impl", ["simple_kalman_impl.pyx"])))
|
||||
@@ -0,0 +1,85 @@
|
||||
import unittest
|
||||
import random
|
||||
import timeit
|
||||
import numpy as np
|
||||
|
||||
from common.kalman.simple_kalman import KF1D
|
||||
from common.kalman.simple_kalman_old import KF1D as KF1D_old
|
||||
|
||||
|
||||
class TestSimpleKalman(unittest.TestCase):
|
||||
def setUp(self):
|
||||
dt = 0.01
|
||||
x0_0 = 0.0
|
||||
x1_0 = 0.0
|
||||
A0_0 = 1.0
|
||||
A0_1 = dt
|
||||
A1_0 = 0.0
|
||||
A1_1 = 1.0
|
||||
C0_0 = 1.0
|
||||
C0_1 = 0.0
|
||||
K0_0 = 0.12287673
|
||||
K1_0 = 0.29666309
|
||||
|
||||
self.kf_old = KF1D_old(x0=np.matrix([[x0_0], [x1_0]]),
|
||||
A=np.matrix([[A0_0, A0_1], [A1_0, A1_1]]),
|
||||
C=np.matrix([C0_0, C0_1]),
|
||||
K=np.matrix([[K0_0], [K1_0]]))
|
||||
|
||||
self.kf = KF1D(x0=[[x0_0], [x1_0]],
|
||||
A=[[A0_0, A0_1], [A1_0, A1_1]],
|
||||
C=[C0_0, C0_1],
|
||||
K=[[K0_0], [K1_0]])
|
||||
|
||||
def test_getter_setter(self):
|
||||
self.kf.x = [[1.0], [1.0]]
|
||||
self.assertEqual(self.kf.x, [[1.0], [1.0]])
|
||||
|
||||
def update_returns_state(self):
|
||||
x = self.kf.update(100)
|
||||
self.assertEqual(x, self.kf.x)
|
||||
|
||||
def test_old_equal_new(self):
|
||||
for _ in range(1000):
|
||||
v_wheel = random.uniform(0, 200)
|
||||
|
||||
x_old = self.kf_old.update(v_wheel)
|
||||
x = self.kf.update(v_wheel)
|
||||
|
||||
# Compare the output x, verify that the error is less than 1e-4
|
||||
self.assertAlmostEqual(x_old[0], x[0])
|
||||
self.assertAlmostEqual(x_old[1], x[1])
|
||||
|
||||
|
||||
def test_new_is_faster(self):
|
||||
setup = """
|
||||
import numpy as np
|
||||
|
||||
from common.kalman.simple_kalman import KF1D
|
||||
from common.kalman.simple_kalman_old import KF1D as KF1D_old
|
||||
|
||||
dt = 0.01
|
||||
x0_0 = 0.0
|
||||
x1_0 = 0.0
|
||||
A0_0 = 1.0
|
||||
A0_1 = dt
|
||||
A1_0 = 0.0
|
||||
A1_1 = 1.0
|
||||
C0_0 = 1.0
|
||||
C0_1 = 0.0
|
||||
K0_0 = 0.12287673
|
||||
K1_0 = 0.29666309
|
||||
|
||||
kf_old = KF1D_old(x0=np.matrix([[x0_0], [x1_0]]),
|
||||
A=np.matrix([[A0_0, A0_1], [A1_0, A1_1]]),
|
||||
C=np.matrix([C0_0, C0_1]),
|
||||
K=np.matrix([[K0_0], [K1_0]]))
|
||||
|
||||
kf = KF1D(x0=[[x0_0], [x1_0]],
|
||||
A=[[A0_0, A0_1], [A1_0, A1_1]],
|
||||
C=[C0_0, C0_1],
|
||||
K=[[K0_0], [K1_0]])
|
||||
"""
|
||||
kf_speed = timeit.timeit("kf.update(1234)", setup=setup, number=10000)
|
||||
kf_old_speed = timeit.timeit("kf_old.update(1234)", setup=setup, number=10000)
|
||||
self.assertTrue(kf_speed < kf_old_speed / 4)
|
||||
@@ -0,0 +1,12 @@
|
||||
class lazy_property():
|
||||
"""Defines a property whose value will be computed only once and as needed.
|
||||
|
||||
This can only be used on instance methods.
|
||||
"""
|
||||
def __init__(self, func):
|
||||
self._func = func
|
||||
|
||||
def __get__(self, obj_self, cls):
|
||||
value = self._func(obj_self)
|
||||
setattr(obj_self, self._func.__name__, value)
|
||||
return value
|
||||
@@ -0,0 +1,284 @@
|
||||
import os
|
||||
import struct
|
||||
import bisect
|
||||
import numpy as np
|
||||
import _io
|
||||
|
||||
import capnp
|
||||
from cereal import log as capnp_log
|
||||
|
||||
class RawData():
|
||||
def __init__(self, f):
|
||||
self.f = _io.FileIO(f, 'rb')
|
||||
self.lenn = struct.unpack("I", self.f.read(4))[0]
|
||||
self.count = os.path.getsize(f) / (self.lenn+4)
|
||||
|
||||
def read(self, i):
|
||||
self.f.seek((self.lenn+4)*i + 4)
|
||||
return self.f.read(self.lenn)
|
||||
|
||||
def yuv420_to_rgb(raw, image_dim=None, swizzled=False):
|
||||
def expand(x):
|
||||
x = np.repeat(x, 2, axis=0)
|
||||
return np.repeat(x, 2, axis=1)
|
||||
|
||||
if image_dim is None:
|
||||
image_dim = (raw.shape[1]*2, raw.shape[2]*2)
|
||||
swizzled = True
|
||||
|
||||
if not swizzled:
|
||||
img_data = np.array(raw, copy=False, dtype=np.uint8)
|
||||
uv_len = (image_dim[0]/2)*(image_dim[1]/2)
|
||||
img_data_u = expand(img_data[image_dim[0]*image_dim[1]: \
|
||||
image_dim[0]*image_dim[1]+uv_len]. \
|
||||
reshape(image_dim[0]/2, image_dim[1]/2))
|
||||
|
||||
img_data_v = expand(img_data[image_dim[0]*image_dim[1]+uv_len: \
|
||||
image_dim[0]*image_dim[1]+2*uv_len]. \
|
||||
reshape(image_dim[0]/2, image_dim[1]/2))
|
||||
img_data_y = img_data[0:image_dim[0]*image_dim[1]].reshape(image_dim)
|
||||
else:
|
||||
img_data_y = np.zeros(image_dim, dtype=np.uint8)
|
||||
img_data_y[0::2, 0::2] = raw[0]
|
||||
img_data_y[1::2, 0::2] = raw[1]
|
||||
img_data_y[0::2, 1::2] = raw[2]
|
||||
img_data_y[1::2, 1::2] = raw[3]
|
||||
img_data_u = expand(raw[4])
|
||||
img_data_v = expand(raw[5])
|
||||
|
||||
yuv = np.stack((img_data_y, img_data_u, img_data_v)).swapaxes(0,2).swapaxes(0,1)
|
||||
yuv = yuv.astype(np.int16)
|
||||
|
||||
# http://maxsharabayko.blogspot.com/2016/01/fast-yuv-to-rgb-conversion-in-python-3.html
|
||||
# according to ITU-R BT.709
|
||||
yuv[:,:, 0] = yuv[:,:, 0].clip(16, 235).astype(yuv.dtype) - 16
|
||||
yuv[:,:,1:] = yuv[:,:,1:].clip(16, 240).astype(yuv.dtype) - 128
|
||||
|
||||
A = np.array([[1.164, 0.000, 1.793],
|
||||
[1.164, -0.213, -0.533],
|
||||
[1.164, 2.112, 0.000]])
|
||||
|
||||
# our result
|
||||
img = np.dot(yuv, A.T).clip(0, 255).astype('uint8')
|
||||
return img
|
||||
|
||||
|
||||
class YuvData():
|
||||
def __init__(self, f, dim=(160,320)):
|
||||
self.f = _io.FileIO(f, 'rb')
|
||||
self.image_dim = dim
|
||||
self.image_size = self.image_dim[0]/2 * self.image_dim[1]/2 * 6
|
||||
self.count = os.path.getsize(f) / self.image_size
|
||||
|
||||
def read_frame(self, frame):
|
||||
self.f.seek(self.image_size*frame)
|
||||
raw = self.f.read(self.image_size)
|
||||
return raw
|
||||
|
||||
def read_frames(self, range_start, range_len):
|
||||
self.f.seek(self.image_size*range_start)
|
||||
raw = self.f.read(self.image_size*range_len)
|
||||
return raw
|
||||
|
||||
def read_frames_into(self, range_start, buf):
|
||||
self.f.seek(self.image_size*range_start)
|
||||
return self.f.readinto(buf)
|
||||
|
||||
def read(self, frame):
|
||||
return yuv420_to_rgb(self.read_frame(frame), self.image_dim)
|
||||
|
||||
def close(self):
|
||||
self.f.close()
|
||||
|
||||
def __enter__(self):
|
||||
return self
|
||||
|
||||
def __exit__(self, type, value, traceback):
|
||||
self.close()
|
||||
|
||||
|
||||
|
||||
class OneReader():
|
||||
def __init__(self, base_path, goofy=False, segment_range=None):
|
||||
self.base_path = base_path
|
||||
|
||||
route_name = os.path.basename(base_path)
|
||||
|
||||
self.rcamera_size = (304, 560)
|
||||
|
||||
if segment_range is None:
|
||||
parent_path = os.path.dirname(base_path)
|
||||
self.segment_nums = []
|
||||
for p in os.listdir(parent_path):
|
||||
if not p.startswith(route_name+"--"):
|
||||
continue
|
||||
self.segment_nums.append(int(p.rsplit("--", 1)[-1]))
|
||||
if not self.segment_nums:
|
||||
raise Exception("no route segments found")
|
||||
self.segment_nums.sort()
|
||||
self.segment_range = (self.segment_nums[0], self.segment_nums[-1])
|
||||
else:
|
||||
self.segment_range = segment_range
|
||||
self.segment_nums = range(segment_range[0], segment_range[1]+1)
|
||||
for i in self.segment_nums:
|
||||
if not os.path.exists(base_path+"--"+str(i)):
|
||||
raise Exception("missing segment in provided range")
|
||||
|
||||
# goofy data is broken with discontinuous logs
|
||||
if goofy and (self.segment_range[0] != 0
|
||||
or self.segment_nums != range(self.segment_range[0], self.segment_range[1]+1)):
|
||||
raise Exception("goofy data needs all the segments for a route")
|
||||
|
||||
self.cur_seg = None
|
||||
self.cur_seg_f = None
|
||||
|
||||
# index the frames
|
||||
print("indexing frames {}...".format(self.segment_nums))
|
||||
|
||||
self.rcamera_encode_map = {} # frame_id -> (segment num, segment id, frame_time)
|
||||
last_frame_id = -1
|
||||
|
||||
if goofy:
|
||||
# goofy is goofy
|
||||
|
||||
frame_size = self.rcamera_size[0]*self.rcamera_size[1]*3/2
|
||||
|
||||
# find the encode id ranges for each segment by using the rcamera file size
|
||||
segment_encode_ids = []
|
||||
cur_encode_id = 0
|
||||
for n in self.segment_nums:
|
||||
camera_path = os.path.join(self.seg_path(n), "rcamera")
|
||||
if not os.path.exists(camera_path):
|
||||
# for goofy, missing camera files means a bad route
|
||||
raise Exception("Missing camera file {}".format(camera_path))
|
||||
camera_size = os.path.getsize(camera_path)
|
||||
assert (camera_size % frame_size) == 0
|
||||
|
||||
num_frames = camera_size / frame_size
|
||||
segment_encode_ids.append(cur_encode_id)
|
||||
cur_encode_id += num_frames
|
||||
|
||||
last_encode_id = -1
|
||||
# use the segment encode id map and frame events to build the frame index
|
||||
for n in self.segment_nums:
|
||||
log_path = os.path.join(self.seg_path(n), "rlog")
|
||||
if os.path.exists(log_path):
|
||||
with open(log_path, "rb") as f:
|
||||
for evt in capnp_log.Event.read_multiple(f):
|
||||
if evt.which() == 'frame':
|
||||
|
||||
if evt.frame.frameId < last_frame_id:
|
||||
# a non-increasing frame id is bad route (eg visiond was restarted)
|
||||
raise Exception("non-increasing frame id")
|
||||
last_frame_id = evt.frame.frameId
|
||||
|
||||
seg_i = bisect.bisect_right(segment_encode_ids, evt.frame.encodeId)-1
|
||||
assert seg_i >= 0
|
||||
seg_num = self.segment_nums[seg_i]
|
||||
seg_id = evt.frame.encodeId-segment_encode_ids[seg_i]
|
||||
frame_time = evt.logMonoTime / 1.0e9
|
||||
|
||||
self.rcamera_encode_map[evt.frame.frameId] = (seg_num, seg_id,
|
||||
frame_time)
|
||||
|
||||
last_encode_id = evt.frame.encodeId
|
||||
|
||||
if last_encode_id-cur_encode_id > 10:
|
||||
# too many missing frames is a bad route (eg route from before encoder rotating worked)
|
||||
raise Exception("goofy route is missing frames: {}, {}".format(
|
||||
last_encode_id, cur_encode_id))
|
||||
|
||||
else:
|
||||
# for harry data, build the index from encodeIdx events
|
||||
for n in self.segment_nums:
|
||||
log_path = os.path.join(self.seg_path(n), "rlog")
|
||||
if os.path.exists(log_path):
|
||||
with open(log_path, "rb") as f:
|
||||
for evt in capnp_log.Event.read_multiple(f):
|
||||
if evt.which() == 'encodeIdx' and evt.encodeIdx.type == 'bigBoxLossless':
|
||||
frame_time = evt.logMonoTime / 1.0e9
|
||||
self.rcamera_encode_map[evt.encodeIdx.frameId] = (
|
||||
evt.encodeIdx.segmentNum, evt.encodeIdx.segmentId,
|
||||
frame_time)
|
||||
|
||||
print("done")
|
||||
|
||||
# read the first event to find the start time
|
||||
self.reset_to_seg(self.segment_range[0])
|
||||
for evt in self.events():
|
||||
if evt.which() != 'initData':
|
||||
self.start_mono = evt.logMonoTime
|
||||
break
|
||||
self.reset_to_seg(self.segment_range[0])
|
||||
|
||||
|
||||
def seg_path(self, num):
|
||||
return self.base_path+"--"+str(num)
|
||||
|
||||
def reset_to_seg(self, seg):
|
||||
self.cur_seg = seg
|
||||
if self.cur_seg_f:
|
||||
self.cur_seg_f.close()
|
||||
self.cur_seg_f = None
|
||||
|
||||
def seek_ts(self, ts):
|
||||
seek_seg = int(ts/60)
|
||||
if seek_seg < self.segment_range[0] or seek_seg > self.segment_range[1]:
|
||||
raise ValueError
|
||||
|
||||
self.reset_to_seg(seek_seg)
|
||||
target_mono = self.start_mono + int(ts*1e9)
|
||||
for evt in self.events():
|
||||
if evt.logMonoTime >= target_mono:
|
||||
break
|
||||
|
||||
def read_event(self):
|
||||
while True:
|
||||
if self.cur_seg > self.segment_range[1]:
|
||||
return None
|
||||
if self.cur_seg_f is None:
|
||||
log_path = os.path.join(self.seg_path(self.cur_seg), "rlog")
|
||||
if not os.path.exists(log_path):
|
||||
print("missing log file!", log_path)
|
||||
self.cur_seg += 1
|
||||
continue
|
||||
self.cur_seg_f = open(log_path, "rb")
|
||||
|
||||
try:
|
||||
return capnp_log.Event.read(self.cur_seg_f)
|
||||
except capnp.lib.capnp.KjException as e:
|
||||
if 'EOF' in str(e): # dumb, but pycapnp does this too
|
||||
self.cur_seg_f.close()
|
||||
self.cur_seg_f = None
|
||||
self.cur_seg += 1
|
||||
else:
|
||||
raise
|
||||
|
||||
def events(self):
|
||||
while True:
|
||||
r = self.read_event()
|
||||
if r is None:
|
||||
break
|
||||
yield r
|
||||
|
||||
def read_frame(self, frame_id):
|
||||
encode_idx = self.rcamera_encode_map.get(frame_id)
|
||||
if encode_idx is None:
|
||||
return None
|
||||
|
||||
seg_num, seg_id, _ = encode_idx
|
||||
camera_path = os.path.join(self.seg_path(seg_num), "rcamera")
|
||||
if not os.path.exists(camera_path):
|
||||
return None
|
||||
with YuvData(camera_path, self.rcamera_size) as data:
|
||||
return data.read_frame(seg_id)
|
||||
|
||||
def close(self):
|
||||
if self.cur_seg_f is not None:
|
||||
self.cur_seg_f.close()
|
||||
|
||||
def __enter__(self):
|
||||
return self
|
||||
|
||||
def __exit__(self, type, value, traceback):
|
||||
self.close()
|
||||
@@ -0,0 +1,92 @@
|
||||
import sys
|
||||
import json
|
||||
# pip2 install msgpack-python
|
||||
import msgpack
|
||||
import zlib
|
||||
import os
|
||||
import logging
|
||||
|
||||
from Crypto.Cipher import AES
|
||||
|
||||
ext = ".gz"
|
||||
SWAG = '\xde\xe2\x11\x15VVC\xf2\x8ep\xd7\xe4\x87\x8d,9'
|
||||
|
||||
def compress_json(in_file, out_file):
|
||||
logging.debug("compressing %s -> %s", in_file, out_file)
|
||||
|
||||
errors = 0
|
||||
|
||||
good = []
|
||||
last_can_time = 0
|
||||
with open(in_file, 'r') as inf:
|
||||
for ln in inf:
|
||||
ln = ln.rstrip()
|
||||
if not ln: continue
|
||||
try:
|
||||
ll = json.loads(ln)
|
||||
except ValueError:
|
||||
errors += 1
|
||||
continue
|
||||
if ll is None or ll[0] is None:
|
||||
continue
|
||||
if ll[0][1] == 1:
|
||||
# no CAN in hex
|
||||
ll[1][2] = ll[1][2].decode("hex")
|
||||
# relativize the CAN timestamps
|
||||
this_can_time = ll[1][1]
|
||||
ll[1] = [ll[1][0], this_can_time - last_can_time, ll[1][2]]
|
||||
last_can_time = this_can_time
|
||||
good.append(ll)
|
||||
|
||||
logging.debug("compressing %s -> %s, read done", in_file, out_file)
|
||||
data = msgpack.packb(good)
|
||||
data_compressed = zlib.compress(data)
|
||||
# zlib doesn't care about this
|
||||
data_compressed += "\x00" * (16 - len(data_compressed)%16)
|
||||
aes = AES.new(SWAG, AES.MODE_CBC, "\x00"*16)
|
||||
data_encrypted = aes.encrypt(data_compressed)
|
||||
with open(out_file, "wb") as outf:
|
||||
outf.write(data_encrypted)
|
||||
|
||||
logging.debug("compressing %s -> %s, write done", in_file, out_file)
|
||||
|
||||
return errors
|
||||
|
||||
def decompress_json_internal(data_encrypted):
|
||||
aes = AES.new(SWAG, AES.MODE_CBC, "\x00"*16)
|
||||
data_compressed = aes.decrypt(data_encrypted)
|
||||
data = zlib.decompress(data_compressed)
|
||||
msgs = msgpack.unpackb(data)
|
||||
good = []
|
||||
last_can_time = 0
|
||||
for ll in msgs:
|
||||
if ll[0][1] == 1:
|
||||
# back into hex
|
||||
ll[1][2] = ll[1][2].encode("hex")
|
||||
# derelativize CAN timestamps
|
||||
last_can_time += ll[1][1]
|
||||
ll[1] = [ll[1][0], last_can_time, ll[1][2]]
|
||||
good.append(ll)
|
||||
return good
|
||||
|
||||
def decompress_json(in_file, out_file):
|
||||
logging.debug("decompressing %s -> %s", in_file, out_file)
|
||||
f = open(in_file)
|
||||
data_encrypted = f.read()
|
||||
f.close()
|
||||
|
||||
good = decompress_json_internal(data_encrypted)
|
||||
out = '\n'.join(map(lambda x: json.dumps(x), good)) + "\n"
|
||||
logging.debug("decompressing %s -> %s, writing", in_file, out_file)
|
||||
f = open(out_file, 'w')
|
||||
f.write(out)
|
||||
f.close()
|
||||
logging.debug("decompressing %s -> %s, write finished", in_file, out_file)
|
||||
|
||||
if __name__ == "__main__":
|
||||
for dat in sys.argv[1:]:
|
||||
print(dat)
|
||||
compress_json(dat, "/tmp/out"+ext)
|
||||
decompress_json("/tmp/out"+ext, "/tmp/test")
|
||||
os.system("diff "+dat+" /tmp/test")
|
||||
|
||||
@@ -0,0 +1,190 @@
|
||||
import io
|
||||
import os
|
||||
import sys
|
||||
import copy
|
||||
import json
|
||||
import socket
|
||||
import logging
|
||||
import traceback
|
||||
from threading import local
|
||||
from collections import OrderedDict
|
||||
from contextlib import contextmanager
|
||||
|
||||
def json_handler(obj):
|
||||
# if isinstance(obj, (datetime.date, datetime.time)):
|
||||
# return obj.isoformat()
|
||||
return repr(obj)
|
||||
|
||||
def json_robust_dumps(obj):
|
||||
return json.dumps(obj, default=json_handler)
|
||||
|
||||
class NiceOrderedDict(OrderedDict):
|
||||
def __str__(self):
|
||||
return json_robust_dumps(self)
|
||||
|
||||
class SwagFormatter(logging.Formatter):
|
||||
def __init__(self, swaglogger):
|
||||
logging.Formatter.__init__(self, None, '%a %b %d %H:%M:%S %Z %Y')
|
||||
|
||||
self.swaglogger = swaglogger
|
||||
self.host = socket.gethostname()
|
||||
|
||||
def format_dict(self, record):
|
||||
record_dict = NiceOrderedDict()
|
||||
|
||||
if isinstance(record.msg, dict):
|
||||
record_dict['msg'] = record.msg
|
||||
else:
|
||||
try:
|
||||
record_dict['msg'] = record.getMessage()
|
||||
except (ValueError, TypeError):
|
||||
record_dict['msg'] = [record.msg]+record.args
|
||||
|
||||
record_dict['ctx'] = self.swaglogger.get_ctx()
|
||||
|
||||
if record.exc_info:
|
||||
record_dict['exc_info'] = self.formatException(record.exc_info)
|
||||
|
||||
record_dict['level'] = record.levelname
|
||||
record_dict['levelnum'] = record.levelno
|
||||
record_dict['name'] = record.name
|
||||
record_dict['filename'] = record.filename
|
||||
record_dict['lineno'] = record.lineno
|
||||
record_dict['pathname'] = record.pathname
|
||||
record_dict['module'] = record.module
|
||||
record_dict['funcName'] = record.funcName
|
||||
record_dict['host'] = self.host
|
||||
record_dict['process'] = record.process
|
||||
record_dict['thread'] = record.thread
|
||||
record_dict['threadName'] = record.threadName
|
||||
record_dict['created'] = record.created
|
||||
|
||||
return record_dict
|
||||
|
||||
def format(self, record):
|
||||
return json_robust_dumps(self.format_dict(record))
|
||||
|
||||
class SwagErrorFilter(logging.Filter):
|
||||
def filter(self, record):
|
||||
return record.levelno < logging.ERROR
|
||||
|
||||
_tmpfunc = lambda: 0
|
||||
_srcfile = os.path.normcase(_tmpfunc.__code__.co_filename)
|
||||
|
||||
class SwagLogger(logging.Logger):
|
||||
def __init__(self):
|
||||
logging.Logger.__init__(self, "swaglog")
|
||||
|
||||
self.global_ctx = {}
|
||||
|
||||
self.log_local = local()
|
||||
self.log_local.ctx = {}
|
||||
|
||||
def local_ctx(self):
|
||||
try:
|
||||
return self.log_local.ctx
|
||||
except AttributeError:
|
||||
self.log_local.ctx = {}
|
||||
return self.log_local.ctx
|
||||
|
||||
def get_ctx(self):
|
||||
return dict(self.local_ctx(), **self.global_ctx)
|
||||
|
||||
@contextmanager
|
||||
def ctx(self, **kwargs):
|
||||
old_ctx = self.local_ctx()
|
||||
self.log_local.ctx = copy.copy(old_ctx) or {}
|
||||
self.log_local.ctx.update(kwargs)
|
||||
try:
|
||||
yield
|
||||
finally:
|
||||
self.log_local.ctx = old_ctx
|
||||
|
||||
def bind(self, **kwargs):
|
||||
self.local_ctx().update(kwargs)
|
||||
|
||||
def bind_global(self, **kwargs):
|
||||
self.global_ctx.update(kwargs)
|
||||
|
||||
def event(self, event_name, *args, **kwargs):
|
||||
evt = NiceOrderedDict()
|
||||
evt['event'] = event_name
|
||||
if args:
|
||||
evt['args'] = args
|
||||
evt.update(kwargs)
|
||||
ctx = self.get_ctx()
|
||||
if ctx:
|
||||
evt['ctx'] = self.get_ctx()
|
||||
if 'error' in kwargs:
|
||||
self.error(evt)
|
||||
else:
|
||||
self.info(evt)
|
||||
|
||||
def findCaller(self, stack_info=False, stacklevel=1):
|
||||
"""
|
||||
Find the stack frame of the caller so that we can note the source
|
||||
file name, line number and function name.
|
||||
"""
|
||||
f = sys._getframe(3)
|
||||
#On some versions of IronPython, currentframe() returns None if
|
||||
#IronPython isn't run with -X:Frames.
|
||||
if f is not None:
|
||||
f = f.f_back
|
||||
orig_f = f
|
||||
while f and stacklevel > 1:
|
||||
f = f.f_back
|
||||
stacklevel -= 1
|
||||
if not f:
|
||||
f = orig_f
|
||||
rv = "(unknown file)", 0, "(unknown function)", None
|
||||
while hasattr(f, "f_code"):
|
||||
co = f.f_code
|
||||
filename = os.path.normcase(co.co_filename)
|
||||
if filename == _srcfile:
|
||||
f = f.f_back
|
||||
continue
|
||||
sinfo = None
|
||||
if stack_info:
|
||||
sio = io.StringIO()
|
||||
sio.write('Stack (most recent call last):\n')
|
||||
traceback.print_stack(f, file=sio)
|
||||
sinfo = sio.getvalue()
|
||||
if sinfo[-1] == '\n':
|
||||
sinfo = sinfo[:-1]
|
||||
sio.close()
|
||||
rv = (co.co_filename, f.f_lineno, co.co_name, sinfo)
|
||||
break
|
||||
return rv
|
||||
|
||||
if __name__ == "__main__":
|
||||
log = SwagLogger()
|
||||
|
||||
stdout_handler = logging.StreamHandler(sys.stdout)
|
||||
stdout_handler.setLevel(logging.INFO)
|
||||
stdout_handler.addFilter(SwagErrorFilter())
|
||||
log.addHandler(stdout_handler)
|
||||
|
||||
stderr_handler = logging.StreamHandler(sys.stderr)
|
||||
stderr_handler.setLevel(logging.ERROR)
|
||||
log.addHandler(stderr_handler)
|
||||
|
||||
log.info("asdasd %s", "a")
|
||||
log.info({'wut': 1})
|
||||
log.warning("warning")
|
||||
log.error("error")
|
||||
log.critical("critical")
|
||||
log.event("test", x="y")
|
||||
|
||||
with log.ctx():
|
||||
stdout_handler.setFormatter(SwagFormatter(log))
|
||||
stderr_handler.setFormatter(SwagFormatter(log))
|
||||
log.bind(user="some user")
|
||||
log.info("in req")
|
||||
print("")
|
||||
log.warning("warning")
|
||||
print("")
|
||||
log.error("error")
|
||||
print("")
|
||||
log.critical("critical")
|
||||
print("")
|
||||
log.event("do_req", a=1, b="c")
|
||||
@@ -0,0 +1,21 @@
|
||||
def int_rnd(x):
|
||||
return int(round(x))
|
||||
|
||||
def clip(x, lo, hi):
|
||||
return max(lo, min(hi, x))
|
||||
|
||||
def interp(x, xp, fp):
|
||||
N = len(xp)
|
||||
def get_interp(xv):
|
||||
hi = 0
|
||||
while hi < N and xv > xp[hi]:
|
||||
hi += 1
|
||||
low = hi - 1
|
||||
return fp[-1] if hi == N and xv > xp[low] else (
|
||||
fp[0] if hi == 0 else
|
||||
(xv - xp[low]) * (fp[hi] - fp[low]) / (xp[hi] - xp[low]) + fp[low])
|
||||
return [get_interp(v) for v in x] if hasattr(
|
||||
x, '__iter__') else get_interp(x)
|
||||
|
||||
def mean(x):
|
||||
return sum(x) / len(x)
|
||||
@@ -0,0 +1,66 @@
|
||||
import bisect
|
||||
import numpy as np
|
||||
from scipy.interpolate import interp1d
|
||||
|
||||
|
||||
def deep_interp_0_fast(dx, x, y):
|
||||
FIX = False
|
||||
if len(y.shape) == 1:
|
||||
y = y[:, None]
|
||||
FIX = True
|
||||
ret = np.zeros((dx.shape[0], y.shape[1]))
|
||||
index = list(x)
|
||||
for i in range(dx.shape[0]):
|
||||
idx = bisect.bisect_left(index, dx[i])
|
||||
if idx == x.shape[0]:
|
||||
idx = x.shape[0] - 1
|
||||
ret[i] = y[idx]
|
||||
|
||||
if FIX:
|
||||
return ret[:, 0]
|
||||
else:
|
||||
return ret
|
||||
|
||||
|
||||
def running_mean(x, N):
|
||||
cumsum = np.cumsum(np.insert(x, [0]*(int(N/2)) + [-1]*(N-int(N/2)), [x[0]]*int(N/2) + [x[-1]]*(N-int(N/2))))
|
||||
return (cumsum[N:] - cumsum[:-N]) / N
|
||||
|
||||
|
||||
def deep_interp_np(x, xp, fp):
|
||||
x = np.atleast_1d(x)
|
||||
xp = np.array(xp)
|
||||
if len(xp) < 2:
|
||||
return np.repeat(fp, len(x), axis=0)
|
||||
if min(np.diff(xp)) < 0:
|
||||
raise RuntimeError('Bad x array for interpolation')
|
||||
j = np.searchsorted(xp, x) - 1
|
||||
j = np.clip(j, 0, len(xp)-2)
|
||||
d = np.divide(x - xp[j], xp[j + 1] - xp[j], out=np.ones_like(x, dtype=np.float64), where=xp[j + 1] - xp[j] != 0)
|
||||
vals_interp = (fp[j].T*(1 - d)).T + (fp[j + 1].T*d).T
|
||||
if len(vals_interp) == 1:
|
||||
return vals_interp[0]
|
||||
else:
|
||||
return vals_interp
|
||||
|
||||
|
||||
def clipping_deep_interp(x, xp, fp):
|
||||
if len(xp) < 2:
|
||||
return deep_interp_np(x, xp, fp)
|
||||
bad_idx = np.where(np.diff(xp) < 0)[0]
|
||||
if len(bad_idx) > 0:
|
||||
if bad_idx[0] ==1:
|
||||
return np.zeros([] + list(fp.shape[1:]))
|
||||
return deep_interp_np(x, xp[:bad_idx[0]], fp[:bad_idx[0]])
|
||||
else:
|
||||
return deep_interp_np(x, xp, fp)
|
||||
|
||||
|
||||
def deep_interp(dx, x, y, kind="slinear"):
|
||||
return interp1d(
|
||||
x, y,
|
||||
axis=0,
|
||||
kind=kind,
|
||||
bounds_error=False,
|
||||
fill_value="extrapolate",
|
||||
assume_sorted=True)(dx)
|
||||
Executable
+415
@@ -0,0 +1,415 @@
|
||||
#!/usr/bin/env python3
|
||||
"""ROS has a parameter server, we have files.
|
||||
|
||||
The parameter store is a persistent key value store, implemented as a directory with a writer lock.
|
||||
On Android, we store params under params_dir = /data/params. The writer lock is a file
|
||||
"<params_dir>/.lock" taken using flock(), and data is stored in a directory symlinked to by
|
||||
"<params_dir>/d".
|
||||
|
||||
Each key, value pair is stored as a file with named <key> with contents <value>, located in
|
||||
<params_dir>/d/<key>
|
||||
|
||||
Readers of a single key can just open("<params_dir>/d/<key>") and read the file contents.
|
||||
Readers who want a consistent snapshot of multiple keys should take the lock.
|
||||
|
||||
Writers should take the lock before modifying anything. Writers should also leave the DB in a
|
||||
consistent state after a crash. The implementation below does this by copying all params to a temp
|
||||
directory <params_dir>/<tmp>, then atomically symlinking <params_dir>/<d> to <params_dir>/<tmp>
|
||||
before deleting the old <params_dir>/<d> directory.
|
||||
|
||||
Writers that only modify a single key can simply take the lock, then swap the corresponding value
|
||||
file in place without messing with <params_dir>/d.
|
||||
"""
|
||||
import time
|
||||
import os
|
||||
import errno
|
||||
import sys
|
||||
import shutil
|
||||
import fcntl
|
||||
import tempfile
|
||||
import threading
|
||||
from enum import Enum
|
||||
from common.basedir import PARAMS
|
||||
|
||||
def mkdirs_exists_ok(path):
|
||||
try:
|
||||
os.makedirs(path)
|
||||
except OSError:
|
||||
if not os.path.isdir(path):
|
||||
raise
|
||||
|
||||
|
||||
class TxType(Enum):
|
||||
PERSISTENT = 1
|
||||
CLEAR_ON_MANAGER_START = 2
|
||||
CLEAR_ON_PANDA_DISCONNECT = 3
|
||||
|
||||
|
||||
class UnknownKeyName(Exception):
|
||||
pass
|
||||
|
||||
|
||||
keys = {
|
||||
"AccessToken": [TxType.PERSISTENT],
|
||||
"AthenadPid": [TxType.PERSISTENT],
|
||||
"CalibrationParams": [TxType.PERSISTENT],
|
||||
"CarParams": [TxType.CLEAR_ON_MANAGER_START, TxType.CLEAR_ON_PANDA_DISCONNECT],
|
||||
"CarParamsCache": [TxType.CLEAR_ON_MANAGER_START, TxType.CLEAR_ON_PANDA_DISCONNECT],
|
||||
"CarVin": [TxType.CLEAR_ON_MANAGER_START, TxType.CLEAR_ON_PANDA_DISCONNECT],
|
||||
"CommunityFeaturesToggle": [TxType.PERSISTENT],
|
||||
"CompletedTrainingVersion": [TxType.PERSISTENT],
|
||||
"ControlsParams": [TxType.PERSISTENT],
|
||||
"DoUninstall": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"DongleId": [TxType.PERSISTENT],
|
||||
"GitBranch": [TxType.PERSISTENT],
|
||||
"GitCommit": [TxType.PERSISTENT],
|
||||
"GitRemote": [TxType.PERSISTENT],
|
||||
"GithubSshKeys": [TxType.PERSISTENT],
|
||||
"HasAcceptedTerms": [TxType.PERSISTENT],
|
||||
"HasCompletedSetup": [TxType.PERSISTENT],
|
||||
"IsLdwEnabled": [TxType.PERSISTENT],
|
||||
"IsGeofenceEnabled": [TxType.PERSISTENT],
|
||||
"IsMetric": [TxType.PERSISTENT],
|
||||
"IsOffroad": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"IsRHD": [TxType.PERSISTENT],
|
||||
"IsTakingSnapshot": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"IsUpdateAvailable": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"IsUploadRawEnabled": [TxType.PERSISTENT],
|
||||
"LastUpdateTime": [TxType.PERSISTENT],
|
||||
"LimitSetSpeed": [TxType.PERSISTENT],
|
||||
"LimitSetSpeedNeural": [TxType.PERSISTENT],
|
||||
"LiveParameters": [TxType.PERSISTENT],
|
||||
"LongitudinalControl": [TxType.PERSISTENT],
|
||||
"OpenpilotEnabledToggle": [TxType.PERSISTENT],
|
||||
"PandaFirmware": [TxType.CLEAR_ON_MANAGER_START, TxType.CLEAR_ON_PANDA_DISCONNECT],
|
||||
"PandaFirmwareHex": [TxType.CLEAR_ON_MANAGER_START, TxType.CLEAR_ON_PANDA_DISCONNECT],
|
||||
"PandaDongleId": [TxType.CLEAR_ON_MANAGER_START, TxType.CLEAR_ON_PANDA_DISCONNECT],
|
||||
"Passive": [TxType.PERSISTENT],
|
||||
"RecordFront": [TxType.PERSISTENT],
|
||||
"ReleaseNotes": [TxType.PERSISTENT],
|
||||
"ShouldDoUpdate": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"SpeedLimitOffset": [TxType.PERSISTENT],
|
||||
"SubscriberInfo": [TxType.PERSISTENT],
|
||||
"TermsVersion": [TxType.PERSISTENT],
|
||||
"TrainingVersion": [TxType.PERSISTENT],
|
||||
"UpdateAvailable": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"Version": [TxType.PERSISTENT],
|
||||
"Offroad_ChargeDisabled": [TxType.CLEAR_ON_MANAGER_START, TxType.CLEAR_ON_PANDA_DISCONNECT],
|
||||
"Offroad_ConnectivityNeeded": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"Offroad_ConnectivityNeededPrompt": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"Offroad_TemperatureTooHigh": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"Offroad_PandaFirmwareMismatch": [TxType.CLEAR_ON_MANAGER_START, TxType.CLEAR_ON_PANDA_DISCONNECT],
|
||||
"Offroad_InvalidTime": [TxType.CLEAR_ON_MANAGER_START],
|
||||
"Offroad_IsTakingSnapshot": [TxType.CLEAR_ON_MANAGER_START],
|
||||
}
|
||||
|
||||
|
||||
def fsync_dir(path):
|
||||
fd = os.open(path, os.O_RDONLY)
|
||||
try:
|
||||
os.fsync(fd)
|
||||
finally:
|
||||
os.close(fd)
|
||||
|
||||
|
||||
class FileLock():
|
||||
def __init__(self, path, create):
|
||||
self._path = path
|
||||
self._create = create
|
||||
self._fd = None
|
||||
|
||||
def acquire(self):
|
||||
self._fd = os.open(self._path, os.O_CREAT if self._create else 0)
|
||||
fcntl.flock(self._fd, fcntl.LOCK_EX)
|
||||
|
||||
def release(self):
|
||||
if self._fd is not None:
|
||||
os.close(self._fd)
|
||||
self._fd = None
|
||||
|
||||
|
||||
class DBAccessor():
|
||||
def __init__(self, path):
|
||||
self._path = path
|
||||
self._vals = None
|
||||
|
||||
def keys(self):
|
||||
self._check_entered()
|
||||
return self._vals.keys()
|
||||
|
||||
def get(self, key):
|
||||
self._check_entered()
|
||||
try:
|
||||
return self._vals[key]
|
||||
except KeyError:
|
||||
return None
|
||||
|
||||
def _get_lock(self, create):
|
||||
lock = FileLock(os.path.join(self._path, ".lock"), create)
|
||||
lock.acquire()
|
||||
return lock
|
||||
|
||||
def _read_values_locked(self):
|
||||
"""Callers should hold a lock while calling this method."""
|
||||
vals = {}
|
||||
try:
|
||||
data_path = self._data_path()
|
||||
keys = os.listdir(data_path)
|
||||
for key in keys:
|
||||
with open(os.path.join(data_path, key), "rb") as f:
|
||||
vals[key] = f.read()
|
||||
except (OSError, IOError) as e:
|
||||
# Either the DB hasn't been created yet, or somebody wrote a bug and left the DB in an
|
||||
# inconsistent state. Either way, return empty.
|
||||
if e.errno == errno.ENOENT:
|
||||
return {}
|
||||
|
||||
return vals
|
||||
|
||||
def _data_path(self):
|
||||
return os.path.join(self._path, "d")
|
||||
|
||||
def _check_entered(self):
|
||||
if self._vals is None:
|
||||
raise Exception("Must call __enter__ before using DB")
|
||||
|
||||
|
||||
class DBReader(DBAccessor):
|
||||
def __enter__(self):
|
||||
try:
|
||||
lock = self._get_lock(False)
|
||||
except OSError as e:
|
||||
# Do not create lock if it does not exist.
|
||||
if e.errno == errno.ENOENT:
|
||||
self._vals = {}
|
||||
return self
|
||||
|
||||
try:
|
||||
# Read everything.
|
||||
self._vals = self._read_values_locked()
|
||||
return self
|
||||
finally:
|
||||
lock.release()
|
||||
|
||||
def __exit__(self, type, value, traceback): pass
|
||||
|
||||
|
||||
class DBWriter(DBAccessor):
|
||||
def __init__(self, path):
|
||||
super(DBWriter, self).__init__(path)
|
||||
self._lock = None
|
||||
self._prev_umask = None
|
||||
|
||||
def put(self, key, value):
|
||||
self._vals[key] = value
|
||||
|
||||
def delete(self, key):
|
||||
self._vals.pop(key, None)
|
||||
|
||||
def __enter__(self):
|
||||
mkdirs_exists_ok(self._path)
|
||||
|
||||
# Make sure we can write and that permissions are correct.
|
||||
self._prev_umask = os.umask(0)
|
||||
|
||||
try:
|
||||
os.chmod(self._path, 0o777)
|
||||
self._lock = self._get_lock(True)
|
||||
self._vals = self._read_values_locked()
|
||||
except:
|
||||
os.umask(self._prev_umask)
|
||||
self._prev_umask = None
|
||||
raise
|
||||
|
||||
return self
|
||||
|
||||
def __exit__(self, type, value, traceback):
|
||||
self._check_entered()
|
||||
|
||||
try:
|
||||
# data_path refers to the externally used path to the params. It is a symlink.
|
||||
# old_data_path is the path currently pointed to by data_path.
|
||||
# tempdir_path is a path where the new params will go, which the new data path will point to.
|
||||
# new_data_path is a temporary symlink that will atomically overwrite data_path.
|
||||
#
|
||||
# The current situation is:
|
||||
# data_path -> old_data_path
|
||||
# We're going to write params data to tempdir_path
|
||||
# tempdir_path -> params data
|
||||
# Then point new_data_path to tempdir_path
|
||||
# new_data_path -> tempdir_path
|
||||
# Then atomically overwrite data_path with new_data_path
|
||||
# data_path -> tempdir_path
|
||||
old_data_path = None
|
||||
new_data_path = None
|
||||
tempdir_path = tempfile.mkdtemp(prefix=".tmp", dir=self._path)
|
||||
|
||||
try:
|
||||
# Write back all keys.
|
||||
os.chmod(tempdir_path, 0o777)
|
||||
for k, v in self._vals.items():
|
||||
with open(os.path.join(tempdir_path, k), "wb") as f:
|
||||
f.write(v)
|
||||
f.flush()
|
||||
os.fsync(f.fileno())
|
||||
fsync_dir(tempdir_path)
|
||||
|
||||
data_path = self._data_path()
|
||||
try:
|
||||
old_data_path = os.path.join(self._path, os.readlink(data_path))
|
||||
except (OSError, IOError):
|
||||
# NOTE(mgraczyk): If other DB implementations have bugs, this could cause
|
||||
# copies to be left behind, but we still want to overwrite.
|
||||
pass
|
||||
|
||||
new_data_path = "{}.link".format(tempdir_path)
|
||||
os.symlink(os.path.basename(tempdir_path), new_data_path)
|
||||
os.rename(new_data_path, data_path)
|
||||
fsync_dir(self._path)
|
||||
finally:
|
||||
# If the rename worked, we can delete the old data. Otherwise delete the new one.
|
||||
success = new_data_path is not None and os.path.exists(data_path) and (
|
||||
os.readlink(data_path) == os.path.basename(tempdir_path))
|
||||
|
||||
if success:
|
||||
if old_data_path is not None:
|
||||
shutil.rmtree(old_data_path)
|
||||
else:
|
||||
shutil.rmtree(tempdir_path)
|
||||
|
||||
# Regardless of what happened above, there should be no link at new_data_path.
|
||||
if new_data_path is not None and os.path.islink(new_data_path):
|
||||
os.remove(new_data_path)
|
||||
finally:
|
||||
os.umask(self._prev_umask)
|
||||
self._prev_umask = None
|
||||
|
||||
# Always release the lock.
|
||||
self._lock.release()
|
||||
self._lock = None
|
||||
|
||||
|
||||
def read_db(params_path, key):
|
||||
path = "%s/d/%s" % (params_path, key)
|
||||
try:
|
||||
with open(path, "rb") as f:
|
||||
return f.read()
|
||||
except IOError:
|
||||
return None
|
||||
|
||||
def write_db(params_path, key, value):
|
||||
if isinstance(value, str):
|
||||
value = value.encode('utf8')
|
||||
|
||||
prev_umask = os.umask(0)
|
||||
lock = FileLock(params_path+"/.lock", True)
|
||||
lock.acquire()
|
||||
|
||||
try:
|
||||
tmp_path = tempfile.mktemp(prefix=".tmp", dir=params_path)
|
||||
with open(tmp_path, "wb") as f:
|
||||
f.write(value)
|
||||
f.flush()
|
||||
os.fsync(f.fileno())
|
||||
|
||||
path = "%s/d/%s" % (params_path, key)
|
||||
os.rename(tmp_path, path)
|
||||
fsync_dir(os.path.dirname(path))
|
||||
finally:
|
||||
os.umask(prev_umask)
|
||||
lock.release()
|
||||
|
||||
class Params():
|
||||
def __init__(self, db=PARAMS):
|
||||
self.db = db
|
||||
|
||||
# create the database if it doesn't exist...
|
||||
if not os.path.exists(self.db+"/d"):
|
||||
with self.transaction(write=True):
|
||||
pass
|
||||
|
||||
def clear_all(self):
|
||||
shutil.rmtree(self.db, ignore_errors=True)
|
||||
with self.transaction(write=True):
|
||||
pass
|
||||
|
||||
def transaction(self, write=False):
|
||||
if write:
|
||||
return DBWriter(self.db)
|
||||
else:
|
||||
return DBReader(self.db)
|
||||
|
||||
def _clear_keys_with_type(self, tx_type):
|
||||
with self.transaction(write=True) as txn:
|
||||
for key in keys:
|
||||
if tx_type in keys[key]:
|
||||
txn.delete(key)
|
||||
|
||||
def manager_start(self):
|
||||
self._clear_keys_with_type(TxType.CLEAR_ON_MANAGER_START)
|
||||
|
||||
def panda_disconnect(self):
|
||||
self._clear_keys_with_type(TxType.CLEAR_ON_PANDA_DISCONNECT)
|
||||
|
||||
def delete(self, key):
|
||||
with self.transaction(write=True) as txn:
|
||||
txn.delete(key)
|
||||
|
||||
def get(self, key, block=False, encoding=None):
|
||||
if key not in keys:
|
||||
raise UnknownKeyName(key)
|
||||
|
||||
while 1:
|
||||
ret = read_db(self.db, key)
|
||||
if not block or ret is not None:
|
||||
break
|
||||
# is polling really the best we can do?
|
||||
time.sleep(0.05)
|
||||
|
||||
if ret is not None and encoding is not None:
|
||||
ret = ret.decode(encoding)
|
||||
|
||||
return ret
|
||||
|
||||
def put(self, key, dat):
|
||||
"""
|
||||
Warning: This function blocks until the param is written to disk!
|
||||
In very rare cases this can take over a second, and your code will hang.
|
||||
|
||||
Use the put_nonblocking helper function in time sensitive code, but
|
||||
in general try to avoid writing params as much as possible.
|
||||
"""
|
||||
|
||||
if key not in keys:
|
||||
raise UnknownKeyName(key)
|
||||
|
||||
write_db(self.db, key, dat)
|
||||
|
||||
|
||||
def put_nonblocking(key, val):
|
||||
def f(key, val):
|
||||
params = Params()
|
||||
params.put(key, val)
|
||||
|
||||
t = threading.Thread(target=f, args=(key, val))
|
||||
t.start()
|
||||
return t
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
params = Params()
|
||||
if len(sys.argv) > 2:
|
||||
params.put(sys.argv[1], sys.argv[2])
|
||||
else:
|
||||
for k in keys:
|
||||
pp = params.get(k)
|
||||
if pp is None:
|
||||
print("%s is None" % k)
|
||||
elif all(ord(c) < 128 and ord(c) >= 32 for c in pp):
|
||||
print("%s = %s" % (k, pp))
|
||||
else:
|
||||
print("%s = %s" % (k, pp.encode("hex")))
|
||||
|
||||
# Test multiprocess:
|
||||
# seq 0 100000 | xargs -P20 -I{} python common/params.py DongleId {} && sleep 0.05
|
||||
# while python common/params.py DongleId; do sleep 0.05; done
|
||||
@@ -0,0 +1,163 @@
|
||||
#!/usr/bin/env python3
|
||||
|
||||
|
||||
# Copyright (C) 2016 Sixten Bergman
|
||||
# License WTFPL
|
||||
#
|
||||
# This program is free software. It comes without any warranty, to the extent
|
||||
# permitted by applicable law.
|
||||
# You can redistribute it and/or modify it under the terms of the Do What The
|
||||
# Fuck You Want To Public License, Version 2, as published by Sam Hocevar. See
|
||||
# http://www.wtfpl.net/ for more details.
|
||||
#
|
||||
# note that the function peakdetect is derived from code which was released to
|
||||
# public domain see: http://billauer.co.il/peakdet.html
|
||||
#
|
||||
|
||||
from math import log
|
||||
import numpy as np
|
||||
|
||||
__all__ = ["peakdetect"]
|
||||
|
||||
|
||||
|
||||
def _datacheck_peakdetect(x_axis, y_axis):
|
||||
if x_axis is None:
|
||||
x_axis = range(len(y_axis))
|
||||
|
||||
if len(y_axis) != len(x_axis):
|
||||
raise ValueError("Input vectors y_axis and x_axis must have same length")
|
||||
|
||||
#needs to be a numpy array
|
||||
y_axis = np.array(y_axis)
|
||||
x_axis = np.array(x_axis)
|
||||
return x_axis, y_axis
|
||||
|
||||
|
||||
def _pad(fft_data, pad_len):
|
||||
"""
|
||||
Pads fft data to interpolate in time domain
|
||||
|
||||
keyword arguments:
|
||||
fft_data -- the fft
|
||||
pad_len -- By how many times the time resolution should be increased by
|
||||
|
||||
return: padded list
|
||||
"""
|
||||
length = len(fft_data)
|
||||
n = _n(length * pad_len)
|
||||
fft_data = list(fft_data)
|
||||
|
||||
return fft_data[:length // 2] + [0] * (2**n-length) + fft_data[length // 2:]
|
||||
|
||||
|
||||
def _n(x):
|
||||
"""
|
||||
Find the smallest value for n, which fulfils 2**n >= x
|
||||
|
||||
keyword arguments:
|
||||
x -- the value, which 2**n must surpass
|
||||
return: the integer n
|
||||
"""
|
||||
return int(log(x)/log(2)) + 1
|
||||
|
||||
|
||||
def peakdetect(y_axis, x_axis=None, lookahead=200, delta=0):
|
||||
"""
|
||||
Converted from/based on a MATLAB script at:
|
||||
http://billauer.co.il/peakdet.html
|
||||
function for detecting local maxima and minima in a signal.
|
||||
Discovers peaks by searching for values which are surrounded by lower
|
||||
or larger values for maxima and minima respectively
|
||||
keyword arguments:
|
||||
y_axis -- A list containing the signal over which to find peaks
|
||||
x_axis -- A x-axis whose values correspond to the y_axis list and is used
|
||||
in the return to specify the position of the peaks. If omitted an
|
||||
index of the y_axis is used.
|
||||
(default: None)
|
||||
lookahead -- distance to look ahead from a peak candidate to determine if
|
||||
it is the actual peak
|
||||
(default: 200)
|
||||
'(samples / period) / f' where '4 >= f >= 1.25' might be a good value
|
||||
delta -- this specifies a minimum difference between a peak and
|
||||
the following points, before a peak may be considered a peak. Useful
|
||||
to hinder the function from picking up false peaks towards to end of
|
||||
the signal. To work well delta should be set to delta >= RMSnoise * 5.
|
||||
(default: 0)
|
||||
When omitted delta function causes a 20% decrease in speed.
|
||||
When used Correctly it can double the speed of the function
|
||||
return: two lists [max_peaks, min_peaks] containing the positive and
|
||||
negative peaks respectively. Each cell of the lists contains a tuple
|
||||
of: (position, peak_value)
|
||||
to get the average peak value do: np.mean(max_peaks, 0)[1] on the
|
||||
results to unpack one of the lists into x, y coordinates do:
|
||||
x, y = zip(*max_peaks)
|
||||
"""
|
||||
max_peaks = []
|
||||
min_peaks = []
|
||||
dump = [] # Used to pop the first hit which almost always is false
|
||||
# check input data
|
||||
x_axis, y_axis = _datacheck_peakdetect(x_axis, y_axis)
|
||||
# store data length for later use
|
||||
length = len(y_axis)
|
||||
#perform some checks
|
||||
if lookahead < 1:
|
||||
raise ValueError("Lookahead must be '1' or above in value")
|
||||
if not (np.isscalar(delta) and delta >= 0):
|
||||
raise ValueError("delta must be a positive number")
|
||||
#maxima and minima candidates are temporarily stored in
|
||||
#mx and mn respectively
|
||||
mn, mx = np.Inf, -np.Inf
|
||||
#Only detect peak if there is 'lookahead' amount of points after it
|
||||
for index, (x, y) in enumerate(zip(x_axis[:-lookahead],
|
||||
y_axis[:-lookahead])):
|
||||
if y > mx:
|
||||
mx = y
|
||||
mxpos = x
|
||||
if y < mn:
|
||||
mn = y
|
||||
mnpos = x
|
||||
####look for max####
|
||||
if y < mx-delta and mx != np.Inf:
|
||||
#Maxima peak candidate found
|
||||
#look ahead in signal to ensure that this is a peak and not jitter
|
||||
if y_axis[index:index+lookahead].max() < mx:
|
||||
max_peaks.append([mxpos, mx])
|
||||
dump.append(True)
|
||||
#set algorithm to only find minima now
|
||||
mx = np.Inf
|
||||
mn = np.Inf
|
||||
if index+lookahead >= length:
|
||||
#end is within lookahead no more peaks can be found
|
||||
break
|
||||
continue
|
||||
#else: #slows shit down this does
|
||||
# mx = ahead
|
||||
# mxpos = x_axis[np.where(y_axis[index:index+lookahead]==mx)]
|
||||
####look for min####
|
||||
if y > mn+delta and mn != -np.Inf:
|
||||
#Minima peak candidate found
|
||||
#look ahead in signal to ensure that this is a peak and not jitter
|
||||
if y_axis[index:index+lookahead].min() > mn:
|
||||
min_peaks.append([mnpos, mn])
|
||||
dump.append(False)
|
||||
#set algorithm to only find maxima now
|
||||
mn = -np.Inf
|
||||
mx = -np.Inf
|
||||
if index+lookahead >= length:
|
||||
#end is within lookahead no more peaks can be found
|
||||
break
|
||||
#else: #slows shit down this does
|
||||
# mn = ahead
|
||||
# mnpos = x_axis[np.where(y_axis[index:index+lookahead]==mn)]
|
||||
#Remove the false hit on the first value of the y_axis
|
||||
try:
|
||||
if dump[0]:
|
||||
max_peaks.pop(0)
|
||||
else:
|
||||
min_peaks.pop(0)
|
||||
del dump
|
||||
except IndexError:
|
||||
#no peaks were found, should the function return empty lists?
|
||||
pass
|
||||
return [max_peaks, min_peaks]
|
||||
@@ -0,0 +1,46 @@
|
||||
import time
|
||||
|
||||
class Profiler():
|
||||
def __init__(self, enabled=False):
|
||||
self.enabled = enabled
|
||||
self.cp = {}
|
||||
self.cp_ignored = []
|
||||
self.iter = 0
|
||||
self.start_time = time.time()
|
||||
self.last_time = self.start_time
|
||||
self.tot = 0.
|
||||
|
||||
def reset(self, enabled=False):
|
||||
self.enabled = enabled
|
||||
self.cp = {}
|
||||
self.cp_ignored = []
|
||||
self.iter = 0
|
||||
self.start_time = time.time()
|
||||
self.last_time = self.start_time
|
||||
|
||||
def checkpoint(self, name, ignore=False):
|
||||
# ignore flag needed when benchmarking threads with ratekeeper
|
||||
if not self.enabled:
|
||||
return
|
||||
tt = time.time()
|
||||
if name not in self.cp:
|
||||
self.cp[name] = 0.
|
||||
if ignore:
|
||||
self.cp_ignored.append(name)
|
||||
self.cp[name] += tt - self.last_time
|
||||
if not ignore:
|
||||
self.tot += tt - self.last_time
|
||||
self.last_time = tt
|
||||
|
||||
def display(self):
|
||||
if not self.enabled:
|
||||
return
|
||||
self.iter += 1
|
||||
print("******* Profiling *******")
|
||||
for n, ms in sorted(self.cp.items(), key=lambda x: -x[1]):
|
||||
if n in self.cp_ignored:
|
||||
print("%30s: %7.2f percent: %3.0f IGNORED" % (n, ms*1000.0, ms/self.tot*100))
|
||||
else:
|
||||
print("%30s: %7.2f percent: %3.0f" % (n, ms*1000.0, ms/self.tot*100))
|
||||
print("Iter clock: %2.6f TOTAL: %2.2f" % (self.tot/self.iter, self.tot))
|
||||
|
||||
@@ -0,0 +1,74 @@
|
||||
"""Utilities for reading real time clocks and keeping soft real time constraints."""
|
||||
import os
|
||||
import time
|
||||
import platform
|
||||
import subprocess
|
||||
import multiprocessing
|
||||
from cffi import FFI
|
||||
|
||||
from common.common_pyx import sec_since_boot # pylint: disable=no-name-in-module, import-error
|
||||
|
||||
|
||||
# time step for each process
|
||||
DT_CTRL = 0.01 # controlsd
|
||||
DT_MDL = 0.05 # model
|
||||
DT_DMON = 0.1 # driver monitoring
|
||||
DT_TRML = 0.5 # thermald and manager
|
||||
|
||||
|
||||
ffi = FFI()
|
||||
ffi.cdef("long syscall(long number, ...);")
|
||||
libc = ffi.dlopen(None)
|
||||
|
||||
|
||||
def set_realtime_priority(level):
|
||||
if os.getuid() != 0:
|
||||
print("not setting priority, not root")
|
||||
return
|
||||
if platform.machine() == "x86_64":
|
||||
NR_gettid = 186
|
||||
elif platform.machine() == "aarch64":
|
||||
NR_gettid = 178
|
||||
else:
|
||||
raise NotImplementedError
|
||||
|
||||
tid = libc.syscall(NR_gettid)
|
||||
return subprocess.call(['chrt', '-f', '-p', str(level), str(tid)])
|
||||
|
||||
|
||||
class Ratekeeper():
|
||||
def __init__(self, rate, print_delay_threshold=0.):
|
||||
"""Rate in Hz for ratekeeping. print_delay_threshold must be nonnegative."""
|
||||
self._interval = 1. / rate
|
||||
self._next_frame_time = sec_since_boot() + self._interval
|
||||
self._print_delay_threshold = print_delay_threshold
|
||||
self._frame = 0
|
||||
self._remaining = 0
|
||||
self._process_name = multiprocessing.current_process().name
|
||||
|
||||
@property
|
||||
def frame(self):
|
||||
return self._frame
|
||||
|
||||
@property
|
||||
def remaining(self):
|
||||
return self._remaining
|
||||
|
||||
# Maintain loop rate by calling this at the end of each loop
|
||||
def keep_time(self):
|
||||
lagged = self.monitor_time()
|
||||
if self._remaining > 0:
|
||||
time.sleep(self._remaining)
|
||||
return lagged
|
||||
|
||||
# this only monitor the cumulative lag, but does not enforce a rate
|
||||
def monitor_time(self):
|
||||
lagged = False
|
||||
remaining = self._next_frame_time - sec_since_boot()
|
||||
self._next_frame_time += self._interval
|
||||
if self._print_delay_threshold is not None and remaining < -self._print_delay_threshold:
|
||||
print("%s lagging by %.2f ms" % (self._process_name, -remaining * 1000))
|
||||
lagged = True
|
||||
self._frame += 1
|
||||
self._remaining = remaining
|
||||
return lagged
|
||||
@@ -0,0 +1,78 @@
|
||||
import os
|
||||
import numpy as np
|
||||
import random
|
||||
|
||||
class SamplingBuffer():
|
||||
def __init__(self, fn, size, write=False):
|
||||
self._fn = fn
|
||||
self._write = write
|
||||
if self._write:
|
||||
self._f = open(self._fn, "ab")
|
||||
else:
|
||||
self._f = open(self._fn, "rb")
|
||||
self._size = size
|
||||
self._refresh()
|
||||
|
||||
def _refresh(self):
|
||||
self.cnt = os.path.getsize(self._fn) / self._size
|
||||
|
||||
@property
|
||||
def count(self):
|
||||
self._refresh()
|
||||
return self.cnt
|
||||
|
||||
def _fetch_one(self, x):
|
||||
assert self._write == False
|
||||
self._f.seek(x*self._size)
|
||||
return self._f.read(self._size)
|
||||
|
||||
def sample(self, count, indices = None):
|
||||
if indices == None:
|
||||
cnt = self.count
|
||||
assert cnt != 0
|
||||
indices = map(lambda x: random.randint(0, cnt-1), range(count))
|
||||
return map(self._fetch_one, indices)
|
||||
|
||||
def write(self, dat):
|
||||
assert self._write == True
|
||||
assert (len(dat) % self._size) == 0
|
||||
self._f.write(dat)
|
||||
self._f.flush()
|
||||
|
||||
class NumpySamplingBuffer():
|
||||
def __init__(self, fn, size, dtype, write=False):
|
||||
self._size = size
|
||||
self._dtype = dtype
|
||||
self._buf = SamplingBuffer(fn, len(np.zeros(size, dtype=dtype).tobytes()), write)
|
||||
|
||||
@property
|
||||
def count(self):
|
||||
return self._buf.count
|
||||
|
||||
def write(self, dat):
|
||||
self._buf.write(dat.tobytes())
|
||||
|
||||
def sample(self, count, indices = None):
|
||||
return np.fromstring(''.join(self._buf.sample(count, indices)), dtype=self._dtype).reshape([count]+list(self._size))
|
||||
|
||||
# TODO: n IOPS needed where n is the Multi
|
||||
class MultiNumpySamplingBuffer():
|
||||
def __init__(self, fn, npa, write=False):
|
||||
self._bufs = []
|
||||
for i,n in enumerate(npa):
|
||||
self._bufs.append(NumpySamplingBuffer(fn + ("_%d" % i), n[0], n[1], write))
|
||||
|
||||
def write(self, dat):
|
||||
for b,x in zip(self._bufs, dat):
|
||||
b.write(x)
|
||||
|
||||
@property
|
||||
def count(self):
|
||||
return min(map(lambda x: x.count, self._bufs))
|
||||
|
||||
def sample(self, count):
|
||||
cnt = self.count
|
||||
assert cnt != 0
|
||||
indices = map(lambda x: random.randint(0, cnt-1), range(count))
|
||||
return map(lambda x: x.sample(count, indices), self._bufs)
|
||||
|
||||
@@ -0,0 +1,63 @@
|
||||
import os
|
||||
import subprocess
|
||||
from common.basedir import BASEDIR
|
||||
|
||||
|
||||
class Spinner():
|
||||
def __init__(self):
|
||||
try:
|
||||
self.spinner_proc = subprocess.Popen(["./spinner"],
|
||||
stdin=subprocess.PIPE,
|
||||
cwd=os.path.join(BASEDIR, "selfdrive", "ui", "spinner"),
|
||||
close_fds=True)
|
||||
except OSError:
|
||||
self.spinner_proc = None
|
||||
|
||||
def __enter__(self):
|
||||
return self
|
||||
|
||||
def update(self, spinner_text):
|
||||
if self.spinner_proc is not None:
|
||||
self.spinner_proc.stdin.write(spinner_text.encode('utf8') + b"\n")
|
||||
try:
|
||||
self.spinner_proc.stdin.flush()
|
||||
except BrokenPipeError:
|
||||
pass
|
||||
|
||||
def close(self):
|
||||
if self.spinner_proc is not None:
|
||||
try:
|
||||
self.spinner_proc.stdin.close()
|
||||
except BrokenPipeError:
|
||||
pass
|
||||
self.spinner_proc.terminate()
|
||||
self.spinner_proc = None
|
||||
|
||||
def __del__(self):
|
||||
self.close()
|
||||
|
||||
def __exit__(self, type, value, traceback):
|
||||
self.close()
|
||||
|
||||
|
||||
class FakeSpinner():
|
||||
def __init__(self):
|
||||
pass
|
||||
|
||||
def __enter__(self):
|
||||
return self
|
||||
|
||||
def update(self, _):
|
||||
pass
|
||||
|
||||
def __exit__(self, type, value, traceback):
|
||||
pass
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
import time
|
||||
with Spinner() as s:
|
||||
s.update("Spinner text")
|
||||
time.sleep(5.0)
|
||||
print("gone")
|
||||
time.sleep(5.0)
|
||||
@@ -1,6 +1,6 @@
|
||||
import numpy as np
|
||||
|
||||
class RunningStat:
|
||||
class RunningStat():
|
||||
# tracks realtime mean and standard deviation without storing any data
|
||||
def __init__(self, priors=None, max_trackable=-1):
|
||||
self.max_trackable = max_trackable
|
||||
@@ -32,7 +32,7 @@ class RunningStat:
|
||||
self.S_last = 0.
|
||||
else:
|
||||
self.M = self.M_last + (new_data - self.M_last) / self.n
|
||||
self.S = self.S_last + (new_data - self.M_last) * (new_data - self.M)
|
||||
self.S = self.S_last + (new_data - self.M_last) * (new_data - self.M);
|
||||
self.M_last = self.M
|
||||
self.S_last = self.S
|
||||
|
||||
@@ -48,9 +48,12 @@ class RunningStat:
|
||||
def std(self):
|
||||
return np.sqrt(self.variance())
|
||||
|
||||
class RunningStatFilter:
|
||||
def params_to_save(self):
|
||||
return [self.M, self.S, self.n]
|
||||
|
||||
class RunningStatFilter():
|
||||
def __init__(self, raw_priors=None, filtered_priors=None, max_trackable=-1):
|
||||
self.raw_stat = RunningStat(raw_priors, -1)
|
||||
self.raw_stat = RunningStat(raw_priors, max_trackable)
|
||||
self.filtered_stat = RunningStat(filtered_priors, max_trackable)
|
||||
|
||||
def reset(self):
|
||||
@@ -61,7 +64,7 @@ class RunningStatFilter:
|
||||
_std_last = self.raw_stat.std()
|
||||
self.raw_stat.push_data(new_data)
|
||||
_delta_std = self.raw_stat.std() - _std_last
|
||||
if _delta_std <= 0:
|
||||
if _delta_std<=0:
|
||||
self.filtered_stat.push_data(new_data)
|
||||
else:
|
||||
pass
|
||||
@@ -0,0 +1,94 @@
|
||||
import numpy as np
|
||||
|
||||
_DESC_FMT = """
|
||||
{} (n={}):
|
||||
MEAN={}
|
||||
VAR={}
|
||||
MIN={}
|
||||
MAX={}
|
||||
"""
|
||||
|
||||
class StatTracker():
|
||||
def __init__(self, name):
|
||||
self._name = name
|
||||
self._mean = 0.
|
||||
self._var = 0.
|
||||
self._n = 0
|
||||
self._min = -float("-inf")
|
||||
self._max = -float("inf")
|
||||
|
||||
@property
|
||||
def mean(self):
|
||||
return self._mean
|
||||
|
||||
@property
|
||||
def var(self):
|
||||
return (self._n * self._var) / (self._n - 1.)
|
||||
|
||||
@property
|
||||
def min(self):
|
||||
return self._min
|
||||
|
||||
@property
|
||||
def max(self):
|
||||
return self._max
|
||||
|
||||
def update(self, samples):
|
||||
# https://en.wikipedia.org/wiki/Algorithms_for_calculating_variance#Parallel_algorithm
|
||||
data = samples.reshape(-1)
|
||||
n_a = data.size
|
||||
mean_a = np.mean(data)
|
||||
var_a = np.var(data, ddof=0)
|
||||
|
||||
n_b = self._n
|
||||
mean_b = self._mean
|
||||
|
||||
delta = mean_b - mean_a
|
||||
m_a = var_a * (n_a - 1)
|
||||
m_b = self._var * (n_b - 1)
|
||||
m2 = m_a + m_b + delta**2 * n_a * n_b / (n_a + n_b)
|
||||
|
||||
self._var = m2 / (n_a + n_b)
|
||||
self._mean = (n_a * mean_a + n_b * mean_b) / (n_a + n_b)
|
||||
self._n = n_a + n_b
|
||||
|
||||
self._min = min(self._min, np.min(data))
|
||||
self._max = max(self._max, np.max(data))
|
||||
|
||||
def __str__(self):
|
||||
return _DESC_FMT.format(self._name, self._n, self._mean, self.var, self._min,
|
||||
self._max)
|
||||
|
||||
# FIXME(mgraczyk): The variance computation does not work with 1 sample batches.
|
||||
class VectorStatTracker(StatTracker):
|
||||
def __init__(self, name, dim):
|
||||
self._name = name
|
||||
self._mean = np.zeros((dim, ))
|
||||
self._var = np.zeros((dim, dim))
|
||||
self._n = 0
|
||||
self._min = np.full((dim, ), -float("-inf"))
|
||||
self._max = np.full((dim, ), -float("inf"))
|
||||
|
||||
@property
|
||||
def cov(self):
|
||||
return self.var
|
||||
|
||||
def update(self, samples):
|
||||
n_a = samples.shape[0]
|
||||
mean_a = np.mean(samples, axis=0)
|
||||
var_a = np.cov(samples, ddof=0, rowvar=False)
|
||||
|
||||
n_b = self._n
|
||||
mean_b = self._mean
|
||||
|
||||
delta = mean_b - mean_a
|
||||
m_a = var_a * (n_a - 1)
|
||||
m_b = self._var * (n_b - 1)
|
||||
m2 = m_a + m_b + delta**2 * n_a * n_b / (n_a + n_b)
|
||||
|
||||
self._var = m2 / (n_a + n_b)
|
||||
self._mean = (n_a * mean_a + n_b * mean_b) / (n_a + n_b)
|
||||
self._n = n_a + n_b
|
||||
|
||||
self._min = np.minimum(self._min, np.min(samples, axis=0))
|
||||
self._max = np.maximum(self._max, np.max(samples, axis=0))
|
||||
@@ -0,0 +1,6 @@
|
||||
def replace_right(s, old, new, occurrence):
|
||||
# replace_right('1232425', '2', ' ', 1) -> '12324 5'
|
||||
# replace_right('1232425', '2', ' ', 2) -> '123 4 5'
|
||||
|
||||
split = s.rsplit(old, occurrence)
|
||||
return new.join(split)
|
||||
@@ -0,0 +1,81 @@
|
||||
#!/usr/bin/env python3
|
||||
import sympy as sp
|
||||
import numpy as np
|
||||
|
||||
def cross(x):
|
||||
ret = sp.Matrix(np.zeros((3,3)))
|
||||
ret[0,1], ret[0,2] = -x[2], x[1]
|
||||
ret[1,0], ret[1,2] = x[2], -x[0]
|
||||
ret[2,0], ret[2,1] = -x[1], x[0]
|
||||
return ret
|
||||
|
||||
def euler_rotate(roll, pitch, yaw):
|
||||
# make symbolic rotation matrix from eulers
|
||||
matrix_roll = sp.Matrix([[1, 0, 0],
|
||||
[0, sp.cos(roll), -sp.sin(roll)],
|
||||
[0, sp.sin(roll), sp.cos(roll)]])
|
||||
matrix_pitch = sp.Matrix([[sp.cos(pitch), 0, sp.sin(pitch)],
|
||||
[0, 1, 0],
|
||||
[-sp.sin(pitch), 0, sp.cos(pitch)]])
|
||||
matrix_yaw = sp.Matrix([[sp.cos(yaw), -sp.sin(yaw), 0],
|
||||
[sp.sin(yaw), sp.cos(yaw), 0],
|
||||
[0, 0, 1]])
|
||||
return matrix_yaw*matrix_pitch*matrix_roll
|
||||
|
||||
def quat_rotate(q0, q1, q2, q3):
|
||||
# make symbolic rotation matrix from quat
|
||||
return sp.Matrix([[q0**2 + q1**2 - q2**2 - q3**2, 2*(q1*q2 + q0*q3), 2*(q1*q3 - q0*q2)],
|
||||
[2*(q1*q2 - q0*q3), q0**2 - q1**2 + q2**2 - q3**2, 2*(q2*q3 + q0*q1)],
|
||||
[2*(q1*q3 + q0*q2), 2*(q2*q3 - q0*q1), q0**2 - q1**2 - q2**2 + q3**2]]).T
|
||||
|
||||
def quat_matrix_l(p):
|
||||
return sp.Matrix([[p[0], -p[1], -p[2], -p[3]],
|
||||
[p[1], p[0], -p[3], p[2]],
|
||||
[p[2], p[3], p[0], -p[1]],
|
||||
[p[3], -p[2], p[1], p[0]]])
|
||||
|
||||
def quat_matrix_r(p):
|
||||
return sp.Matrix([[p[0], -p[1], -p[2], -p[3]],
|
||||
[p[1], p[0], p[3], -p[2]],
|
||||
[p[2], -p[3], p[0], p[1]],
|
||||
[p[3], p[2], -p[1], p[0]]])
|
||||
|
||||
|
||||
def sympy_into_c(sympy_functions):
|
||||
from sympy.utilities import codegen
|
||||
routines = []
|
||||
for name, expr, args in sympy_functions:
|
||||
r = codegen.make_routine(name, expr, language="C99")
|
||||
|
||||
# argument ordering input to sympy is broken with function with output arguments
|
||||
nargs = []
|
||||
# reorder the input arguments
|
||||
for aa in args:
|
||||
if aa is None:
|
||||
nargs.append(codegen.InputArgument(sp.Symbol('unused'), dimensions=[1,1]))
|
||||
continue
|
||||
found = False
|
||||
for a in r.arguments:
|
||||
if str(aa.name) == str(a.name):
|
||||
nargs.append(a)
|
||||
found = True
|
||||
break
|
||||
if not found:
|
||||
# [1,1] is a hack for Matrices
|
||||
nargs.append(codegen.InputArgument(aa, dimensions=[1,1]))
|
||||
# add the output arguments
|
||||
for a in r.arguments:
|
||||
if type(a) == codegen.OutputArgument:
|
||||
nargs.append(a)
|
||||
|
||||
#assert len(r.arguments) == len(args)+1
|
||||
r.arguments = nargs
|
||||
|
||||
# add routine to list
|
||||
routines.append(r)
|
||||
|
||||
[(c_name, c_code), (h_name, c_header)] = codegen.get_code_generator('C', 'ekf', 'C99').write(routines, "ekf")
|
||||
c_code = '\n'.join(x for x in c_code.split("\n") if len(x) > 0 and x[0] != '#')
|
||||
c_header = '\n'.join(x for x in c_header.split("\n") if len(x) > 0 and x[0] != '#')
|
||||
|
||||
return c_header, c_code
|
||||
@@ -0,0 +1,9 @@
|
||||
import os
|
||||
from nose.tools import nottest
|
||||
|
||||
def phone_only(x):
|
||||
if os.path.isfile("/init.qcom.rc"):
|
||||
return x
|
||||
else:
|
||||
return nottest(x)
|
||||
|
||||
@@ -0,0 +1,28 @@
|
||||
import os
|
||||
import unittest
|
||||
from uuid import uuid4
|
||||
|
||||
from common.file_helpers import atomic_write_on_fs_tmp
|
||||
from common.file_helpers import atomic_write_in_dir
|
||||
|
||||
|
||||
class TestFileHelpers(unittest.TestCase):
|
||||
def run_atomic_write_func(self, atomic_write_func):
|
||||
path = "/tmp/tmp{}".format(uuid4())
|
||||
with atomic_write_func(path) as f:
|
||||
f.write("test")
|
||||
|
||||
with open(path) as f:
|
||||
self.assertEqual(f.read(), "test")
|
||||
self.assertEqual(os.stat(path).st_mode & 0o777, 0o644)
|
||||
os.remove(path)
|
||||
|
||||
def test_atomic_write_on_fs_tmp(self):
|
||||
self.run_atomic_write_func(atomic_write_on_fs_tmp)
|
||||
|
||||
def test_atomic_write_in_dir(self):
|
||||
self.run_atomic_write_func(atomic_write_in_dir)
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
unittest.main()
|
||||
@@ -0,0 +1,27 @@
|
||||
import numpy as np
|
||||
import unittest
|
||||
import timeit
|
||||
|
||||
from common.numpy_fast import interp
|
||||
|
||||
|
||||
class InterpTest(unittest.TestCase):
|
||||
def test_correctness_controls(self):
|
||||
_A_CRUISE_MIN_BP = np.asarray([0., 5., 10., 20., 40.])
|
||||
_A_CRUISE_MIN_V = np.asarray([-1.0, -.8, -.67, -.5, -.30])
|
||||
v_ego_arr = [-1, -1e-12, 0, 4, 5, 6, 7, 10, 11, 15.2, 20, 21, 39,
|
||||
39.999999, 40, 41]
|
||||
|
||||
expected = np.interp(v_ego_arr, _A_CRUISE_MIN_BP, _A_CRUISE_MIN_V)
|
||||
actual = interp(v_ego_arr, _A_CRUISE_MIN_BP, _A_CRUISE_MIN_V)
|
||||
|
||||
np.testing.assert_equal(actual, expected)
|
||||
|
||||
for v_ego in v_ego_arr:
|
||||
expected = np.interp(v_ego, _A_CRUISE_MIN_BP, _A_CRUISE_MIN_V)
|
||||
actual = interp(v_ego, _A_CRUISE_MIN_BP, _A_CRUISE_MIN_V)
|
||||
np.testing.assert_equal(actual, expected)
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
unittest.main()
|
||||
@@ -0,0 +1,63 @@
|
||||
from common.params import Params, UnknownKeyName
|
||||
import threading
|
||||
import time
|
||||
import tempfile
|
||||
import shutil
|
||||
import unittest
|
||||
|
||||
|
||||
class TestParams(unittest.TestCase):
|
||||
def setUp(self):
|
||||
self.tmpdir = tempfile.mkdtemp()
|
||||
print("using", self.tmpdir)
|
||||
self.params = Params(self.tmpdir)
|
||||
|
||||
def tearDown(self):
|
||||
shutil.rmtree(self.tmpdir)
|
||||
|
||||
def test_params_put_and_get(self):
|
||||
self.params.put("DongleId", "cb38263377b873ee")
|
||||
assert self.params.get("DongleId") == b"cb38263377b873ee"
|
||||
|
||||
def test_params_non_ascii(self):
|
||||
st = b"\xe1\x90\xff"
|
||||
self.params.put("CarParams", st)
|
||||
assert self.params.get("CarParams") == st
|
||||
|
||||
def test_params_get_cleared_panda_disconnect(self):
|
||||
self.params.put("CarParams", "test")
|
||||
self.params.put("DongleId", "cb38263377b873ee")
|
||||
assert self.params.get("CarParams") == b"test"
|
||||
self.params.panda_disconnect()
|
||||
assert self.params.get("CarParams") is None
|
||||
assert self.params.get("DongleId") is not None
|
||||
|
||||
def test_params_get_cleared_manager_start(self):
|
||||
self.params.put("CarParams", "test")
|
||||
self.params.put("DongleId", "cb38263377b873ee")
|
||||
assert self.params.get("CarParams") == b"test"
|
||||
self.params.manager_start()
|
||||
assert self.params.get("CarParams") is None
|
||||
assert self.params.get("DongleId") is not None
|
||||
|
||||
def test_params_two_things(self):
|
||||
self.params.put("DongleId", "bob")
|
||||
self.params.put("AccessToken", "knope")
|
||||
assert self.params.get("DongleId") == b"bob"
|
||||
assert self.params.get("AccessToken") == b"knope"
|
||||
|
||||
def test_params_get_block(self):
|
||||
def _delayed_writer():
|
||||
time.sleep(0.1)
|
||||
self.params.put("CarParams", "test")
|
||||
threading.Thread(target=_delayed_writer).start()
|
||||
assert self.params.get("CarParams") is None
|
||||
assert self.params.get("CarParams", True) == b"test"
|
||||
|
||||
def test_params_unknown_key_fails(self):
|
||||
with self.assertRaises(UnknownKeyName):
|
||||
self.params.get("swag")
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
unittest.main()
|
||||
@@ -12,7 +12,7 @@ class Timeout:
|
||||
"""
|
||||
def __init__(self, seconds, error_msg=None):
|
||||
if error_msg is None:
|
||||
error_msg = f'Timed out after {seconds} seconds'
|
||||
error_msg = 'Timed out after {} seconds'.format(seconds)
|
||||
self.seconds = seconds
|
||||
self.error_msg = error_msg
|
||||
|
||||
@@ -25,3 +25,4 @@ class Timeout:
|
||||
|
||||
def __exit__(self, exc_type, exc_val, exc_tb):
|
||||
signal.alarm(0)
|
||||
|
||||
@@ -0,0 +1,61 @@
|
||||
|
||||
Reference Frames
|
||||
------
|
||||
Many reference frames are used throughout. This
|
||||
folder contains all helper functions needed to
|
||||
transform between them. Generally this is done
|
||||
by generating a rotation matrix and multiplying.
|
||||
|
||||
|
||||
| Name | [x, y, z] | Units | Notes |
|
||||
| :-------------: |:-------------:| :-----:| :----: |
|
||||
| Geodetic | [Latitude, Longitude, Altitude] | geodetic coordinates | Sometimes used as [lon, lat, alt], avoid this frame. |
|
||||
| ECEF | [x, y, z] | meters | We use **ITRF14 (IGS14)**, NOT NAD83. <br> This is the global Mesh3D frame. |
|
||||
| NED | [North, East, Down] | meters | Relative to earth's surface, useful for vizualizing. |
|
||||
| Device | [Forward, Right, Down] | meters | This is the Mesh3D local frame. <br> Relative to camera, **not imu.** <br> 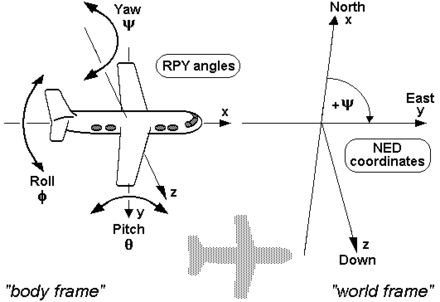|
|
||||
| Road | [Forward, Left, Up] | meters | On the road plane aligned to the vehicle. <br>  |
|
||||
| View | [Right, Down, Forward] | meters | Like device frame, but according to camera conventions. |
|
||||
| Camera | [u, v, focal] | pixels | Like view frame, but 2d on the camera image.|
|
||||
| Normalized Camera | [u / focal, v / focal, 1] | / | |
|
||||
| Model | [u, v, focal] | pixels | The sampled rectangle of the full camera frame the model uses. |
|
||||
| Normalized Model | [u / focal, v / focal, 1] | / | |
|
||||
|
||||
|
||||
|
||||
|
||||
Orientation Conventations
|
||||
------
|
||||
Quaternions, rotation matrices and euler angles are three
|
||||
equivalent representations of orientation and all three are
|
||||
used throughout the code base.
|
||||
|
||||
For euler angles the preferred convention is [roll, pitch, yaw]
|
||||
which corresponds to rotations around the [x, y, z] axes. All
|
||||
euler angles should always be in radians or radians/s unless
|
||||
for plotting or display purposes. For quaternions the hamilton
|
||||
notations is preferred which is [q<sub>w</sub>, q<sub>x</sub>, q<sub>y</sub>, q<sub>z</sub>]. All quaternions
|
||||
should always be normalized with a strictly positive q<sub>w</sub>. **These
|
||||
quaternions are a unique representation of orientation whereas euler angles
|
||||
or rotation matrices are not.**
|
||||
|
||||
To rotate from one frame into another with euler angles the
|
||||
convention is to rotate around roll, then pitch and then yaw,
|
||||
while rotating around the rotated axes, not the original axes.
|
||||
|
||||
|
||||
Calibration
|
||||
------
|
||||
EONs are not all mounted in the exact same way. To compensate for the effects of this the vision model takes in an image that is "calibrated". This means the image is aligned so the direction of travel of the car when it is going straight and the road is flat is always in the location on the image. This calibration is defined by a pitch and yaw angle that describe the direction of travel vector in device frame.
|
||||
|
||||
Example
|
||||
------
|
||||
To transform global Mesh3D positions and orientations (positions_ecef, quats_ecef) into the local frame described by the
|
||||
first position and orientation from Mesh3D one would do:
|
||||
```
|
||||
ecef_from_local = rot_from_quat(quats_ecef[0])
|
||||
local_from_ecef = ecef_from_local.T
|
||||
positions_local = np.einsum('ij,kj->ki', local_from_ecef, postions_ecef - positions_ecef[0])
|
||||
rotations_global = rot_from_quat(quats_ecef)
|
||||
rotations_local = np.einsum('ij,kjl->kil', local_from_ecef, rotations_global)
|
||||
eulers_local = euler_from_rot(rotations_local)
|
||||
```
|
||||
Some files were not shown because too many files have changed in this diff Show More
Reference in New Issue
Block a user