mirror of
https://github.com/sunnypilot/sunnypilot.git
synced 2026-09-16 19:23:45 +08:00
Compare commits
1 Commits
| Author | SHA1 | Date | |
|---|---|---|---|
 Jason Wen |
6fc9247eaa |
@@ -38,7 +38,7 @@ jobs:
|
||||
report:
|
||||
needs: [ci_matrix_run]
|
||||
runs-on: ubuntu-latest
|
||||
if: always() && github.repository == 'commaai/openpilot'
|
||||
if: always()
|
||||
steps:
|
||||
- name: Get job results
|
||||
uses: actions/github-script@v7
|
||||
|
||||
@@ -1,151 +0,0 @@
|
||||
name: "mici raylib ui preview"
|
||||
on:
|
||||
push:
|
||||
branches:
|
||||
- master
|
||||
pull_request_target:
|
||||
types: [assigned, opened, synchronize, reopened, edited]
|
||||
branches:
|
||||
- 'master'
|
||||
paths:
|
||||
- 'selfdrive/assets/**'
|
||||
- 'selfdrive/ui/**'
|
||||
- 'system/ui/**'
|
||||
workflow_dispatch:
|
||||
|
||||
env:
|
||||
UI_JOB_NAME: "Create mici raylib UI Report"
|
||||
REPORT_NAME: ${{ github.event_name == 'push' && github.ref == 'refs/heads/master' && 'master' || github.event.number }}
|
||||
SHA: ${{ github.event_name == 'push' && github.ref == 'refs/heads/master' && github.sha || github.event.pull_request.head.sha }}
|
||||
BRANCH_NAME: "openpilot/pr-${{ github.event.number }}-mici-raylib-ui"
|
||||
MASTER_BRANCH_NAME: "openpilot_master_ui_mici_raylib"
|
||||
# All report files are pushed here
|
||||
REPORT_FILES_BRANCH_NAME: "mici-raylib-ui-reports"
|
||||
|
||||
jobs:
|
||||
preview:
|
||||
if: github.repository == 'commaai/openpilot'
|
||||
name: preview
|
||||
runs-on: ubuntu-latest
|
||||
timeout-minutes: 20
|
||||
permissions:
|
||||
contents: read
|
||||
pull-requests: write
|
||||
actions: read
|
||||
steps:
|
||||
- uses: actions/checkout@v4
|
||||
with:
|
||||
submodules: true
|
||||
|
||||
- name: Waiting for ui generation to end
|
||||
uses: lewagon/wait-on-check-action@v1.3.4
|
||||
with:
|
||||
ref: ${{ env.SHA }}
|
||||
check-name: ${{ env.UI_JOB_NAME }}
|
||||
repo-token: ${{ secrets.GITHUB_TOKEN }}
|
||||
allowed-conclusions: success
|
||||
wait-interval: 20
|
||||
|
||||
- name: Getting workflow run ID
|
||||
id: get_run_id
|
||||
run: |
|
||||
echo "run_id=$(curl https://api.github.com/repos/${{ github.repository }}/commits/${{ env.SHA }}/check-runs | jq -r '.check_runs[] | select(.name == "${{ env.UI_JOB_NAME }}") | .html_url | capture("(?<number>[0-9]+)") | .number')" >> $GITHUB_OUTPUT
|
||||
|
||||
- name: Getting proposed ui # filename: pr_ui/mici_ui_replay.mp4
|
||||
id: download-artifact
|
||||
uses: dawidd6/action-download-artifact@v6
|
||||
with:
|
||||
github_token: ${{ secrets.GITHUB_TOKEN }}
|
||||
run_id: ${{ steps.get_run_id.outputs.run_id }}
|
||||
search_artifacts: true
|
||||
name: mici-raylib-report-1-${{ env.REPORT_NAME }}
|
||||
path: ${{ github.workspace }}/pr_ui
|
||||
|
||||
- name: Getting master ui # filename: master_ui_raylib/mici_ui_replay.mp4
|
||||
uses: actions/checkout@v4
|
||||
with:
|
||||
repository: commaai/ci-artifacts
|
||||
ssh-key: ${{ secrets.CI_ARTIFACTS_DEPLOY_KEY }}
|
||||
path: ${{ github.workspace }}/master_ui_raylib
|
||||
ref: ${{ env.MASTER_BRANCH_NAME }}
|
||||
|
||||
- name: Saving new master ui
|
||||
if: github.ref == 'refs/heads/master' && github.event_name == 'push'
|
||||
working-directory: ${{ github.workspace }}/master_ui_raylib
|
||||
run: |
|
||||
git checkout --orphan=new_master_ui_mici_raylib
|
||||
git rm -rf *
|
||||
git branch -D ${{ env.MASTER_BRANCH_NAME }}
|
||||
git branch -m ${{ env.MASTER_BRANCH_NAME }}
|
||||
git config user.name "GitHub Actions Bot"
|
||||
git config user.email "<>"
|
||||
mv ${{ github.workspace }}/pr_ui/* .
|
||||
git add .
|
||||
git commit -m "mici raylib video for commit ${{ env.SHA }}"
|
||||
git push origin ${{ env.MASTER_BRANCH_NAME }} --force
|
||||
|
||||
- name: Setup FFmpeg
|
||||
uses: AnimMouse/setup-ffmpeg@ae28d57dabbb148eff63170b6bf7f2b60062cbae
|
||||
|
||||
- name: Finding diff
|
||||
if: github.event_name == 'pull_request_target'
|
||||
id: find_diff
|
||||
run: |
|
||||
# Find the video file from PR
|
||||
pr_video="${{ github.workspace }}/pr_ui/mici_ui_replay_proposed.mp4"
|
||||
mv "${{ github.workspace }}/pr_ui/mici_ui_replay.mp4" "$pr_video"
|
||||
|
||||
master_video="${{ github.workspace }}/pr_ui/mici_ui_replay_master.mp4"
|
||||
mv "${{ github.workspace }}/master_ui_raylib/mici_ui_replay.mp4" "$master_video"
|
||||
|
||||
# Run report
|
||||
export PYTHONPATH=${{ github.workspace }}
|
||||
baseurl="https://github.com/commaai/ci-artifacts/raw/refs/heads/${{ env.BRANCH_NAME }}"
|
||||
diff_exit_code=0
|
||||
python3 ${{ github.workspace }}/selfdrive/ui/tests/diff/diff.py "${{ github.workspace }}/pr_ui/mici_ui_replay_master.mp4" "${{ github.workspace }}/pr_ui/mici_ui_replay_proposed.mp4" "diff.html" --basedir "$baseurl" --no-open || diff_exit_code=$?
|
||||
|
||||
# Copy diff report files
|
||||
cp ${{ github.workspace }}/selfdrive/ui/tests/diff/report/diff.html ${{ github.workspace }}/pr_ui/
|
||||
cp ${{ github.workspace }}/selfdrive/ui/tests/diff/report/diff.mp4 ${{ github.workspace }}/pr_ui/
|
||||
|
||||
REPORT_URL="https://commaai.github.io/ci-artifacts/diff_pr_${{ github.event.number }}.html"
|
||||
if [ $diff_exit_code -eq 0 ]; then
|
||||
DIFF="✅ Videos are identical! [View Diff Report]($REPORT_URL)"
|
||||
else
|
||||
DIFF="❌ <strong>Videos differ!</strong> [View Diff Report]($REPORT_URL)"
|
||||
fi
|
||||
echo "DIFF=$DIFF" >> "$GITHUB_OUTPUT"
|
||||
|
||||
- name: Saving proposed ui
|
||||
if: github.event_name == 'pull_request_target'
|
||||
working-directory: ${{ github.workspace }}/master_ui_raylib
|
||||
run: |
|
||||
# Overwrite PR branch w/ proposed ui, and master ui at this point in time for future reference
|
||||
git config user.name "GitHub Actions Bot"
|
||||
git config user.email "<>"
|
||||
git checkout --orphan=${{ env.BRANCH_NAME }}
|
||||
git rm -rf *
|
||||
mv ${{ github.workspace }}/pr_ui/* .
|
||||
git add .
|
||||
git commit -m "mici raylib video for PR #${{ github.event.number }}"
|
||||
git push origin ${{ env.BRANCH_NAME }} --force
|
||||
|
||||
# Append diff report to report files branch
|
||||
git fetch origin ${{ env.REPORT_FILES_BRANCH_NAME }}
|
||||
git checkout ${{ env.REPORT_FILES_BRANCH_NAME }}
|
||||
cp ${{ github.workspace }}/selfdrive/ui/tests/diff/report/diff.html diff_pr_${{ github.event.number }}.html
|
||||
git add diff_pr_${{ github.event.number }}.html
|
||||
git commit -m "mici raylib ui diff report for PR #${{ github.event.number }}" || echo "No changes to commit"
|
||||
git push origin ${{ env.REPORT_FILES_BRANCH_NAME }}
|
||||
|
||||
- name: Comment Video on PR
|
||||
if: github.event_name == 'pull_request_target'
|
||||
uses: thollander/actions-comment-pull-request@v2
|
||||
with:
|
||||
message: |
|
||||
<!-- _(run_id_video_mici_raylib **${{ github.run_id }}**)_ -->
|
||||
## mici raylib UI Preview
|
||||
${{ steps.find_diff.outputs.DIFF }}
|
||||
comment_tag: run_id_video_mici_raylib
|
||||
pr_number: ${{ github.event.number }}
|
||||
GITHUB_TOKEN: ${{ secrets.GITHUB_TOKEN }}
|
||||
@@ -200,28 +200,37 @@ jobs:
|
||||
sudo rm -rf ${OUTPUT_DIR}
|
||||
mkdir -p ${OUTPUT_DIR}
|
||||
rsync -am${RUNNER_DEBUG:+v} \
|
||||
--include='**/panda/board/' \
|
||||
--include='**/panda/board/obj' \
|
||||
--include='**/panda/board/obj/panda.bin.signed' \
|
||||
--include='**/panda/board/obj/panda_h7.bin.signed' \
|
||||
--include='**/panda/board/obj/bootstub.panda.bin' \
|
||||
--include='**/panda/board/obj/bootstub.panda_h7.bin' \
|
||||
--exclude='.sconsign.dblite' \
|
||||
--exclude='*.a' \
|
||||
--exclude='*.o' \
|
||||
--exclude='*.os' \
|
||||
--exclude='*.pyc' \
|
||||
--exclude='moc_*' \
|
||||
--exclude='__pycache__' \
|
||||
--exclude='*.cc' \
|
||||
--exclude='Jenkinsfile' \
|
||||
--exclude='supercombo.onnx' \
|
||||
--exclude='**/panda/board/*' \
|
||||
--exclude='**/panda/board/obj/**' \
|
||||
--exclude='**/panda/certs/' \
|
||||
--exclude='**/panda/crypto/' \
|
||||
--exclude='**/release/' \
|
||||
--exclude='**/.github/' \
|
||||
--exclude='**/selfdrive/ui/replay/' \
|
||||
--exclude='**/__pycache__/' \
|
||||
--exclude='**/selfdrive/ui/*.h' \
|
||||
--exclude='**/selfdrive/ui/**/*.h' \
|
||||
--exclude='**/selfdrive/ui/qt/offroad/sunnypilot/' \
|
||||
--exclude='${{env.SCONS_CACHE_DIR}}' \
|
||||
--exclude='**/.git/' \
|
||||
--exclude='**/SConstruct' \
|
||||
--exclude='**/SConscript' \
|
||||
--exclude='**/.venv/' \
|
||||
--exclude='selfdrive/modeld/models/driving_vision.onnx' \
|
||||
--exclude='selfdrive/modeld/models/driving_policy.onnx' \
|
||||
--exclude='sunnypilot/modeld*/models/supercombo.onnx' \
|
||||
--exclude='third_party/*x86*' \
|
||||
--exclude='third_party/*Darwin*' \
|
||||
--delete-excluded \
|
||||
--chown=comma:comma \
|
||||
${BUILD_DIR}/ ${OUTPUT_DIR}/
|
||||
|
||||
@@ -297,29 +297,3 @@ jobs:
|
||||
with:
|
||||
name: raylib-report-${{ inputs.run_number || '1' }}-${{ github.event_name == 'push' && github.ref == 'refs/heads/master' && 'master' || github.event.number }}
|
||||
path: selfdrive/ui/tests/test_ui/raylib_report/screenshots
|
||||
|
||||
create_mici_raylib_ui_report:
|
||||
name: Create mici raylib UI Report
|
||||
runs-on: ${{
|
||||
(github.repository == 'commaai/openpilot') &&
|
||||
((github.event_name != 'pull_request') ||
|
||||
(github.event.pull_request.head.repo.full_name == 'commaai/openpilot'))
|
||||
&& fromJSON('["namespace-profile-amd64-8x16", "namespace-experiments:docker.builds.local-cache=separate"]')
|
||||
|| fromJSON('["ubuntu-24.04"]') }}
|
||||
steps:
|
||||
- uses: actions/checkout@v4
|
||||
with:
|
||||
submodules: true
|
||||
- uses: ./.github/workflows/setup-with-retry
|
||||
- name: Build openpilot
|
||||
run: ${{ env.RUN }} "scons -j$(nproc)"
|
||||
- name: Create mici raylib UI Report
|
||||
run: >
|
||||
${{ env.RUN }} "PYTHONWARNINGS=ignore &&
|
||||
source selfdrive/test/setup_xvfb.sh &&
|
||||
WINDOWED=1 python3 selfdrive/ui/tests/diff/replay.py"
|
||||
- name: Upload Raylib UI Report
|
||||
uses: actions/upload-artifact@v4
|
||||
with:
|
||||
name: mici-raylib-report-${{ inputs.run_number || '1' }}-${{ github.event_name == 'push' && github.ref == 'refs/heads/master' && 'master' || github.event.number }}
|
||||
path: selfdrive/ui/tests/diff/report
|
||||
|
||||
@@ -1,6 +1,3 @@
|
||||
Version 0.10.3 (2025-12-10)
|
||||
========================
|
||||
|
||||
Version 0.10.2 (2025-11-19)
|
||||
========================
|
||||
* comma four support
|
||||
|
||||
+1
-6
@@ -192,7 +192,6 @@ struct LongitudinalPlanSP @0xf35cc4560bbf6ec2 {
|
||||
aTarget @5 :Float32;
|
||||
events @6 :List(OnroadEventSP.Event);
|
||||
e2eAlerts @7 :E2eAlerts;
|
||||
accelPersonality @8 :AccelerationPersonality;
|
||||
|
||||
struct DynamicExperimentalControl {
|
||||
state @0 :DynamicExperimentalControlState;
|
||||
@@ -204,11 +203,7 @@ struct LongitudinalPlanSP @0xf35cc4560bbf6ec2 {
|
||||
blended @1;
|
||||
}
|
||||
}
|
||||
enum AccelerationPersonality {
|
||||
sport @0;
|
||||
normal @1;
|
||||
eco @2;
|
||||
}
|
||||
|
||||
struct SmartCruiseControl {
|
||||
vision @0 :Vision;
|
||||
map @1 :Map;
|
||||
|
||||
@@ -22,5 +22,5 @@ def api_get(endpoint, method='GET', timeout=None, access_token=None, **params):
|
||||
return CommaConnectApi(None).api_get(endpoint, method, timeout, access_token, **params)
|
||||
|
||||
|
||||
def get_key_pair() -> tuple[str, str, str] | tuple[None, None, None]:
|
||||
def get_key_pair():
|
||||
return CommaConnectApi(None).get_key_pair()
|
||||
|
||||
+4
-4
@@ -6,9 +6,9 @@ from datetime import datetime, timedelta, UTC
|
||||
from openpilot.system.hardware.hw import Paths
|
||||
from openpilot.system.version import get_version
|
||||
|
||||
# name: jwt signature algorithm
|
||||
KEYS = {"id_rsa": "RS256",
|
||||
"id_ecdsa": "ES256"}
|
||||
# name : jwt signature algorithm
|
||||
KEYS = {"id_rsa" : "RS256",
|
||||
"id_ecdsa" : "ES256"}
|
||||
|
||||
|
||||
class BaseApi:
|
||||
@@ -62,7 +62,7 @@ class BaseApi:
|
||||
return requests.request(method, f"{self.api_host}/{endpoint}", timeout=timeout, headers=headers, json=json, params=params)
|
||||
|
||||
@staticmethod
|
||||
def get_key_pair() -> tuple[str, str, str] | tuple[None, None, None]:
|
||||
def get_key_pair():
|
||||
for key in KEYS:
|
||||
if os.path.isfile(Paths.persist_root() + f'/comma/{key}') and os.path.isfile(Paths.persist_root() + f'/comma/{key}.pub'):
|
||||
with open(Paths.persist_root() + f'/comma/{key}') as private, open(Paths.persist_root() + f'/comma/{key}.pub') as public:
|
||||
|
||||
+1
-1
@@ -1 +1 @@
|
||||
#define DEFAULT_MODEL "Dark Souls 2 (Default)"
|
||||
#define DEFAULT_MODEL "The Cool People (Default)"
|
||||
|
||||
@@ -71,7 +71,6 @@ inline static std::unordered_map<std::string, ParamKeyAttributes> keys = {
|
||||
{"LastGPSPosition", {PERSISTENT, STRING}},
|
||||
{"LastManagerExitReason", {CLEAR_ON_MANAGER_START, STRING}},
|
||||
{"LastOffroadStatusPacket", {CLEAR_ON_MANAGER_START | CLEAR_ON_OFFROAD_TRANSITION, JSON}},
|
||||
{"LastAgnosPowerMonitorShutdown", {CLEAR_ON_MANAGER_START, STRING}},
|
||||
{"LastPowerDropDetected", {CLEAR_ON_MANAGER_START, STRING}},
|
||||
{"LastUpdateException", {CLEAR_ON_MANAGER_START, STRING}},
|
||||
{"LastUpdateRouteCount", {PERSISTENT, INT, "0"}},
|
||||
@@ -133,8 +132,6 @@ inline static std::unordered_map<std::string, ParamKeyAttributes> keys = {
|
||||
{"Version", {PERSISTENT, STRING}},
|
||||
|
||||
// --- sunnypilot params --- //
|
||||
{"AccelPersonality", {PERSISTENT | BACKUP, INT, std::to_string(static_cast<int>(cereal::LongitudinalPlanSP::AccelerationPersonality::NORMAL))}},
|
||||
{"AccelPersonalityEnabled", {PERSISTENT | BACKUP, BOOL, "1"}},
|
||||
{"ApiCache_DriveStats", {PERSISTENT, JSON}},
|
||||
{"AutoLaneChangeBsmDelay", {PERSISTENT | BACKUP, BOOL, "0"}},
|
||||
{"AutoLaneChangeTimer", {PERSISTENT | BACKUP, INT, "0"}},
|
||||
|
||||
@@ -1,7 +1,7 @@
|
||||
import os
|
||||
from uuid import uuid4
|
||||
|
||||
from openpilot.common.utils import atomic_write
|
||||
from openpilot.common.utils import atomic_write_in_dir
|
||||
|
||||
|
||||
class TestFileHelpers:
|
||||
@@ -15,5 +15,5 @@ class TestFileHelpers:
|
||||
assert f.read() == "test"
|
||||
os.remove(path)
|
||||
|
||||
def test_atomic_write(self):
|
||||
self.run_atomic_write_func(atomic_write)
|
||||
def test_atomic_write_in_dir(self):
|
||||
self.run_atomic_write_func(atomic_write_in_dir)
|
||||
|
||||
+2
-2
@@ -32,8 +32,8 @@ class CallbackReader:
|
||||
|
||||
|
||||
@contextlib.contextmanager
|
||||
def atomic_write(path: str, mode: str = 'w', buffering: int = -1, encoding: str | None = None, newline: str | None = None,
|
||||
overwrite: bool = False):
|
||||
def atomic_write_in_dir(path: str, mode: str = 'w', buffering: int = -1, encoding: str | None = None, newline: str | None = None,
|
||||
overwrite: bool = False):
|
||||
"""Write to a file atomically using a temporary file in the same directory as the destination file."""
|
||||
dir_name = os.path.dirname(path)
|
||||
|
||||
|
||||
+1
-1
@@ -1 +1 @@
|
||||
#define COMMA_VERSION "0.10.3"
|
||||
#define COMMA_VERSION "0.10.2"
|
||||
|
||||
+2
-2
@@ -20,7 +20,7 @@ A supported vehicle is one that just works when you install a comma device. All
|
||||
|Audi|Q3 2019-24|Adaptive Cruise Control (ACC) & Lane Assist|openpilot available[<sup>1,15</sup>](#footnotes)|0 mph|0 mph|[](##)|[](##)|<details><summary>Parts</summary><sub>- 1 OBD-C cable (2 ft)<br>- 1 USB-C coupler<br>- 1 VW J533 connector<br>- 1 comma four<br>- 1 harness box<br>- 1 long OBD-C cable (9.5 ft)<br>- 1 mount<br><a href="https://comma.ai/shop/comma-3x?harness=Audi Q3 2019-24">Buy Here</a></sub></details>|||
|
||||
|Audi|RS3 2018|Adaptive Cruise Control (ACC) & Lane Assist|openpilot available[<sup>1,15</sup>](#footnotes)|0 mph|0 mph|[](##)|[](##)|<details><summary>Parts</summary><sub>- 1 OBD-C cable (2 ft)<br>- 1 USB-C coupler<br>- 1 VW J533 connector<br>- 1 comma four<br>- 1 harness box<br>- 1 long OBD-C cable (9.5 ft)<br>- 1 mount<br><a href="https://comma.ai/shop/comma-3x?harness=Audi RS3 2018">Buy Here</a></sub></details>|||
|
||||
|Audi|S3 2015-17|Adaptive Cruise Control (ACC) & Lane Assist|openpilot available[<sup>1,15</sup>](#footnotes)|0 mph|0 mph|[](##)|[](##)|<details><summary>Parts</summary><sub>- 1 OBD-C cable (2 ft)<br>- 1 USB-C coupler<br>- 1 VW J533 connector<br>- 1 comma four<br>- 1 harness box<br>- 1 long OBD-C cable (9.5 ft)<br>- 1 mount<br><a href="https://comma.ai/shop/comma-3x?harness=Audi S3 2015-17">Buy Here</a></sub></details>|||
|
||||
|Chevrolet|Bolt EUV 2022-23|Premier or Premier Redline Trim, without Super Cruise Package|openpilot available[<sup>1</sup>](#footnotes)|3 mph|6 mph|[](##)|[](##)|<details><summary>Parts</summary><sub>- 1 GM connector<br>- 1 OBD-C cable (2 ft)<br>- 1 comma four<br>- 1 harness box<br>- 1 mount<br><a href="https://comma.ai/shop/comma-3x?harness=Chevrolet Bolt EUV 2022-23">Buy Here</a></sub></details>|<a href="https://youtu.be/xvwzGMUA210" target="_blank"><img height="18px" src="assets/icon-youtube.svg"></img></a>||
|
||||
|Chevrolet|Bolt EUV 2022-23|Premier or Premier Redline Trim without Super Cruise Package|openpilot available[<sup>1</sup>](#footnotes)|3 mph|6 mph|[](##)|[](##)|<details><summary>Parts</summary><sub>- 1 GM connector<br>- 1 OBD-C cable (2 ft)<br>- 1 comma four<br>- 1 harness box<br>- 1 mount<br><a href="https://comma.ai/shop/comma-3x?harness=Chevrolet Bolt EUV 2022-23">Buy Here</a></sub></details>|<a href="https://youtu.be/xvwzGMUA210" target="_blank"><img height="18px" src="assets/icon-youtube.svg"></img></a>||
|
||||
|Chevrolet|Bolt EV 2022-23|2LT Trim with Adaptive Cruise Control Package|openpilot available[<sup>1</sup>](#footnotes)|3 mph|6 mph|[](##)|[](##)|<details><summary>Parts</summary><sub>- 1 GM connector<br>- 1 OBD-C cable (2 ft)<br>- 1 comma four<br>- 1 harness box<br>- 1 mount<br><a href="https://comma.ai/shop/comma-3x?harness=Chevrolet Bolt EV 2022-23">Buy Here</a></sub></details>|||
|
||||
|Chevrolet|Bolt EV Non-ACC 2017|Adaptive Cruise Control (ACC)|Stock|24 mph|7 mph|[](##)|[](##)|<details><summary>Parts</summary><sub>- 1 GM connector<br>- 1 OBD-C cable (2 ft)<br>- 1 comma four<br>- 1 harness box<br>- 1 mount<br><a href="https://comma.ai/shop/comma-3x?harness=Chevrolet Bolt EV Non-ACC 2017">Buy Here</a></sub></details>|||
|
||||
|Chevrolet|Bolt EV Non-ACC 2018-21|Adaptive Cruise Control (ACC)|Stock|24 mph|7 mph|[](##)|[](##)|<details><summary>Parts</summary><sub>- 1 GM connector<br>- 1 OBD-C cable (2 ft)<br>- 1 comma four<br>- 1 harness box<br>- 1 mount<br><a href="https://comma.ai/shop/comma-3x?harness=Chevrolet Bolt EV Non-ACC 2018-21">Buy Here</a></sub></details>|||
|
||||
@@ -384,7 +384,7 @@ If your car has the following packages or features, then it's a good candidate f
|
||||
|
||||
| Make | Required Package/Features |
|
||||
| ---- | ------------------------- |
|
||||
| Acura | Any car with AcuraWatch will work. AcuraWatch comes standard on many newer models. |
|
||||
| Acura | Any car with AcuraWatch Plus will work. AcuraWatch Plus comes standard on many newer models. |
|
||||
| Ford | Any car with Lane Centering will likely work. |
|
||||
| Honda | Any car with Honda Sensing will work. Honda Sensing comes standard on many newer models. |
|
||||
| Subaru | Any car with EyeSight will work. EyeSight comes standard on many newer models. |
|
||||
|
||||
@@ -31,7 +31,7 @@ We'll run the `replay` tool with the demo route to get data streaming for testin
|
||||
tools/replay/replay --demo
|
||||
|
||||
# in terminal 2
|
||||
./selfdrive/ui/ui.py
|
||||
selfdrive/ui/ui
|
||||
```
|
||||
|
||||
The openpilot UI should launch and show a replay of the demo route.
|
||||
@@ -43,36 +43,39 @@ If you have your own comma device, you can replace `--demo` with one of your own
|
||||
|
||||
Now let’s update the speed display color in the UI.
|
||||
|
||||
Search for the function responsible for rendering the current speed:
|
||||
Search for the function responsible for rendering UI text:
|
||||
```bash
|
||||
git grep "_draw_current_speed" selfdrive/ui/onroad/hud_renderer.py
|
||||
git grep "drawText" selfdrive/ui/qt/onroad/hud.cc
|
||||
```
|
||||
|
||||
You'll find the relevant code inside `selfdrive/ui/onroad/hud_renderer.py`, in this function:
|
||||
You’ll find the relevant code inside `selfdrive/ui/qt/onroad/hud.cc`, in this function:
|
||||
|
||||
```python
|
||||
def _draw_current_speed(self, rect: rl.Rectangle) -> None:
|
||||
"""Draw the current vehicle speed and unit."""
|
||||
speed_text = str(round(self.speed))
|
||||
speed_text_size = measure_text_cached(self._font_bold, speed_text, FONT_SIZES.current_speed)
|
||||
speed_pos = rl.Vector2(rect.x + rect.width / 2 - speed_text_size.x / 2, 180 - speed_text_size.y / 2)
|
||||
rl.draw_text_ex(self._font_bold, speed_text, speed_pos, FONT_SIZES.current_speed, 0, COLORS.white) # <- this sets the speed text color
|
||||
```cpp
|
||||
void HudRenderer::drawText(QPainter &p, int x, int y, const QString &text, int alpha) {
|
||||
QRect real_rect = p.fontMetrics().boundingRect(text);
|
||||
real_rect.moveCenter({x, y - real_rect.height() / 2});
|
||||
|
||||
p.setPen(QColor(0xff, 0xff, 0xff, alpha)); // <- this sets the speed text color
|
||||
p.drawText(real_rect.x(), real_rect.bottom(), text);
|
||||
}
|
||||
```
|
||||
|
||||
Change `COLORS.white` to make it **blue** instead of white. A nice soft blue is `#8080FF`, which you can change inline:
|
||||
Change the `QColor(...)` line to make it **blue** instead of white. A nice soft blue is `#8080FF`, which translates to:
|
||||
|
||||
```diff
|
||||
- rl.draw_text_ex(self._font_bold, speed_text, speed_pos, FONT_SIZES.current_speed, 0, COLORS.white)
|
||||
+ rl.draw_text_ex(self._font_bold, speed_text, speed_pos, FONT_SIZES.current_speed, 0, rl.Color(0x80, 0x80, 0xFF, 255))
|
||||
- p.setPen(QColor(0xff, 0xff, 0xff, alpha));
|
||||
+ p.setPen(QColor(0x80, 0x80, 0xFF, alpha));
|
||||
```
|
||||
|
||||
This change will tint all speed-related UI text to blue with the same transparency (`alpha`).
|
||||
|
||||
---
|
||||
|
||||
## 4. Re-run the UI
|
||||
## 4. Rebuild the UI
|
||||
|
||||
After making changes, re-run the UI to see your new UI:
|
||||
After making changes, rebuild Openpilot so your new UI is compiled:
|
||||
```bash
|
||||
./selfdrive/ui/ui.py
|
||||
scons -j$(nproc) && selfdrive/ui/ui
|
||||
```
|
||||
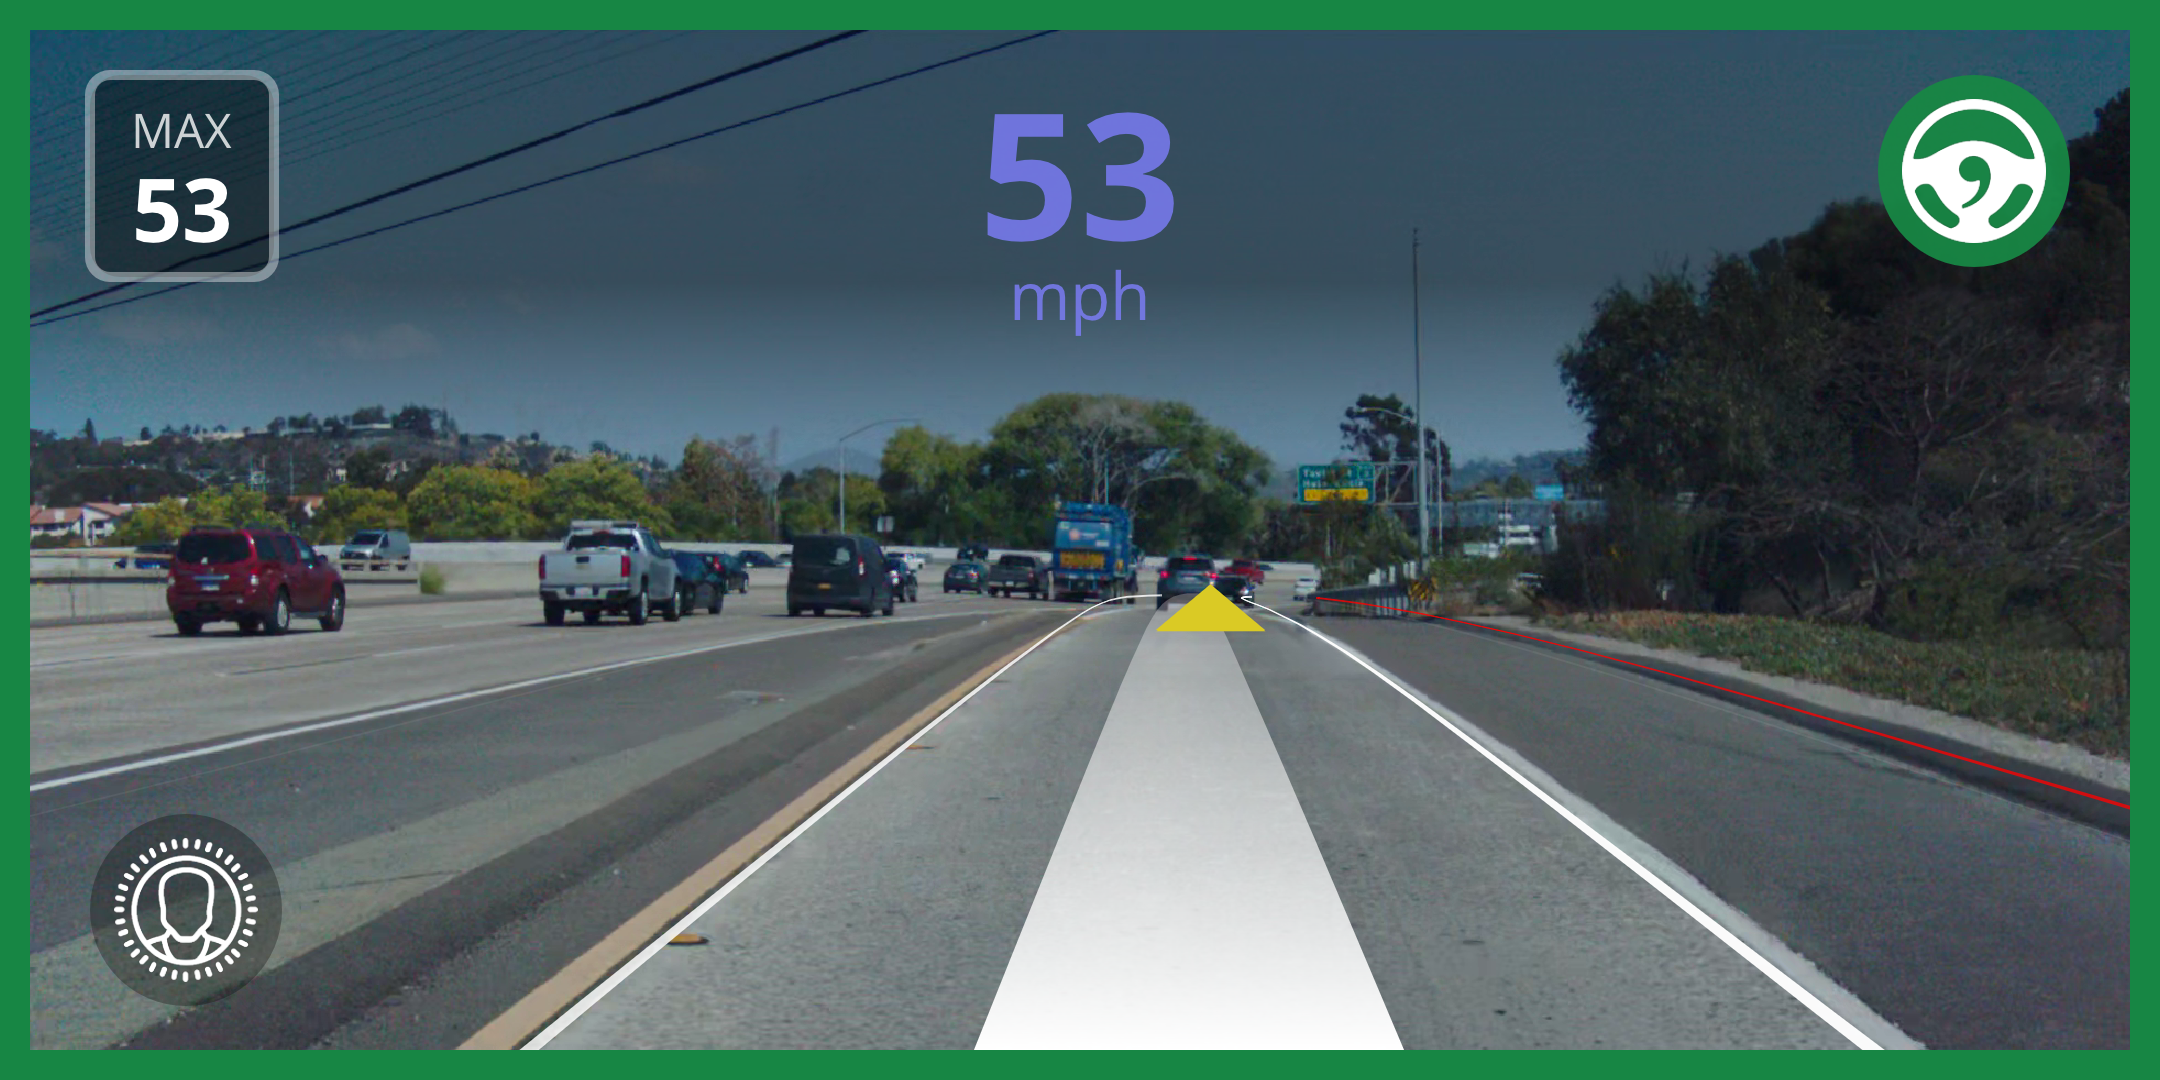
|
||||
|
||||
|
||||
+1
-1
Submodule opendbc_repo updated: f746884333...61bf5a90c5
+1
-1
Submodule panda updated: 5f3c09c910...dee9061b2a
+3
-4
@@ -85,7 +85,6 @@ docs = [
|
||||
]
|
||||
|
||||
testing = [
|
||||
"coverage",
|
||||
"hypothesis ==6.47.*",
|
||||
"mypy",
|
||||
"pytest",
|
||||
@@ -116,7 +115,7 @@ dev = [
|
||||
"pyautogui",
|
||||
"pygame",
|
||||
"pyopencl; platform_machine != 'aarch64'", # broken on arm64
|
||||
"pytools>=2025.1.6; platform_machine != 'aarch64'",
|
||||
"pytools < 2024.1.11; platform_machine != 'aarch64'", # pyopencl use a broken version
|
||||
"pywinctl",
|
||||
"pyprof2calltree",
|
||||
"tabulate",
|
||||
@@ -126,7 +125,7 @@ dev = [
|
||||
|
||||
tools = [
|
||||
"metadrive-simulator @ https://github.com/commaai/metadrive/releases/download/MetaDrive-minimal-0.4.2.4/metadrive_simulator-0.4.2.4-py3-none-any.whl ; (platform_machine != 'aarch64')",
|
||||
"dearpygui>=2.1.0; (sys_platform != 'linux' or platform_machine != 'aarch64')", # not vended for linux aarch64
|
||||
"dearpygui>=2.1.0",
|
||||
]
|
||||
|
||||
[project.urls]
|
||||
@@ -227,7 +226,7 @@ lint.select = [
|
||||
"TRY203", "TRY400", "TRY401", # try/excepts
|
||||
"RUF008", "RUF100",
|
||||
"TID251",
|
||||
"PLE", "PLR1704",
|
||||
"PLR1704",
|
||||
]
|
||||
lint.ignore = [
|
||||
"E741",
|
||||
|
||||
@@ -1,26 +0,0 @@
|
||||
#!/usr/bin/env bash
|
||||
set -e
|
||||
|
||||
DIR="$( cd "$( dirname "${BASH_SOURCE[0]}" )" >/dev/null && pwd )"
|
||||
cd $DIR/../../tinygrad_repo
|
||||
|
||||
GREEN='\033[0;32m'
|
||||
NC='\033[0m'
|
||||
|
||||
|
||||
#export DEBUG=2
|
||||
export PYTHONPATH=.
|
||||
export AM_RESET=1
|
||||
export AMD=1
|
||||
export AMD_IFACE=USB
|
||||
export AMD_LLVM=1
|
||||
|
||||
python3 -m unittest -q --buffer test.test_tiny.TestTiny.test_plus \
|
||||
> /tmp/test_tiny.log 2>&1 || (cat /tmp/test_tiny.log; exit 1)
|
||||
printf "${GREEN}Booted in ${SECONDS}s${NC}\n"
|
||||
printf "${GREEN}=============${NC}\n"
|
||||
|
||||
printf "\n\n"
|
||||
printf "${GREEN}Transfer speeds:${NC}\n"
|
||||
printf "${GREEN}================${NC}\n"
|
||||
python3 test/external/external_test_usb_asm24.py TestDevCopySpeeds
|
||||
@@ -1,3 +1,3 @@
|
||||
version https://git-lfs.github.com/spec/v1
|
||||
oid sha256:42bd04a57b527c787a0555503e02a203f7d672c12d448769a3f41f17befbf013
|
||||
size 48044
|
||||
oid sha256:c94582be9d921146b3c356e08a7352700c309cb407877c1180542811b2d637fa
|
||||
size 48078
|
||||
|
||||
@@ -1,3 +1,3 @@
|
||||
version https://git-lfs.github.com/spec/v1
|
||||
oid sha256:b1e177499d9439367179cc57a6301b6162393972e3a136cc35c5fdac026bf10a
|
||||
size 48044
|
||||
oid sha256:bc2b12bfe816a79307660b6b3d2de87a7643c6ccbfc9d1b33804645ad717682a
|
||||
size 48078
|
||||
|
||||
@@ -1,19 +0,0 @@
|
||||
import numpy as np
|
||||
from scipy.io import wavfile
|
||||
|
||||
|
||||
sr = 48000
|
||||
max_int16 = 2**15 - 1
|
||||
|
||||
def harmonic_beep(freq, duration_seconds):
|
||||
n_total = int(sr * duration_seconds)
|
||||
|
||||
signal = np.sin(2 * np.pi * freq * np.arange(n_total) / sr)
|
||||
x = np.arange(n_total)
|
||||
exp_scale = np.exp(-x/5.5e3)
|
||||
return max_int16 * signal * exp_scale
|
||||
|
||||
engage_beep = harmonic_beep(1661.219, 0.5)
|
||||
wavfile.write("engage.wav", sr, engage_beep.astype(np.int16))
|
||||
disengage_beep = harmonic_beep(1318.51, 0.5)
|
||||
wavfile.write("disengage.wav", sr, disengage_beep.astype(np.int16))
|
||||
@@ -42,7 +42,7 @@ If your car has the following packages or features, then it's a good candidate f
|
||||
|
||||
| Make | Required Package/Features |
|
||||
| ---- | ------------------------- |
|
||||
| Acura | Any car with AcuraWatch will work. AcuraWatch comes standard on many newer models. |
|
||||
| Acura | Any car with AcuraWatch Plus will work. AcuraWatch Plus comes standard on many newer models. |
|
||||
| Ford | Any car with Lane Centering will likely work. |
|
||||
| Honda | Any car with Honda Sensing will work. Honda Sensing comes standard on many newer models. |
|
||||
| Subaru | Any car with EyeSight will work. EyeSight comes standard on many newer models. |
|
||||
|
||||
@@ -26,18 +26,6 @@ class MockCarState:
|
||||
return CS, CS_SP
|
||||
|
||||
|
||||
BRAND_EXTRA_GEARS = {
|
||||
'ford': [GearShifter.low, GearShifter.manumatic],
|
||||
'nissan': [GearShifter.brake],
|
||||
'chrysler': [GearShifter.low],
|
||||
'honda': [GearShifter.sport],
|
||||
'toyota': [GearShifter.sport],
|
||||
'gm': [GearShifter.sport, GearShifter.low, GearShifter.eco, GearShifter.manumatic],
|
||||
'volkswagen': [GearShifter.eco, GearShifter.sport, GearShifter.manumatic],
|
||||
'hyundai': [GearShifter.sport, GearShifter.manumatic]
|
||||
}
|
||||
|
||||
|
||||
class CarSpecificEvents:
|
||||
def __init__(self, CP: structs.CarParams):
|
||||
self.CP = CP
|
||||
@@ -48,13 +36,17 @@ class CarSpecificEvents:
|
||||
self.silent_steer_warning = True
|
||||
|
||||
def update(self, CS: car.CarState, CS_prev: car.CarState, CC: car.CarControl):
|
||||
extra_gears = BRAND_EXTRA_GEARS.get(self.CP.brand, None)
|
||||
|
||||
if self.CP.brand in ('body', 'mock'):
|
||||
events = Events()
|
||||
|
||||
elif self.CP.brand == 'ford':
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=[GearShifter.low, GearShifter.manumatic])
|
||||
|
||||
elif self.CP.brand == 'nissan':
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=[GearShifter.brake])
|
||||
|
||||
elif self.CP.brand == 'chrysler':
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=extra_gears)
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=[GearShifter.low])
|
||||
|
||||
# Low speed steer alert hysteresis logic
|
||||
if self.CP.minSteerSpeed > 0. and CS.vEgo < (self.CP.minSteerSpeed + 0.5):
|
||||
@@ -65,7 +57,7 @@ class CarSpecificEvents:
|
||||
events.add(EventName.belowSteerSpeed)
|
||||
|
||||
elif self.CP.brand == 'honda':
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=extra_gears, pcm_enable=False)
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=[GearShifter.sport], pcm_enable=False)
|
||||
|
||||
if self.CP.pcmCruise and CS.vEgo < self.CP.minEnableSpeed:
|
||||
events.add(EventName.belowEngageSpeed)
|
||||
@@ -87,7 +79,7 @@ class CarSpecificEvents:
|
||||
|
||||
elif self.CP.brand == 'toyota':
|
||||
# TODO: when we check for unexpected disengagement, check gear not S1, S2, S3
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=extra_gears)
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=[GearShifter.sport])
|
||||
|
||||
if self.CP.openpilotLongitudinalControl:
|
||||
if CS.cruiseState.standstill and not CS.brakePressed:
|
||||
@@ -102,7 +94,9 @@ class CarSpecificEvents:
|
||||
events.add(EventName.manualRestart)
|
||||
|
||||
elif self.CP.brand == 'gm':
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=extra_gears, pcm_enable=self.CP.pcmCruise)
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=[GearShifter.sport, GearShifter.low,
|
||||
GearShifter.eco, GearShifter.manumatic],
|
||||
pcm_enable=self.CP.pcmCruise)
|
||||
|
||||
# Enabling at a standstill with brake is allowed
|
||||
# TODO: verify 17 Volt can enable for the first time at a stop and allow for all GMs
|
||||
@@ -113,7 +107,8 @@ class CarSpecificEvents:
|
||||
events.add(EventName.resumeRequired)
|
||||
|
||||
elif self.CP.brand == 'volkswagen':
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=extra_gears, pcm_enable=self.CP.pcmCruise)
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=[GearShifter.eco, GearShifter.sport, GearShifter.manumatic],
|
||||
pcm_enable=self.CP.pcmCruise)
|
||||
|
||||
if self.CP.openpilotLongitudinalControl:
|
||||
if CS.vEgo < self.CP.minEnableSpeed + 0.5:
|
||||
@@ -126,14 +121,15 @@ class CarSpecificEvents:
|
||||
# events.add(EventName.steerTimeLimit)
|
||||
|
||||
elif self.CP.brand == 'hyundai':
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=extra_gears, pcm_enable=self.CP.pcmCruise, allow_button_cancel=False)
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=(GearShifter.sport, GearShifter.manumatic),
|
||||
pcm_enable=self.CP.pcmCruise, allow_button_cancel=False)
|
||||
|
||||
else:
|
||||
events = self.create_common_events(CS, CS_prev, extra_gears=extra_gears)
|
||||
events = self.create_common_events(CS, CS_prev)
|
||||
|
||||
return events
|
||||
|
||||
def create_common_events(self, CS: structs.CarState, CS_prev: car.CarState, extra_gears: list | None = None, pcm_enable=True,
|
||||
def create_common_events(self, CS: structs.CarState, CS_prev: car.CarState, extra_gears=None, pcm_enable=True,
|
||||
allow_button_cancel=True):
|
||||
events = Events()
|
||||
|
||||
|
||||
@@ -22,17 +22,15 @@ from openpilot.sunnypilot.selfdrive.controls.lib.latcontrol_torque_ext import La
|
||||
# Additionally, there is friction in the steering wheel that needs
|
||||
# to be overcome to move it at all, this is compensated for too.
|
||||
|
||||
KP = 0.8
|
||||
KI = 0.15
|
||||
|
||||
KP = 1.0
|
||||
KI = 0.3
|
||||
KD = 0.0
|
||||
INTERP_SPEEDS = [1, 1.5, 2.0, 3.0, 5, 7.5, 10, 15, 30]
|
||||
KP_INTERP = [250, 120, 65, 30, 11.5, 5.5, 3.5, 2.0, KP]
|
||||
|
||||
LP_FILTER_CUTOFF_HZ = 1.2
|
||||
JERK_LOOKAHEAD_SECONDS = 0.19
|
||||
JERK_GAIN = 0.3
|
||||
LAT_ACCEL_REQUEST_BUFFER_SECONDS = 1.0
|
||||
VERSION = 1
|
||||
VERSION = 0
|
||||
|
||||
class LatControlTorque(LatControl):
|
||||
def __init__(self, CP, CP_SP, CI, dt):
|
||||
@@ -40,13 +38,13 @@ class LatControlTorque(LatControl):
|
||||
self.torque_params = CP.lateralTuning.torque.as_builder()
|
||||
self.torque_from_lateral_accel = CI.torque_from_lateral_accel()
|
||||
self.lateral_accel_from_torque = CI.lateral_accel_from_torque()
|
||||
self.pid = PIDController([INTERP_SPEEDS, KP_INTERP], KI, rate=1/self.dt)
|
||||
self.pid = PIDController([INTERP_SPEEDS, KP_INTERP], KI, KD, rate=1/self.dt)
|
||||
self.update_limits()
|
||||
self.steering_angle_deadzone_deg = self.torque_params.steeringAngleDeadzoneDeg
|
||||
self.lat_accel_request_buffer_len = int(LAT_ACCEL_REQUEST_BUFFER_SECONDS / self.dt)
|
||||
self.lat_accel_request_buffer = deque([0.] * self.lat_accel_request_buffer_len , maxlen=self.lat_accel_request_buffer_len)
|
||||
self.lookahead_frames = int(JERK_LOOKAHEAD_SECONDS / self.dt)
|
||||
self.jerk_filter = FirstOrderFilter(0.0, 1 / (2 * np.pi * LP_FILTER_CUTOFF_HZ), self.dt)
|
||||
self.previous_measurement = 0.0
|
||||
self.measurement_rate_filter = FirstOrderFilter(0.0, 1 / (2 * np.pi * LP_FILTER_CUTOFF_HZ), self.dt)
|
||||
|
||||
self.extension = LatControlTorqueExt(self, CP, CP_SP, CI)
|
||||
|
||||
@@ -78,15 +76,17 @@ class LatControlTorque(LatControl):
|
||||
|
||||
delay_frames = int(np.clip(lat_delay / self.dt, 1, self.lat_accel_request_buffer_len))
|
||||
expected_lateral_accel = self.lat_accel_request_buffer[-delay_frames]
|
||||
lookahead_idx = int(np.clip(-delay_frames + self.lookahead_frames, -self.lat_accel_request_buffer_len+1, -2))
|
||||
raw_lateral_jerk = (self.lat_accel_request_buffer[lookahead_idx+1] - self.lat_accel_request_buffer[lookahead_idx-1]) / (2 * self.dt)
|
||||
desired_lateral_jerk = self.jerk_filter.update(raw_lateral_jerk)
|
||||
# TODO factor out lateral jerk from error to later replace it with delay independent alternative
|
||||
future_desired_lateral_accel = desired_curvature * CS.vEgo ** 2
|
||||
self.lat_accel_request_buffer.append(future_desired_lateral_accel)
|
||||
gravity_adjusted_future_lateral_accel = future_desired_lateral_accel - roll_compensation
|
||||
setpoint = expected_lateral_accel
|
||||
desired_lateral_jerk = (future_desired_lateral_accel - expected_lateral_accel) / lat_delay
|
||||
|
||||
measurement = measured_curvature * CS.vEgo ** 2
|
||||
measurement_rate = self.measurement_rate_filter.update((measurement - self.previous_measurement) / self.dt)
|
||||
self.previous_measurement = measurement
|
||||
|
||||
setpoint = lat_delay * desired_lateral_jerk + expected_lateral_accel
|
||||
error = setpoint - measurement
|
||||
|
||||
# do error correction in lateral acceleration space, convert at end to handle non-linear torque responses correctly
|
||||
@@ -94,10 +94,15 @@ class LatControlTorque(LatControl):
|
||||
ff = gravity_adjusted_future_lateral_accel
|
||||
# latAccelOffset corrects roll compensation bias from device roll misalignment relative to car roll
|
||||
ff -= self.torque_params.latAccelOffset
|
||||
ff += get_friction(error + JERK_GAIN * desired_lateral_jerk, lateral_accel_deadzone, FRICTION_THRESHOLD, self.torque_params)
|
||||
# TODO jerk is weighted by lat_delay for legacy reasons, but should be made independent of it
|
||||
ff += get_friction(error, lateral_accel_deadzone, FRICTION_THRESHOLD, self.torque_params)
|
||||
|
||||
freeze_integrator = steer_limited_by_safety or CS.steeringPressed or CS.vEgo < 5
|
||||
output_lataccel = self.pid.update(pid_log.error, speed=CS.vEgo, feedforward=ff, freeze_integrator=freeze_integrator)
|
||||
output_lataccel = self.pid.update(pid_log.error,
|
||||
-measurement_rate,
|
||||
feedforward=ff,
|
||||
speed=CS.vEgo,
|
||||
freeze_integrator=freeze_integrator)
|
||||
output_torque = self.torque_from_lateral_accel(output_lataccel, self.torque_params)
|
||||
|
||||
# Lateral acceleration torque controller extension updates
|
||||
|
||||
@@ -10,8 +10,6 @@ from openpilot.common.swaglog import cloudlog
|
||||
from openpilot.selfdrive.modeld.constants import index_function
|
||||
from openpilot.selfdrive.controls.radard import _LEAD_ACCEL_TAU
|
||||
|
||||
from openpilot.sunnypilot.selfdrive.controls.lib.accel_personality.accel_controller import AccelPersonalityController
|
||||
|
||||
if __name__ == '__main__': # generating code
|
||||
from openpilot.third_party.acados.acados_template import AcadosModel, AcadosOcp, AcadosOcpSolver
|
||||
else:
|
||||
@@ -230,7 +228,6 @@ class LongitudinalMpc:
|
||||
self.solver = AcadosOcpSolverCython(MODEL_NAME, ACADOS_SOLVER_TYPE, N)
|
||||
self.reset()
|
||||
self.source = SOURCES[2]
|
||||
self.accel_controller = AccelPersonalityController()
|
||||
|
||||
def reset(self):
|
||||
# self.solver = AcadosOcpSolverCython(MODEL_NAME, ACADOS_SOLVER_TYPE, N)
|
||||
@@ -335,13 +332,6 @@ class LongitudinalMpc:
|
||||
v_ego = self.x0[1]
|
||||
self.status = radarstate.leadOne.status or radarstate.leadTwo.status
|
||||
|
||||
|
||||
if self.accel_controller.is_enabled():
|
||||
min_accel = self.accel_controller.get_min_accel(v_ego)
|
||||
else:
|
||||
min_accel = CRUISE_MIN_ACCEL
|
||||
a_cruise_min = min_accel
|
||||
|
||||
lead_xv_0 = self.process_lead(radarstate.leadOne)
|
||||
lead_xv_1 = self.process_lead(radarstate.leadTwo)
|
||||
|
||||
@@ -360,7 +350,7 @@ class LongitudinalMpc:
|
||||
|
||||
# Fake an obstacle for cruise, this ensures smooth acceleration to set speed
|
||||
# when the leads are no factor.
|
||||
v_lower = v_ego + (T_IDXS * a_cruise_min * 1.05)
|
||||
v_lower = v_ego + (T_IDXS * CRUISE_MIN_ACCEL * 1.05)
|
||||
# TODO does this make sense when max_a is negative?
|
||||
v_upper = v_ego + (T_IDXS * CRUISE_MAX_ACCEL * 1.05)
|
||||
v_cruise_clipped = np.clip(v_cruise * np.ones(N+1),
|
||||
|
||||
@@ -124,11 +124,7 @@ class LongitudinalPlanner(LongitudinalPlannerSP):
|
||||
prev_accel_constraint = not (reset_state or sm['carState'].standstill)
|
||||
|
||||
if mode == 'acc':
|
||||
if self.accel_controller.is_enabled():
|
||||
max_accel = self.accel_controller.get_max_accel(v_ego)
|
||||
accel_clip = [ACCEL_MIN, max_accel]
|
||||
else:
|
||||
accel_clip = [ACCEL_MIN, get_max_accel(v_ego)]
|
||||
accel_clip = [ACCEL_MIN, get_max_accel(v_ego)]
|
||||
steer_angle_without_offset = sm['carState'].steeringAngleDeg - sm['liveParameters'].angleOffsetDeg
|
||||
accel_clip = limit_accel_in_turns(v_ego, steer_angle_without_offset, accel_clip, self.CP)
|
||||
else:
|
||||
|
||||
@@ -172,7 +172,7 @@ class PoseCalibrator:
|
||||
ned_from_calib_euler = self._ned_from_calib(pose.orientation)
|
||||
angular_velocity_calib = self._transform_calib_from_device(pose.angular_velocity)
|
||||
acceleration_calib = self._transform_calib_from_device(pose.acceleration)
|
||||
velocity_calib = self._transform_calib_from_device(pose.velocity)
|
||||
velocity_calib = self._transform_calib_from_device(pose.angular_velocity)
|
||||
|
||||
return Pose(ned_from_calib_euler, velocity_calib, acceleration_calib, angular_velocity_calib)
|
||||
|
||||
|
||||
@@ -1,3 +1,3 @@
|
||||
version https://git-lfs.github.com/spec/v1
|
||||
oid sha256:f8fe9a71b0fd428a045a82ed50790179f77aa664391198f078e11e7b2cb2c2d7
|
||||
oid sha256:c5a1f0655ddf266ed42ad1980389d96f47cc5e756da1fa3ca1477a920bb9b157
|
||||
size 13926324
|
||||
|
||||
@@ -1,3 +1,3 @@
|
||||
version https://git-lfs.github.com/spec/v1
|
||||
oid sha256:1dc66bc06f250b577653ccbeaa2c6521b3d46749f601d0a1a366419e929ca438
|
||||
oid sha256:8f16d548ea4eb5d01518a9e90d4527cd97c31a84bcaf6f695dead8f0015fecc4
|
||||
size 46271942
|
||||
|
||||
@@ -0,0 +1,102 @@
|
||||
import numpy as np
|
||||
import random
|
||||
|
||||
import cereal.messaging as messaging
|
||||
from msgq.visionipc import VisionIpcServer, VisionStreamType
|
||||
from opendbc.car.car_helpers import get_demo_car_params
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.common.transformations.camera import DEVICE_CAMERAS
|
||||
from openpilot.common.realtime import DT_MDL
|
||||
from openpilot.system.manager.process_config import managed_processes
|
||||
from openpilot.selfdrive.test.process_replay.vision_meta import meta_from_camera_state
|
||||
|
||||
CAM = DEVICE_CAMERAS[("tici", "ar0231")].fcam
|
||||
IMG = np.zeros(int(CAM.width*CAM.height*(3/2)), dtype=np.uint8)
|
||||
IMG_BYTES = IMG.flatten().tobytes()
|
||||
|
||||
|
||||
class TestModeld:
|
||||
|
||||
def setup_method(self):
|
||||
self.vipc_server = VisionIpcServer("camerad")
|
||||
self.vipc_server.create_buffers(VisionStreamType.VISION_STREAM_ROAD, 40, CAM.width, CAM.height)
|
||||
self.vipc_server.create_buffers(VisionStreamType.VISION_STREAM_DRIVER, 40, CAM.width, CAM.height)
|
||||
self.vipc_server.create_buffers(VisionStreamType.VISION_STREAM_WIDE_ROAD, 40, CAM.width, CAM.height)
|
||||
self.vipc_server.start_listener()
|
||||
Params().put("CarParams", get_demo_car_params().to_bytes())
|
||||
|
||||
self.sm = messaging.SubMaster(['modelV2', 'cameraOdometry'])
|
||||
self.pm = messaging.PubMaster(['roadCameraState', 'wideRoadCameraState', 'liveCalibration'])
|
||||
|
||||
managed_processes['modeld'].start()
|
||||
self.pm.wait_for_readers_to_update("roadCameraState", 10)
|
||||
|
||||
def teardown_method(self):
|
||||
managed_processes['modeld'].stop()
|
||||
del self.vipc_server
|
||||
|
||||
def _send_frames(self, frame_id, cams=None):
|
||||
if cams is None:
|
||||
cams = ('roadCameraState', 'wideRoadCameraState')
|
||||
|
||||
cs = None
|
||||
for cam in cams:
|
||||
msg = messaging.new_message(cam)
|
||||
cs = getattr(msg, cam)
|
||||
cs.frameId = frame_id
|
||||
cs.timestampSof = int((frame_id * DT_MDL) * 1e9)
|
||||
cs.timestampEof = int(cs.timestampSof + (DT_MDL * 1e9))
|
||||
cam_meta = meta_from_camera_state(cam)
|
||||
|
||||
self.pm.send(msg.which(), msg)
|
||||
self.vipc_server.send(cam_meta.stream, IMG_BYTES, cs.frameId,
|
||||
cs.timestampSof, cs.timestampEof)
|
||||
return cs
|
||||
|
||||
def _wait(self):
|
||||
self.sm.update(5000)
|
||||
if self.sm['modelV2'].frameId != self.sm['cameraOdometry'].frameId:
|
||||
self.sm.update(1000)
|
||||
|
||||
def test_modeld(self):
|
||||
for n in range(1, 500):
|
||||
cs = self._send_frames(n)
|
||||
self._wait()
|
||||
|
||||
mdl = self.sm['modelV2']
|
||||
assert mdl.frameId == n
|
||||
assert mdl.frameIdExtra == n
|
||||
assert mdl.timestampEof == cs.timestampEof
|
||||
assert mdl.frameAge == 0
|
||||
assert mdl.frameDropPerc == 0
|
||||
|
||||
odo = self.sm['cameraOdometry']
|
||||
assert odo.frameId == n
|
||||
assert odo.timestampEof == cs.timestampEof
|
||||
|
||||
def test_dropped_frames(self):
|
||||
"""
|
||||
modeld should only run on consecutive road frames
|
||||
"""
|
||||
frame_id = -1
|
||||
road_frames = list()
|
||||
for n in range(1, 50):
|
||||
if (random.random() < 0.1) and n > 3:
|
||||
cams = random.choice([(), ('wideRoadCameraState', )])
|
||||
self._send_frames(n, cams)
|
||||
else:
|
||||
self._send_frames(n)
|
||||
road_frames.append(n)
|
||||
self._wait()
|
||||
|
||||
if len(road_frames) < 3 or road_frames[-1] - road_frames[-2] == 1:
|
||||
frame_id = road_frames[-1]
|
||||
|
||||
mdl = self.sm['modelV2']
|
||||
odo = self.sm['cameraOdometry']
|
||||
assert mdl.frameId == frame_id
|
||||
assert mdl.frameIdExtra == frame_id
|
||||
assert odo.frameId == frame_id
|
||||
if n != frame_id:
|
||||
assert not self.sm.updated['modelV2']
|
||||
assert not self.sm.updated['cameraOdometry']
|
||||
@@ -40,8 +40,8 @@ def dmonitoringd_thread():
|
||||
|
||||
# save rhd virtual toggle every 5 mins
|
||||
if (sm['driverStateV2'].frameId % 6000 == 0 and not demo_mode and
|
||||
DM.wheelpos.prob_offseter.filtered_stat.n > DM.settings._WHEELPOS_FILTER_MIN_COUNT and
|
||||
DM.wheel_on_right == (DM.wheelpos.prob_offseter.filtered_stat.M > DM.settings._WHEELPOS_THRESHOLD)):
|
||||
DM.wheelpos_learner.filtered_stat.n > DM.settings._WHEELPOS_FILTER_MIN_COUNT and
|
||||
DM.wheel_on_right == (DM.wheelpos_learner.filtered_stat.M > DM.settings._WHEELPOS_THRESHOLD)):
|
||||
params.put_bool_nonblocking("IsRhdDetected", DM.wheel_on_right)
|
||||
|
||||
def main():
|
||||
|
||||
@@ -40,9 +40,6 @@ class DRIVER_MONITOR_SETTINGS:
|
||||
self._PHONE_THRESH2 = 15.0
|
||||
self._PHONE_MAX_OFFSET = 0.06
|
||||
self._PHONE_MIN_OFFSET = 0.025
|
||||
self._PHONE_DATA_AVG = 0.05
|
||||
self._PHONE_DATA_VAR = 3*0.005
|
||||
self._PHONE_MAX_COUNT = int(360 / self._DT_DMON)
|
||||
|
||||
self._POSE_PITCH_THRESHOLD = 0.3133
|
||||
self._POSE_PITCH_THRESHOLD_SLACK = 0.3237
|
||||
@@ -50,11 +47,9 @@ class DRIVER_MONITOR_SETTINGS:
|
||||
self._POSE_YAW_THRESHOLD = 0.4020
|
||||
self._POSE_YAW_THRESHOLD_SLACK = 0.5042
|
||||
self._POSE_YAW_THRESHOLD_STRICT = self._POSE_YAW_THRESHOLD
|
||||
self._PITCH_NATURAL_OFFSET = 0.011 # initial value before offset is learned
|
||||
self._PITCH_NATURAL_OFFSET = 0.029 # initial value before offset is learned
|
||||
self._PITCH_NATURAL_THRESHOLD = 0.449
|
||||
self._YAW_NATURAL_OFFSET = 0.075 # initial value before offset is learned
|
||||
self._PITCH_NATURAL_VAR = 3*0.01
|
||||
self._YAW_NATURAL_VAR = 3*0.05
|
||||
self._YAW_NATURAL_OFFSET = 0.097 # initial value before offset is learned
|
||||
self._PITCH_MAX_OFFSET = 0.124
|
||||
self._PITCH_MIN_OFFSET = -0.0881
|
||||
self._YAW_MAX_OFFSET = 0.289
|
||||
@@ -75,9 +70,6 @@ class DRIVER_MONITOR_SETTINGS:
|
||||
self._WHEELPOS_CALIB_MIN_SPEED = 11
|
||||
self._WHEELPOS_THRESHOLD = 0.5
|
||||
self._WHEELPOS_FILTER_MIN_COUNT = int(15 / self._DT_DMON) # allow 15 seconds to converge wheel side
|
||||
self._WHEELPOS_DATA_AVG = 0.03
|
||||
self._WHEELPOS_DATA_VAR = 3*5.5e-5
|
||||
self._WHEELPOS_MAX_COUNT = -1
|
||||
|
||||
self._RECOVERY_FACTOR_MAX = 5. # relative to minus step change
|
||||
self._RECOVERY_FACTOR_MIN = 1.25 # relative to minus step change
|
||||
@@ -86,33 +78,30 @@ class DRIVER_MONITOR_SETTINGS:
|
||||
self._MAX_TERMINAL_DURATION = int(30 / self._DT_DMON) # not allowed to engage after 30s of terminal alerts
|
||||
|
||||
class DistractedType:
|
||||
|
||||
NOT_DISTRACTED = 0
|
||||
DISTRACTED_POSE = 1 << 0
|
||||
DISTRACTED_BLINK = 1 << 1
|
||||
DISTRACTED_PHONE = 1 << 2
|
||||
|
||||
class DriverPose:
|
||||
def __init__(self, settings):
|
||||
pitch_filter_raw_priors = (settings._PITCH_NATURAL_OFFSET, settings._PITCH_NATURAL_VAR, 2)
|
||||
yaw_filter_raw_priors = (settings._YAW_NATURAL_OFFSET, settings._YAW_NATURAL_VAR, 2)
|
||||
def __init__(self, max_trackable):
|
||||
self.yaw = 0.
|
||||
self.pitch = 0.
|
||||
self.roll = 0.
|
||||
self.yaw_std = 0.
|
||||
self.pitch_std = 0.
|
||||
self.roll_std = 0.
|
||||
self.pitch_offseter = RunningStatFilter(raw_priors=pitch_filter_raw_priors, max_trackable=settings._POSE_OFFSET_MAX_COUNT)
|
||||
self.yaw_offseter = RunningStatFilter(raw_priors=yaw_filter_raw_priors, max_trackable=settings._POSE_OFFSET_MAX_COUNT)
|
||||
self.pitch_offseter = RunningStatFilter(max_trackable=max_trackable)
|
||||
self.yaw_offseter = RunningStatFilter(max_trackable=max_trackable)
|
||||
self.calibrated = False
|
||||
self.low_std = True
|
||||
self.cfactor_pitch = 1.
|
||||
self.cfactor_yaw = 1.
|
||||
|
||||
class DriverProb:
|
||||
def __init__(self, raw_priors, max_trackable):
|
||||
class DriverPhone:
|
||||
def __init__(self, max_trackable):
|
||||
self.prob = 0.
|
||||
self.prob_offseter = RunningStatFilter(raw_priors=raw_priors, max_trackable=max_trackable)
|
||||
self.prob_offseter = RunningStatFilter(max_trackable=max_trackable)
|
||||
self.prob_calibrated = False
|
||||
|
||||
class DriverBlink:
|
||||
@@ -151,11 +140,9 @@ class DriverMonitoring:
|
||||
self.settings = settings if settings is not None else DRIVER_MONITOR_SETTINGS(device_type=HARDWARE.get_device_type())
|
||||
|
||||
# init driver status
|
||||
wheelpos_filter_raw_priors = (self.settings._WHEELPOS_DATA_AVG, self.settings._WHEELPOS_DATA_VAR, 2)
|
||||
phone_filter_raw_priors = (self.settings._PHONE_DATA_AVG, self.settings._PHONE_DATA_VAR, 2)
|
||||
self.wheelpos = DriverProb(raw_priors=wheelpos_filter_raw_priors, max_trackable=self.settings._WHEELPOS_MAX_COUNT)
|
||||
self.phone = DriverProb(raw_priors=phone_filter_raw_priors, max_trackable=self.settings._PHONE_MAX_COUNT)
|
||||
self.pose = DriverPose(settings=self.settings)
|
||||
self.wheelpos_learner = RunningStatFilter()
|
||||
self.pose = DriverPose(self.settings._POSE_OFFSET_MAX_COUNT)
|
||||
self.phone = DriverPhone(self.settings._POSE_OFFSET_MAX_COUNT)
|
||||
self.blink = DriverBlink()
|
||||
|
||||
self.always_on = always_on
|
||||
@@ -247,11 +234,8 @@ class DriverMonitoring:
|
||||
self.settings._YAW_MIN_OFFSET), self.settings._YAW_MAX_OFFSET)
|
||||
pitch_error = 0 if pitch_error > 0 else abs(pitch_error) # no positive pitch limit
|
||||
yaw_error = abs(yaw_error)
|
||||
|
||||
pitch_threshold = self.settings._POSE_PITCH_THRESHOLD * self.pose.cfactor_pitch if self.pose.calibrated else self.settings._PITCH_NATURAL_THRESHOLD
|
||||
yaw_threshold = self.settings._POSE_YAW_THRESHOLD * self.pose.cfactor_yaw
|
||||
|
||||
if pitch_error > pitch_threshold or yaw_error > yaw_threshold:
|
||||
if pitch_error > (self.settings._POSE_PITCH_THRESHOLD*self.pose.cfactor_pitch if self.pose.calibrated else self.settings._PITCH_NATURAL_THRESHOLD) or \
|
||||
yaw_error > self.settings._POSE_YAW_THRESHOLD*self.pose.cfactor_yaw:
|
||||
distracted_types.append(DistractedType.DISTRACTED_POSE)
|
||||
|
||||
if (self.blink.left + self.blink.right)*0.5 > self.settings._BLINK_THRESHOLD:
|
||||
@@ -272,12 +256,9 @@ class DriverMonitoring:
|
||||
# calibrates only when there's movement and either face detected
|
||||
if car_speed > self.settings._WHEELPOS_CALIB_MIN_SPEED and (driver_state.leftDriverData.faceProb > self.settings._FACE_THRESHOLD or
|
||||
driver_state.rightDriverData.faceProb > self.settings._FACE_THRESHOLD):
|
||||
self.wheelpos.prob_offseter.push_and_update(rhd_pred)
|
||||
|
||||
self.wheelpos.prob_calibrated = self.wheelpos.prob_offseter.filtered_stat.n > self.settings._WHEELPOS_FILTER_MIN_COUNT
|
||||
|
||||
if self.wheelpos.prob_calibrated or demo_mode:
|
||||
self.wheel_on_right = self.wheelpos.prob_offseter.filtered_stat.M > self.settings._WHEELPOS_THRESHOLD
|
||||
self.wheelpos_learner.push_and_update(rhd_pred)
|
||||
if self.wheelpos_learner.filtered_stat.n > self.settings._WHEELPOS_FILTER_MIN_COUNT or demo_mode:
|
||||
self.wheel_on_right = self.wheelpos_learner.filtered_stat.M > self.settings._WHEELPOS_THRESHOLD
|
||||
else:
|
||||
self.wheel_on_right = self.wheel_on_right_default # use default/saved if calibration is unfinished
|
||||
# make sure no switching when engaged
|
||||
|
||||
@@ -1 +1 @@
|
||||
e0ad86508edb61b3eaa1b84662c515d2c3368295
|
||||
b508f43fb0481bce0859c9b6ab4f45ee690b8dab
|
||||
@@ -206,9 +206,8 @@ class TestOnroad:
|
||||
result += "-------------- UI Draw Timing ------------------\n"
|
||||
result += "------------------------------------------------\n"
|
||||
|
||||
# other processes preempt ui while starting up
|
||||
offset = int(20 * LOG_OFFSET)
|
||||
ts = self.ts['uiDebug']['drawTimeMillis'][offset:]
|
||||
# skip first few frames -- connecting to vipc
|
||||
ts = self.ts['uiDebug']['drawTimeMillis'][15:]
|
||||
result += f"min {min(ts):.2f}ms\n"
|
||||
result += f"max {max(ts):.2f}ms\n"
|
||||
result += f"std {np.std(ts):.2f}ms\n"
|
||||
|
||||
@@ -177,7 +177,7 @@ class HomeLayout(Widget):
|
||||
|
||||
version_rect = rl.Rectangle(self.header_rect.x + self.header_rect.width - version_text_width, self.header_rect.y,
|
||||
version_text_width, self.header_rect.height)
|
||||
gui_label(version_rect, self._version_text, 48, rl.WHITE, alignment=rl.GuiTextAlignment.TEXT_ALIGN_RIGHT)
|
||||
gui_label(version_rect, self._version_text, 48, rl.WHITE, alignment=rl.GuiTextAlignment.TEXT_ALIGN_RIGHT, font_weight=FontWeight.AUDIOWIDE)
|
||||
|
||||
def _render_home_content(self):
|
||||
self._render_left_column()
|
||||
|
||||
@@ -19,9 +19,6 @@ from openpilot.system.ui.widgets.list_view import text_item, button_item, dual_b
|
||||
from openpilot.system.ui.widgets.option_dialog import MultiOptionDialog
|
||||
from openpilot.system.ui.widgets.scroller_tici import Scroller
|
||||
|
||||
if gui_app.sunnypilot_ui():
|
||||
from openpilot.system.ui.sunnypilot.widgets.list_view import button_item_sp as button_item
|
||||
|
||||
# Description constants
|
||||
DESCRIPTIONS = {
|
||||
'pair_device': tr_noop("Pair your device with comma connect (connect.comma.ai) and claim your comma prime offer."),
|
||||
|
||||
@@ -1,11 +1,19 @@
|
||||
import pyray as rl
|
||||
import time
|
||||
import threading
|
||||
|
||||
from openpilot.common.api import api_get
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.common.swaglog import cloudlog
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state
|
||||
from openpilot.system.athena.registration import UNREGISTERED_DONGLE_ID
|
||||
from openpilot.system.ui.lib.application import gui_app, FontWeight, FONT_SCALE
|
||||
from openpilot.system.ui.lib.multilang import tr, trn, tr_noop
|
||||
from openpilot.system.ui.lib.text_measure import measure_text_cached
|
||||
from openpilot.system.ui.lib.scroll_panel import GuiScrollPanel
|
||||
from openpilot.system.ui.lib.wrap_text import wrap_text
|
||||
from openpilot.selfdrive.ui.mici.layouts.settings.firehose import FirehoseLayoutBase
|
||||
from openpilot.system.ui.widgets import Widget
|
||||
from openpilot.selfdrive.ui.lib.api_helpers import get_token
|
||||
|
||||
TITLE = tr_noop("Firehose Mode")
|
||||
DESCRIPTION = tr_noop(
|
||||
@@ -24,17 +32,50 @@ INSTRUCTIONS = tr_noop(
|
||||
)
|
||||
|
||||
|
||||
class FirehoseLayout(FirehoseLayoutBase):
|
||||
class FirehoseLayout(Widget):
|
||||
PARAM_KEY = "ApiCache_FirehoseStats"
|
||||
GREEN = rl.Color(46, 204, 113, 255)
|
||||
RED = rl.Color(231, 76, 60, 255)
|
||||
GRAY = rl.Color(68, 68, 68, 255)
|
||||
LIGHT_GRAY = rl.Color(228, 228, 228, 255)
|
||||
UPDATE_INTERVAL = 30 # seconds
|
||||
|
||||
def __init__(self):
|
||||
super().__init__()
|
||||
self._scroll_panel = GuiScrollPanel()
|
||||
self.params = Params()
|
||||
self.segment_count = self._get_segment_count()
|
||||
self.scroll_panel = GuiScrollPanel()
|
||||
self._content_height = 0
|
||||
|
||||
self.running = True
|
||||
self.update_thread = threading.Thread(target=self._update_loop, daemon=True)
|
||||
self.update_thread.start()
|
||||
self.last_update_time = 0
|
||||
|
||||
def show_event(self):
|
||||
self.scroll_panel.set_offset(0)
|
||||
|
||||
def _get_segment_count(self) -> int:
|
||||
stats = self.params.get(self.PARAM_KEY)
|
||||
if not stats:
|
||||
return 0
|
||||
try:
|
||||
return int(stats.get("firehose", 0))
|
||||
except Exception:
|
||||
cloudlog.exception(f"Failed to decode firehose stats: {stats}")
|
||||
return 0
|
||||
|
||||
def __del__(self):
|
||||
self.running = False
|
||||
if self.update_thread and self.update_thread.is_alive():
|
||||
self.update_thread.join(timeout=1.0)
|
||||
|
||||
def _render(self, rect: rl.Rectangle):
|
||||
# Calculate content dimensions
|
||||
content_rect = rl.Rectangle(rect.x, rect.y, rect.width, self._content_height)
|
||||
|
||||
# Handle scrolling and render with clipping
|
||||
scroll_offset = self._scroll_panel.update(rect, content_rect)
|
||||
scroll_offset = self.scroll_panel.update(rect, content_rect)
|
||||
rl.begin_scissor_mode(int(rect.x), int(rect.y), int(rect.width), int(rect.height))
|
||||
self._content_height = self._render_content(rect, scroll_offset)
|
||||
rl.end_scissor_mode()
|
||||
@@ -66,9 +107,9 @@ class FirehoseLayout(FirehoseLayoutBase):
|
||||
y += 20 + 20
|
||||
|
||||
# Contribution count (if available)
|
||||
if self._segment_count > 0:
|
||||
if self.segment_count > 0:
|
||||
contrib_text = trn("{} segment of your driving is in the training dataset so far.",
|
||||
"{} segments of your driving is in the training dataset so far.", self._segment_count).format(self._segment_count)
|
||||
"{} segments of your driving is in the training dataset so far.", self.segment_count).format(self.segment_count)
|
||||
y = self._draw_wrapped_text(x, y, w, contrib_text, gui_app.font(FontWeight.BOLD), 52, rl.WHITE)
|
||||
y += 20 + 20
|
||||
|
||||
@@ -80,7 +121,7 @@ class FirehoseLayout(FirehoseLayoutBase):
|
||||
y = self._draw_wrapped_text(x, y, w, tr(INSTRUCTIONS), gui_app.font(FontWeight.NORMAL), 40, self.LIGHT_GRAY)
|
||||
|
||||
# bottom margin + remove effect of scroll offset
|
||||
return int(round(y - self._scroll_panel.offset + 40))
|
||||
return int(round(y - self.scroll_panel.offset + 40))
|
||||
|
||||
def _draw_wrapped_text(self, x, y, width, text, font, font_size, color):
|
||||
wrapped = wrap_text(font, text, font_size, width)
|
||||
@@ -88,3 +129,32 @@ class FirehoseLayout(FirehoseLayoutBase):
|
||||
rl.draw_text_ex(font, line, rl.Vector2(x, y), font_size, 0, color)
|
||||
y += font_size * FONT_SCALE
|
||||
return round(y)
|
||||
|
||||
def _get_status(self) -> tuple[str, rl.Color]:
|
||||
network_type = ui_state.sm["deviceState"].networkType
|
||||
network_metered = ui_state.sm["deviceState"].networkMetered
|
||||
|
||||
if not network_metered and network_type != 0: # Not metered and connected
|
||||
return tr("ACTIVE"), self.GREEN
|
||||
else:
|
||||
return tr("INACTIVE: connect to an unmetered network"), self.RED
|
||||
|
||||
def _fetch_firehose_stats(self):
|
||||
try:
|
||||
dongle_id = self.params.get("DongleId")
|
||||
if not dongle_id or dongle_id == UNREGISTERED_DONGLE_ID:
|
||||
return
|
||||
identity_token = get_token(dongle_id)
|
||||
response = api_get(f"v1/devices/{dongle_id}/firehose_stats", access_token=identity_token)
|
||||
if response.status_code == 200:
|
||||
data = response.json()
|
||||
self.segment_count = data.get("firehose", 0)
|
||||
self.params.put(self.PARAM_KEY, data)
|
||||
except Exception as e:
|
||||
cloudlog.error(f"Failed to fetch firehose stats: {e}")
|
||||
|
||||
def _update_loop(self):
|
||||
while self.running:
|
||||
if not ui_state.started:
|
||||
self._fetch_firehose_stats()
|
||||
time.sleep(self.UPDATE_INTERVAL)
|
||||
|
||||
@@ -11,19 +11,9 @@ from openpilot.system.ui.widgets.list_view import button_item, text_item, ListIt
|
||||
from openpilot.system.ui.widgets.option_dialog import MultiOptionDialog
|
||||
from openpilot.system.ui.widgets.scroller_tici import Scroller
|
||||
|
||||
if gui_app.sunnypilot_ui():
|
||||
from openpilot.system.ui.sunnypilot.widgets.list_view import button_item_sp as button_item
|
||||
|
||||
# TODO: remove this. updater fails to respond on startup if time is not correct
|
||||
UPDATED_TIMEOUT = 10 # seconds to wait for updated to respond
|
||||
|
||||
# Mapping updater internal states to translated display strings
|
||||
STATE_TO_DISPLAY_TEXT = {
|
||||
"checking...": tr("checking..."),
|
||||
"downloading...": tr("downloading..."),
|
||||
"finalizing update...": tr("finalizing update..."),
|
||||
}
|
||||
|
||||
|
||||
def time_ago(date: datetime.datetime | None) -> str:
|
||||
if not date:
|
||||
@@ -110,9 +100,7 @@ class SoftwareLayout(Widget):
|
||||
# Updater responded
|
||||
self._waiting_for_updater = False
|
||||
self._download_btn.action_item.set_enabled(False)
|
||||
# Use the mapping, with a fallback to the original state string
|
||||
display_text = STATE_TO_DISPLAY_TEXT.get(updater_state, updater_state)
|
||||
self._download_btn.action_item.set_value(display_text)
|
||||
self._download_btn.action_item.set_value(updater_state)
|
||||
else:
|
||||
if failed_count > 0:
|
||||
self._download_btn.action_item.set_value(tr("failed to check for update"))
|
||||
|
||||
@@ -67,10 +67,8 @@ class PrimeState:
|
||||
cloudlog.info(f"Prime type updated to {prime_type}")
|
||||
|
||||
def _worker_thread(self) -> None:
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state, device
|
||||
while self._running:
|
||||
if not ui_state.started and device._awake:
|
||||
self._fetch_prime_status()
|
||||
self._fetch_prime_status()
|
||||
|
||||
for _ in range(int(self.FETCH_INTERVAL / self.SLEEP_INTERVAL)):
|
||||
if not self._running:
|
||||
|
||||
@@ -3,16 +3,18 @@ import time
|
||||
from cereal import log
|
||||
import pyray as rl
|
||||
from collections.abc import Callable
|
||||
from openpilot.system.ui.widgets.label import gui_label, MiciLabel, UnifiedLabel
|
||||
from openpilot.system.ui.widgets.label import gui_label, MiciLabel
|
||||
from openpilot.system.ui.widgets import Widget
|
||||
from openpilot.system.ui.lib.application import gui_app, FontWeight, DEFAULT_TEXT_COLOR, MousePos
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state
|
||||
from openpilot.system.ui.text import wrap_text
|
||||
from openpilot.system.version import training_version, RELEASE_BRANCHES
|
||||
from openpilot.system.version import training_version
|
||||
|
||||
HEAD_BUTTON_FONT_SIZE = 40
|
||||
HOME_PADDING = 8
|
||||
|
||||
RELEASE_BRANCH = "release3"
|
||||
|
||||
NetworkType = log.DeviceState.NetworkType
|
||||
|
||||
NETWORK_TYPES = {
|
||||
@@ -113,7 +115,7 @@ class MiciHomeLayout(Widget):
|
||||
self._version_label = MiciLabel("", font_size=36, font_weight=FontWeight.ROMAN)
|
||||
self._large_version_label = MiciLabel("", font_size=64, color=rl.GRAY, font_weight=FontWeight.ROMAN)
|
||||
self._date_label = MiciLabel("", font_size=36, color=rl.GRAY, font_weight=FontWeight.ROMAN)
|
||||
self._branch_label = UnifiedLabel("", font_size=36, text_color=rl.GRAY, font_weight=FontWeight.ROMAN, scroll=True)
|
||||
self._branch_label = MiciLabel("", font_size=36, color=rl.GRAY, font_weight=FontWeight.ROMAN, elide_right=False, scroll=True)
|
||||
self._version_commit_label = MiciLabel("", font_size=36, color=rl.GRAY, font_weight=FontWeight.ROMAN)
|
||||
|
||||
def show_event(self):
|
||||
@@ -185,22 +187,27 @@ class MiciHomeLayout(Widget):
|
||||
|
||||
if self._version_text is not None:
|
||||
# release branch
|
||||
release_branch = self._version_text[1] in RELEASE_BRANCHES
|
||||
version_pos = rl.Rectangle(text_pos.x, text_pos.y + self._openpilot_label.font_size + 16, 100, 44)
|
||||
self._version_label.set_text(self._version_text[0])
|
||||
self._version_label.set_position(version_pos.x, version_pos.y)
|
||||
self._version_label.render()
|
||||
if self._version_text[0] == RELEASE_BRANCH:
|
||||
version_pos = rl.Vector2(text_pos.x, text_pos.y + self._openpilot_label.font_size + 16)
|
||||
self._large_version_label.set_text(self._version_text[0])
|
||||
self._large_version_label.set_position(version_pos.x, version_pos.y)
|
||||
self._large_version_label.render()
|
||||
|
||||
self._date_label.set_text(" " + self._version_text[3])
|
||||
self._date_label.set_position(version_pos.x + self._version_label.rect.width + 10, version_pos.y)
|
||||
self._date_label.render()
|
||||
else:
|
||||
version_pos = rl.Rectangle(text_pos.x, text_pos.y + self._openpilot_label.font_size + 16, 100, 44)
|
||||
self._version_label.set_text(self._version_text[0])
|
||||
self._version_label.set_position(version_pos.x, version_pos.y)
|
||||
self._version_label.render()
|
||||
|
||||
self._branch_label.set_max_width(gui_app.width - self._version_label.rect.width - self._date_label.rect.width - 32)
|
||||
self._branch_label.set_text(" " + ("release" if release_branch else self._version_text[1]))
|
||||
self._branch_label.set_position(version_pos.x + self._version_label.rect.width + self._date_label.rect.width + 20, version_pos.y)
|
||||
self._branch_label.render()
|
||||
self._date_label.set_text(" " + self._version_text[3])
|
||||
self._date_label.set_position(version_pos.x + self._version_label.rect.width + 10, version_pos.y)
|
||||
self._date_label.render()
|
||||
|
||||
self._branch_label.set_width(gui_app.width - self._version_label.rect.width - self._date_label.rect.width - 32)
|
||||
self._branch_label.set_text(" " + self._version_text[1])
|
||||
self._branch_label.set_position(version_pos.x + self._version_label.rect.width + self._date_label.rect.width + 20, version_pos.y)
|
||||
self._branch_label.render()
|
||||
|
||||
if not release_branch:
|
||||
# 2nd line
|
||||
self._version_commit_label.set_text(self._version_text[2])
|
||||
self._version_commit_label.set_position(version_pos.x, version_pos.y + self._date_label.font_size + 7)
|
||||
|
||||
@@ -5,7 +5,6 @@ from dataclasses import dataclass
|
||||
from enum import IntEnum
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.selfdrive.selfdrived.alertmanager import OFFROAD_ALERTS
|
||||
from openpilot.system.hardware import HARDWARE
|
||||
from openpilot.system.ui.widgets import Widget
|
||||
from openpilot.system.ui.widgets.label import UnifiedLabel
|
||||
from openpilot.system.ui.widgets.scroller import Scroller
|
||||
@@ -221,7 +220,6 @@ class MiciOffroadAlerts(Widget):
|
||||
update_alert_data = AlertData(key="UpdateAvailable", text="", severity=-1)
|
||||
self.sorted_alerts.append(update_alert_data)
|
||||
update_alert_item = AlertItem(update_alert_data)
|
||||
update_alert_item.set_click_callback(lambda: HARDWARE.reboot())
|
||||
self.alert_items.append(update_alert_item)
|
||||
self._scroller.add_widget(update_alert_item)
|
||||
|
||||
@@ -246,18 +244,18 @@ class MiciOffroadAlerts(Widget):
|
||||
|
||||
if update_alert_data:
|
||||
if update_available:
|
||||
version_string = ""
|
||||
# Default text
|
||||
update_alert_data.text = "update available. go to comma.ai/blog to read the release notes."
|
||||
|
||||
# Get new version description and parse version and date
|
||||
new_desc = self.params.get("UpdaterNewDescription") or ""
|
||||
if new_desc:
|
||||
# format: "version / branch / commit / date"
|
||||
# Parse description (format: "version / branch / commit / date")
|
||||
parts = new_desc.split(" / ")
|
||||
if len(parts) > 3:
|
||||
version, date = parts[0], parts[3]
|
||||
version_string = f"\nsunnypilot {version}, {date}\n"
|
||||
update_alert_data.text = f"update available\n sunnypilot {version}, {date}. go to comma.ai/blog to read the release notes."
|
||||
|
||||
update_alert_data.text = f"Update available {version_string}. Click to update. Read the release notes at blog.comma.ai."
|
||||
update_alert_data.visible = True
|
||||
active_count += 1
|
||||
else:
|
||||
|
||||
@@ -1,7 +1,6 @@
|
||||
from enum import IntEnum
|
||||
from collections.abc import Callable
|
||||
|
||||
import weakref
|
||||
import pyray as rl
|
||||
from openpilot.system.ui.lib.application import FontWeight, gui_app
|
||||
from openpilot.system.ui.widgets import Widget
|
||||
@@ -93,10 +92,11 @@ class TrainingGuideDMTutorial(Widget):
|
||||
super().__init__()
|
||||
self._title_header = TermsHeader("fill the circle to continue", gui_app.texture("icons_mici/setup/green_dm.png", 60, 60))
|
||||
|
||||
self._original_continue_callback = continue_callback
|
||||
|
||||
# Wrap the continue callback to restore settings
|
||||
def wrapped_continue_callback():
|
||||
device.set_offroad_brightness(None)
|
||||
device.reset_interactive_timeout()
|
||||
self._restore_settings()
|
||||
continue_callback()
|
||||
|
||||
self._dialog = DriverCameraSetupDialog(wrapped_continue_callback)
|
||||
@@ -114,6 +114,10 @@ class TrainingGuideDMTutorial(Widget):
|
||||
device.set_offroad_brightness(100)
|
||||
device.reset_interactive_timeout(300) # 5 minutes
|
||||
|
||||
def _restore_settings(self):
|
||||
device.set_offroad_brightness(None)
|
||||
device.reset_interactive_timeout()
|
||||
|
||||
def _update_state(self):
|
||||
super()._update_state()
|
||||
if device.awake:
|
||||
@@ -146,7 +150,7 @@ class TrainingGuideRecordFront(SetupTermsPage):
|
||||
super().__init__(on_continue, back_callback=on_back, back_text="no", continue_text="yes")
|
||||
self._title_header = TermsHeader("improve driver monitoring", gui_app.texture("icons_mici/setup/green_dm.png", 60, 60))
|
||||
|
||||
self._dm_label = UnifiedLabel("Do you want to upload driver camera data?", 42,
|
||||
self._dm_label = UnifiedLabel("Do you want to upload driver camera data to improve driver monitoring?", 42,
|
||||
FontWeight.ROMAN)
|
||||
|
||||
def show_event(self):
|
||||
@@ -210,17 +214,11 @@ class TrainingGuide(Widget):
|
||||
self._completed_callback = completed_callback
|
||||
self._step = 0
|
||||
|
||||
self_ref = weakref.ref(self)
|
||||
|
||||
def on_continue():
|
||||
if obj := self_ref():
|
||||
obj._advance_step()
|
||||
|
||||
self._steps = [
|
||||
TrainingGuideAttentionNotice(continue_callback=on_continue),
|
||||
TrainingGuidePreDMTutorial(continue_callback=on_continue),
|
||||
TrainingGuideDMTutorial(continue_callback=on_continue),
|
||||
TrainingGuideRecordFront(continue_callback=on_continue),
|
||||
TrainingGuideAttentionNotice(continue_callback=self._advance_step),
|
||||
TrainingGuidePreDMTutorial(continue_callback=self._advance_step),
|
||||
TrainingGuideDMTutorial(continue_callback=self._advance_step),
|
||||
TrainingGuideRecordFront(continue_callback=self._advance_step),
|
||||
]
|
||||
|
||||
def _advance_step(self):
|
||||
|
||||
@@ -39,7 +39,7 @@ class MiciFccModal(NavWidget):
|
||||
content_height += self._fcc_logo.height + 20
|
||||
|
||||
scroll_content_rect = rl.Rectangle(rect.x, rect.y, rect.width, content_height)
|
||||
scroll_offset = round(self._scroll_panel.update(rect, scroll_content_rect.height))
|
||||
scroll_offset = self._scroll_panel.update(rect, scroll_content_rect.height)
|
||||
|
||||
fcc_pos = rl.Vector2(rect.x + 20, rect.y + 20 + scroll_offset)
|
||||
|
||||
|
||||
@@ -6,13 +6,14 @@ from openpilot.common.api import api_get
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.common.swaglog import cloudlog
|
||||
from openpilot.selfdrive.ui.lib.api_helpers import get_token
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state, device
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state
|
||||
from openpilot.system.athena.registration import UNREGISTERED_DONGLE_ID
|
||||
from openpilot.system.ui.lib.application import gui_app, FontWeight, FONT_SCALE
|
||||
from openpilot.system.ui.lib.wrap_text import wrap_text
|
||||
from openpilot.system.ui.lib.scroll_panel2 import GuiScrollPanel2
|
||||
from openpilot.system.ui.lib.multilang import tr, trn, tr_noop
|
||||
from openpilot.system.ui.widgets import Widget, NavWidget
|
||||
from openpilot.system.ui.widgets import NavWidget
|
||||
|
||||
|
||||
TITLE = tr_noop("Firehose Mode")
|
||||
DESCRIPTION = tr_noop(
|
||||
@@ -33,7 +34,9 @@ FAQ_ITEMS = [
|
||||
]
|
||||
|
||||
|
||||
class FirehoseLayoutBase(Widget):
|
||||
class FirehoseLayoutMici(NavWidget):
|
||||
BACK_TOUCH_AREA_PERCENTAGE = 0.1
|
||||
|
||||
PARAM_KEY = "ApiCache_FirehoseStats"
|
||||
GREEN = rl.Color(46, 204, 113, 255)
|
||||
RED = rl.Color(231, 76, 60, 255)
|
||||
@@ -41,10 +44,12 @@ class FirehoseLayoutBase(Widget):
|
||||
LIGHT_GRAY = rl.Color(228, 228, 228, 255)
|
||||
UPDATE_INTERVAL = 30 # seconds
|
||||
|
||||
def __init__(self):
|
||||
def __init__(self, back_callback):
|
||||
super().__init__()
|
||||
self._params = Params()
|
||||
self._segment_count = self._get_segment_count()
|
||||
self.set_back_callback(back_callback)
|
||||
|
||||
self.params = Params()
|
||||
self.segment_count = self._get_segment_count()
|
||||
|
||||
self._scroll_panel = GuiScrollPanel2(horizontal=False)
|
||||
self._content_height = 0
|
||||
@@ -66,7 +71,7 @@ class FirehoseLayoutBase(Widget):
|
||||
self._scroll_panel.set_offset(0)
|
||||
|
||||
def _get_segment_count(self) -> int:
|
||||
stats = self._params.get(self.PARAM_KEY)
|
||||
stats = self.params.get(self.PARAM_KEY)
|
||||
if not stats:
|
||||
return 0
|
||||
try:
|
||||
@@ -78,7 +83,7 @@ class FirehoseLayoutBase(Widget):
|
||||
def _render(self, rect: rl.Rectangle):
|
||||
# compute total content height for scrolling
|
||||
content_height = self._measure_content_height(rect)
|
||||
scroll_offset = round(self._scroll_panel.update(rect, content_height))
|
||||
scroll_offset = self._scroll_panel.update(rect, content_height)
|
||||
|
||||
# start drawing with offset
|
||||
x = int(rect.x + 40)
|
||||
@@ -106,9 +111,9 @@ class FirehoseLayoutBase(Widget):
|
||||
y += 20
|
||||
|
||||
# Contribution count (if available)
|
||||
if self._segment_count > 0:
|
||||
if self.segment_count > 0:
|
||||
contrib_text = trn("{} segment of your driving is in the training dataset so far.",
|
||||
"{} segments of your driving is in the training dataset so far.", self._segment_count).format(self._segment_count)
|
||||
"{} segments of your driving is in the training dataset so far.", self.segment_count).format(self.segment_count)
|
||||
y = self._draw_wrapped_text(x, y, w, contrib_text, gui_app.font(FontWeight.BOLD), 42, rl.WHITE)
|
||||
y += 20
|
||||
|
||||
@@ -160,9 +165,9 @@ class FirehoseLayoutBase(Widget):
|
||||
y += int(len(status_lines) * 48 * FONT_SCALE) + 20
|
||||
|
||||
# Contribution count
|
||||
if self._segment_count > 0:
|
||||
if self.segment_count > 0:
|
||||
contrib_text = trn("{} segment of your driving is in the training dataset so far.",
|
||||
"{} segments of your driving is in the training dataset so far.", self._segment_count).format(self._segment_count)
|
||||
"{} segments of your driving is in the training dataset so far.", self.segment_count).format(self.segment_count)
|
||||
contrib_lines = wrap_text(gui_app.font(FontWeight.BOLD), contrib_text, 42, w)
|
||||
y += int(len(contrib_lines) * 42 * FONT_SCALE) + 20
|
||||
|
||||
@@ -199,28 +204,20 @@ class FirehoseLayoutBase(Widget):
|
||||
|
||||
def _fetch_firehose_stats(self):
|
||||
try:
|
||||
dongle_id = self._params.get("DongleId")
|
||||
dongle_id = self.params.get("DongleId")
|
||||
if not dongle_id or dongle_id == UNREGISTERED_DONGLE_ID:
|
||||
return
|
||||
identity_token = get_token(dongle_id)
|
||||
response = api_get(f"v1/devices/{dongle_id}/firehose_stats", access_token=identity_token)
|
||||
if response.status_code == 200:
|
||||
data = response.json()
|
||||
self._segment_count = data.get("firehose", 0)
|
||||
self._params.put(self.PARAM_KEY, data)
|
||||
self.segment_count = data.get("firehose", 0)
|
||||
self.params.put(self.PARAM_KEY, data)
|
||||
except Exception as e:
|
||||
cloudlog.error(f"Failed to fetch firehose stats: {e}")
|
||||
|
||||
def _update_loop(self):
|
||||
while self._running:
|
||||
if not ui_state.started and device._awake:
|
||||
if not ui_state.started:
|
||||
self._fetch_firehose_stats()
|
||||
time.sleep(self.UPDATE_INTERVAL)
|
||||
|
||||
|
||||
class FirehoseLayout(FirehoseLayoutBase, NavWidget):
|
||||
BACK_TOUCH_AREA_PERCENTAGE = 0.1
|
||||
|
||||
def __init__(self, back_callback):
|
||||
super().__init__()
|
||||
self.set_back_callback(back_callback)
|
||||
|
||||
+127
-16
@@ -1,20 +1,28 @@
|
||||
import math
|
||||
import numpy as np
|
||||
import pyray as rl
|
||||
from enum import IntEnum
|
||||
from collections.abc import Callable
|
||||
|
||||
from openpilot.common.swaglog import cloudlog
|
||||
from openpilot.system.ui.widgets.scroller import Scroller
|
||||
from openpilot.system.ui.widgets.label import UnifiedLabel
|
||||
from openpilot.selfdrive.ui.mici.widgets.button import BigButton, BigMultiToggle, BigToggle
|
||||
from openpilot.selfdrive.ui.mici.widgets.dialog import BigMultiOptionDialog, BigInputDialog, BigDialogOptionButton, BigConfirmationDialogV2
|
||||
from openpilot.system.ui.lib.application import gui_app, MousePos, FontWeight
|
||||
from openpilot.system.ui.widgets import Widget, NavWidget
|
||||
from openpilot.system.ui.lib.wifi_manager import WifiManager, Network, SecurityType
|
||||
from openpilot.system.ui.lib.wifi_manager import WifiManager, Network, SecurityType, MeteredType
|
||||
|
||||
|
||||
def normalize_ssid(ssid: str) -> str:
|
||||
return ssid.replace("’", "'") # for iPhone hotspots
|
||||
|
||||
|
||||
class NetworkPanelType(IntEnum):
|
||||
NONE = 0
|
||||
WIFI = 1
|
||||
|
||||
|
||||
class LoadingAnimation(Widget):
|
||||
def _render(self, _):
|
||||
cx = int(self._rect.x + 70)
|
||||
@@ -83,13 +91,11 @@ class WifiIcon(Widget):
|
||||
|
||||
class WifiItem(BigDialogOptionButton):
|
||||
LEFT_MARGIN = 20
|
||||
HEIGHT = 54
|
||||
SELECTED_HEIGHT = 74
|
||||
|
||||
def __init__(self, network: Network):
|
||||
super().__init__(network.ssid)
|
||||
|
||||
self.set_rect(rl.Rectangle(0, 0, gui_app.width, self.HEIGHT))
|
||||
self.set_rect(rl.Rectangle(0, 0, gui_app.width, 64))
|
||||
|
||||
self._selected_txt = gui_app.texture("icons_mici/settings/network/new/wifi_selected.png", 48, 96)
|
||||
|
||||
@@ -97,10 +103,6 @@ class WifiItem(BigDialogOptionButton):
|
||||
self._wifi_icon = WifiIcon()
|
||||
self._wifi_icon.set_current_network(network)
|
||||
|
||||
def set_selected(self, selected: bool):
|
||||
super().set_selected(selected)
|
||||
self._rect.height = self.SELECTED_HEIGHT if selected else self.HEIGHT
|
||||
|
||||
def set_current_network(self, network: Network):
|
||||
self._network = network
|
||||
self._wifi_icon.set_current_network(network)
|
||||
@@ -115,7 +117,7 @@ class WifiItem(BigDialogOptionButton):
|
||||
self._wifi_icon.render(rl.Rectangle(
|
||||
self._rect.x + self.LEFT_MARGIN,
|
||||
self._rect.y,
|
||||
self.SELECTED_HEIGHT,
|
||||
self._rect.height,
|
||||
self._rect.height
|
||||
))
|
||||
|
||||
@@ -124,7 +126,7 @@ class WifiItem(BigDialogOptionButton):
|
||||
self._label.set_color(rl.Color(255, 255, 255, int(255 * 0.9)))
|
||||
self._label.set_font_weight(FontWeight.DISPLAY)
|
||||
else:
|
||||
self._label.set_font_size(54)
|
||||
self._label.set_font_size(70)
|
||||
self._label.set_color(rl.Color(255, 255, 255, int(255 * 0.58)))
|
||||
self._label.set_font_weight(FontWeight.DISPLAY_REGULAR)
|
||||
|
||||
@@ -213,7 +215,7 @@ class NetworkInfoPage(NavWidget):
|
||||
self._connect_btn.set_click_callback(lambda: connect_callback(self._network.ssid) if self._network is not None else None)
|
||||
|
||||
self._title = UnifiedLabel("", 64, FontWeight.DISPLAY, rl.Color(255, 255, 255, int(255 * 0.9)),
|
||||
alignment_vertical=rl.GuiTextAlignmentVertical.TEXT_ALIGN_MIDDLE, scroll=True)
|
||||
alignment_vertical=rl.GuiTextAlignmentVertical.TEXT_ALIGN_MIDDLE)
|
||||
self._subtitle = UnifiedLabel("", 36, FontWeight.ROMAN, rl.Color(255, 255, 255, int(255 * 0.9 * 0.65)),
|
||||
alignment_vertical=rl.GuiTextAlignmentVertical.TEXT_ALIGN_MIDDLE)
|
||||
|
||||
@@ -223,10 +225,6 @@ class NetworkInfoPage(NavWidget):
|
||||
self._network: Network | None = None
|
||||
self._connecting: Callable[[], str | None] | None = None
|
||||
|
||||
def show_event(self):
|
||||
super().show_event()
|
||||
self._title.reset_scroll()
|
||||
|
||||
def update_networks(self, networks: dict[str, Network]):
|
||||
# update current network from latest scan results
|
||||
for ssid, network in networks.items():
|
||||
@@ -394,7 +392,7 @@ class WifiUIMici(BigMultiOptionDialog):
|
||||
self._network_info_page.set_current_network(_network)
|
||||
self._should_open_network_info_page = True
|
||||
|
||||
network_button.set_click_callback(lambda _net=network, _button=network_button: _button._selected and show_network_info_page(_net))
|
||||
network_button.set_click_callback(lambda _net=network,_button=network_button: _button._selected and show_network_info_page(_net))
|
||||
|
||||
self.add_button(network_button)
|
||||
|
||||
@@ -445,3 +443,116 @@ class WifiUIMici(BigMultiOptionDialog):
|
||||
|
||||
if not self._networks:
|
||||
self._loading_animation.render(self._rect)
|
||||
|
||||
|
||||
class NetworkLayoutMici(NavWidget):
|
||||
def __init__(self, back_callback: Callable):
|
||||
super().__init__()
|
||||
|
||||
self._current_panel = NetworkPanelType.WIFI
|
||||
self.set_back_enabled(lambda: self._current_panel == NetworkPanelType.NONE)
|
||||
|
||||
self._wifi_manager = WifiManager()
|
||||
self._wifi_manager.set_active(False)
|
||||
self._wifi_ui = WifiUIMici(self._wifi_manager, back_callback=lambda: self._switch_to_panel(NetworkPanelType.NONE))
|
||||
|
||||
self._wifi_manager.add_callbacks(
|
||||
networks_updated=self._on_network_updated,
|
||||
)
|
||||
|
||||
_tethering_icon = "icons_mici/settings/network/tethering.png"
|
||||
|
||||
# ******** Tethering ********
|
||||
def tethering_toggle_callback(checked: bool):
|
||||
self._tethering_toggle_btn.set_enabled(False)
|
||||
self._network_metered_btn.set_enabled(False)
|
||||
self._wifi_manager.set_tethering_active(checked)
|
||||
|
||||
self._tethering_toggle_btn = BigToggle("enable tethering", "", toggle_callback=tethering_toggle_callback)
|
||||
|
||||
def tethering_password_callback(password: str):
|
||||
if password:
|
||||
self._wifi_manager.set_tethering_password(password)
|
||||
|
||||
def tethering_password_clicked():
|
||||
tethering_password = self._wifi_manager.tethering_password
|
||||
dlg = BigInputDialog("enter password...", tethering_password, minimum_length=8,
|
||||
confirm_callback=tethering_password_callback)
|
||||
gui_app.set_modal_overlay(dlg)
|
||||
|
||||
txt_tethering = gui_app.texture(_tethering_icon, 64, 53)
|
||||
self._tethering_password_btn = BigButton("tethering password", "", txt_tethering)
|
||||
self._tethering_password_btn.set_click_callback(tethering_password_clicked)
|
||||
|
||||
# ******** IP Address ********
|
||||
self._ip_address_btn = BigButton("IP Address", "Not connected")
|
||||
|
||||
# ******** Network Metered ********
|
||||
def network_metered_callback(value: str):
|
||||
self._network_metered_btn.set_enabled(False)
|
||||
metered = {
|
||||
'default': MeteredType.UNKNOWN,
|
||||
'metered': MeteredType.YES,
|
||||
'unmetered': MeteredType.NO
|
||||
}.get(value, MeteredType.UNKNOWN)
|
||||
self._wifi_manager.set_current_network_metered(metered)
|
||||
|
||||
# TODO: signal for current network metered type when changing networks, this is wrong until you press it once
|
||||
# TODO: disable when not connected
|
||||
self._network_metered_btn = BigMultiToggle("network usage", ["default", "metered", "unmetered"], select_callback=network_metered_callback)
|
||||
self._network_metered_btn.set_enabled(False)
|
||||
|
||||
wifi_button = BigButton("wi-fi")
|
||||
wifi_button.set_click_callback(lambda: self._switch_to_panel(NetworkPanelType.WIFI))
|
||||
|
||||
# Main scroller ----------------------------------
|
||||
self._scroller = Scroller([
|
||||
wifi_button,
|
||||
self._network_metered_btn,
|
||||
self._tethering_toggle_btn,
|
||||
self._tethering_password_btn,
|
||||
self._ip_address_btn,
|
||||
], snap_items=False)
|
||||
|
||||
# Set up back navigation
|
||||
self.set_back_callback(back_callback)
|
||||
|
||||
def show_event(self):
|
||||
super().show_event()
|
||||
self._current_panel = NetworkPanelType.NONE
|
||||
self._wifi_ui.show_event()
|
||||
self._scroller.show_event()
|
||||
|
||||
def hide_event(self):
|
||||
super().hide_event()
|
||||
self._wifi_ui.hide_event()
|
||||
|
||||
def _on_network_updated(self, networks: list[Network]):
|
||||
# Update tethering state
|
||||
tethering_active = self._wifi_manager.is_tethering_active()
|
||||
# TODO: use real signals (like activated/settings changed, etc.) to speed up re-enabling buttons
|
||||
self._tethering_toggle_btn.set_enabled(True)
|
||||
self._network_metered_btn.set_enabled(lambda: not tethering_active and bool(self._wifi_manager.ipv4_address))
|
||||
self._tethering_toggle_btn.set_checked(tethering_active)
|
||||
|
||||
# Update IP address
|
||||
self._ip_address_btn.set_value(self._wifi_manager.ipv4_address or "Not connected")
|
||||
|
||||
# Update network metered
|
||||
self._network_metered_btn.set_value(
|
||||
{
|
||||
MeteredType.UNKNOWN: 'default',
|
||||
MeteredType.YES: 'metered',
|
||||
MeteredType.NO: 'unmetered'
|
||||
}.get(self._wifi_manager.current_network_metered, 'default'))
|
||||
|
||||
def _switch_to_panel(self, panel_type: NetworkPanelType):
|
||||
self._current_panel = panel_type
|
||||
|
||||
def _render(self, rect: rl.Rectangle):
|
||||
self._wifi_manager.process_callbacks()
|
||||
|
||||
if self._current_panel == NetworkPanelType.WIFI:
|
||||
self._wifi_ui.render(rect)
|
||||
else:
|
||||
self._scroller.render(rect)
|
||||
@@ -1,182 +0,0 @@
|
||||
import pyray as rl
|
||||
from enum import IntEnum
|
||||
from collections.abc import Callable
|
||||
|
||||
from openpilot.system.ui.widgets.scroller import Scroller
|
||||
from openpilot.selfdrive.ui.mici.layouts.settings.network.wifi_ui import WifiUIMici
|
||||
from openpilot.selfdrive.ui.mici.widgets.button import BigButton, BigMultiToggle, BigToggle, BigParamControl
|
||||
from openpilot.selfdrive.ui.mici.widgets.dialog import BigInputDialog
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state
|
||||
from openpilot.selfdrive.ui.lib.prime_state import PrimeType
|
||||
from openpilot.system.ui.lib.application import gui_app
|
||||
from openpilot.system.ui.widgets import NavWidget
|
||||
from openpilot.system.ui.lib.wifi_manager import WifiManager, Network, MeteredType
|
||||
|
||||
|
||||
class NetworkPanelType(IntEnum):
|
||||
NONE = 0
|
||||
WIFI = 1
|
||||
|
||||
|
||||
class NetworkLayoutMici(NavWidget):
|
||||
def __init__(self, back_callback: Callable):
|
||||
super().__init__()
|
||||
|
||||
self._current_panel = NetworkPanelType.WIFI
|
||||
self.set_back_enabled(lambda: self._current_panel == NetworkPanelType.NONE)
|
||||
|
||||
self._wifi_manager = WifiManager()
|
||||
self._wifi_manager.set_active(False)
|
||||
self._wifi_ui = WifiUIMici(self._wifi_manager, back_callback=lambda: self._switch_to_panel(NetworkPanelType.NONE))
|
||||
|
||||
self._wifi_manager.add_callbacks(
|
||||
networks_updated=self._on_network_updated,
|
||||
)
|
||||
|
||||
_tethering_icon = "icons_mici/settings/network/tethering.png"
|
||||
|
||||
# ******** Tethering ********
|
||||
def tethering_toggle_callback(checked: bool):
|
||||
self._tethering_toggle_btn.set_enabled(False)
|
||||
self._network_metered_btn.set_enabled(False)
|
||||
self._wifi_manager.set_tethering_active(checked)
|
||||
|
||||
self._tethering_toggle_btn = BigToggle("enable tethering", "", toggle_callback=tethering_toggle_callback)
|
||||
|
||||
def tethering_password_callback(password: str):
|
||||
if password:
|
||||
self._wifi_manager.set_tethering_password(password)
|
||||
|
||||
def tethering_password_clicked():
|
||||
tethering_password = self._wifi_manager.tethering_password
|
||||
dlg = BigInputDialog("enter password...", tethering_password, minimum_length=8,
|
||||
confirm_callback=tethering_password_callback)
|
||||
gui_app.set_modal_overlay(dlg)
|
||||
|
||||
txt_tethering = gui_app.texture(_tethering_icon, 64, 53)
|
||||
self._tethering_password_btn = BigButton("tethering password", "", txt_tethering)
|
||||
self._tethering_password_btn.set_click_callback(tethering_password_clicked)
|
||||
|
||||
# ******** IP Address ********
|
||||
self._ip_address_btn = BigButton("IP Address", "Not connected")
|
||||
|
||||
# ******** Network Metered ********
|
||||
def network_metered_callback(value: str):
|
||||
self._network_metered_btn.set_enabled(False)
|
||||
metered = {
|
||||
'default': MeteredType.UNKNOWN,
|
||||
'metered': MeteredType.YES,
|
||||
'unmetered': MeteredType.NO
|
||||
}.get(value, MeteredType.UNKNOWN)
|
||||
self._wifi_manager.set_current_network_metered(metered)
|
||||
|
||||
# TODO: signal for current network metered type when changing networks, this is wrong until you press it once
|
||||
# TODO: disable when not connected
|
||||
self._network_metered_btn = BigMultiToggle("network usage", ["default", "metered", "unmetered"], select_callback=network_metered_callback)
|
||||
self._network_metered_btn.set_enabled(False)
|
||||
|
||||
wifi_button = BigButton("wi-fi")
|
||||
wifi_button.set_click_callback(lambda: self._switch_to_panel(NetworkPanelType.WIFI))
|
||||
|
||||
# ******** Advanced settings ********
|
||||
# ******** Roaming toggle ********
|
||||
self._roaming_btn = BigParamControl("enable roaming", "GsmRoaming", toggle_callback=self._toggle_roaming)
|
||||
|
||||
# ******** APN settings ********
|
||||
self._apn_btn = BigButton("apn settings", "edit")
|
||||
self._apn_btn.set_click_callback(self._edit_apn)
|
||||
|
||||
# ******** Cellular metered toggle ********
|
||||
self._cellular_metered_btn = BigParamControl("cellular metered", "GsmMetered", toggle_callback=self._toggle_cellular_metered)
|
||||
|
||||
# Main scroller ----------------------------------
|
||||
self._scroller = Scroller([
|
||||
wifi_button,
|
||||
self._network_metered_btn,
|
||||
self._tethering_toggle_btn,
|
||||
self._tethering_password_btn,
|
||||
# /* Advanced settings
|
||||
self._roaming_btn,
|
||||
self._apn_btn,
|
||||
self._cellular_metered_btn,
|
||||
# */
|
||||
self._ip_address_btn,
|
||||
], snap_items=False)
|
||||
|
||||
# Set initial config
|
||||
roaming_enabled = ui_state.params.get_bool("GsmRoaming")
|
||||
metered = ui_state.params.get_bool("GsmMetered")
|
||||
self._wifi_manager.update_gsm_settings(roaming_enabled, ui_state.params.get("GsmApn") or "", metered)
|
||||
|
||||
# Set up back navigation
|
||||
self.set_back_callback(back_callback)
|
||||
|
||||
def _update_state(self):
|
||||
super()._update_state()
|
||||
|
||||
# If not using prime SIM, show GSM settings and enable IPv4 forwarding
|
||||
show_cell_settings = ui_state.prime_state.get_type() in (PrimeType.NONE, PrimeType.LITE)
|
||||
self._wifi_manager.set_ipv4_forward(show_cell_settings)
|
||||
self._roaming_btn.set_visible(show_cell_settings)
|
||||
self._apn_btn.set_visible(show_cell_settings)
|
||||
self._cellular_metered_btn.set_visible(show_cell_settings)
|
||||
|
||||
def show_event(self):
|
||||
super().show_event()
|
||||
self._current_panel = NetworkPanelType.NONE
|
||||
self._wifi_ui.show_event()
|
||||
self._scroller.show_event()
|
||||
|
||||
def hide_event(self):
|
||||
super().hide_event()
|
||||
self._wifi_ui.hide_event()
|
||||
|
||||
def _toggle_roaming(self, checked: bool):
|
||||
self._wifi_manager.update_gsm_settings(checked, ui_state.params.get("GsmApn") or "", ui_state.params.get_bool("GsmMetered"))
|
||||
|
||||
def _edit_apn(self):
|
||||
def update_apn(apn: str):
|
||||
apn = apn.strip()
|
||||
if apn == "":
|
||||
ui_state.params.remove("GsmApn")
|
||||
else:
|
||||
ui_state.params.put("GsmApn", apn)
|
||||
|
||||
self._wifi_manager.update_gsm_settings(ui_state.params.get_bool("GsmRoaming"), apn, ui_state.params.get_bool("GsmMetered"))
|
||||
|
||||
current_apn = ui_state.params.get("GsmApn") or ""
|
||||
dlg = BigInputDialog("enter APN", current_apn, minimum_length=0, confirm_callback=update_apn)
|
||||
gui_app.set_modal_overlay(dlg)
|
||||
|
||||
def _toggle_cellular_metered(self, checked: bool):
|
||||
self._wifi_manager.update_gsm_settings(ui_state.params.get_bool("GsmRoaming"), ui_state.params.get("GsmApn") or "", checked)
|
||||
|
||||
def _on_network_updated(self, networks: list[Network]):
|
||||
# Update tethering state
|
||||
tethering_active = self._wifi_manager.is_tethering_active()
|
||||
# TODO: use real signals (like activated/settings changed, etc.) to speed up re-enabling buttons
|
||||
self._tethering_toggle_btn.set_enabled(True)
|
||||
self._network_metered_btn.set_enabled(lambda: not tethering_active and bool(self._wifi_manager.ipv4_address))
|
||||
self._tethering_toggle_btn.set_checked(tethering_active)
|
||||
|
||||
# Update IP address
|
||||
self._ip_address_btn.set_value(self._wifi_manager.ipv4_address or "Not connected")
|
||||
|
||||
# Update network metered
|
||||
self._network_metered_btn.set_value(
|
||||
{
|
||||
MeteredType.UNKNOWN: 'default',
|
||||
MeteredType.YES: 'metered',
|
||||
MeteredType.NO: 'unmetered'
|
||||
}.get(self._wifi_manager.current_network_metered, 'default'))
|
||||
|
||||
def _switch_to_panel(self, panel_type: NetworkPanelType):
|
||||
self._current_panel = panel_type
|
||||
|
||||
def _render(self, rect: rl.Rectangle):
|
||||
self._wifi_manager.process_callbacks()
|
||||
|
||||
if self._current_panel == NetworkPanelType.WIFI:
|
||||
self._wifi_ui.render(rect)
|
||||
else:
|
||||
self._scroller.render(rect)
|
||||
@@ -10,7 +10,7 @@ from openpilot.selfdrive.ui.mici.layouts.settings.toggles import TogglesLayoutMi
|
||||
from openpilot.selfdrive.ui.mici.layouts.settings.network import NetworkLayoutMici
|
||||
from openpilot.selfdrive.ui.mici.layouts.settings.device import DeviceLayoutMici, PairBigButton
|
||||
from openpilot.selfdrive.ui.mici.layouts.settings.developer import DeveloperLayoutMici
|
||||
from openpilot.selfdrive.ui.mici.layouts.settings.firehose import FirehoseLayout
|
||||
from openpilot.selfdrive.ui.mici.layouts.settings.firehose import FirehoseLayoutMici
|
||||
from openpilot.system.ui.lib.application import gui_app, FontWeight
|
||||
from openpilot.system.ui.widgets import Widget, NavWidget
|
||||
|
||||
@@ -67,7 +67,7 @@ class SettingsLayout(NavWidget):
|
||||
PanelType.NETWORK: PanelInfo("Network", NetworkLayoutMici(back_callback=lambda: self._set_current_panel(None))),
|
||||
PanelType.DEVICE: PanelInfo("Device", DeviceLayoutMici(back_callback=lambda: self._set_current_panel(None))),
|
||||
PanelType.DEVELOPER: PanelInfo("Developer", DeveloperLayoutMici(back_callback=lambda: self._set_current_panel(None))),
|
||||
PanelType.FIREHOSE: PanelInfo("Firehose", FirehoseLayout(back_callback=lambda: self._set_current_panel(None))),
|
||||
PanelType.FIREHOSE: PanelInfo("Firehose", FirehoseLayoutMici(back_callback=lambda: self._set_current_panel(None))),
|
||||
}
|
||||
|
||||
self._font_medium = gui_app.font(FontWeight.MEDIUM)
|
||||
|
||||
@@ -89,6 +89,10 @@ ALERT_CRITICAL_REBOOT = Alert(
|
||||
class AlertRenderer(Widget):
|
||||
def __init__(self):
|
||||
super().__init__()
|
||||
self.font_regular: rl.Font = gui_app.font(FontWeight.MEDIUM)
|
||||
self.font_roman: rl.Font = gui_app.font(FontWeight.ROMAN)
|
||||
self.font_bold: rl.Font = gui_app.font(FontWeight.BOLD)
|
||||
self.font_display: rl.Font = gui_app.font(FontWeight.DISPLAY)
|
||||
|
||||
self._alert_text1_label = UnifiedLabel(text="", font_size=ALERT_FONT_BIG, font_weight=FontWeight.DISPLAY, line_height=0.86,
|
||||
letter_spacing=-0.02)
|
||||
@@ -200,11 +204,11 @@ class AlertRenderer(Widget):
|
||||
text_x = self._rect.x + ALERT_MARGIN
|
||||
text_width = self._rect.width - ALERT_MARGIN
|
||||
if icon_side == 'left':
|
||||
text_x = self._rect.x + self._txt_turn_signal_right.width
|
||||
text_width = self._rect.width - ALERT_MARGIN - self._txt_turn_signal_right.width
|
||||
text_x = self._rect.x + self._txt_turn_signal_right.width + 20 * 2
|
||||
text_width = self._rect.width - ALERT_MARGIN - self._txt_turn_signal_right.width - 20 * 2
|
||||
elif icon_side == 'right':
|
||||
text_x = self._rect.x + ALERT_MARGIN
|
||||
text_width = self._rect.width - ALERT_MARGIN - self._txt_turn_signal_right.width
|
||||
text_width = self._rect.width - ALERT_MARGIN - self._txt_turn_signal_right.width - 20 * 2
|
||||
|
||||
text_rect = rl.Rectangle(
|
||||
text_x,
|
||||
|
||||
@@ -1,7 +1,6 @@
|
||||
import time
|
||||
import numpy as np
|
||||
import pyray as rl
|
||||
from cereal import messaging, car, log
|
||||
from cereal import car, log
|
||||
from msgq.visionipc import VisionStreamType
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state, UIStatus
|
||||
from openpilot.selfdrive.ui.mici.onroad import SIDE_PANEL_WIDTH
|
||||
@@ -161,9 +160,6 @@ class AugmentedRoadView(CameraView):
|
||||
|
||||
self._fade_texture = gui_app.texture("icons_mici/onroad/onroad_fade.png")
|
||||
|
||||
# debug
|
||||
self._pm = messaging.PubMaster(['uiDebug'])
|
||||
|
||||
def is_swiping_left(self) -> bool:
|
||||
"""Check if currently swiping left (for scroller to disable)."""
|
||||
return self._bookmark_icon.is_swiping_left()
|
||||
@@ -183,7 +179,6 @@ class AugmentedRoadView(CameraView):
|
||||
super()._handle_mouse_release(mouse_pos)
|
||||
|
||||
def _render(self, _):
|
||||
start_draw = time.monotonic()
|
||||
self._switch_stream_if_needed(ui_state.sm)
|
||||
|
||||
# Update calibration before rendering
|
||||
@@ -249,11 +244,6 @@ class AugmentedRoadView(CameraView):
|
||||
rl.draw_rectangle(int(self.rect.x), int(self.rect.y), int(self.rect.width), int(self.rect.height), rl.Color(0, 0, 0, 175))
|
||||
self._offroad_label.render(self._content_rect)
|
||||
|
||||
# publish uiDebug
|
||||
msg = messaging.new_message('uiDebug')
|
||||
msg.uiDebug.drawTimeMillis = (time.monotonic() - start_draw) * 1000
|
||||
self._pm.send('uiDebug', msg)
|
||||
|
||||
def _switch_stream_if_needed(self, sm):
|
||||
if sm['selfdriveState'].experimentalMode and WIDE_CAM in self.available_streams:
|
||||
v_ego = sm['carState'].vEgo
|
||||
|
||||
@@ -107,6 +107,7 @@ else:
|
||||
class CameraView(Widget):
|
||||
def __init__(self, name: str, stream_type: VisionStreamType):
|
||||
super().__init__()
|
||||
# TODO: implement a receiver and connect thread
|
||||
self._name = name
|
||||
# Primary stream
|
||||
self.client = VisionIpcClient(name, stream_type, conflate=True)
|
||||
@@ -196,10 +197,7 @@ class CameraView(Widget):
|
||||
# Clean up shader
|
||||
if self.shader and self.shader.id:
|
||||
rl.unload_shader(self.shader)
|
||||
self.shader.id = 0
|
||||
|
||||
self.frame = None
|
||||
self.available_streams.clear()
|
||||
self.client = None
|
||||
|
||||
def __del__(self):
|
||||
@@ -236,9 +234,6 @@ class CameraView(Widget):
|
||||
if buffer:
|
||||
self._texture_needs_update = True
|
||||
self.frame = buffer
|
||||
elif not self.client.is_connected():
|
||||
# ensure we clear the displayed frame when the connection is lost
|
||||
self.frame = None
|
||||
|
||||
if not self.frame:
|
||||
self._draw_placeholder(rect)
|
||||
|
||||
@@ -15,27 +15,20 @@ EventName = log.OnroadEvent.EventName
|
||||
EVENT_TO_INT = EventName.schema.enumerants
|
||||
|
||||
|
||||
class DriverCameraView(CameraView):
|
||||
def _calc_frame_matrix(self, rect: rl.Rectangle):
|
||||
base = super()._calc_frame_matrix(rect)
|
||||
driver_view_ratio = 1.5
|
||||
base[0, 0] *= driver_view_ratio
|
||||
base[1, 1] *= driver_view_ratio
|
||||
return base
|
||||
|
||||
|
||||
class DriverCameraDialog(NavWidget):
|
||||
def __init__(self, no_escape=False):
|
||||
super().__init__()
|
||||
self._camera_view = DriverCameraView("camerad", VisionStreamType.VISION_STREAM_DRIVER)
|
||||
self._camera_view = CameraView("camerad", VisionStreamType.VISION_STREAM_DRIVER)
|
||||
self._original_calc_frame_matrix = self._camera_view._calc_frame_matrix
|
||||
self._camera_view._calc_frame_matrix = self._calc_driver_frame_matrix
|
||||
self.driver_state_renderer = DriverStateRenderer(lines=True)
|
||||
self.driver_state_renderer.set_rect(rl.Rectangle(0, 0, 200, 200))
|
||||
self.driver_state_renderer.load_icons()
|
||||
self._pm: messaging.PubMaster | None = None
|
||||
self._pm = messaging.PubMaster(['selfdriveState'])
|
||||
if not no_escape:
|
||||
# TODO: this can grow unbounded, should be given some thought
|
||||
device.add_interactive_timeout_callback(lambda: gui_app.set_modal_overlay(None))
|
||||
self.set_back_callback(lambda: gui_app.set_modal_overlay(None))
|
||||
device.add_interactive_timeout_callback(self.stop_dmonitoringmodeld)
|
||||
self.set_back_callback(self._dismiss)
|
||||
self.set_back_enabled(not no_escape)
|
||||
|
||||
# Load eye icons
|
||||
@@ -47,24 +40,26 @@ class DriverCameraDialog(NavWidget):
|
||||
|
||||
self._load_eye_textures()
|
||||
|
||||
def stop_dmonitoringmodeld(self):
|
||||
ui_state.params.put_bool("IsDriverViewEnabled", False)
|
||||
gui_app.set_modal_overlay(None)
|
||||
|
||||
def show_event(self):
|
||||
super().show_event()
|
||||
ui_state.params.put_bool("IsDriverViewEnabled", True)
|
||||
self._publish_alert_sound(None)
|
||||
device.reset_interactive_timeout(300)
|
||||
ui_state.params.remove("DriverTooDistracted")
|
||||
self._pm = messaging.PubMaster(['selfdriveState'])
|
||||
|
||||
def hide_event(self):
|
||||
super().hide_event()
|
||||
ui_state.params.put_bool("IsDriverViewEnabled", False)
|
||||
device.reset_interactive_timeout()
|
||||
|
||||
def _handle_mouse_release(self, _):
|
||||
ui_state.params.remove("DriverTooDistracted")
|
||||
|
||||
def __del__(self):
|
||||
self.close()
|
||||
def _dismiss(self):
|
||||
self.stop_dmonitoringmodeld()
|
||||
|
||||
def close(self):
|
||||
if self._camera_view:
|
||||
@@ -108,9 +103,6 @@ class DriverCameraDialog(NavWidget):
|
||||
|
||||
def _publish_alert_sound(self, dm_state):
|
||||
"""Publish selfdriveState with only alertSound field set"""
|
||||
if self._pm is None:
|
||||
return
|
||||
|
||||
msg = messaging.new_message('selfdriveState')
|
||||
if dm_state is not None and len(dm_state.events):
|
||||
event_name = EVENT_TO_INT[dm_state.events[0].name]
|
||||
@@ -229,6 +221,13 @@ class DriverCameraDialog(NavWidget):
|
||||
glasses_prob = driver_data.sunglassesProb
|
||||
rl.draw_texture_v(self._glasses_texture, glasses_pos, rl.Color(70, 80, 161, int(255 * glasses_prob)))
|
||||
|
||||
def _calc_driver_frame_matrix(self, rect: rl.Rectangle):
|
||||
base = self._original_calc_frame_matrix(rect)
|
||||
driver_view_ratio = 1.5
|
||||
base[0, 0] *= driver_view_ratio
|
||||
base[1, 1] *= driver_view_ratio
|
||||
return base
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
gui_app.init_window("Driver Camera View (mici)")
|
||||
|
||||
@@ -3,7 +3,6 @@ from collections.abc import Callable
|
||||
import numpy as np
|
||||
import math
|
||||
from cereal import log
|
||||
from openpilot.system.hardware import PC
|
||||
from openpilot.common.filter_simple import FirstOrderFilter
|
||||
from openpilot.system.ui.lib.application import gui_app
|
||||
from openpilot.system.ui.widgets import Widget
|
||||
@@ -218,10 +217,7 @@ class DriverStateRenderer(Widget):
|
||||
rotation = math.degrees(math.atan2(pitch, yaw))
|
||||
angle_diff = rotation - self._rotation_filter.x
|
||||
angle_diff = ((angle_diff + 180) % 360) - 180
|
||||
if PC and self._confirm_mode:
|
||||
self._rotation_filter.x += 2
|
||||
else:
|
||||
self._rotation_filter.update(self._rotation_filter.x + angle_diff)
|
||||
self._rotation_filter.update(self._rotation_filter.x + angle_diff)
|
||||
|
||||
if not self.should_draw:
|
||||
self._fade_filter.update(0.0)
|
||||
|
||||
@@ -30,8 +30,20 @@ class FontSizes:
|
||||
|
||||
@dataclass(frozen=True)
|
||||
class Colors:
|
||||
WHITE = rl.WHITE
|
||||
WHITE_TRANSLUCENT = rl.Color(255, 255, 255, 200)
|
||||
white: rl.Color = rl.WHITE
|
||||
disengaged: rl.Color = rl.Color(145, 155, 149, 255)
|
||||
override: rl.Color = rl.Color(145, 155, 149, 255) # Added
|
||||
engaged: rl.Color = rl.Color(128, 216, 166, 255)
|
||||
disengaged_bg: rl.Color = rl.Color(0, 0, 0, 153)
|
||||
override_bg: rl.Color = rl.Color(145, 155, 149, 204)
|
||||
engaged_bg: rl.Color = rl.Color(128, 216, 166, 204)
|
||||
grey: rl.Color = rl.Color(166, 166, 166, 255)
|
||||
dark_grey: rl.Color = rl.Color(114, 114, 114, 255)
|
||||
black_translucent: rl.Color = rl.Color(0, 0, 0, 166)
|
||||
white_translucent: rl.Color = rl.Color(255, 255, 255, 200)
|
||||
border_translucent: rl.Color = rl.Color(255, 255, 255, 75)
|
||||
header_gradient_start: rl.Color = rl.Color(0, 0, 0, 114)
|
||||
header_gradient_end: rl.Color = rl.BLANK
|
||||
|
||||
|
||||
FONT_SIZES = FontSizes()
|
||||
@@ -224,18 +236,16 @@ class HudRenderer(Widget):
|
||||
|
||||
def _draw_set_speed(self, rect: rl.Rectangle) -> None:
|
||||
"""Draw the MAX speed indicator box."""
|
||||
alpha = self._set_speed_alpha_filter.update(0 < rl.get_time() - self._set_speed_changed_time < SET_SPEED_PERSISTENCE and
|
||||
self._can_draw_top_icons and self._engaged)
|
||||
if alpha < 1e-2:
|
||||
return
|
||||
|
||||
x = rect.x
|
||||
y = rect.y
|
||||
|
||||
alpha = self._set_speed_alpha_filter.update(0 < rl.get_time() - self._set_speed_changed_time < SET_SPEED_PERSISTENCE and
|
||||
self._can_draw_top_icons and self._engaged)
|
||||
|
||||
# draw drop shadow
|
||||
circle_radius = 162 // 2
|
||||
rl.draw_circle_gradient(int(x + circle_radius), int(y + circle_radius), circle_radius,
|
||||
rl.Color(0, 0, 0, int(255 / 2 * alpha)), rl.BLANK)
|
||||
rl.Color(0, 0, 0, int(255 / 2 * alpha)), rl.Color(0, 0, 0, 0))
|
||||
|
||||
set_speed_color = rl.Color(255, 255, 255, int(255 * 0.9 * alpha))
|
||||
max_color = rl.Color(255, 255, 255, int(255 * 0.9 * alpha))
|
||||
@@ -269,9 +279,9 @@ class HudRenderer(Widget):
|
||||
speed_text = str(round(self.speed))
|
||||
speed_text_size = measure_text_cached(self._font_bold, speed_text, FONT_SIZES.current_speed)
|
||||
speed_pos = rl.Vector2(rect.x + rect.width / 2 - speed_text_size.x / 2, 180 - speed_text_size.y / 2)
|
||||
rl.draw_text_ex(self._font_bold, speed_text, speed_pos, FONT_SIZES.current_speed, 0, COLORS.WHITE)
|
||||
rl.draw_text_ex(self._font_bold, speed_text, speed_pos, FONT_SIZES.current_speed, 0, COLORS.white)
|
||||
|
||||
unit_text = tr("km/h") if ui_state.is_metric else tr("mph")
|
||||
unit_text_size = measure_text_cached(self._font_medium, unit_text, FONT_SIZES.speed_unit)
|
||||
unit_pos = rl.Vector2(rect.x + rect.width / 2 - unit_text_size.x / 2, 290 - unit_text_size.y / 2)
|
||||
rl.draw_text_ex(self._font_medium, unit_text, unit_pos, FONT_SIZES.speed_unit, 0, COLORS.WHITE_TRANSLUCENT)
|
||||
rl.draw_text_ex(self._font_medium, unit_text, unit_pos, FONT_SIZES.speed_unit, 0, COLORS.white_translucent)
|
||||
|
||||
@@ -130,9 +130,6 @@ def arc_bar_pts(cx: float, cy: float,
|
||||
|
||||
pts = np.vstack((outer, cap_end, inner, cap_start, outer[:1])).astype(np.float32)
|
||||
|
||||
# Rotate to start from middle of cap for proper triangulation
|
||||
pts = np.roll(pts, cap_segs, axis=0)
|
||||
|
||||
if DEBUG:
|
||||
n = len(pts)
|
||||
idx = int(time.monotonic() * 12) % max(1, n) # speed: 12 pts/sec
|
||||
|
||||
@@ -282,8 +282,7 @@ class BigDialogOptionButton(Widget):
|
||||
self._selected = False
|
||||
|
||||
self._label = UnifiedLabel(option, font_size=70, text_color=rl.Color(255, 255, 255, int(255 * 0.58)),
|
||||
font_weight=FontWeight.DISPLAY_REGULAR, alignment_vertical=rl.GuiTextAlignmentVertical.TEXT_ALIGN_MIDDLE,
|
||||
scroll=True)
|
||||
font_weight=FontWeight.DISPLAY_REGULAR, alignment_vertical=rl.GuiTextAlignmentVertical.TEXT_ALIGN_TOP)
|
||||
|
||||
def set_selected(self, selected: bool):
|
||||
self._selected = selected
|
||||
|
||||
@@ -68,6 +68,7 @@ else:
|
||||
class CameraView(Widget):
|
||||
def __init__(self, name: str, stream_type: VisionStreamType):
|
||||
super().__init__()
|
||||
# TODO: implement a receiver and connect thread
|
||||
self._name = name
|
||||
# Primary stream
|
||||
self.client = VisionIpcClient(name, stream_type, conflate=True)
|
||||
@@ -336,12 +337,12 @@ class CameraView(Widget):
|
||||
self._initialize_textures()
|
||||
|
||||
def _initialize_textures(self):
|
||||
self._clear_textures()
|
||||
if not TICI:
|
||||
self.texture_y = rl.load_texture_from_image(rl.Image(None, int(self.client.stride),
|
||||
int(self.client.height), 1, rl.PixelFormat.PIXELFORMAT_UNCOMPRESSED_GRAYSCALE))
|
||||
self.texture_uv = rl.load_texture_from_image(rl.Image(None, int(self.client.stride // 2),
|
||||
int(self.client.height // 2), 1, rl.PixelFormat.PIXELFORMAT_UNCOMPRESSED_GRAY_ALPHA))
|
||||
self._clear_textures()
|
||||
if not TICI:
|
||||
self.texture_y = rl.load_texture_from_image(rl.Image(None, int(self.client.stride),
|
||||
int(self.client.height), 1, rl.PixelFormat.PIXELFORMAT_UNCOMPRESSED_GRAYSCALE))
|
||||
self.texture_uv = rl.load_texture_from_image(rl.Image(None, int(self.client.stride // 2),
|
||||
int(self.client.height // 2), 1, rl.PixelFormat.PIXELFORMAT_UNCOMPRESSED_GRAY_ALPHA))
|
||||
|
||||
def _clear_textures(self):
|
||||
if self.texture_y and self.texture_y.id:
|
||||
|
||||
@@ -35,20 +35,20 @@ class FontSizes:
|
||||
|
||||
@dataclass(frozen=True)
|
||||
class Colors:
|
||||
WHITE = rl.WHITE
|
||||
DISENGAGED = rl.Color(145, 155, 149, 255)
|
||||
OVERRIDE = rl.Color(145, 155, 149, 255) # Added
|
||||
ENGAGED = rl.Color(128, 216, 166, 255)
|
||||
DISENGAGED_BG = rl.Color(0, 0, 0, 153)
|
||||
OVERRIDE_BG = rl.Color(145, 155, 149, 204)
|
||||
ENGAGED_BG = rl.Color(128, 216, 166, 204)
|
||||
GREY = rl.Color(166, 166, 166, 255)
|
||||
DARK_GREY = rl.Color(114, 114, 114, 255)
|
||||
BLACK_TRANSLUCENT = rl.Color(0, 0, 0, 166)
|
||||
WHITE_TRANSLUCENT = rl.Color(255, 255, 255, 200)
|
||||
BORDER_TRANSLUCENT = rl.Color(255, 255, 255, 75)
|
||||
HEADER_GRADIENT_START = rl.Color(0, 0, 0, 114)
|
||||
HEADER_GRADIENT_END = rl.BLANK
|
||||
white: rl.Color = rl.WHITE
|
||||
disengaged: rl.Color = rl.Color(145, 155, 149, 255)
|
||||
override: rl.Color = rl.Color(145, 155, 149, 255) # Added
|
||||
engaged: rl.Color = rl.Color(128, 216, 166, 255)
|
||||
disengaged_bg: rl.Color = rl.Color(0, 0, 0, 153)
|
||||
override_bg: rl.Color = rl.Color(145, 155, 149, 204)
|
||||
engaged_bg: rl.Color = rl.Color(128, 216, 166, 204)
|
||||
grey: rl.Color = rl.Color(166, 166, 166, 255)
|
||||
dark_grey: rl.Color = rl.Color(114, 114, 114, 255)
|
||||
black_translucent: rl.Color = rl.Color(0, 0, 0, 166)
|
||||
white_translucent: rl.Color = rl.Color(255, 255, 255, 200)
|
||||
border_translucent: rl.Color = rl.Color(255, 255, 255, 75)
|
||||
header_gradient_start: rl.Color = rl.Color(0, 0, 0, 114)
|
||||
header_gradient_end: rl.Color = rl.BLANK
|
||||
|
||||
|
||||
UI_CONFIG = UIConfig()
|
||||
@@ -108,8 +108,8 @@ class HudRenderer(Widget):
|
||||
int(rect.y),
|
||||
int(rect.width),
|
||||
UI_CONFIG.header_height,
|
||||
COLORS.HEADER_GRADIENT_START,
|
||||
COLORS.HEADER_GRADIENT_END,
|
||||
COLORS.header_gradient_start,
|
||||
COLORS.header_gradient_end,
|
||||
)
|
||||
|
||||
if self.is_cruise_available:
|
||||
@@ -131,19 +131,19 @@ class HudRenderer(Widget):
|
||||
y = rect.y + 45
|
||||
|
||||
set_speed_rect = rl.Rectangle(x, y, set_speed_width, UI_CONFIG.set_speed_height)
|
||||
rl.draw_rectangle_rounded(set_speed_rect, 0.35, 10, COLORS.BLACK_TRANSLUCENT)
|
||||
rl.draw_rectangle_rounded_lines_ex(set_speed_rect, 0.35, 10, 6, COLORS.BORDER_TRANSLUCENT)
|
||||
rl.draw_rectangle_rounded(set_speed_rect, 0.35, 10, COLORS.black_translucent)
|
||||
rl.draw_rectangle_rounded_lines_ex(set_speed_rect, 0.35, 10, 6, COLORS.border_translucent)
|
||||
|
||||
max_color = COLORS.GREY
|
||||
set_speed_color = COLORS.DARK_GREY
|
||||
max_color = COLORS.grey
|
||||
set_speed_color = COLORS.dark_grey
|
||||
if self.is_cruise_set:
|
||||
set_speed_color = COLORS.WHITE
|
||||
set_speed_color = COLORS.white
|
||||
if ui_state.status == UIStatus.ENGAGED:
|
||||
max_color = COLORS.ENGAGED
|
||||
max_color = COLORS.engaged
|
||||
elif ui_state.status == UIStatus.DISENGAGED:
|
||||
max_color = COLORS.DISENGAGED
|
||||
max_color = COLORS.disengaged
|
||||
elif ui_state.status == UIStatus.OVERRIDE:
|
||||
max_color = COLORS.OVERRIDE
|
||||
max_color = COLORS.override
|
||||
|
||||
max_text = tr("MAX")
|
||||
max_text_width = measure_text_cached(self._font_semi_bold, max_text, FONT_SIZES.max_speed).x
|
||||
@@ -172,9 +172,9 @@ class HudRenderer(Widget):
|
||||
speed_text = str(round(self.speed))
|
||||
speed_text_size = measure_text_cached(self._font_bold, speed_text, FONT_SIZES.current_speed)
|
||||
speed_pos = rl.Vector2(rect.x + rect.width / 2 - speed_text_size.x / 2, 180 - speed_text_size.y / 2)
|
||||
rl.draw_text_ex(self._font_bold, speed_text, speed_pos, FONT_SIZES.current_speed, 0, COLORS.WHITE)
|
||||
rl.draw_text_ex(self._font_bold, speed_text, speed_pos, FONT_SIZES.current_speed, 0, COLORS.white)
|
||||
|
||||
unit_text = tr("km/h") if ui_state.is_metric else tr("mph")
|
||||
unit_text_size = measure_text_cached(self._font_medium, unit_text, FONT_SIZES.speed_unit)
|
||||
unit_pos = rl.Vector2(rect.x + rect.width / 2 - unit_text_size.x / 2, 290 - unit_text_size.y / 2)
|
||||
rl.draw_text_ex(self._font_medium, unit_text, unit_pos, FONT_SIZES.speed_unit, 0, COLORS.WHITE_TRANSLUCENT)
|
||||
rl.draw_text_ex(self._font_medium, unit_text, unit_pos, FONT_SIZES.speed_unit, 0, COLORS.white_translucent)
|
||||
|
||||
@@ -1,106 +0,0 @@
|
||||
"""
|
||||
Copyright (c) 2021-, Haibin Wen, sunnypilot, and a number of other contributors.
|
||||
|
||||
This file is part of sunnypilot and is licensed under the MIT License.
|
||||
See the LICENSE.md file in the root directory for more details.
|
||||
"""
|
||||
import datetime
|
||||
import os
|
||||
from pathlib import Path
|
||||
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state
|
||||
from openpilot.selfdrive.ui.layouts.settings.developer import DeveloperLayout
|
||||
from openpilot.system.hardware import PC
|
||||
from openpilot.system.hardware.hw import Paths
|
||||
from openpilot.system.ui.lib.application import gui_app
|
||||
from openpilot.system.ui.lib.multilang import tr
|
||||
from openpilot.system.ui.widgets import DialogResult
|
||||
from openpilot.system.ui.widgets.confirm_dialog import ConfirmDialog
|
||||
from openpilot.system.ui.widgets.list_view import button_item
|
||||
|
||||
from openpilot.system.ui.sunnypilot.widgets.html_render import HtmlModalSP
|
||||
from openpilot.system.ui.sunnypilot.widgets.list_view import toggle_item_sp
|
||||
|
||||
PREBUILT_PATH = os.path.join(Paths.comma_home(), "prebuilt") if PC else "/data/openpilot/prebuilt"
|
||||
|
||||
|
||||
class DeveloperLayoutSP(DeveloperLayout):
|
||||
def __init__(self):
|
||||
super().__init__()
|
||||
self.error_log_path = os.path.join(Paths.crash_log_root(), "error.log")
|
||||
self._is_release_branch: bool = self._is_release or ui_state.params.get_bool("IsReleaseSpBranch")
|
||||
self._is_development_branch: bool = ui_state.params.get_bool("IsTestedBranch") or ui_state.params.get_bool("IsDevelopmentBranch")
|
||||
self._initialize_items()
|
||||
|
||||
for item in self.items:
|
||||
self._scroller.add_widget(item)
|
||||
|
||||
def _initialize_items(self):
|
||||
self.show_advanced_controls = toggle_item_sp(tr("Show Advanced Controls"),
|
||||
tr("Toggle visibility of advanced sunnypilot controls.<br>This only changes the visibility of the toggles; " +
|
||||
"it does not change the actual enabled/disabled state."), param="ShowAdvancedControls")
|
||||
|
||||
self.enable_github_runner_toggle = toggle_item_sp(tr("GitHub Runner Service"), tr("Enables or disables the GitHub runner service."),
|
||||
param="EnableGithubRunner")
|
||||
|
||||
self.enable_copyparty_toggle = toggle_item_sp(tr("copyparty Service"),
|
||||
tr("copyparty is a very capable file server, you can use it to download your routes, view your logs " +
|
||||
"and even make some edits on some files from your browser. " +
|
||||
"Requires you to connect to your comma locally via its IP address."), param="EnableCopyparty")
|
||||
|
||||
self.prebuilt_toggle = toggle_item_sp(tr("Quickboot Mode"), "", param="QuickBootToggle", callback=self._on_prebuilt_toggled)
|
||||
|
||||
self.error_log_btn = button_item(tr("Error Log"), tr("VIEW"), tr("View the error log for sunnypilot crashes."), callback=self._on_error_log_clicked)
|
||||
|
||||
self.items: list = [self.show_advanced_controls, self.enable_github_runner_toggle, self.enable_copyparty_toggle, self.prebuilt_toggle, self.error_log_btn,]
|
||||
|
||||
@staticmethod
|
||||
def _on_prebuilt_toggled(state):
|
||||
if state:
|
||||
Path(PREBUILT_PATH).touch(exist_ok=True)
|
||||
else:
|
||||
os.remove(PREBUILT_PATH)
|
||||
ui_state.params.put_bool("QuickBootToggle", state)
|
||||
|
||||
def _on_delete_confirm(self, result):
|
||||
if result == DialogResult.CONFIRM:
|
||||
if os.path.exists(self.error_log_path):
|
||||
os.remove(self.error_log_path)
|
||||
|
||||
def _on_error_log_closed(self, result, log_exists):
|
||||
if result == DialogResult.CONFIRM and log_exists:
|
||||
dialog2 = ConfirmDialog(tr("Would you like to delete this log?"), tr("Yes"), tr("No"), rich=False)
|
||||
gui_app.set_modal_overlay(dialog2, callback=self._on_delete_confirm)
|
||||
|
||||
def _on_error_log_clicked(self):
|
||||
text = ""
|
||||
if os.path.exists(self.error_log_path):
|
||||
text = f"<b>{datetime.datetime.fromtimestamp(os.path.getmtime(self.error_log_path)).strftime('%d-%b-%Y %H:%M:%S').upper()}</b><br><br>"
|
||||
try:
|
||||
with open(self.error_log_path) as file:
|
||||
text += file.read()
|
||||
except Exception:
|
||||
pass
|
||||
dialog = HtmlModalSP(text=text, callback=lambda result: self._on_error_log_closed(result, os.path.exists(self.error_log_path)))
|
||||
gui_app.set_modal_overlay(dialog)
|
||||
|
||||
def _update_state(self):
|
||||
disable_updates = ui_state.params.get_bool("DisableUpdates")
|
||||
show_advanced = ui_state.params.get_bool("ShowAdvancedControls")
|
||||
|
||||
if (prebuilt_file := os.path.exists(PREBUILT_PATH)) != ui_state.params.get_bool("QuickBootToggle"):
|
||||
ui_state.params.put_bool("QuickBootToggle", prebuilt_file)
|
||||
self.prebuilt_toggle.action_item.set_state(prebuilt_file)
|
||||
|
||||
self.prebuilt_toggle.set_visible(show_advanced and not (self._is_release_branch or self._is_development_branch))
|
||||
self.prebuilt_toggle.action_item.set_enabled(disable_updates)
|
||||
|
||||
if disable_updates:
|
||||
self.prebuilt_toggle.set_description(tr("When toggled on, this creates a prebuilt file to allow accelerated boot times. When toggled off, it " +
|
||||
"removes the prebuilt file so compilation of locally edited cpp files can be made."))
|
||||
else:
|
||||
self.prebuilt_toggle.set_description(tr("Quickboot mode requires updates to be disabled.<br>Enable 'Disable Updates' in the Software panel first."))
|
||||
|
||||
self.enable_copyparty_toggle.set_visible(show_advanced)
|
||||
self.enable_github_runner_toggle.set_visible(show_advanced and not self._is_release_branch)
|
||||
self.error_log_btn.set_visible(not self._is_release_branch)
|
||||
@@ -4,248 +4,24 @@ Copyright (c) 2021-, Haibin Wen, sunnypilot, and a number of other contributors.
|
||||
This file is part of sunnypilot and is licensed under the MIT License.
|
||||
See the LICENSE.md file in the root directory for more details.
|
||||
"""
|
||||
import os
|
||||
import re
|
||||
import time
|
||||
import pyray as rl
|
||||
|
||||
from cereal import custom
|
||||
from openpilot.common.constants import CV
|
||||
from openpilot.selfdrive.ui.ui_state import device, ui_state
|
||||
from openpilot.system.ui.lib.multilang import tr
|
||||
from openpilot.system.ui.lib.application import gui_app
|
||||
from openpilot.system.ui.widgets import DialogResult, Widget
|
||||
from openpilot.system.ui.widgets.confirm_dialog import alert_dialog, ConfirmDialog
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.system.ui.widgets.scroller_tici import Scroller
|
||||
from openpilot.system.ui.widgets.toggle import ON_COLOR
|
||||
|
||||
from openpilot.sunnypilot.models.runners.constants import CUSTOM_MODEL_PATH
|
||||
from openpilot.system.ui.sunnypilot.lib.styles import style
|
||||
from openpilot.system.ui.sunnypilot.lib.utils import NoElideButtonAction
|
||||
from openpilot.system.ui.sunnypilot.widgets.list_view import ListItemSP, toggle_item_sp, option_item_sp
|
||||
from openpilot.system.ui.sunnypilot.widgets.progress_bar import progress_item
|
||||
from openpilot.system.ui.sunnypilot.widgets.tree_dialog import TreeOptionDialog, TreeNode, TreeFolder
|
||||
|
||||
if gui_app.sunnypilot_ui():
|
||||
from openpilot.system.ui.sunnypilot.widgets.list_view import button_item_sp as button_item
|
||||
from openpilot.system.ui.widgets import Widget
|
||||
|
||||
|
||||
class ModelsLayout(Widget):
|
||||
def __init__(self):
|
||||
super().__init__()
|
||||
self.model_manager = None
|
||||
self.download_status = None
|
||||
self.prev_download_status = None
|
||||
self.model_dialog = None
|
||||
self.last_cache_calc_time = 0
|
||||
|
||||
self._initialize_items()
|
||||
|
||||
self.clear_cache_item.action_item.set_value(f"{self._calculate_cache_size():.2f} MB")
|
||||
for ctrl, key in [(self.lane_turn_value_control, "LaneTurnValue"), (self.delay_control, "LagdToggleDelay")]:
|
||||
ctrl.action_item.set_value(int(float(ui_state.params.get(key, return_default=True)) * 100))
|
||||
|
||||
self._scroller = Scroller(self.items, line_separator=True, spacing=0)
|
||||
self._params = Params()
|
||||
items = self._initialize_items()
|
||||
self._scroller = Scroller(items, line_separator=True, spacing=0)
|
||||
|
||||
def _initialize_items(self):
|
||||
self.current_model_item = ListItemSP(
|
||||
title=tr("Current Model"),
|
||||
description="",
|
||||
action_item=NoElideButtonAction(tr("SELECT")),
|
||||
callback=self._handle_current_model_clicked
|
||||
)
|
||||
items = [
|
||||
|
||||
self.supercombo_label = progress_item(tr("Driving Model"))
|
||||
self.vision_label = progress_item(tr("Vision Model"))
|
||||
self.policy_label = progress_item(tr("Policy Model"))
|
||||
|
||||
self.refresh_item = button_item(tr("Refresh Model List"), tr("REFRESH"), "",
|
||||
lambda: (ui_state.params.put("ModelManager_LastSyncTime", 0),
|
||||
gui_app.set_modal_overlay(alert_dialog(tr("Fetching Latest Models")))))
|
||||
|
||||
self.clear_cache_item = ListItemSP(
|
||||
title=tr("Clear Model Cache"),
|
||||
description="",
|
||||
action_item=NoElideButtonAction(tr("CLEAR")),
|
||||
callback=self._clear_cache
|
||||
)
|
||||
|
||||
self.cancel_download_item = button_item(tr("Cancel Download"), tr("Cancel"), "", lambda: ui_state.params.remove("ModelManager_DownloadIndex"))
|
||||
|
||||
self.lane_turn_value_control = option_item_sp(tr("Adjust Lane Turn Speed"), "LaneTurnValue", 500, 2000,
|
||||
tr("Set the maximum speed for lane turn desires. Default is 19 mph."),
|
||||
int(round(100 / CV.MPH_TO_KPH)), None, True, "", style.BUTTON_WIDTH, None, True,
|
||||
lambda v: f"{int(round(v / 100 * (CV.MPH_TO_KPH if ui_state.is_metric else 1)))}" +
|
||||
f" {'km/h' if ui_state.is_metric else 'mph'}")
|
||||
|
||||
self.lane_turn_desire_toggle = toggle_item_sp(tr("Use Lane Turn Desires"),
|
||||
tr("If you're driving at 20 mph (32 km/h) or below and have your blinker on," +
|
||||
" the car will plan a turn in that direction at the nearest drivable path. " +
|
||||
"This prevents situations (like at red lights) where the car might plan the wrong turn direction."),
|
||||
param="LaneTurnDesire")
|
||||
|
||||
self.delay_control = option_item_sp(tr("Adjust Software Delay"), "LagdToggleDelay", 5, 50,
|
||||
tr("Adjust the software delay when Live Learning Steer Delay is toggled off. The default software delay value is 0.2"),
|
||||
1, None, True, "", style.BUTTON_WIDTH, None, True, lambda v: f"{v / 100:.2f}s")
|
||||
|
||||
self.lagd_toggle = toggle_item_sp(tr("Live Learning Steer Delay"), "", param="LagdToggle")
|
||||
|
||||
self.items = [self.current_model_item, self.cancel_download_item, self.supercombo_label, self.vision_label,
|
||||
self.policy_label, self.refresh_item, self.clear_cache_item, self.lane_turn_desire_toggle,
|
||||
self.lane_turn_value_control, self.lagd_toggle, self.delay_control]
|
||||
|
||||
def _update_lagd_description(self, lagd_toggle: bool):
|
||||
desc = tr("Enable this for the car to learn and adapt its steering response time. Disable to use a fixed steering response time. " +
|
||||
"Keeping this on provides the stock openpilot experience.")
|
||||
if lagd_toggle:
|
||||
desc += f"<br>{tr('Live Steer Delay:')} {ui_state.sm['liveDelay'].lateralDelay:.3f} s"
|
||||
elif ui_state.CP:
|
||||
sw = float(ui_state.params.get("LagdToggleDelay", "0.2"))
|
||||
cp = ui_state.CP.steerActuatorDelay
|
||||
desc += f"<br>{tr('Actuator Delay:')} {cp:.2f} s + {tr('Software Delay:')} {sw:.2f} s = {tr('Total Delay:')} {cp + sw:.2f} s"
|
||||
self.lagd_toggle.set_description(desc)
|
||||
|
||||
def _is_downloading(self):
|
||||
return (self.model_manager and self.model_manager.selectedBundle and
|
||||
self.model_manager.selectedBundle.status == custom.ModelManagerSP.DownloadStatus.downloading)
|
||||
|
||||
@staticmethod
|
||||
def _calculate_cache_size():
|
||||
cache_size = 0.0
|
||||
if os.path.exists(CUSTOM_MODEL_PATH):
|
||||
cache_size = sum(os.path.getsize(os.path.join(CUSTOM_MODEL_PATH, file)) for file in os.listdir(CUSTOM_MODEL_PATH)) / (1024**2)
|
||||
return cache_size
|
||||
|
||||
def _clear_cache(self):
|
||||
def _callback(response):
|
||||
if response == DialogResult.CONFIRM:
|
||||
ui_state.params.put_bool("ModelManager_ClearCache", True)
|
||||
self.clear_cache_item.action_item.set_value(f"{self._calculate_cache_size():.2f} MB")
|
||||
|
||||
gui_app.set_modal_overlay(ConfirmDialog(tr("This will delete ALL downloaded models from the cache except the currently active model. Are you sure?"),
|
||||
tr("Clear Cache")), callback=_callback)
|
||||
|
||||
def _handle_bundle_download_progress(self):
|
||||
labels = {custom.ModelManagerSP.Model.Type.supercombo: self.supercombo_label,
|
||||
custom.ModelManagerSP.Model.Type.vision: self.vision_label,
|
||||
custom.ModelManagerSP.Model.Type.policy: self.policy_label}
|
||||
for label in labels.values():
|
||||
label.set_visible(False)
|
||||
self.cancel_download_item.set_visible(False)
|
||||
|
||||
if not self.model_manager or (not self.model_manager.selectedBundle and not self.model_manager.activeBundle):
|
||||
return
|
||||
|
||||
bundle = self.model_manager.selectedBundle if self._is_downloading() or (
|
||||
self.model_manager.selectedBundle and self.model_manager.selectedBundle.status == custom.ModelManagerSP.DownloadStatus.failed
|
||||
) else self.model_manager.activeBundle
|
||||
if not bundle:
|
||||
return
|
||||
|
||||
self.download_status = bundle.status
|
||||
status_changed = self.prev_download_status != self.download_status
|
||||
self.prev_download_status = self.download_status
|
||||
|
||||
self.cancel_download_item.set_visible(bool(self.model_manager.selectedBundle) and bool(ui_state.params.get("ModelManager_DownloadIndex")))
|
||||
|
||||
if (current_time := time.monotonic()) - self.last_cache_calc_time > 0.5:
|
||||
self.last_cache_calc_time = current_time
|
||||
self.clear_cache_item.action_item.set_value(f"{self._calculate_cache_size():.2f} MB")
|
||||
|
||||
if self.download_status == custom.ModelManagerSP.DownloadStatus.downloading:
|
||||
device.reset_interactive_timeout()
|
||||
|
||||
for model in bundle.models:
|
||||
if label := labels.get(getattr(model.type, 'raw', model.type)):
|
||||
label.set_visible(True)
|
||||
p = model.artifact.downloadProgress
|
||||
text, show, color = f"pending - {bundle.displayName}", False, rl.GRAY
|
||||
if p.status == custom.ModelManagerSP.DownloadStatus.downloading:
|
||||
text, show = f"{int(p.progress)}% - {bundle.displayName}", True
|
||||
elif p.status in (custom.ModelManagerSP.DownloadStatus.downloaded, custom.ModelManagerSP.DownloadStatus.cached):
|
||||
status_text = tr("from cache" if p.status == custom.ModelManagerSP.DownloadStatus.cached else "downloaded")
|
||||
text, color = f"{bundle.displayName} - {status_text if status_changed else tr('ready')}", ON_COLOR
|
||||
elif p.status == custom.ModelManagerSP.DownloadStatus.failed:
|
||||
text, color = f"download failed - {bundle.displayName}", rl.RED
|
||||
label.action_item.update(p.progress, text, show, color)
|
||||
|
||||
@staticmethod
|
||||
def _show_reset_params_dialog():
|
||||
def _callback(response):
|
||||
if response == DialogResult.CONFIRM:
|
||||
ui_state.params.remove("CalibrationParams")
|
||||
ui_state.params.remove("LiveTorqueParameters")
|
||||
msg = tr("Model download has started in the background. We suggest resetting calibration. Would you like to do that now?")
|
||||
gui_app.set_modal_overlay(ConfirmDialog(msg, tr("Reset Calibration")), callback=_callback)
|
||||
|
||||
def _on_model_selected(self, result):
|
||||
if result != DialogResult.CONFIRM:
|
||||
return
|
||||
selected_ref = self.model_dialog.selection_ref
|
||||
if selected_ref == "Default":
|
||||
ui_state.params.remove("ModelManager_ActiveBundle")
|
||||
self._show_reset_params_dialog()
|
||||
elif selected_bundle := next((bundle for bundle in self.model_manager.availableBundles if bundle.ref == selected_ref), None):
|
||||
ui_state.params.put("ModelManager_DownloadIndex", selected_bundle.index)
|
||||
if self.model_manager.activeBundle and selected_bundle.generation != self.model_manager.activeBundle.generation:
|
||||
self._show_reset_params_dialog()
|
||||
self.model_dialog = None
|
||||
|
||||
@staticmethod
|
||||
def _bundle_to_node(bundle):
|
||||
return TreeNode(bundle.ref, {'display_name': bundle.displayName, 'short_name': bundle.internalName})
|
||||
|
||||
def _get_folders(self, favorites):
|
||||
bundles = self.model_manager.availableBundles
|
||||
folders = {}
|
||||
for bundle in bundles:
|
||||
folders.setdefault(next((ov_ride.value for ov_ride in bundle.overrides if ov_ride.key == "folder"), ""), []).append(bundle)
|
||||
|
||||
folders_list = [TreeFolder("", [TreeNode("Default", {'display_name': tr("Default Model"), 'short_name': "Default"})])]
|
||||
for folder, folder_bundles in sorted(folders.items(), key=lambda x: max((bundle.index for bundle in x[1]), default=-1), reverse=True):
|
||||
folder_bundles.sort(key=lambda bundle: bundle.index, reverse=True)
|
||||
name = folder + (f" - (Updated: {m.group(1)})" if folder_bundles and (m := re.search(r'\(([^)]*)\)[^(]*$', folder_bundles[0].displayName)) else "")
|
||||
folders_list.append(TreeFolder(name, [self._bundle_to_node(bundle) for bundle in folder_bundles]))
|
||||
|
||||
if favorites and (fav_bundles := [bundle for bundle in bundles if bundle.ref in favorites]):
|
||||
folders_list.insert(1, TreeFolder("Favorites", [self._bundle_to_node(bundle) for bundle in fav_bundles]))
|
||||
return folders_list
|
||||
|
||||
def _handle_current_model_clicked(self):
|
||||
favs = ui_state.params.get("ModelManager_Favs")
|
||||
favorites = set(favs.split(';')) if favs else set()
|
||||
folders_list = self._get_folders(favorites)
|
||||
|
||||
active_ref = self.model_manager.activeBundle.ref if self.model_manager.activeBundle else "Default"
|
||||
self.model_dialog = TreeOptionDialog(tr("Select a Model"), folders_list, active_ref, "ModelManager_Favs",
|
||||
get_folders_fn=self._get_folders, on_exit=self._on_model_selected)
|
||||
gui_app.set_modal_overlay(self.model_dialog, callback=self._on_model_selected)
|
||||
|
||||
def _update_state(self):
|
||||
advanced_controls: bool = ui_state.params.get_bool("ShowAdvancedControls")
|
||||
turn_desire: bool = ui_state.params.get_bool("LaneTurnDesire")
|
||||
live_delay: bool = ui_state.params.get_bool("LagdToggle")
|
||||
|
||||
self.lane_turn_desire_toggle.action_item.set_state(turn_desire)
|
||||
self.lane_turn_value_control.set_visible(turn_desire and advanced_controls)
|
||||
self.lagd_toggle.action_item.set_state(live_delay)
|
||||
self.delay_control.set_visible(not live_delay and advanced_controls)
|
||||
new_step = int(round(100 / CV.MPH_TO_KPH)) if ui_state.is_metric else 100
|
||||
if self.lane_turn_value_control.action_item.value_change_step != new_step:
|
||||
self.lane_turn_value_control.action_item.value_change_step = new_step
|
||||
|
||||
self._update_lagd_description(live_delay)
|
||||
self.model_manager = ui_state.sm["modelManagerSP"]
|
||||
self._handle_bundle_download_progress()
|
||||
active_name = self.model_manager.activeBundle.internalName if self.model_manager and self.model_manager.activeBundle.ref else tr("Default Model")
|
||||
self.current_model_item.action_item.set_value(active_name)
|
||||
|
||||
if not ui_state.is_offroad():
|
||||
self.current_model_item.action_item.set_enabled(False)
|
||||
self.current_model_item.set_description(tr("Only available when vehicle is off, or always offroad mode is on"))
|
||||
else:
|
||||
self.current_model_item.action_item.set_enabled(True)
|
||||
self.current_model_item.set_description("")
|
||||
]
|
||||
return items
|
||||
|
||||
def _render(self, rect):
|
||||
self._scroller.render(rect)
|
||||
|
||||
@@ -4,229 +4,27 @@ Copyright (c) 2021-, Haibin Wen, sunnypilot, and a number of other contributors.
|
||||
This file is part of sunnypilot and is licensed under the MIT License.
|
||||
See the LICENSE.md file in the root directory for more details.
|
||||
"""
|
||||
import datetime
|
||||
import os
|
||||
import platform
|
||||
import requests
|
||||
import shutil
|
||||
import threading
|
||||
from pathlib import Path
|
||||
from time import monotonic
|
||||
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.selfdrive.ui.ui_state import device, ui_state
|
||||
from openpilot.selfdrive.ui.layouts.settings.software import time_ago
|
||||
from openpilot.system.hardware.hw import Paths
|
||||
from openpilot.system.ui.lib.application import gui_app
|
||||
from openpilot.system.ui.lib.multilang import tr
|
||||
from openpilot.system.ui.widgets import DialogResult, Widget
|
||||
from openpilot.system.ui.widgets.confirm_dialog import ConfirmDialog
|
||||
from openpilot.system.ui.widgets.list_view import text_item
|
||||
from openpilot.system.ui.widgets.scroller_tici import Scroller
|
||||
|
||||
from openpilot.system.ui.sunnypilot.lib.utils import NoElideButtonAction
|
||||
from openpilot.system.ui.sunnypilot.widgets.list_view import ListItemSP
|
||||
from openpilot.system.ui.sunnypilot.widgets.tree_dialog import TreeFolder, TreeNode, TreeOptionDialog
|
||||
from openpilot.system.ui.sunnypilot.widgets.progress_bar import progress_item
|
||||
|
||||
MAP_PATH = Path(Paths.mapd_root()) / "offline"
|
||||
from openpilot.system.ui.widgets import Widget
|
||||
|
||||
|
||||
class OSMLayout(Widget):
|
||||
def __init__(self):
|
||||
super().__init__()
|
||||
self._current_percent = 0
|
||||
self._last_map_size_update = 0
|
||||
self._mem_params = Params("/dev/shm/params") if platform.system() != "Darwin" else ui_state.params
|
||||
self._initialize_items()
|
||||
self._update_map_size()
|
||||
self._progress.set_visible(False)
|
||||
self._state_btn.set_visible(False)
|
||||
self._mapd_version.action_item.set_text(ui_state.params.get("MapdVersion") or "Loading...")
|
||||
self._scroller = Scroller(self.items, line_separator=True, spacing=0)
|
||||
|
||||
self._params = Params()
|
||||
items = self._initialize_items()
|
||||
self._scroller = Scroller(items, line_separator=True, spacing=0)
|
||||
|
||||
def _initialize_items(self):
|
||||
self._mapd_version = text_item(tr("Mapd Version"), lambda: ui_state.params.get("MapdVersion") or "Loading...")
|
||||
self._delete_maps_btn = ListItemSP(tr("Downloaded Maps"), action_item=NoElideButtonAction(tr("DELETE"), enabled=True), callback=self._delete_maps)
|
||||
self._progress = progress_item(tr("Downloading Map"))
|
||||
self._update_btn = ListItemSP(tr("Database Update"), action_item=NoElideButtonAction(tr("CHECK"), enabled=True), callback=self._update_db)
|
||||
self._country_btn = ListItemSP(tr("Country"), action_item=NoElideButtonAction(tr("SELECT"), enabled=True), callback=lambda: self._select_region("Country"))
|
||||
self._state_btn = ListItemSP(tr("State"), action_item=NoElideButtonAction(tr("SELECT"), enabled=True), callback=lambda: self._select_region("State"))
|
||||
items = [
|
||||
|
||||
self.items = [self._mapd_version, self._delete_maps_btn, self._progress, self._update_btn, self._country_btn, self._state_btn]
|
||||
|
||||
def _show_confirm(self, msg, confirm_text, func):
|
||||
gui_app.set_modal_overlay(ConfirmDialog(msg, confirm_text), lambda res: func() if res == DialogResult.CONFIRM else None)
|
||||
|
||||
def calculate_size(self):
|
||||
total_size = 0
|
||||
directories_to_scan = [MAP_PATH] if MAP_PATH.exists() else []
|
||||
while directories_to_scan:
|
||||
try:
|
||||
for entry in os.scandir(directories_to_scan.pop()):
|
||||
if entry.is_file():
|
||||
total_size += entry.stat().st_size
|
||||
elif entry.is_dir():
|
||||
directories_to_scan.append(entry.path)
|
||||
except OSError:
|
||||
pass
|
||||
self._delete_maps_btn.action_item.set_value(f"{total_size / 1024 ** 2:.2f} MB" if total_size < 1024 ** 3 else f"{total_size / 1024 ** 3:.2f} GB")
|
||||
|
||||
def _update_map_size(self):
|
||||
threading.Thread(target=self.calculate_size, daemon=True).start()
|
||||
|
||||
def _do_delete_maps(self):
|
||||
if MAP_PATH.exists():
|
||||
shutil.rmtree(MAP_PATH)
|
||||
|
||||
for param in ("OsmDownloadedDate", "OsmLocal", "OsmLocationName", "OsmLocationTitle", "OsmStateName", "OsmStateTitle"):
|
||||
ui_state.params.remove(param)
|
||||
|
||||
self._delete_maps_btn.action_item.set_enabled(True)
|
||||
self._delete_maps_btn.action_item.set_text(tr("DELETE"))
|
||||
self._update_map_size()
|
||||
|
||||
def _on_confirm_delete_maps(self):
|
||||
self._delete_maps_btn.action_item.set_enabled(False)
|
||||
self._delete_maps_btn.action_item.set_text("DELETING...")
|
||||
threading.Thread(target=self._do_delete_maps).start()
|
||||
|
||||
def _delete_maps(self):
|
||||
self._show_confirm(tr("This will delete ALL downloaded maps\n\nAre you sure you want to delete all maps?"),
|
||||
tr("Yes, delete all maps"), self._on_confirm_delete_maps)
|
||||
|
||||
def _update_db(self):
|
||||
self._show_confirm(tr("This will start the download process and it might take a while to complete."), tr("Start Download"),
|
||||
lambda: ui_state.params.put_bool("OsmDbUpdatesCheck", True))
|
||||
|
||||
def _select_region(self, region_type):
|
||||
is_country = region_type == "Country"
|
||||
btn = self._country_btn if is_country else self._state_btn
|
||||
btn.action_item.set_enabled(False)
|
||||
btn.action_item.set_text(tr("FETCHING..."))
|
||||
threading.Thread(target=self._do_select_region, args=(region_type, btn)).start()
|
||||
|
||||
def _handle_region_selection(self, region_type, locations, key, res, ref):
|
||||
if res != DialogResult.CONFIRM or not ref:
|
||||
if region_type == "State" and res == DialogResult.CANCEL:
|
||||
if ui_state.params.get("OsmLocationName") == "US" and not ui_state.params.get("OsmStateName"):
|
||||
ui_state.params.remove("OsmLocationName")
|
||||
ui_state.params.remove("OsmLocationTitle")
|
||||
ui_state.params.remove("OsmLocal")
|
||||
self._update_labels()
|
||||
return
|
||||
|
||||
if region_type == "Country":
|
||||
ui_state.params.put_bool("OsmLocal", True)
|
||||
ui_state.params.remove("OsmStateName")
|
||||
ui_state.params.remove("OsmStateTitle")
|
||||
|
||||
ui_state.params.put(f"{key}Name", ref)
|
||||
name = next((n.data['display_name'] for n in locations if n.ref == ref), ref)
|
||||
ui_state.params.put(f"{key}Title", name)
|
||||
|
||||
if ref == "US" and region_type == "Country":
|
||||
self._select_region("State")
|
||||
else:
|
||||
self._update_db()
|
||||
|
||||
def _do_select_region(self, region_type, btn):
|
||||
base_url = "https://raw.githubusercontent.com/pfeiferj/openpilot-mapd/main/"
|
||||
url = base_url + ("nation_bounding_boxes.json" if region_type == "Country" else "us_states_bounding_boxes.json")
|
||||
try:
|
||||
data = requests.get(url, timeout=10).json()
|
||||
locations = sorted([TreeNode(ref=k, data={'display_name': v['full_name']}) for k, v in data.items()], key=lambda n: n.data['display_name'])
|
||||
except Exception:
|
||||
locations = []
|
||||
|
||||
if region_type == "State":
|
||||
locations.insert(0, TreeNode(ref="All", data={'display_name': tr("All states (~6.0 GB)")}))
|
||||
|
||||
btn.action_item.set_enabled(True)
|
||||
btn.action_item.set_text(tr("SELECT"))
|
||||
|
||||
key = "OsmLocation" if region_type == "Country" else "OsmState"
|
||||
current = ui_state.params.get(f"{key}Name") or ""
|
||||
|
||||
dialog = TreeOptionDialog(tr(f"Select {region_type}"), [TreeFolder(folder="", nodes=locations)], current_ref=current, search_prompt="Perform a search")
|
||||
dialog.on_exit = lambda res: self._handle_region_selection(region_type, locations, key, res, dialog.selection_ref)
|
||||
gui_app.set_modal_overlay(dialog, callback=lambda res: self._handle_region_selection(region_type, locations, key, res, dialog.selection_ref))
|
||||
|
||||
def _update_labels(self):
|
||||
downloading = bool(self._mem_params.get("OSMDownloadLocations"))
|
||||
self._country_btn.set_enabled(not downloading)
|
||||
self._state_btn.set_enabled(not downloading)
|
||||
self._state_btn.set_visible(ui_state.params.get("OsmLocationName") == "US")
|
||||
self._update_btn.set_visible(bool(ui_state.params.get("OsmLocationName")))
|
||||
|
||||
self._country_btn.action_item.set_value(ui_state.params.get("OsmLocationTitle") or "")
|
||||
self._state_btn.action_item.set_value(ui_state.params.get("OsmStateTitle") or "")
|
||||
|
||||
pending = ui_state.params.get_bool("OsmDbUpdatesCheck")
|
||||
if downloading or pending:
|
||||
if downloading:
|
||||
device.reset_interactive_timeout()
|
||||
self._update_map_size()
|
||||
self._progress.set_visible(True)
|
||||
progress = ui_state.params.get("OSMDownloadProgress")
|
||||
total = progress.get('total_files', 0) if progress else 0
|
||||
done = progress.get('downloaded_files', 0) if progress else 0
|
||||
failed = total > 0 and not downloading and done < total
|
||||
|
||||
if total > 0:
|
||||
progress_perc = max(0.0, min(100.0, (done / total) * 100.0))
|
||||
else:
|
||||
progress_perc = 0.0
|
||||
|
||||
if failed:
|
||||
text = "0% - Downloading Maps"
|
||||
btn_text = tr("Error: Invalid download. Retry.")
|
||||
self._current_percent = 0.0
|
||||
elif total > 0 and downloading:
|
||||
self._current_percent = progress_perc
|
||||
perc_int = int(progress_perc)
|
||||
text = f"{perc_int}% - Downloading Maps"
|
||||
btn_text = f"{done}/{total} ({perc_int}%)"
|
||||
else:
|
||||
self._current_percent = 0.0
|
||||
text = "0% - Downloading Maps"
|
||||
btn_text = tr("Downloading Maps...")
|
||||
|
||||
self._progress.action_item.update(self._current_percent, text, show_progress=total > 0 and downloading and not failed)
|
||||
self._update_btn.action_item.set_enabled(not downloading) # TODO-SP: introduce CANCEL database download with mapd
|
||||
self._update_btn.action_item.set_value(btn_text)
|
||||
self._country_btn.action_item.set_enabled(not downloading)
|
||||
self._state_btn.action_item.set_enabled(not downloading)
|
||||
self._delete_maps_btn.action_item.set_enabled(not downloading)
|
||||
else:
|
||||
self._progress.set_visible(False)
|
||||
self._update_btn.action_item.set_enabled(True)
|
||||
self._country_btn.action_item.set_enabled(True)
|
||||
self._state_btn.action_item.set_enabled(True)
|
||||
self._delete_maps_btn.action_item.set_enabled(True)
|
||||
|
||||
ts = ui_state.params.get("OsmDownloadedDate")
|
||||
dt: datetime.datetime | None = None
|
||||
|
||||
if ts:
|
||||
try:
|
||||
ts_f = float(ts)
|
||||
if ts_f > 0:
|
||||
dt = datetime.datetime.fromtimestamp(ts_f, tz=datetime.UTC)
|
||||
except (ValueError, TypeError):
|
||||
dt = None
|
||||
|
||||
formatted = time_ago(dt)
|
||||
self._update_btn.action_item.set_value(tr("Last checked {}").format(formatted))
|
||||
|
||||
def show_event(self):
|
||||
self._scroller.show_event()
|
||||
|
||||
def _update_state(self):
|
||||
now = monotonic()
|
||||
if now - self._last_map_size_update >= 1.0:
|
||||
self._last_map_size_update = now
|
||||
self._update_labels()
|
||||
]
|
||||
return items
|
||||
|
||||
def _render(self, rect):
|
||||
self._scroller.render(rect)
|
||||
|
||||
def show_event(self):
|
||||
self._scroller.show_event()
|
||||
|
||||
@@ -9,9 +9,10 @@ from enum import IntEnum
|
||||
|
||||
import pyray as rl
|
||||
from openpilot.selfdrive.ui.layouts.settings import settings as OP
|
||||
from openpilot.selfdrive.ui.layouts.settings.developer import DeveloperLayout
|
||||
from openpilot.selfdrive.ui.sunnypilot.layouts.settings.device import DeviceLayoutSP
|
||||
from openpilot.selfdrive.ui.layouts.settings.firehose import FirehoseLayout
|
||||
from openpilot.selfdrive.ui.sunnypilot.layouts.settings.software import SoftwareLayoutSP
|
||||
from openpilot.selfdrive.ui.layouts.settings.software import SoftwareLayout
|
||||
from openpilot.selfdrive.ui.layouts.settings.toggles import TogglesLayout
|
||||
from openpilot.system.ui.lib.application import gui_app, MousePos
|
||||
from openpilot.system.ui.lib.multilang import tr_noop
|
||||
@@ -30,7 +31,6 @@ from openpilot.selfdrive.ui.sunnypilot.layouts.settings.steering import Steering
|
||||
from openpilot.selfdrive.ui.sunnypilot.layouts.settings.cruise import CruiseLayout
|
||||
from openpilot.selfdrive.ui.sunnypilot.layouts.settings.visuals import VisualsLayout
|
||||
from openpilot.selfdrive.ui.sunnypilot.layouts.settings.display import DisplayLayout
|
||||
from openpilot.selfdrive.ui.sunnypilot.layouts.settings.developer import DeveloperLayoutSP
|
||||
|
||||
# from openpilot.selfdrive.ui.sunnypilot.layouts.settings.navigation import NavigationLayout
|
||||
|
||||
@@ -112,9 +112,9 @@ class SettingsLayoutSP(OP.SettingsLayout):
|
||||
self._panels = {
|
||||
OP.PanelType.DEVICE: PanelInfo(tr_noop("Device"), DeviceLayoutSP(), icon="../../sunnypilot/selfdrive/assets/offroad/icon_home.png"),
|
||||
OP.PanelType.NETWORK: PanelInfo(tr_noop("Network"), NetworkUISP(wifi_manager), icon="icons/network.png"),
|
||||
OP.PanelType.SUNNYLINK: PanelInfo(tr_noop("sunnylink"), SunnylinkLayout(), icon="icons/wifi_strength_full.png"),
|
||||
OP.PanelType.SUNNYLINK: PanelInfo(tr_noop("sunnylink"), SunnylinkLayout(), icon="icons/shell.png"),
|
||||
OP.PanelType.TOGGLES: PanelInfo(tr_noop("Toggles"), TogglesLayout(), icon="../../sunnypilot/selfdrive/assets/offroad/icon_toggle.png"),
|
||||
OP.PanelType.SOFTWARE: PanelInfo(tr_noop("Software"), SoftwareLayoutSP(), icon="../../sunnypilot/selfdrive/assets/offroad/icon_software.png"),
|
||||
OP.PanelType.SOFTWARE: PanelInfo(tr_noop("Software"), SoftwareLayout(), icon="../../sunnypilot/selfdrive/assets/offroad/icon_software.png"),
|
||||
OP.PanelType.MODELS: PanelInfo(tr_noop("Models"), ModelsLayout(), icon="../../sunnypilot/selfdrive/assets/offroad/icon_models.png"),
|
||||
OP.PanelType.STEERING: PanelInfo(tr_noop("Steering"), SteeringLayout(), icon="../../sunnypilot/selfdrive/assets/offroad/icon_lateral.png"),
|
||||
OP.PanelType.CRUISE: PanelInfo(tr_noop("Cruise"), CruiseLayout(), icon="icons/speed_limit.png"),
|
||||
@@ -125,7 +125,7 @@ class SettingsLayoutSP(OP.SettingsLayout):
|
||||
OP.PanelType.TRIPS: PanelInfo(tr_noop("Trips"), TripsLayout(), icon="../../sunnypilot/selfdrive/assets/offroad/icon_trips.png"),
|
||||
OP.PanelType.VEHICLE: PanelInfo(tr_noop("Vehicle"), VehicleLayout(), icon="../../sunnypilot/selfdrive/assets/offroad/icon_vehicle.png"),
|
||||
OP.PanelType.FIREHOSE: PanelInfo(tr_noop("Firehose"), FirehoseLayout(), icon="../../sunnypilot/selfdrive/assets/offroad/icon_firehose.png"),
|
||||
OP.PanelType.DEVELOPER: PanelInfo(tr_noop("Developer"), DeveloperLayoutSP(), icon="icons/shell.png"),
|
||||
OP.PanelType.DEVELOPER: PanelInfo(tr_noop("Developer"), DeveloperLayout(), icon="icons/shell.png"),
|
||||
}
|
||||
|
||||
def _draw_sidebar(self, rect: rl.Rectangle):
|
||||
|
||||
@@ -1,96 +0,0 @@
|
||||
"""
|
||||
Copyright (c) 2021-, Haibin Wen, sunnypilot, and a number of other contributors.
|
||||
|
||||
This file is part of sunnypilot and is licensed under the MIT License.
|
||||
See the LICENSE.md file in the root directory for more details.
|
||||
"""
|
||||
import os
|
||||
|
||||
from openpilot.selfdrive.ui.layouts.settings.software import SoftwareLayout
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state
|
||||
from openpilot.system.hardware import HARDWARE
|
||||
from openpilot.system.ui.lib.application import gui_app
|
||||
from openpilot.system.ui.lib.multilang import tr, tr_noop
|
||||
from openpilot.system.ui.widgets import DialogResult
|
||||
from openpilot.system.ui.widgets.confirm_dialog import ConfirmDialog
|
||||
|
||||
from openpilot.system.ui.sunnypilot.widgets.list_view import toggle_item_sp
|
||||
from openpilot.system.ui.sunnypilot.widgets.tree_dialog import TreeOptionDialog, TreeNode, TreeFolder
|
||||
|
||||
|
||||
DESCRIPTIONS = {
|
||||
'disable_updates_offroad': tr_noop(
|
||||
"When enabled, automatic software updates will be off.<br><b>This requires a reboot to take effect.</b>"
|
||||
),
|
||||
'disable_updates_onroad': tr_noop(
|
||||
"Please enable \"Always Offroad\" mode or turn off the vehicle to adjust these toggles."
|
||||
)
|
||||
}
|
||||
|
||||
|
||||
class SoftwareLayoutSP(SoftwareLayout):
|
||||
def __init__(self):
|
||||
super().__init__()
|
||||
self.disable_updates_toggle = toggle_item_sp(
|
||||
lambda: tr("Disable Updates"),
|
||||
description="",
|
||||
initial_state=ui_state.params.get_bool("DisableUpdates"),
|
||||
callback=self._on_disable_updates_toggled,
|
||||
)
|
||||
self._scroller.add_widget(self.disable_updates_toggle)
|
||||
|
||||
def _handle_reboot(self, result):
|
||||
if result == DialogResult.CONFIRM:
|
||||
ui_state.params.put_bool("DisableUpdates", self.disable_updates_toggle.action_item.get_state())
|
||||
ui_state.params.put_bool("DoReboot", True)
|
||||
else:
|
||||
self.disable_updates_toggle.action_item.set_state(ui_state.params.get_bool("DisableUpdates"))
|
||||
|
||||
def _on_disable_updates_toggled(self, enabled):
|
||||
dialog = ConfirmDialog(tr("System reboot required for changes to take effect. Reboot now?"), tr("Reboot"))
|
||||
gui_app.set_modal_overlay(dialog, callback=self._handle_reboot)
|
||||
|
||||
def _on_select_branch(self):
|
||||
current_git_branch = ui_state.params.get("GitBranch") or ""
|
||||
branches_str = ui_state.params.get("UpdaterAvailableBranches") or ""
|
||||
branches = [b for b in branches_str.split(",") if b]
|
||||
current_target = ui_state.params.get("UpdaterTargetBranch") or ""
|
||||
top_level_branches = [current_git_branch, "release-mici", "release-tizi", "staging", "dev", "master"]
|
||||
|
||||
if HARDWARE.get_device_type() == "tici":
|
||||
top_level_branches = ["release-tici", "staging-tici"]
|
||||
branches = [b for b in branches if b.endswith("-tici")]
|
||||
|
||||
top_level_nodes = [TreeNode(b, {'display_name': b}) for b in top_level_branches if b in branches]
|
||||
remaining_branches = [b for b in branches if b not in top_level_branches]
|
||||
prebuilt_nodes = [TreeNode(b, {'display_name': b}) for b in remaining_branches if b.endswith("-prebuilt")]
|
||||
non_prebuilt_nodes = [TreeNode(b, {'display_name': b}) for b in remaining_branches if not b.endswith("-prebuilt")]
|
||||
|
||||
folders = [
|
||||
TreeFolder("", top_level_nodes),
|
||||
TreeFolder("Prebuilt Branches", prebuilt_nodes),
|
||||
TreeFolder("Non-Prebuilt Branches", non_prebuilt_nodes),
|
||||
]
|
||||
|
||||
def _on_branch_selected(result):
|
||||
if result == DialogResult.CONFIRM and self._branch_dialog is not None:
|
||||
selection = self._branch_dialog.selection_ref
|
||||
if selection:
|
||||
ui_state.params.put("UpdaterTargetBranch", selection)
|
||||
self._branch_btn.action_item.set_value(selection)
|
||||
os.system("pkill -SIGUSR1 -f system.updated.updated")
|
||||
self._branch_dialog = None
|
||||
|
||||
self._branch_dialog = TreeOptionDialog(tr("Select a branch"), folders, current_target, "",
|
||||
on_exit=_on_branch_selected)
|
||||
|
||||
gui_app.set_modal_overlay(self._branch_dialog, callback=_on_branch_selected)
|
||||
|
||||
def _update_state(self):
|
||||
super()._update_state()
|
||||
show_advanced = ui_state.params.get_bool("ShowAdvancedControls")
|
||||
self.disable_updates_toggle.action_item.set_enabled(ui_state.is_offroad())
|
||||
self.disable_updates_toggle.set_visible(show_advanced)
|
||||
|
||||
disable_updates_desc = tr(DESCRIPTIONS["disable_updates_offroad"] if ui_state.is_offroad() else DESCRIPTIONS["disable_updates_onroad"])
|
||||
self.disable_updates_toggle.set_description(disable_updates_desc)
|
||||
@@ -4,340 +4,27 @@ Copyright (c) 2021-, Haibin Wen, sunnypilot, and a number of other contributors.
|
||||
This file is part of sunnypilot and is licensed under the MIT License.
|
||||
See the LICENSE.md file in the root directory for more details.
|
||||
"""
|
||||
from cereal import custom
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state
|
||||
from openpilot.sunnypilot.sunnylink.api import UNREGISTERED_SUNNYLINK_DONGLE_ID
|
||||
from openpilot.system.ui.lib.application import gui_app, FontWeight
|
||||
from openpilot.system.ui.lib.multilang import tr
|
||||
from openpilot.system.ui.sunnypilot.widgets.sunnylink_pairing_dialog import SunnylinkPairingDialog
|
||||
from openpilot.system.ui.widgets.button import ButtonStyle, Button
|
||||
from openpilot.system.ui.widgets.confirm_dialog import alert_dialog, ConfirmDialog
|
||||
from openpilot.system.ui.widgets.label import UnifiedLabel
|
||||
from openpilot.system.ui.widgets.list_view import button_item, dual_button_item
|
||||
from openpilot.system.ui.widgets.scroller_tici import Scroller, LineSeparator
|
||||
from openpilot.system.ui.widgets import Widget, DialogResult
|
||||
from openpilot.system.ui.sunnypilot.widgets.list_view import toggle_item_sp
|
||||
import pyray as rl
|
||||
|
||||
if gui_app.sunnypilot_ui():
|
||||
from openpilot.system.ui.sunnypilot.widgets.list_view import button_item_sp as button_item
|
||||
|
||||
|
||||
class SunnylinkHeader(Widget):
|
||||
def __init__(self):
|
||||
super().__init__()
|
||||
|
||||
self._title = UnifiedLabel(
|
||||
text="🚀 sunnylink 🚀",
|
||||
font_size=90,
|
||||
font_weight=FontWeight.AUDIOWIDE,
|
||||
text_color=rl.WHITE,
|
||||
alignment=rl.GuiTextAlignment.TEXT_ALIGN_CENTER,
|
||||
alignment_vertical=rl.GuiTextAlignmentVertical.TEXT_ALIGN_TOP,
|
||||
wrap_text=False,
|
||||
elide=False
|
||||
)
|
||||
|
||||
self._description = UnifiedLabel(
|
||||
text=tr("For secure backup, restore, and remote configuration"),
|
||||
font_size=40,
|
||||
font_weight=FontWeight.LIGHT,
|
||||
text_color=rl.Color(0, 255, 0, 255), # Green
|
||||
alignment=rl.GuiTextAlignment.TEXT_ALIGN_CENTER,
|
||||
alignment_vertical=rl.GuiTextAlignmentVertical.TEXT_ALIGN_TOP,
|
||||
wrap_text=True,
|
||||
elide=False
|
||||
)
|
||||
|
||||
self._sponsor_msg = UnifiedLabel(
|
||||
text=tr("Sponsorship isn't required for basic backup/restore") + "\n" +
|
||||
tr("Click the Sponsor button for more details"),
|
||||
font_size=35,
|
||||
font_weight=FontWeight.LIGHT,
|
||||
text_color=rl.Color(255, 165, 0, 255), # Orange
|
||||
alignment=rl.GuiTextAlignment.TEXT_ALIGN_CENTER,
|
||||
alignment_vertical=rl.GuiTextAlignmentVertical.TEXT_ALIGN_TOP,
|
||||
wrap_text=True,
|
||||
elide=False
|
||||
)
|
||||
|
||||
self._padding = 20
|
||||
self._spacing = 10
|
||||
|
||||
def set_parent_rect(self, parent_rect: rl.Rectangle) -> None:
|
||||
super().set_parent_rect(parent_rect)
|
||||
|
||||
content_width = int(parent_rect.width - (self._padding * 2))
|
||||
|
||||
title_height = self._title.get_content_height(content_width)
|
||||
desc_height = self._description.get_content_height(content_width)
|
||||
sponsor_height = self._sponsor_msg.get_content_height(content_width)
|
||||
|
||||
total_height = (self._padding + title_height + self._spacing +
|
||||
desc_height + self._spacing + sponsor_height + self._padding)
|
||||
|
||||
self._rect.width = parent_rect.width
|
||||
self._rect.height = total_height
|
||||
|
||||
def _render(self, rect: rl.Rectangle):
|
||||
content_width = rect.width - (self._padding * 2)
|
||||
current_y = rect.y + self._padding
|
||||
|
||||
# Render title
|
||||
title_height = self._title.get_content_height(int(content_width))
|
||||
title_rect = rl.Rectangle(rect.x + self._padding, current_y, content_width, title_height)
|
||||
self._title.render(title_rect)
|
||||
current_y += title_height + self._spacing
|
||||
|
||||
# Render description
|
||||
desc_height = self._description.get_content_height(int(content_width))
|
||||
desc_rect = rl.Rectangle(rect.x + self._padding, current_y, content_width, desc_height)
|
||||
self._description.render(desc_rect)
|
||||
current_y += desc_height + self._spacing
|
||||
|
||||
# Render sponsor message
|
||||
sponsor_height = self._sponsor_msg.get_content_height(int(content_width))
|
||||
sponsor_rect = rl.Rectangle(rect.x + self._padding, current_y, content_width, sponsor_height)
|
||||
self._sponsor_msg.render(sponsor_rect)
|
||||
|
||||
|
||||
class SunnylinkDescriptionItem(Widget):
|
||||
def __init__(self):
|
||||
super().__init__()
|
||||
self._description = UnifiedLabel(
|
||||
text="",
|
||||
font_size=40,
|
||||
font_weight=FontWeight.LIGHT,
|
||||
text_color=rl.WHITE,
|
||||
alignment=rl.GuiTextAlignment.TEXT_ALIGN_LEFT,
|
||||
alignment_vertical=rl.GuiTextAlignmentVertical.TEXT_ALIGN_TOP,
|
||||
wrap_text=True,
|
||||
elide=False,
|
||||
)
|
||||
self._padding = 20
|
||||
|
||||
def set_parent_rect(self, parent_rect: rl.Rectangle) -> None:
|
||||
super().set_parent_rect(parent_rect)
|
||||
desc_height = self._description.get_content_height(int(parent_rect.width)) + self._padding * 2
|
||||
|
||||
self._rect.width = parent_rect.width
|
||||
self._rect.height = desc_height
|
||||
|
||||
def set_text(self, text: str):
|
||||
self._description.set_text(text)
|
||||
|
||||
def set_color(self, color: rl.Color):
|
||||
self._description.set_text_color(color)
|
||||
|
||||
def _render(self, rect: rl.Rectangle):
|
||||
content_width = rect.width - (self._padding * 2)
|
||||
|
||||
desc_height = self._description.get_content_height(int(content_width))
|
||||
desc_rect = rl.Rectangle(rect.x + self._padding, rect.y, content_width, desc_height)
|
||||
self._description.render(desc_rect)
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.system.ui.widgets.scroller_tici import Scroller
|
||||
from openpilot.system.ui.widgets import Widget
|
||||
|
||||
|
||||
class SunnylinkLayout(Widget):
|
||||
def __init__(self):
|
||||
super().__init__()
|
||||
|
||||
self._sunnylink_pairing_dialog: SunnylinkPairingDialog | None = None
|
||||
self._restore_in_progress = False
|
||||
self._backup_in_progress = False
|
||||
self._sunnylink_enabled = ui_state.params.get("SunnylinkEnabled")
|
||||
|
||||
self._params = Params()
|
||||
items = self._initialize_items()
|
||||
self._scroller = Scroller(items, line_separator=False, spacing=0)
|
||||
self._scroller = Scroller(items, line_separator=True, spacing=0)
|
||||
|
||||
def _initialize_items(self):
|
||||
self._sunnylink_toggle = toggle_item_sp(
|
||||
title=tr("Enable sunnylink"),
|
||||
description=tr("This is the master switch, it will allow you to cutoff any sunnylink requests should you want to do that."),
|
||||
param="SunnylinkEnabled",
|
||||
callback=self._sunnylink_toggle_callback
|
||||
)
|
||||
|
||||
self._sunnylink_description = SunnylinkDescriptionItem()
|
||||
self._sunnylink_description.set_visible(False)
|
||||
|
||||
self._sponsor_btn = button_item(
|
||||
title=tr("Sponsor Status"),
|
||||
button_text=tr("SPONSOR"),
|
||||
description=tr(
|
||||
"Become a sponsor of sunnypilot to get early access to sunnylink features when they become available."),
|
||||
callback=lambda: self._handle_pair_btn(False)
|
||||
)
|
||||
self._pair_btn = button_item(
|
||||
title=tr("Pair GitHub Account"),
|
||||
button_text=tr("Not Paired"),
|
||||
description=tr(
|
||||
"Pair your GitHub account to grant your device sponsor benefits, including API access on sunnylink."),
|
||||
callback=lambda: self._handle_pair_btn(True)
|
||||
)
|
||||
self._sunnylink_uploader_toggle = toggle_item_sp(
|
||||
title=tr("Enable sunnylink uploader (infrastructure test)"),
|
||||
description=tr("Enable sunnylink uploader to allow sunnypilot to upload your driving data to sunnypilot servers. ") +
|
||||
tr("(Only for highest tiers, and does NOT bring ANY benefit to you yet. We are just testing data volume.)"),
|
||||
param="EnableSunnylinkUploader"
|
||||
)
|
||||
self._sunnylink_backup_restore_buttons = dual_button_item(
|
||||
description="",
|
||||
left_text=tr("Backup Settings"),
|
||||
right_text=tr("Restore Settings"),
|
||||
left_callback=self._handle_backup_btn,
|
||||
right_callback=self._handle_restore_btn
|
||||
)
|
||||
self._backup_btn: Button = self._sunnylink_backup_restore_buttons.action_item.left_button # store for easy individual access
|
||||
self._restore_btn: Button = self._sunnylink_backup_restore_buttons.action_item.right_button
|
||||
self._backup_btn.set_button_style(ButtonStyle.NORMAL)
|
||||
self._restore_btn.set_button_style(ButtonStyle.PRIMARY)
|
||||
|
||||
items = [
|
||||
SunnylinkHeader(),
|
||||
LineSeparator(),
|
||||
self._sunnylink_toggle,
|
||||
self._sunnylink_description,
|
||||
LineSeparator(),
|
||||
self._sponsor_btn,
|
||||
LineSeparator(),
|
||||
self._pair_btn,
|
||||
LineSeparator(),
|
||||
self._sunnylink_uploader_toggle,
|
||||
LineSeparator(),
|
||||
self._sunnylink_backup_restore_buttons
|
||||
|
||||
]
|
||||
return items
|
||||
|
||||
@staticmethod
|
||||
def _get_sunnylink_dongle_id() -> str | None:
|
||||
return str(ui_state.params.get("SunnylinkDongleId") or (lambda: tr("N/A")))
|
||||
|
||||
def _handle_pair_btn(self, sponsor_pairing: bool = False):
|
||||
sunnylink_dongle_id = self._get_sunnylink_dongle_id()
|
||||
if sunnylink_dongle_id == UNREGISTERED_SUNNYLINK_DONGLE_ID:
|
||||
gui_app.set_modal_overlay(alert_dialog(message=tr("sunnylink Dongle ID not found. ") +
|
||||
tr("This may be due to weak internet connection or sunnylink registration issue. ") +
|
||||
tr("Please reboot and try again.")))
|
||||
elif not self._sunnylink_pairing_dialog:
|
||||
self._sunnylink_pairing_dialog = SunnylinkPairingDialog(sponsor_pairing)
|
||||
gui_app.set_modal_overlay(self._sunnylink_pairing_dialog, callback=lambda result: setattr(self, '_sunnylink_pairing_dialog', None))
|
||||
|
||||
def _handle_backup_btn(self):
|
||||
backup_dialog = ConfirmDialog(text=tr("Are you sure you want to backup your current sunnypilot settings?"), confirm_text="Backup")
|
||||
gui_app.set_modal_overlay(backup_dialog, callback=self._backup_handler)
|
||||
|
||||
def _handle_restore_btn(self):
|
||||
self._restore_btn.set_enabled(False)
|
||||
restore_dialog = ConfirmDialog(text=tr("Are you sure you want to restore the last backed up sunnypilot settings?"), confirm_text="Restore")
|
||||
gui_app.set_modal_overlay(restore_dialog, callback=self._restore_handler)
|
||||
|
||||
def _backup_handler(self, dialog_result: int):
|
||||
if dialog_result == DialogResult.CONFIRM:
|
||||
self._backup_in_progress = True
|
||||
self._backup_btn.set_enabled(False)
|
||||
ui_state.params.put_bool("BackupManager_CreateBackup", True)
|
||||
|
||||
def _restore_handler(self, dialog_result: int):
|
||||
if dialog_result == DialogResult.CONFIRM:
|
||||
self._restore_in_progress = True
|
||||
self._restore_btn.set_enabled(False)
|
||||
ui_state.params.put("BackupManager_RestoreVersion", "latest")
|
||||
|
||||
def handle_backup_restore_progress(self):
|
||||
sunnylink_backup_manager = ui_state.sm["backupManagerSP"]
|
||||
|
||||
backup_status = sunnylink_backup_manager.backupStatus
|
||||
restore_status = sunnylink_backup_manager.restoreStatus
|
||||
backup_progress = sunnylink_backup_manager.backupProgress
|
||||
restore_progress = sunnylink_backup_manager.restoreProgress
|
||||
|
||||
if self._backup_in_progress:
|
||||
self._restore_btn.set_enabled(False)
|
||||
self._backup_btn.set_enabled(False)
|
||||
|
||||
if backup_status == custom.BackupManagerSP.Status.inProgress:
|
||||
self._backup_in_progress = True
|
||||
text = tr(f"Backing up {backup_progress}%")
|
||||
self._backup_btn.set_text(text)
|
||||
|
||||
elif backup_status == custom.BackupManagerSP.Status.failed:
|
||||
self._backup_in_progress = False
|
||||
self._backup_btn.set_enabled(not ui_state.is_onroad())
|
||||
self._backup_btn.set_text(tr("Backup Failed"))
|
||||
|
||||
elif (backup_status == custom.BackupManagerSP.Status.completed or
|
||||
(backup_status == custom.BackupManagerSP.Status.idle and backup_progress == 100.0)):
|
||||
self._backup_in_progress = False
|
||||
dialog = alert_dialog(tr("Settings backup completed."))
|
||||
gui_app.set_modal_overlay(dialog)
|
||||
self._backup_btn.set_enabled(not ui_state.is_onroad())
|
||||
|
||||
elif self._restore_in_progress:
|
||||
self._restore_btn.set_enabled(False)
|
||||
self._backup_btn.set_enabled(False)
|
||||
|
||||
if restore_status == custom.BackupManagerSP.Status.inProgress:
|
||||
self._restore_in_progress = True
|
||||
text = tr(f"Restoring {restore_progress}%")
|
||||
self._restore_btn.set_text(text)
|
||||
|
||||
elif restore_status == custom.BackupManagerSP.Status.failed:
|
||||
self._restore_in_progress = False
|
||||
self._restore_btn.set_enabled(not ui_state.is_onroad())
|
||||
self._restore_btn.set_text(tr("Restore Failed"))
|
||||
dialog = alert_dialog(tr("Unable to restore the settings, try again later."))
|
||||
gui_app.set_modal_overlay(dialog)
|
||||
|
||||
elif (restore_status == custom.BackupManagerSP.Status.completed or
|
||||
(restore_status == custom.BackupManagerSP.Status.idle and restore_progress == 100.0)):
|
||||
self._restore_in_progress = False
|
||||
dialog = alert_dialog(tr("Settings restored. Confirm to restart the interface."))
|
||||
gui_app.set_modal_overlay(dialog, callback=lambda: gui_app.request_close())
|
||||
|
||||
else:
|
||||
can_enable = self._sunnylink_enabled and not ui_state.is_onroad()
|
||||
self._backup_btn.set_enabled(can_enable)
|
||||
self._backup_btn.set_text(tr("Backup Settings"))
|
||||
self._restore_btn.set_enabled(can_enable)
|
||||
self._restore_btn.set_text(tr("Restore Settings"))
|
||||
|
||||
def _sunnylink_toggle_callback(self, state: bool):
|
||||
if state:
|
||||
description = tr(
|
||||
"Welcome back!! We're excited to see you've enabled sunnylink again!")
|
||||
color = rl.Color(0, 255, 0, 255) # Green
|
||||
else:
|
||||
description = ("😢 " + tr("Not going to lie, it's sad to see you disabled sunnylink") +
|
||||
tr(", but we'll be here when you're ready to come back."))
|
||||
color = rl.Color(255, 165, 0, 255) # Orange
|
||||
self._sunnylink_description.set_text(description)
|
||||
self._sunnylink_description.set_color(color)
|
||||
self._sunnylink_description.set_visible(True)
|
||||
self._sunnylink_toggle.show_description(False)
|
||||
|
||||
def _update_state(self):
|
||||
super()._update_state()
|
||||
self._sunnylink_enabled = ui_state.params.get_bool("SunnylinkEnabled")
|
||||
self._sunnylink_toggle.set_right_value(tr("Dongle ID") + ": " + self._get_sunnylink_dongle_id())
|
||||
self._sunnylink_toggle.action_item.set_enabled(not ui_state.is_onroad())
|
||||
self._sunnylink_toggle.action_item.set_state(self._sunnylink_enabled)
|
||||
self._sunnylink_uploader_toggle.action_item.set_enabled(self._sunnylink_enabled)
|
||||
self.handle_backup_restore_progress()
|
||||
|
||||
sponsor_btn_text = tr("THANKS ♥") if ui_state.sunnylink_state.is_sponsor() else tr("SPONSOR")
|
||||
tier_name = ui_state.sunnylink_state.get_sponsor_tier().name.capitalize() or tr("Not Sponsor")
|
||||
self._sponsor_btn.action_item.set_text(sponsor_btn_text)
|
||||
self._sponsor_btn.action_item.set_value(tier_name, ui_state.sunnylink_state.get_sponsor_tier_color())
|
||||
self._sponsor_btn.action_item.set_enabled(self._sunnylink_enabled)
|
||||
|
||||
pair_btn_text = tr("Paired") if ui_state.sunnylink_state.is_paired() else tr("Not Paired")
|
||||
self._pair_btn.action_item.set_text(pair_btn_text)
|
||||
self._pair_btn.action_item.set_enabled(self._sunnylink_enabled)
|
||||
|
||||
def _render(self, rect):
|
||||
self._scroller.render(rect)
|
||||
|
||||
def show_event(self):
|
||||
super().show_event()
|
||||
self._scroller.show_event()
|
||||
self._sunnylink_description.set_visible(False)
|
||||
|
||||
@@ -14,7 +14,7 @@ class UIStateSP:
|
||||
self.params = Params()
|
||||
self.sm_services_ext = [
|
||||
"modelManagerSP", "selfdriveStateSP", "longitudinalPlanSP", "backupManagerSP",
|
||||
"gpsLocation", "liveTorqueParameters", "carStateSP", "liveMapDataSP", "carParamsSP", "liveDelay"
|
||||
"gpsLocation", "liveTorqueParameters", "carStateSP", "liveMapDataSP", "carParamsSP"
|
||||
]
|
||||
|
||||
self.sunnylink_state = SunnylinkState()
|
||||
|
||||
@@ -2,8 +2,3 @@ test
|
||||
test_translations
|
||||
test_ui/report_1
|
||||
test_ui/raylib_report
|
||||
|
||||
diff/*.mp4
|
||||
diff/*.html
|
||||
diff/.coverage
|
||||
diff/htmlcov/
|
||||
|
||||
@@ -1,201 +0,0 @@
|
||||
#!/usr/bin/env python3
|
||||
import os
|
||||
import sys
|
||||
import subprocess
|
||||
import tempfile
|
||||
import base64
|
||||
import webbrowser
|
||||
import argparse
|
||||
from pathlib import Path
|
||||
from openpilot.common.basedir import BASEDIR
|
||||
|
||||
DIFF_OUT_DIR = Path(BASEDIR) / "selfdrive" / "ui" / "tests" / "diff" / "report"
|
||||
|
||||
|
||||
def extract_frames(video_path, output_dir):
|
||||
output_pattern = str(output_dir / "frame_%04d.png")
|
||||
cmd = ['ffmpeg', '-i', video_path, '-vsync', '0', output_pattern, '-y']
|
||||
subprocess.run(cmd, capture_output=True, check=True)
|
||||
frames = sorted(output_dir.glob("frame_*.png"))
|
||||
return frames
|
||||
|
||||
|
||||
def compare_frames(frame1_path, frame2_path):
|
||||
result = subprocess.run(['cmp', '-s', frame1_path, frame2_path])
|
||||
return result.returncode == 0
|
||||
|
||||
|
||||
def frame_to_data_url(frame_path):
|
||||
with open(frame_path, 'rb') as f:
|
||||
data = f.read()
|
||||
return f"data:image/png;base64,{base64.b64encode(data).decode()}"
|
||||
|
||||
|
||||
def create_diff_video(video1, video2, output_path):
|
||||
"""Create a diff video using ffmpeg blend filter with difference mode."""
|
||||
print("Creating diff video...")
|
||||
cmd = ['ffmpeg', '-i', video1, '-i', video2, '-filter_complex', '[0:v]blend=all_mode=difference', '-vsync', '0', '-y', output_path]
|
||||
subprocess.run(cmd, capture_output=True, check=True)
|
||||
|
||||
|
||||
def find_differences(video1, video2):
|
||||
with tempfile.TemporaryDirectory() as tmpdir:
|
||||
tmpdir = Path(tmpdir)
|
||||
|
||||
print(f"Extracting frames from {video1}...")
|
||||
frames1_dir = tmpdir / "frames1"
|
||||
frames1_dir.mkdir()
|
||||
frames1 = extract_frames(video1, frames1_dir)
|
||||
|
||||
print(f"Extracting frames from {video2}...")
|
||||
frames2_dir = tmpdir / "frames2"
|
||||
frames2_dir.mkdir()
|
||||
frames2 = extract_frames(video2, frames2_dir)
|
||||
|
||||
if len(frames1) != len(frames2):
|
||||
print(f"WARNING: Frame count mismatch: {len(frames1)} vs {len(frames2)}")
|
||||
min_frames = min(len(frames1), len(frames2))
|
||||
frames1 = frames1[:min_frames]
|
||||
frames2 = frames2[:min_frames]
|
||||
|
||||
print(f"Comparing {len(frames1)} frames...")
|
||||
different_frames = []
|
||||
frame_data = []
|
||||
|
||||
for i, (f1, f2) in enumerate(zip(frames1, frames2, strict=False)):
|
||||
is_different = not compare_frames(f1, f2)
|
||||
if is_different:
|
||||
different_frames.append(i)
|
||||
|
||||
if i < 10 or i >= len(frames1) - 10 or is_different:
|
||||
frame_data.append({'index': i, 'different': is_different, 'frame1_url': frame_to_data_url(f1), 'frame2_url': frame_to_data_url(f2)})
|
||||
|
||||
return different_frames, frame_data, len(frames1)
|
||||
|
||||
|
||||
def generate_html_report(video1, video2, basedir, different_frames, frame_data, total_frames):
|
||||
chunks = []
|
||||
if different_frames:
|
||||
current_chunk = [different_frames[0]]
|
||||
for i in range(1, len(different_frames)):
|
||||
if different_frames[i] == different_frames[i - 1] + 1:
|
||||
current_chunk.append(different_frames[i])
|
||||
else:
|
||||
chunks.append(current_chunk)
|
||||
current_chunk = [different_frames[i]]
|
||||
chunks.append(current_chunk)
|
||||
|
||||
result_text = (
|
||||
f"✅ Videos are identical! ({total_frames} frames)"
|
||||
if len(different_frames) == 0
|
||||
else f"❌ Found {len(different_frames)} different frames out of {total_frames} total ({(len(different_frames) / total_frames * 100):.1f}%)"
|
||||
)
|
||||
|
||||
html = f"""<h2>UI Diff</h2>
|
||||
<table>
|
||||
<tr>
|
||||
<td width='33%'>
|
||||
<p><strong>Video 1</strong></p>
|
||||
<video id='video1' width='100%' autoplay muted loop onplay='syncVideos()'>
|
||||
<source src='{os.path.join(basedir, os.path.basename(video1))}' type='video/mp4'>
|
||||
Your browser does not support the video tag.
|
||||
</video>
|
||||
</td>
|
||||
<td width='33%'>
|
||||
<p><strong>Video 2</strong></p>
|
||||
<video id='video2' width='100%' autoplay muted loop onplay='syncVideos()'>
|
||||
<source src='{os.path.join(basedir, os.path.basename(video2))}' type='video/mp4'>
|
||||
Your browser does not support the video tag.
|
||||
</video>
|
||||
</td>
|
||||
<td width='33%'>
|
||||
<p><strong>Pixel Diff</strong></p>
|
||||
<video id='diffVideo' width='100%' autoplay muted loop>
|
||||
<source src='{os.path.join(basedir, 'diff.mp4')}' type='video/mp4'>
|
||||
Your browser does not support the video tag.
|
||||
</video>
|
||||
</td>
|
||||
</tr>
|
||||
</table>
|
||||
<script>
|
||||
function syncVideos() {{
|
||||
const video1 = document.getElementById('video1');
|
||||
const video2 = document.getElementById('video2');
|
||||
const diffVideo = document.getElementById('diffVideo');
|
||||
video1.currentTime = video2.currentTime = diffVideo.currentTime;
|
||||
}}
|
||||
video1.addEventListener('timeupdate', () => {{
|
||||
if (Math.abs(video1.currentTime - video2.currentTime) > 0.1) {{
|
||||
video2.currentTime = video1.currentTime;
|
||||
}}
|
||||
if (Math.abs(video1.currentTime - diffVideo.currentTime) > 0.1) {{
|
||||
diffVideo.currentTime = video1.currentTime;
|
||||
}}
|
||||
}});
|
||||
video2.addEventListener('timeupdate', () => {{
|
||||
if (Math.abs(video2.currentTime - video1.currentTime) > 0.1) {{
|
||||
video1.currentTime = video2.currentTime;
|
||||
}}
|
||||
if (Math.abs(video2.currentTime - diffVideo.currentTime) > 0.1) {{
|
||||
diffVideo.currentTime = video2.currentTime;
|
||||
}}
|
||||
}});
|
||||
diffVideo.addEventListener('timeupdate', () => {{
|
||||
if (Math.abs(diffVideo.currentTime - video1.currentTime) > 0.1) {{
|
||||
video1.currentTime = diffVideo.currentTime;
|
||||
video2.currentTime = diffVideo.currentTime;
|
||||
}}
|
||||
}});
|
||||
</script>
|
||||
<hr>
|
||||
<p><strong>Results:</strong> {result_text}</p>
|
||||
"""
|
||||
return html
|
||||
|
||||
|
||||
def main():
|
||||
parser = argparse.ArgumentParser(description='Compare two videos and generate HTML diff report')
|
||||
parser.add_argument('video1', help='First video file')
|
||||
parser.add_argument('video2', help='Second video file')
|
||||
parser.add_argument('output', nargs='?', default='diff.html', help='Output HTML file (default: diff.html)')
|
||||
parser.add_argument("--basedir", type=str, help="Base directory for output", default="")
|
||||
parser.add_argument('--no-open', action='store_true', help='Do not open HTML report in browser')
|
||||
|
||||
args = parser.parse_args()
|
||||
|
||||
os.makedirs(DIFF_OUT_DIR, exist_ok=True)
|
||||
|
||||
print("=" * 60)
|
||||
print("VIDEO DIFF - HTML REPORT")
|
||||
print("=" * 60)
|
||||
print(f"Video 1: {args.video1}")
|
||||
print(f"Video 2: {args.video2}")
|
||||
print(f"Output: {args.output}")
|
||||
print()
|
||||
|
||||
# Create diff video
|
||||
diff_video_path = os.path.join(os.path.dirname(args.output), DIFF_OUT_DIR / "diff.mp4")
|
||||
create_diff_video(args.video1, args.video2, diff_video_path)
|
||||
|
||||
different_frames, frame_data, total_frames = find_differences(args.video1, args.video2)
|
||||
|
||||
if different_frames is None:
|
||||
sys.exit(1)
|
||||
|
||||
print()
|
||||
print("Generating HTML report...")
|
||||
html = generate_html_report(args.video1, args.video2, args.basedir, different_frames, frame_data, total_frames)
|
||||
|
||||
with open(DIFF_OUT_DIR / args.output, 'w') as f:
|
||||
f.write(html)
|
||||
|
||||
# Open in browser by default
|
||||
if not args.no_open:
|
||||
print(f"Opening {args.output} in browser...")
|
||||
webbrowser.open(f'file://{os.path.abspath(DIFF_OUT_DIR / args.output)}')
|
||||
|
||||
return 0 if len(different_frames) == 0 else 1
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
sys.exit(main())
|
||||
@@ -1,128 +0,0 @@
|
||||
#!/usr/bin/env python3
|
||||
import os
|
||||
import time
|
||||
import coverage
|
||||
import pyray as rl
|
||||
from dataclasses import dataclass
|
||||
from openpilot.selfdrive.ui.tests.diff.diff import DIFF_OUT_DIR
|
||||
|
||||
os.environ["RECORD"] = "1"
|
||||
if "RECORD_OUTPUT" not in os.environ:
|
||||
os.environ["RECORD_OUTPUT"] = "mici_ui_replay.mp4"
|
||||
|
||||
os.environ["RECORD_OUTPUT"] = os.path.join(DIFF_OUT_DIR, os.environ["RECORD_OUTPUT"])
|
||||
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.system.version import terms_version, training_version
|
||||
from openpilot.system.ui.lib.application import gui_app, MousePos, MouseEvent
|
||||
from openpilot.selfdrive.ui.ui_state import ui_state
|
||||
from openpilot.selfdrive.ui.mici.layouts.main import MiciMainLayout
|
||||
|
||||
FPS = 60
|
||||
HEADLESS = os.getenv("WINDOWED", "0") == "1"
|
||||
|
||||
|
||||
@dataclass
|
||||
class DummyEvent:
|
||||
click: bool = False
|
||||
# TODO: add some kind of intensity
|
||||
swipe_left: bool = False
|
||||
swipe_right: bool = False
|
||||
swipe_down: bool = False
|
||||
|
||||
|
||||
SCRIPT = [
|
||||
(0, DummyEvent()),
|
||||
(FPS * 1, DummyEvent(click=True)),
|
||||
(FPS * 2, DummyEvent(click=True)),
|
||||
(FPS * 3, DummyEvent()),
|
||||
]
|
||||
|
||||
|
||||
def setup_state():
|
||||
params = Params()
|
||||
params.put("HasAcceptedTerms", terms_version)
|
||||
params.put("CompletedTrainingVersion", training_version)
|
||||
params.put("DongleId", "test123456789")
|
||||
params.put("UpdaterCurrentDescription", "0.10.1 / test-branch / abc1234 / Nov 30")
|
||||
return None
|
||||
|
||||
|
||||
def inject_click(coords):
|
||||
events = []
|
||||
x, y = coords[0]
|
||||
events.append(MouseEvent(pos=MousePos(x, y), slot=0, left_pressed=True, left_released=False, left_down=False, t=time.monotonic()))
|
||||
for x, y in coords[1:]:
|
||||
events.append(MouseEvent(pos=MousePos(x, y), slot=0, left_pressed=False, left_released=False, left_down=True, t=time.monotonic()))
|
||||
x, y = coords[-1]
|
||||
events.append(MouseEvent(pos=MousePos(x, y), slot=0, left_pressed=False, left_released=True, left_down=False, t=time.monotonic()))
|
||||
|
||||
with gui_app._mouse._lock:
|
||||
gui_app._mouse._events.extend(events)
|
||||
|
||||
|
||||
def handle_event(event: DummyEvent):
|
||||
if event.click:
|
||||
inject_click([(gui_app.width // 2, gui_app.height // 2)])
|
||||
if event.swipe_left:
|
||||
inject_click([(gui_app.width * 3 // 4, gui_app.height // 2),
|
||||
(gui_app.width // 4, gui_app.height // 2),
|
||||
(0, gui_app.height // 2)])
|
||||
if event.swipe_right:
|
||||
inject_click([(gui_app.width // 4, gui_app.height // 2),
|
||||
(gui_app.width * 3 // 4, gui_app.height // 2),
|
||||
(gui_app.width, gui_app.height // 2)])
|
||||
if event.swipe_down:
|
||||
inject_click([(gui_app.width // 2, gui_app.height // 4),
|
||||
(gui_app.width // 2, gui_app.height * 3 // 4),
|
||||
(gui_app.width // 2, gui_app.height)])
|
||||
|
||||
|
||||
def run_replay():
|
||||
setup_state()
|
||||
os.makedirs(DIFF_OUT_DIR, exist_ok=True)
|
||||
|
||||
if not HEADLESS:
|
||||
rl.set_config_flags(rl.FLAG_WINDOW_HIDDEN)
|
||||
gui_app.init_window("ui diff test", fps=FPS)
|
||||
main_layout = MiciMainLayout()
|
||||
main_layout.set_rect(rl.Rectangle(0, 0, gui_app.width, gui_app.height))
|
||||
|
||||
frame = 0
|
||||
script_index = 0
|
||||
|
||||
for should_render in gui_app.render():
|
||||
while script_index < len(SCRIPT) and SCRIPT[script_index][0] == frame:
|
||||
_, event = SCRIPT[script_index]
|
||||
handle_event(event)
|
||||
script_index += 1
|
||||
|
||||
ui_state.update()
|
||||
|
||||
if should_render:
|
||||
main_layout.render()
|
||||
|
||||
frame += 1
|
||||
|
||||
if script_index >= len(SCRIPT):
|
||||
break
|
||||
|
||||
gui_app.close()
|
||||
|
||||
print(f"Total frames: {frame}")
|
||||
print(f"Video saved to: {os.environ['RECORD_OUTPUT']}")
|
||||
|
||||
|
||||
def main():
|
||||
cov = coverage.coverage(source=['openpilot.selfdrive.ui.mici'])
|
||||
with cov.collect():
|
||||
run_replay()
|
||||
cov.stop()
|
||||
cov.save()
|
||||
cov.report()
|
||||
cov.html_report(directory=os.path.join(DIFF_OUT_DIR, 'htmlcov'))
|
||||
print("HTML report: htmlcov/index.html")
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
main()
|
||||
@@ -88,9 +88,9 @@ if __name__ == "__main__":
|
||||
print("Running...")
|
||||
patch_submaster(message_chunks)
|
||||
|
||||
W, H = 2048, 1216
|
||||
W, H = 1928, 1208
|
||||
vipc = VisionIpcServer("camerad")
|
||||
vipc.create_buffers(VisionStreamType.VISION_STREAM_ROAD, 5, W, H)
|
||||
vipc.create_buffers(VisionStreamType.VISION_STREAM_ROAD, 5, 1928, 1208)
|
||||
vipc.start_listener()
|
||||
yuv_buffer_size = W * H + (W // 2) * (H // 2) * 2
|
||||
yuv_data = np.random.randint(0, 256, yuv_buffer_size, dtype=np.uint8).tobytes()
|
||||
|
||||
@@ -369,7 +369,6 @@ def create_screenshots():
|
||||
with OpenpilotPrefix():
|
||||
params = Params()
|
||||
params.put("DongleId", "123456789012345")
|
||||
params.put("SunnylinkDongleId", "123456789012345")
|
||||
|
||||
# Set branch name
|
||||
params.put("UpdaterCurrentDescription", VERSION)
|
||||
|
||||
@@ -68,10 +68,10 @@ msgid ""
|
||||
"control alpha. Changing this setting will restart openpilot if the car is "
|
||||
"powered on."
|
||||
msgstr ""
|
||||
"<b>경고: 이 차량에서 openpilot의 롱컨 제어는 알파 버전이며 자동 긴급 제동"
|
||||
"(AEB)을 비활성화합니다.</b><br><br>이 차량에서는 openpilot 롱컨 제어 대신 "
|
||||
"차량 내장 ACC가 기본으로 사용됩니다. openpilot 롱컨 제어로 전환하려면 이 설"
|
||||
"정을 켜세요. 롱컨 제어 알파를 켤 때는 실험 모드 사용을 권장합니다. 차량 전"
|
||||
"<b>경고: 이 차량에서 openpilot의 종방향 제어는 알파 버전이며 자동 긴급 제동"
|
||||
"(AEB)을 비활성화합니다.</b><br><br>이 차량에서는 openpilot 종방향 제어 대신 "
|
||||
"차량 내장 ACC가 기본으로 사용됩니다. openpilot 종방향 제어로 전환하려면 이 설"
|
||||
"정을 켜세요. 종방향 제어 알파를 켤 때는 실험 모드 사용을 권장합니다. 차량 전"
|
||||
"원이 켜져 있는 경우 이 설정을 변경하면 openpilot이 재시작됩니다."
|
||||
|
||||
#: selfdrive/ui/layouts/settings/device.py:148
|
||||
@@ -130,7 +130,7 @@ msgstr "동의"
|
||||
#: selfdrive/ui/layouts/settings/toggles.py:70
|
||||
#, python-format
|
||||
msgid "Always-On Driver Monitoring"
|
||||
msgstr "운전자 모니터링 항상 켜짐"
|
||||
msgstr "항상 켜짐 운전자 모니터링"
|
||||
|
||||
#: selfdrive/ui/layouts/settings/toggles.py:186
|
||||
#, python-format
|
||||
@@ -138,7 +138,7 @@ msgid ""
|
||||
"An alpha version of openpilot longitudinal control can be tested, along with "
|
||||
"Experimental mode, on non-release branches."
|
||||
msgstr ""
|
||||
"openpilot 롱컨 제어 알파 버전은 실험 모드와 함께 비릴리스 브랜치에서 테스트"
|
||||
"openpilot 종방향 제어 알파 버전은 실험 모드와 함께 비릴리스 브랜치에서 테스트"
|
||||
"할 수 있습니다."
|
||||
|
||||
#: selfdrive/ui/layouts/settings/device.py:187
|
||||
@@ -192,7 +192,7 @@ msgstr "확인"
|
||||
#: selfdrive/ui/widgets/exp_mode_button.py:50
|
||||
#, python-format
|
||||
msgid "CHILL MODE ON"
|
||||
msgstr "안정적 모드 켜짐"
|
||||
msgstr "칠 모드 켜짐"
|
||||
|
||||
#: system/ui/widgets/network.py:155 selfdrive/ui/layouts/sidebar.py:73
|
||||
#: selfdrive/ui/layouts/sidebar.py:134 selfdrive/ui/layouts/sidebar.py:136
|
||||
@@ -283,7 +283,7 @@ msgstr "해제 후 재시작"
|
||||
#: selfdrive/ui/layouts/settings/device.py:103
|
||||
#, python-format
|
||||
msgid "Disengage to Reset Calibration"
|
||||
msgstr "해제 후 캘리브레이션 재설정"
|
||||
msgstr "해제 후 보정 재설정"
|
||||
|
||||
#: selfdrive/ui/layouts/settings/toggles.py:32
|
||||
msgid "Display speed in km/h instead of mph."
|
||||
@@ -372,7 +372,7 @@ msgstr "openpilot 사용"
|
||||
msgid ""
|
||||
"Enable the openpilot longitudinal control (alpha) toggle to allow "
|
||||
"Experimental mode."
|
||||
msgstr "실험 모드를 사용하려면 openpilot 롱컨 제어(알파) 토글을 켜세요."
|
||||
msgstr "실험 모드를 사용하려면 openpilot 종방향 제어(알파) 토글을 켜세요."
|
||||
|
||||
#: system/ui/widgets/network.py:204
|
||||
#, python-format
|
||||
@@ -415,7 +415,7 @@ msgid ""
|
||||
"Experimental mode is currently unavailable on this car since the car's stock "
|
||||
"ACC is used for longitudinal control."
|
||||
msgstr ""
|
||||
"이 차량은 롱컨 제어에 순정 ACC를 사용하므로 현재 실험 모드를 사용할 수 없습"
|
||||
"이 차량은 종방향 제어에 순정 ACC를 사용하므로 현재 실험 모드를 사용할 수 없습"
|
||||
"니다."
|
||||
|
||||
#: system/ui/widgets/network.py:373
|
||||
@@ -430,11 +430,11 @@ msgstr "설정 완료"
|
||||
|
||||
#: selfdrive/ui/layouts/settings/settings.py:66
|
||||
msgid "Firehose"
|
||||
msgstr "파이어호스"
|
||||
msgstr "Firehose"
|
||||
|
||||
#: selfdrive/ui/layouts/settings/firehose.py:18
|
||||
msgid "Firehose Mode"
|
||||
msgstr "파이어호스 모드"
|
||||
msgstr "Firehose 모드"
|
||||
|
||||
#: selfdrive/ui/layouts/settings/firehose.py:25
|
||||
msgid ""
|
||||
@@ -462,7 +462,7 @@ msgstr ""
|
||||
"최대의 효과를 위해 주 1회는 장치를 실내로 가져와 품질 좋은 USB‑C 어댑터와 "
|
||||
"Wi‑Fi에 연결하세요.\n"
|
||||
"\n"
|
||||
"핫스팟이나 무제한 SIM에 연결되어 있다면 주행 중에도 파이어호스 모드가 동작합니"
|
||||
"핫스팟이나 무제한 SIM에 연결되어 있다면 주행 중에도 Firehose 모드가 동작합니"
|
||||
"다.\n"
|
||||
"\n"
|
||||
"\n"
|
||||
@@ -470,7 +470,7 @@ msgstr ""
|
||||
"\n"
|
||||
"어떻게, 어디서 운전하는지가 중요한가요? 아니요. 평소처럼 운전하세요.\n"
|
||||
"\n"
|
||||
"파이어호스 모드에서 모든 구간을 가져가지나요? 아니요. 일부 구간만 선택"
|
||||
"Firehose 모드에서 모든 세그먼트가 가져가지나요? 아니요. 일부 세그먼트만 선택"
|
||||
"적으로 가져갑니다.\n"
|
||||
"\n"
|
||||
"좋은 USB‑C 어댑터는 무엇인가요? 빠른 휴대폰 또는 노트북 충전기면 충분합니"
|
||||
@@ -544,7 +544,7 @@ msgstr "LTE"
|
||||
#: selfdrive/ui/layouts/settings/developer.py:64
|
||||
#, python-format
|
||||
msgid "Longitudinal Maneuver Mode"
|
||||
msgstr "롱컨 기동 모드"
|
||||
msgstr "종방향 매뉴버 모드"
|
||||
|
||||
#: selfdrive/ui/onroad/hud_renderer.py:148
|
||||
#, python-format
|
||||
@@ -623,7 +623,7 @@ msgstr "미리보기"
|
||||
#: selfdrive/ui/widgets/prime.py:44
|
||||
#, python-format
|
||||
msgid "PRIME FEATURES:"
|
||||
msgstr "프라임 기능:"
|
||||
msgstr "prime 기능:"
|
||||
|
||||
#: selfdrive/ui/layouts/settings/device.py:48
|
||||
#, python-format
|
||||
@@ -646,7 +646,7 @@ msgid ""
|
||||
"Pair your device with comma connect (connect.comma.ai) and claim your comma "
|
||||
"prime offer."
|
||||
msgstr ""
|
||||
"장치를 comma connect(connect.comma.ai)와 페어링하고 comma 프라임 혜택을 받으세"
|
||||
"장치를 comma connect(connect.comma.ai)와 페어링하고 comma prime 혜택을 받으세"
|
||||
"요."
|
||||
|
||||
#: selfdrive/ui/widgets/setup.py:91
|
||||
@@ -748,7 +748,7 @@ msgstr "규제 정보"
|
||||
#: selfdrive/ui/layouts/settings/toggles.py:98
|
||||
#, python-format
|
||||
msgid "Relaxed"
|
||||
msgstr "편안한"
|
||||
msgstr "편안함"
|
||||
|
||||
#: selfdrive/ui/widgets/prime.py:47
|
||||
#, python-format
|
||||
@@ -773,7 +773,7 @@ msgstr "재설정"
|
||||
#: selfdrive/ui/layouts/settings/device.py:51
|
||||
#, python-format
|
||||
msgid "Reset Calibration"
|
||||
msgstr "캘리브레이션 재설정"
|
||||
msgstr "보정 재설정"
|
||||
|
||||
#: selfdrive/ui/layouts/settings/device.py:65
|
||||
#, python-format
|
||||
@@ -841,7 +841,7 @@ msgid ""
|
||||
"cycle through these personalities with your steering wheel distance button."
|
||||
msgstr ""
|
||||
"표준을 권장합니다. 공격적 모드에서는 앞차를 더 가깝게 따라가고 가감속이 더 적"
|
||||
"극적입니다. 편안한 모드에서는 앞차와 거리를 더 둡니다. 지원 차량에서는 스티어"
|
||||
"극적입니다. 편안함 모드에서는 앞차와 거리를 더 둡니다. 지원 차량에서는 스티어"
|
||||
"링의 차간 버튼으로 이 성향들을 전환할 수 있습니다."
|
||||
|
||||
#: selfdrive/ui/onroad/alert_renderer.py:59
|
||||
@@ -892,7 +892,7 @@ msgstr "제거"
|
||||
|
||||
#: selfdrive/ui/layouts/sidebar.py:117
|
||||
msgid "Unknown"
|
||||
msgstr "알수없음"
|
||||
msgstr "알 수 없음"
|
||||
|
||||
#: selfdrive/ui/layouts/settings/software.py:48
|
||||
#, python-format
|
||||
@@ -994,7 +994,7 @@ msgstr "카메라 시작 중"
|
||||
#: selfdrive/ui/widgets/prime.py:63
|
||||
#, python-format
|
||||
msgid "comma prime"
|
||||
msgstr "comma 프라임"
|
||||
msgstr "comma prime"
|
||||
|
||||
#: system/ui/widgets/network.py:142
|
||||
#, python-format
|
||||
@@ -1054,7 +1054,7 @@ msgstr "지금"
|
||||
#: selfdrive/ui/layouts/settings/developer.py:71
|
||||
#, python-format
|
||||
msgid "openpilot Longitudinal Control (Alpha)"
|
||||
msgstr "openpilot 롱컨 제어(알파)"
|
||||
msgstr "openpilot 종방향 제어(알파)"
|
||||
|
||||
#: selfdrive/ui/onroad/alert_renderer.py:51
|
||||
#, python-format
|
||||
@@ -1076,9 +1076,9 @@ msgid ""
|
||||
"some turns. The Experimental mode logo will also be shown in the top right "
|
||||
"corner."
|
||||
msgstr ""
|
||||
"openpilot은 기본적으로 안정적 모드로 주행합니다. 실험 모드를 사용하면 안정적 모드에 "
|
||||
"openpilot은 기본적으로 칠 모드로 주행합니다. 실험 모드를 사용하면 칠 모드에 "
|
||||
"아직 준비되지 않은 알파 수준의 기능이 활성화됩니다. 실험 기능은 아래와 같습니"
|
||||
"다:<br><h4>엔드투엔드 롱컨 제어</h4><br>주행 모델이 가속과 제동을 제어합니"
|
||||
"다:<br><h4>엔드투엔드 종방향 제어</h4><br>주행 모델이 가속과 제동을 제어합니"
|
||||
"다. openpilot은 빨간 신호 및 정지 표지에서의 정지를 포함해 사람이 운전한다고 "
|
||||
"판단하는 방식으로 주행합니다. 주행 속도는 모델이 결정하므로 설정 속도는 상한"
|
||||
"으로만 동작합니다. 알파 품질 기능이므로 오작동이 발생할 수 있습니다.<br><h4>"
|
||||
@@ -1111,7 +1111,7 @@ msgstr ""
|
||||
#: selfdrive/ui/layouts/settings/toggles.py:183
|
||||
#, python-format
|
||||
msgid "openpilot longitudinal control may come in a future update."
|
||||
msgstr "openpilot 롱컨 제어는 향후 업데이트에서 제공될 수 있습니다."
|
||||
msgstr "openpilot 종방향 제어는 향후 업데이트에서 제공될 수 있습니다."
|
||||
|
||||
#: selfdrive/ui/layouts/settings/device.py:26
|
||||
msgid ""
|
||||
@@ -1177,7 +1177,7 @@ msgstr[0] "{}분 전"
|
||||
#, python-format
|
||||
msgid "{} segment of your driving is in the training dataset so far."
|
||||
msgid_plural "{} segments of your driving is in the training dataset so far."
|
||||
msgstr[0] "현재까지 귀하의 주행 {}구간이 학습 데이터셋에 포함되었습니다."
|
||||
msgstr[0] "현재까지 귀하의 주행 {}세그먼트가 학습 데이터셋에 포함되었습니다."
|
||||
|
||||
#: selfdrive/ui/widgets/prime.py:62
|
||||
#, python-format
|
||||
@@ -1187,4 +1187,4 @@ msgstr "✓ 구독됨"
|
||||
#: selfdrive/ui/widgets/setup.py:22
|
||||
#, python-format
|
||||
msgid "🔥 Firehose Mode 🔥"
|
||||
msgstr "🔥 파이어호스 모드 🔥"
|
||||
msgstr "🔥 Firehose 모드 🔥"
|
||||
|
||||
File diff suppressed because it is too large
Load Diff
@@ -5,7 +5,6 @@
|
||||
"Português": "pt-BR",
|
||||
"Español": "es",
|
||||
"Türkçe": "tr",
|
||||
"Українська": "uk",
|
||||
"العربية": "ar",
|
||||
"ไทย": "th",
|
||||
"中文(繁體)": "zh-CHT",
|
||||
|
||||
@@ -64,7 +64,12 @@ def request_refresh_osm_location_data(nations: list[str], states: list[str] = No
|
||||
"states": states or []
|
||||
}
|
||||
|
||||
print(f"Downloading maps for {json.dumps(osm_download_locations)}")
|
||||
osm_download_locations_dump = json.dumps({
|
||||
"nations": nations,
|
||||
"states": states or []
|
||||
})
|
||||
|
||||
print(f"Downloading maps for {osm_download_locations_dump}")
|
||||
mem_params.put("OSMDownloadLocations", osm_download_locations)
|
||||
|
||||
|
||||
@@ -98,6 +103,8 @@ def filter_nations_and_states(nations: list[str], states: list[str] = None) -> t
|
||||
|
||||
|
||||
def update_osm_db() -> None:
|
||||
# last_downloaded_date = params.get("OsmDownloadedDate", return_default=True)
|
||||
# if params.get_bool("OsmDbUpdatesCheck") or time.monotonic() - last_downloaded_date >= 604800: # 7 days * 24 hours/day * 60
|
||||
if params.get_bool("OsmDbUpdatesCheck"):
|
||||
cleanup_old_osm_data(get_files_for_cleanup())
|
||||
country = params.get("OsmLocationName", return_default=True)
|
||||
|
||||
@@ -11,12 +11,13 @@ SEND_RAW_PRED = os.getenv('SEND_RAW_PRED')
|
||||
ConfidenceClass = log.ModelDataV2.ConfidenceClass
|
||||
|
||||
|
||||
def get_curvature_from_output(output, plan, vego, lat_action_t, mlsim):
|
||||
def get_curvature_from_output(output, vego, lat_action_t, mlsim):
|
||||
if not mlsim:
|
||||
if desired_curv := output.get('desired_curvature'): # If the model outputs the desired curvature, use that directly
|
||||
return float(desired_curv[0, 0])
|
||||
|
||||
return float(get_curvature_from_plan(plan[:, Plan.T_FROM_CURRENT_EULER][:, 2], plan[:, Plan.ORIENTATION_RATE][:, 2],
|
||||
plan_output = output['plan'][0]
|
||||
return float(get_curvature_from_plan(plan_output[:, Plan.T_FROM_CURRENT_EULER][:, 2], plan_output[:, Plan.ORIENTATION_RATE][:, 2],
|
||||
ModelConstants.T_IDXS, vego, lat_action_t))
|
||||
|
||||
|
||||
|
||||
@@ -28,7 +28,6 @@ from openpilot.sunnypilot.models.helpers import get_active_bundle
|
||||
from openpilot.sunnypilot.models.runners.helpers import get_model_runner
|
||||
|
||||
PROCESS_NAME = "selfdrive.modeld.modeld_tinygrad"
|
||||
RECOVERY_POWER = 1.0 # The higher this number the more aggressively the model will recover to lanecenter, too high and it will ping-pong
|
||||
|
||||
|
||||
class FrameMeta:
|
||||
@@ -157,13 +156,11 @@ class ModelState(ModelStateBase):
|
||||
def get_action_from_model(self, model_output: dict[str, np.ndarray], prev_action: log.ModelDataV2.Action,
|
||||
lat_action_t: float, long_action_t: float, v_ego: float) -> log.ModelDataV2.Action:
|
||||
plan = model_output['plan'][0]
|
||||
if 'planplus' in model_output:
|
||||
plan = plan + RECOVERY_POWER*model_output['planplus'][0]
|
||||
desired_accel, should_stop = get_accel_from_plan(plan[:, Plan.VELOCITY][:, 0], plan[:, Plan.ACCELERATION][:, 0], self.constants.T_IDXS,
|
||||
action_t=long_action_t)
|
||||
desired_accel = smooth_value(desired_accel, prev_action.desiredAcceleration, self.LONG_SMOOTH_SECONDS)
|
||||
|
||||
desired_curvature = get_curvature_from_output(model_output, plan, v_ego, lat_action_t, self.mlsim)
|
||||
desired_curvature = get_curvature_from_output(model_output, v_ego, lat_action_t, self.mlsim)
|
||||
if self.generation is not None and self.generation >= 10: # smooth curvature for post FOF models
|
||||
if v_ego > self.MIN_LAT_CONTROL_SPEED:
|
||||
desired_curvature = smooth_value(desired_curvature, prev_action.desiredCurvature, self.LAT_SMOOTH_SECONDS)
|
||||
|
||||
@@ -108,8 +108,6 @@ class Parser:
|
||||
plan_in_N, plan_out_N = (SplitModelConstants.PLAN_MHP_N, SplitModelConstants.PLAN_MHP_SELECTION) if plan_mhp else (0, 0)
|
||||
self.parse_mdn('plan', outs, in_N=plan_in_N, out_N=plan_out_N,
|
||||
out_shape=(SplitModelConstants.IDX_N, SplitModelConstants.PLAN_WIDTH))
|
||||
if 'planplus' in outs:
|
||||
self.parse_mdn('planplus', outs, in_N=plan_in_N, out_N=plan_out_N, out_shape=(SplitModelConstants.IDX_N, SplitModelConstants.PLAN_WIDTH))
|
||||
|
||||
def split_outputs(self, outs: dict[str, np.ndarray]) -> None:
|
||||
if 'desired_curvature' in outs:
|
||||
|
||||
@@ -19,7 +19,7 @@ from openpilot.system.hardware.hw import Paths
|
||||
from pathlib import Path
|
||||
|
||||
# see the README.md for more details on the model selector versioning
|
||||
CURRENT_SELECTOR_VERSION = 13
|
||||
CURRENT_SELECTOR_VERSION = 12
|
||||
REQUIRED_MIN_SELECTOR_VERSION = 12
|
||||
|
||||
USE_ONNX = os.getenv('USE_ONNX', PC)
|
||||
|
||||
@@ -63,9 +63,6 @@ class ModelManagerSP:
|
||||
f.write(chunk)
|
||||
bytes_downloaded += len(chunk)
|
||||
|
||||
if not self.params.get("ModelManager_DownloadIndex"):
|
||||
raise Exception("Download cancelled")
|
||||
|
||||
if total_size > 0:
|
||||
progress = (bytes_downloaded / total_size) * 100
|
||||
model.downloadProgress.status = custom.ModelManagerSP.DownloadStatus.downloading
|
||||
@@ -179,7 +176,6 @@ class ModelManagerSP:
|
||||
cloudlog.exception(e)
|
||||
finally:
|
||||
self.params.remove("ModelManager_DownloadIndex")
|
||||
self.selected_bundle = None
|
||||
|
||||
if self.params.get("ModelManager_ClearCache"):
|
||||
self.clear_model_cache()
|
||||
|
||||
@@ -1 +1 @@
|
||||
6168bc755ea17aececa535e8b94e6c798e5e855bfc47be19220d5cbc08483332
|
||||
030a2a502e95e51290bb1d76795013b72b25521a572c3942a232b9395e544250
|
||||
@@ -1,112 +0,0 @@
|
||||
"""
|
||||
Copyright (c) 2021-, rav4kumar, Haibin Wen, sunnypilot, and a number of other contributors.
|
||||
|
||||
This file is part of sunnypilot and is licensed under the MIT License.
|
||||
See the LICENSE.md file in the root directory for more details.
|
||||
"""
|
||||
|
||||
from cereal import custom
|
||||
import numpy as np
|
||||
from openpilot.common.realtime import DT_MDL
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.common.swaglog import cloudlog
|
||||
|
||||
AccelPersonality = custom.LongitudinalPlanSP.AccelerationPersonality
|
||||
|
||||
# Acceleration Profiles
|
||||
MAX_ACCEL_PROFILES = {
|
||||
AccelPersonality.eco: [2.0, 1.99, 1.88, 1.10, 0.500, 0.292, 0.15, 0.10],
|
||||
AccelPersonality.normal: [1.0, 2.00, 1.94, 1.22, 0.635, 0.33, 0.22, 0.16],
|
||||
AccelPersonality.sport: [.5, 2.00, 2.00, 1.85, 0.800, 0.54, 0.32, 0.22],
|
||||
}
|
||||
MAX_ACCEL_BREAKPOINTS = [0., 4., 6., 9., 16., 25., 30., 55.]
|
||||
# Braking Profiles
|
||||
MIN_ACCEL_PROFILES = {
|
||||
AccelPersonality.eco: [-0.14, -0.0006, -0.010, -0.30, -1.20],
|
||||
AccelPersonality.normal: [-0.1, -0.0007, -0.012, -0.35, -1.20],
|
||||
AccelPersonality.sport: [-0.6, -0.0008, -0.014, -0.40, -1.20],
|
||||
}
|
||||
MIN_ACCEL_BREAKPOINTS = [0., 3., 11., 14., 50.]
|
||||
|
||||
|
||||
class AccelPersonalityController:
|
||||
|
||||
def __init__(self):
|
||||
self.params = Params()
|
||||
self.frame = 0
|
||||
self.accel_personality = AccelPersonality.normal
|
||||
self.param_keys = {
|
||||
'personality': 'AccelPersonality',
|
||||
'enabled': 'AccelPersonalityEnabled'
|
||||
}
|
||||
self._load_personality_from_params()
|
||||
|
||||
def _load_personality_from_params(self):
|
||||
try:
|
||||
saved = self.params.get(self.param_keys['personality'])
|
||||
if saved is not None:
|
||||
personality_value = int(saved)
|
||||
if personality_value in [AccelPersonality.eco, AccelPersonality.normal, AccelPersonality.sport]:
|
||||
self.accel_personality = personality_value
|
||||
else:
|
||||
cloudlog.warning(f"Invalid personality value {personality_value}, using normal")
|
||||
self.accel_personality = AccelPersonality.normal
|
||||
except (ValueError, TypeError) as e:
|
||||
cloudlog.warning(f"Failed to load personality from params: {e}")
|
||||
self.accel_personality = AccelPersonality.normal
|
||||
|
||||
def _update_from_params(self):
|
||||
if self.frame % int(1. / DT_MDL) != 0:
|
||||
return
|
||||
self._load_personality_from_params()
|
||||
|
||||
def get_accel_personality(self) -> int:
|
||||
self._update_from_params()
|
||||
return int(self.accel_personality)
|
||||
|
||||
def set_accel_personality(self, personality: int):
|
||||
if personality not in [AccelPersonality.eco, AccelPersonality.normal, AccelPersonality.sport]:
|
||||
cloudlog.error(f"Invalid personality {personality}, ignoring")
|
||||
return
|
||||
|
||||
self.accel_personality = personality
|
||||
self.params.put(self.param_keys['personality'], str(personality))
|
||||
cloudlog.info(f"Accel personality set to {personality}")
|
||||
|
||||
def cycle_accel_personality(self) -> int:
|
||||
personalities = [AccelPersonality.eco, AccelPersonality.normal, AccelPersonality.sport]
|
||||
current_idx = personalities.index(self.accel_personality)
|
||||
next_personality = personalities[(current_idx + 1) % len(personalities)]
|
||||
self.set_accel_personality(next_personality)
|
||||
return int(next_personality)
|
||||
|
||||
def get_accel_limits(self, v_ego: float) -> tuple[float, float]:
|
||||
max_a = np.interp(v_ego, MAX_ACCEL_BREAKPOINTS, MAX_ACCEL_PROFILES[self.accel_personality])
|
||||
min_a = np.interp(v_ego, MIN_ACCEL_BREAKPOINTS, MIN_ACCEL_PROFILES[self.accel_personality])
|
||||
return float(min_a), float(max_a)
|
||||
|
||||
def get_min_accel(self, v_ego: float) -> float:
|
||||
return self.get_accel_limits(v_ego)[0]
|
||||
|
||||
def get_max_accel(self, v_ego: float) -> float:
|
||||
return self.get_accel_limits(v_ego)[1]
|
||||
|
||||
def is_enabled(self) -> bool:
|
||||
return bool(self.params.get_bool(self.param_keys['enabled']))
|
||||
|
||||
def set_enabled(self, enabled: bool):
|
||||
self.params.put_bool(self.param_keys['enabled'], enabled)
|
||||
cloudlog.info(f"Accel personality controller {'enabled' if enabled else 'disabled'}")
|
||||
|
||||
def toggle_enabled(self) -> bool:
|
||||
current = self.is_enabled()
|
||||
self.set_enabled(not current)
|
||||
return not current
|
||||
|
||||
def reset(self):
|
||||
self.accel_personality = AccelPersonality.normal
|
||||
self.frame = 0
|
||||
|
||||
def update(self):
|
||||
self.frame += 1
|
||||
self._update_from_params()
|
||||
@@ -1,286 +0,0 @@
|
||||
"""
|
||||
Copyright (c) 2021-, rav4kumar, Haibin Wen, sunnypilot, and a number of other contributors.
|
||||
|
||||
This file is part of sunnypilot and is licensed under the MIT License.
|
||||
See the LICENSE.md file in the root directory for more details.
|
||||
"""
|
||||
|
||||
import pytest
|
||||
import numpy as np
|
||||
from cereal import custom
|
||||
from sunnypilot.selfdrive.controls.lib.accel_personality.accel_controller import (
|
||||
AccelPersonalityController,
|
||||
MAX_ACCEL_PROFILES,
|
||||
MIN_ACCEL_PROFILES,
|
||||
MAX_ACCEL_BREAKPOINTS,
|
||||
MIN_ACCEL_BREAKPOINTS,
|
||||
)
|
||||
|
||||
AccelPersonality = custom.LongitudinalPlanSP.AccelerationPersonality
|
||||
|
||||
|
||||
class TestAccelPersonalityController:
|
||||
|
||||
@pytest.fixture
|
||||
def mock_params(self, mocker):
|
||||
params = mocker.Mock()
|
||||
params.get = mocker.Mock(return_value=None)
|
||||
params.get_bool = mocker.Mock(return_value=False)
|
||||
params.put = mocker.Mock()
|
||||
params.put_bool = mocker.Mock()
|
||||
return params
|
||||
|
||||
@pytest.fixture
|
||||
def controller(self, mock_params, mocker):
|
||||
mocker.patch('sunnypilot.selfdrive.controls.lib.accel_personality.accel_controller.Params', return_value=mock_params)
|
||||
ctrl = AccelPersonalityController()
|
||||
ctrl.params = mock_params
|
||||
return ctrl
|
||||
|
||||
def test_initialization_defaults(self, controller):
|
||||
assert controller.frame == 0
|
||||
assert controller.accel_personality == AccelPersonality.normal
|
||||
assert controller.param_keys == {
|
||||
'personality': 'AccelPersonality',
|
||||
'enabled': 'AccelPersonalityEnabled'
|
||||
}
|
||||
|
||||
@pytest.mark.parametrize("personality,expected", [
|
||||
(AccelPersonality.eco, AccelPersonality.eco),
|
||||
(AccelPersonality.normal, AccelPersonality.normal),
|
||||
(AccelPersonality.sport, AccelPersonality.sport),
|
||||
])
|
||||
def test_load_personality_valid(self, mocker, personality, expected):
|
||||
mock_params = mocker.Mock()
|
||||
mock_params.get = mocker.Mock(return_value=str(personality).encode())
|
||||
mock_params.get_bool = mocker.Mock(return_value=False)
|
||||
mocker.patch('sunnypilot.selfdrive.controls.lib.accel_personality.accel_controller.Params', return_value=mock_params)
|
||||
controller = AccelPersonalityController()
|
||||
assert controller.accel_personality == expected
|
||||
|
||||
def test_load_personality_invalid_value(self, mocker):
|
||||
mock_params = mocker.Mock()
|
||||
mock_params.get = mocker.Mock(return_value=b'999')
|
||||
mock_params.get_bool = mocker.Mock(return_value=False)
|
||||
mocker.patch('sunnypilot.selfdrive.controls.lib.accel_personality.accel_controller.Params', return_value=mock_params)
|
||||
controller = AccelPersonalityController()
|
||||
assert controller.accel_personality == AccelPersonality.normal
|
||||
|
||||
def test_load_personality_parse_error(self, mocker):
|
||||
mock_params = mocker.Mock()
|
||||
mock_params.get = mocker.Mock(return_value=b'invalid_data')
|
||||
mock_params.get_bool = mocker.Mock(return_value=False)
|
||||
mocker.patch('sunnypilot.selfdrive.controls.lib.accel_personality.accel_controller.Params', return_value=mock_params)
|
||||
controller = AccelPersonalityController()
|
||||
assert controller.accel_personality == AccelPersonality.normal
|
||||
|
||||
def test_load_personality_none(self, mocker):
|
||||
mock_params = mocker.Mock()
|
||||
mock_params.get = mocker.Mock(return_value=None)
|
||||
mock_params.get_bool = mocker.Mock(return_value=False)
|
||||
mocker.patch('sunnypilot.selfdrive.controls.lib.accel_personality.accel_controller.Params', return_value=mock_params)
|
||||
controller = AccelPersonalityController()
|
||||
assert controller.accel_personality == AccelPersonality.normal
|
||||
|
||||
def test_get_accel_personality(self, controller):
|
||||
controller.accel_personality = AccelPersonality.sport
|
||||
result = controller.get_accel_personality()
|
||||
assert result == AccelPersonality.sport
|
||||
assert isinstance(result, int)
|
||||
|
||||
@pytest.mark.parametrize("personality", [
|
||||
AccelPersonality.eco,
|
||||
AccelPersonality.normal,
|
||||
AccelPersonality.sport,
|
||||
])
|
||||
def test_set_accel_personality_valid(self, controller, mock_params, personality):
|
||||
controller.set_accel_personality(personality)
|
||||
assert controller.accel_personality == personality
|
||||
mock_params.put.assert_called_once_with('AccelPersonality', str(personality))
|
||||
|
||||
def test_set_accel_personality_invalid(self, controller, mock_params):
|
||||
original = controller.accel_personality
|
||||
controller.set_accel_personality(999)
|
||||
assert controller.accel_personality == original
|
||||
mock_params.put.assert_not_called()
|
||||
|
||||
def test_cycle_accel_personality_full_cycle(self, controller):
|
||||
controller.accel_personality = AccelPersonality.eco
|
||||
|
||||
result = controller.cycle_accel_personality()
|
||||
assert result == AccelPersonality.normal
|
||||
assert controller.accel_personality == AccelPersonality.normal
|
||||
|
||||
result = controller.cycle_accel_personality()
|
||||
assert result == AccelPersonality.sport
|
||||
assert controller.accel_personality == AccelPersonality.sport
|
||||
|
||||
result = controller.cycle_accel_personality()
|
||||
assert result == AccelPersonality.eco
|
||||
assert controller.accel_personality == AccelPersonality.eco
|
||||
|
||||
def test_cycle_accel_personality_return_type(self, controller):
|
||||
result = controller.cycle_accel_personality()
|
||||
assert isinstance(result, int)
|
||||
|
||||
@pytest.mark.parametrize("personality", [
|
||||
AccelPersonality.eco,
|
||||
AccelPersonality.normal,
|
||||
AccelPersonality.sport,
|
||||
])
|
||||
def test_get_accel_limits_at_zero_speed(self, controller, personality):
|
||||
controller.accel_personality = personality
|
||||
min_a, max_a = controller.get_accel_limits(0.0)
|
||||
|
||||
expected_max = MAX_ACCEL_PROFILES[personality][0]
|
||||
expected_min = MIN_ACCEL_PROFILES[personality][0]
|
||||
|
||||
assert abs(max_a - expected_max) < 1e-6
|
||||
assert abs(min_a - expected_min) < 1e-6
|
||||
|
||||
@pytest.mark.parametrize("v_ego,personality", [
|
||||
(0.0, AccelPersonality.eco),
|
||||
(10.0, AccelPersonality.normal),
|
||||
(25.0, AccelPersonality.sport),
|
||||
(50.0, AccelPersonality.eco),
|
||||
(4.0, AccelPersonality.normal),
|
||||
(30.0, AccelPersonality.sport),
|
||||
])
|
||||
def test_get_accel_limits_interpolation(self, controller, v_ego, personality):
|
||||
controller.accel_personality = personality
|
||||
min_a, max_a = controller.get_accel_limits(v_ego)
|
||||
|
||||
expected_max = np.interp(v_ego, MAX_ACCEL_BREAKPOINTS, MAX_ACCEL_PROFILES[personality])
|
||||
expected_min = np.interp(v_ego, MIN_ACCEL_BREAKPOINTS, MIN_ACCEL_PROFILES[personality])
|
||||
|
||||
assert abs(max_a - expected_max) < 1e-6
|
||||
assert abs(min_a - expected_min) < 1e-6
|
||||
|
||||
def test_get_accel_limits_return_types(self, controller):
|
||||
min_a, max_a = controller.get_accel_limits(10.0)
|
||||
assert isinstance(min_a, float)
|
||||
assert isinstance(max_a, float)
|
||||
|
||||
def test_get_min_accel(self, controller):
|
||||
controller.accel_personality = AccelPersonality.sport
|
||||
v_ego = 15.0
|
||||
min_a = controller.get_min_accel(v_ego)
|
||||
expected = controller.get_accel_limits(v_ego)[0]
|
||||
assert min_a == expected
|
||||
assert isinstance(min_a, float)
|
||||
|
||||
def test_get_max_accel(self, controller):
|
||||
controller.accel_personality = AccelPersonality.eco
|
||||
v_ego = 20.0
|
||||
max_a = controller.get_max_accel(v_ego)
|
||||
expected = controller.get_accel_limits(v_ego)[1]
|
||||
assert max_a == expected
|
||||
assert isinstance(max_a, float)
|
||||
|
||||
def test_is_enabled_true(self, controller, mock_params):
|
||||
mock_params.get_bool.return_value = True
|
||||
assert controller.is_enabled() is True
|
||||
|
||||
def test_is_enabled_false(self, controller, mock_params):
|
||||
mock_params.get_bool.return_value = False
|
||||
assert controller.is_enabled() is False
|
||||
|
||||
def test_is_enabled_calls_params(self, controller, mock_params):
|
||||
controller.is_enabled()
|
||||
mock_params.get_bool.assert_called_once_with('AccelPersonalityEnabled')
|
||||
|
||||
@pytest.mark.parametrize("enabled", [True, False])
|
||||
def test_set_enabled(self, controller, mock_params, enabled):
|
||||
controller.set_enabled(enabled)
|
||||
mock_params.put_bool.assert_called_once_with('AccelPersonalityEnabled', enabled)
|
||||
|
||||
def test_toggle_enabled_from_false(self, controller, mock_params):
|
||||
mock_params.get_bool.return_value = False
|
||||
result = controller.toggle_enabled()
|
||||
assert result is True
|
||||
mock_params.put_bool.assert_called_once_with('AccelPersonalityEnabled', True)
|
||||
|
||||
def test_toggle_enabled_from_true(self, controller, mock_params):
|
||||
mock_params.get_bool.return_value = True
|
||||
result = controller.toggle_enabled()
|
||||
assert result is False
|
||||
mock_params.put_bool.assert_called_once_with('AccelPersonalityEnabled', False)
|
||||
|
||||
def test_reset(self, controller):
|
||||
controller.accel_personality = AccelPersonality.sport
|
||||
controller.frame = 100
|
||||
controller.reset()
|
||||
assert controller.accel_personality == AccelPersonality.normal
|
||||
assert controller.frame == 0
|
||||
|
||||
def test_update_increments_frame(self, controller):
|
||||
initial_frame = controller.frame
|
||||
controller.update()
|
||||
assert controller.frame == initial_frame + 1
|
||||
|
||||
def test_update_multiple_calls(self, controller):
|
||||
for i in range(1, 11):
|
||||
controller.update()
|
||||
assert controller.frame == i
|
||||
|
||||
@pytest.mark.parametrize("v_ego", [0, 5, 10, 15, 20, 25, 30, 40, 50, 55])
|
||||
@pytest.mark.parametrize("personality", [
|
||||
AccelPersonality.eco,
|
||||
AccelPersonality.normal,
|
||||
AccelPersonality.sport,
|
||||
])
|
||||
def test_accel_limits_physical_constraints(self, controller, v_ego, personality):
|
||||
controller.accel_personality = personality
|
||||
min_a, max_a = controller.get_accel_limits(v_ego)
|
||||
assert min_a < 0
|
||||
assert max_a > 0
|
||||
assert min_a < max_a
|
||||
|
||||
def test_max_accel_decreases_with_speed(self, controller):
|
||||
test_speeds = [0, 10, 20, 30, 40, 50]
|
||||
for personality in [AccelPersonality.eco, AccelPersonality.normal, AccelPersonality.sport]:
|
||||
controller.accel_personality = personality
|
||||
max_accels = [controller.get_max_accel(v) for v in test_speeds]
|
||||
assert max_accels[-1] < max_accels[0]
|
||||
|
||||
@pytest.mark.parametrize("v_ego", [5, 10, 15, 20, 25])
|
||||
def test_acceleration_personality_ordering(self, controller, v_ego):
|
||||
controller.accel_personality = AccelPersonality.eco
|
||||
_, eco_max = controller.get_accel_limits(v_ego)
|
||||
|
||||
controller.accel_personality = AccelPersonality.normal
|
||||
_, normal_max = controller.get_accel_limits(v_ego)
|
||||
|
||||
controller.accel_personality = AccelPersonality.sport
|
||||
_, sport_max = controller.get_accel_limits(v_ego)
|
||||
|
||||
assert sport_max >= normal_max
|
||||
assert normal_max >= eco_max
|
||||
|
||||
@pytest.mark.parametrize("v_ego", [5, 10, 15, 20])
|
||||
def test_braking_personality_ordering(self, controller, v_ego):
|
||||
controller.accel_personality = AccelPersonality.eco
|
||||
eco_min, _ = controller.get_accel_limits(v_ego)
|
||||
|
||||
controller.accel_personality = AccelPersonality.sport
|
||||
sport_min, _ = controller.get_accel_limits(v_ego)
|
||||
|
||||
assert sport_min <= eco_min
|
||||
|
||||
def test_accel_limits_at_max_speed(self, controller):
|
||||
max_speed = MAX_ACCEL_BREAKPOINTS[-1]
|
||||
min_a, max_a = controller.get_accel_limits(max_speed)
|
||||
assert isinstance(min_a, float)
|
||||
assert isinstance(max_a, float)
|
||||
|
||||
def test_accel_limits_beyond_max_speed(self, controller):
|
||||
beyond_max = MAX_ACCEL_BREAKPOINTS[-1] + 10
|
||||
min_a, max_a = controller.get_accel_limits(beyond_max)
|
||||
assert isinstance(min_a, float)
|
||||
assert isinstance(max_a, float)
|
||||
|
||||
def test_accel_limits_very_low_speed(self, controller):
|
||||
min_a, max_a = controller.get_accel_limits(0.5)
|
||||
assert isinstance(min_a, float)
|
||||
assert isinstance(max_a, float)
|
||||
assert min_a >= -2.0
|
||||
@@ -15,8 +15,9 @@ LAT_PLAN_MIN_IDX = 5
|
||||
LATERAL_LAG_MOD = 0.0 # seconds, modifies how far in the future we look ahead for the lateral plan
|
||||
|
||||
# from selfdrive/controls/lib/latcontrol_torque.py
|
||||
KP = 0.8
|
||||
KI = 0.15
|
||||
KP = 1.0
|
||||
KI = 0.3
|
||||
KD = 0.0
|
||||
INTERP_SPEEDS = [1, 1.5, 2.0, 3.0, 5, 7.5, 10, 15, 30]
|
||||
KP_INTERP = [250, 120, 65, 30, 11.5, 5.5, 3.5, 2.0, KP]
|
||||
|
||||
@@ -63,7 +64,7 @@ class LatControlTorqueExtBase:
|
||||
self.torque_from_lateral_accel_in_torque_space = CI.torque_from_lateral_accel_in_torque_space()
|
||||
|
||||
self._ff = 0.0
|
||||
self._pid = PIDController([INTERP_SPEEDS, KP_INTERP], KI)
|
||||
self._pid = PIDController([INTERP_SPEEDS, KP_INTERP], KI, KD)
|
||||
self._pid_log = None
|
||||
self._setpoint = 0.0
|
||||
self._measurement = 0.0
|
||||
|
||||
@@ -17,7 +17,6 @@ from openpilot.sunnypilot.selfdrive.controls.lib.speed_limit.speed_limit_resolve
|
||||
from openpilot.sunnypilot.selfdrive.selfdrived.events import EventsSP
|
||||
from openpilot.sunnypilot.models.helpers import get_active_bundle
|
||||
|
||||
from openpilot.sunnypilot.selfdrive.controls.lib.accel_personality.accel_controller import AccelPersonalityController
|
||||
DecState = custom.LongitudinalPlanSP.DynamicExperimentalControl.DynamicExperimentalControlState
|
||||
LongitudinalPlanSource = custom.LongitudinalPlanSP.LongitudinalPlanSource
|
||||
|
||||
@@ -27,7 +26,6 @@ class LongitudinalPlannerSP:
|
||||
self.events_sp = EventsSP()
|
||||
self.resolver = SpeedLimitResolver()
|
||||
self.dec = DynamicExperimentalController(CP, mpc)
|
||||
self.accel_controller = AccelPersonalityController()
|
||||
self.scc = SmartCruiseControl()
|
||||
self.resolver = SpeedLimitResolver()
|
||||
self.sla = SpeedLimitAssist(CP, CP_SP)
|
||||
@@ -83,7 +81,6 @@ class LongitudinalPlannerSP:
|
||||
self.events_sp.clear()
|
||||
self.dec.update(sm)
|
||||
self.e2e_alerts_helper.update(sm, self.events_sp)
|
||||
self.accel_controller.update()
|
||||
|
||||
def publish_longitudinal_plan_sp(self, sm: messaging.SubMaster, pm: messaging.PubMaster) -> None:
|
||||
plan_sp_send = messaging.new_message('longitudinalPlanSP')
|
||||
|
||||
@@ -2,10 +2,9 @@ import json
|
||||
import os
|
||||
import random
|
||||
import time
|
||||
import jwt
|
||||
from typing import cast
|
||||
from datetime import datetime, timedelta, UTC
|
||||
from datetime import datetime, timedelta
|
||||
|
||||
import jwt
|
||||
from openpilot.common.api.base import BaseApi
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.system.hardware import HARDWARE
|
||||
@@ -93,8 +92,7 @@ class SunnylinkApi(BaseApi):
|
||||
|
||||
backoff = 1
|
||||
while True:
|
||||
register_token = jwt.encode({'register': True, 'exp': datetime.now(UTC).replace(tzinfo=None) + timedelta(hours=1)},
|
||||
cast(str, private_key), algorithm=jwt_algo)
|
||||
register_token = jwt.encode({'register': True, 'exp': datetime.utcnow() + timedelta(hours=1)}, private_key, algorithm=jwt_algo)
|
||||
try:
|
||||
if verbose or time.monotonic() - start_time < timeout / 2:
|
||||
self._status_update("Registering device to sunnylink...")
|
||||
|
||||
@@ -1,26 +1,4 @@
|
||||
{
|
||||
"AccelPersonality": {
|
||||
"title": "Acceleration Personality",
|
||||
"description": "",
|
||||
"options": [
|
||||
{
|
||||
"value": 0,
|
||||
"label": "Sport"
|
||||
},
|
||||
{
|
||||
"value": 1,
|
||||
"label": "Normal"
|
||||
},
|
||||
{
|
||||
"value": 2,
|
||||
"label": "Eco"
|
||||
}
|
||||
]
|
||||
},
|
||||
"AccelPersonalityEnabled": {
|
||||
"title": "Enable Acceleration Personality",
|
||||
"description": "Controls acceleration behavior: Eco (efficient), Normal (balanced), Sport (responsive)."
|
||||
},
|
||||
"AccessToken": {
|
||||
"title": "AccessTokenIsNice",
|
||||
"description": ""
|
||||
@@ -280,11 +258,11 @@
|
||||
"description": ""
|
||||
},
|
||||
"EnableCopyparty": {
|
||||
"title": "copyparty Service",
|
||||
"title": "Enable Copyparty",
|
||||
"description": ""
|
||||
},
|
||||
"EnableGithubRunner": {
|
||||
"title": "GitHub Runner Service",
|
||||
"title": "Enable GitHub Runner",
|
||||
"description": ""
|
||||
},
|
||||
"EnableSunnylinkUploader": {
|
||||
@@ -480,10 +458,6 @@
|
||||
"title": "Language",
|
||||
"description": ""
|
||||
},
|
||||
"LastAgnosPowerMonitorShutdown": {
|
||||
"title": "Last AGNOS Power Monitor Shutdown",
|
||||
"description": ""
|
||||
},
|
||||
"LastAthenaPingTime": {
|
||||
"title": "Last Athena Ping Time",
|
||||
"description": ""
|
||||
|
||||
@@ -17,7 +17,7 @@ from cereal.messaging import SubMaster
|
||||
from openpilot.system.hardware.hw import Paths
|
||||
from openpilot.common.swaglog import cloudlog
|
||||
from openpilot.system.hardware import HARDWARE
|
||||
from openpilot.common.utils import atomic_write
|
||||
from openpilot.common.utils import atomic_write_in_dir
|
||||
from openpilot.system.version import get_build_metadata
|
||||
from openpilot.system.loggerd.config import STATS_DIR_FILE_LIMIT, STATS_SOCKET, STATS_FLUSH_TIME_S
|
||||
from openpilot.system.statsd import METRIC_TYPE, StatLogSP
|
||||
@@ -242,7 +242,7 @@ def stats_main(end_event):
|
||||
if len(os.listdir(STATS_DIR)) < STATS_DIR_FILE_LIMIT:
|
||||
if len(result) > 0:
|
||||
stats_path = os.path.join(STATS_DIR, f"{boot_uid}_{idx}")
|
||||
with atomic_write(stats_path) as f:
|
||||
with atomic_write_in_dir(stats_path) as f:
|
||||
f.write(result)
|
||||
idx += 1
|
||||
else:
|
||||
|
||||
@@ -8,13 +8,11 @@ from enum import IntEnum
|
||||
import threading
|
||||
import time
|
||||
import json
|
||||
import pyray as rl
|
||||
|
||||
from cereal import messaging
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.common.swaglog import cloudlog
|
||||
from openpilot.sunnypilot.sunnylink.api import UNREGISTERED_SUNNYLINK_DONGLE_ID, SunnylinkApi
|
||||
from openpilot.system.ui.sunnypilot.lib.styles import style
|
||||
|
||||
|
||||
class RoleType(IntEnum):
|
||||
@@ -203,19 +201,5 @@ class SunnylinkState:
|
||||
network_type = self._sm["deviceState"].networkType
|
||||
return bool(network_type != 0)
|
||||
|
||||
def get_sponsor_tier_color(self) -> rl.Color:
|
||||
tier = self.get_sponsor_tier()
|
||||
|
||||
if tier == SponsorTier.GUARDIAN:
|
||||
return rl.Color(255, 215, 0, 255)
|
||||
elif tier == SponsorTier.BENEFACTOR:
|
||||
return rl.Color(60, 179, 113, 255)
|
||||
elif tier == SponsorTier.CONTRIBUTOR:
|
||||
return rl.Color(70, 130, 180, 255)
|
||||
elif tier == SponsorTier.SUPPORTER:
|
||||
return rl.Color(147, 112, 219, 255)
|
||||
else:
|
||||
return style.ITEM_TEXT_VALUE_COLOR
|
||||
|
||||
def __del__(self):
|
||||
self.stop()
|
||||
|
||||
@@ -31,7 +31,7 @@ from websocket import (ABNF, WebSocket, WebSocketException, WebSocketTimeoutExce
|
||||
import cereal.messaging as messaging
|
||||
from cereal import log
|
||||
from cereal.services import SERVICE_LIST
|
||||
from openpilot.common.api import Api, get_key_pair
|
||||
from openpilot.common.api import Api
|
||||
from openpilot.common.utils import CallbackReader, get_upload_stream
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.common.realtime import set_core_affinity
|
||||
@@ -554,8 +554,11 @@ def start_local_proxy_shim(global_end_event: threading.Event, local_port: int, w
|
||||
|
||||
@dispatcher.add_method
|
||||
def getPublicKey() -> str | None:
|
||||
_, _, public_key = get_key_pair()
|
||||
return public_key
|
||||
if not os.path.isfile(Paths.persist_root() + '/comma/id_rsa.pub'):
|
||||
return None
|
||||
|
||||
with open(Paths.persist_root() + '/comma/id_rsa.pub') as f:
|
||||
return f.read()
|
||||
|
||||
|
||||
@dispatcher.add_method
|
||||
|
||||
@@ -2,7 +2,6 @@
|
||||
import time
|
||||
import json
|
||||
import jwt
|
||||
from typing import cast
|
||||
from pathlib import Path
|
||||
|
||||
from datetime import datetime, timedelta, UTC
|
||||
@@ -70,9 +69,7 @@ def register(show_spinner=False) -> str | None:
|
||||
start_time = time.monotonic()
|
||||
while True:
|
||||
try:
|
||||
register_token = jwt.encode({'register': True, 'exp': datetime.now(UTC).replace(tzinfo=None) + timedelta(hours=1)},
|
||||
cast(str, private_key), algorithm=jwt_algo)
|
||||
cloudlog.info("getting pilotauth")
|
||||
register_token = jwt.encode({'register': True, 'exp': datetime.now(UTC).replace(tzinfo=None) + timedelta(hours=1)}, private_key, algorithm=jwt_algo)
|
||||
cloudlog.info("getting pilotauth")
|
||||
resp = api_get("v2/pilotauth/", method='POST', timeout=15,
|
||||
imei=imei1, imei2=imei2, serial=serial, public_key=public_key, register_token=register_token)
|
||||
|
||||
@@ -1004,8 +1004,8 @@ bool SpectraCamera::openSensor() {
|
||||
};
|
||||
|
||||
// Figure out which sensor we have
|
||||
if (!init_sensor_lambda(new OS04C10) &&
|
||||
!init_sensor_lambda(new OX03C10)) {
|
||||
if (!init_sensor_lambda(new OX03C10) &&
|
||||
!init_sensor_lambda(new OS04C10)) {
|
||||
LOGE("** sensor %d FAILED bringup, disabling", cc.camera_num);
|
||||
enabled = false;
|
||||
return false;
|
||||
|
||||
@@ -1,7 +1,6 @@
|
||||
#include <cmath>
|
||||
|
||||
#include "system/camerad/sensors/sensor.h"
|
||||
#include "third_party/linux/include/msm_camsensor_sdk.h"
|
||||
|
||||
namespace {
|
||||
|
||||
@@ -52,7 +51,7 @@ OS04C10::OS04C10() {
|
||||
probe_expected_data = 0x5304;
|
||||
bits_per_pixel = 12;
|
||||
mipi_format = CAM_FORMAT_MIPI_RAW_12;
|
||||
frame_data_type = CSI_RAW12;
|
||||
frame_data_type = 0x2c;
|
||||
mclk_frequency = 24000000; // Hz
|
||||
|
||||
// TODO: this was set from logs. actually calculate it out
|
||||
|
||||
@@ -4,10 +4,10 @@ const struct i2c_random_wr_payload start_reg_array_os04c10[] = {{0x100, 1}};
|
||||
const struct i2c_random_wr_payload stop_reg_array_os04c10[] = {{0x100, 0}};
|
||||
|
||||
const struct i2c_random_wr_payload init_array_os04c10[] = {
|
||||
// baseed on DP_2688X1520_NEWSTG_MIPI0776Mbps_30FPS_10BIT_FOURLANE
|
||||
{0x0103, 0x01}, // software reset
|
||||
// DP_2688X1520_NEWSTG_MIPI0776Mbps_30FPS_10BIT_FOURLANE
|
||||
{0x0103, 0x01},
|
||||
|
||||
// PLL + clocks
|
||||
// PLL
|
||||
{0x0301, 0xe4},
|
||||
{0x0303, 0x01},
|
||||
{0x0305, 0xb6},
|
||||
@@ -24,7 +24,7 @@ const struct i2c_random_wr_payload init_array_os04c10[] = {
|
||||
{0x3106, 0x21},
|
||||
{0x3107, 0xa1},
|
||||
|
||||
// Analog/timing fine-tuning block
|
||||
// ?
|
||||
{0x3624, 0x00},
|
||||
{0x3625, 0x4c},
|
||||
{0x3660, 0x04},
|
||||
@@ -101,7 +101,7 @@ const struct i2c_random_wr_payload init_array_os04c10[] = {
|
||||
{0x3f00, 0x0b},
|
||||
{0x3f06, 0x04},
|
||||
|
||||
// BLC - black level correction
|
||||
// BLC
|
||||
{0x400a, 0x01},
|
||||
{0x400b, 0x50},
|
||||
{0x400e, 0x08},
|
||||
@@ -157,7 +157,7 @@ const struct i2c_random_wr_payload init_array_os04c10[] = {
|
||||
{0x5180, 0x70},
|
||||
{0x5181, 0x10},
|
||||
|
||||
// DPC - defective pixel correction
|
||||
// DPC
|
||||
{0x520a, 0x03},
|
||||
{0x520b, 0x06},
|
||||
{0x520c, 0x0c},
|
||||
@@ -248,7 +248,7 @@ const struct i2c_random_wr_payload init_array_os04c10[] = {
|
||||
{0x4008, 0x01},
|
||||
{0x4009, 0x06},
|
||||
|
||||
// FSIN - frame sync
|
||||
// FSIN
|
||||
{0x3002, 0x22},
|
||||
{0x3663, 0x22},
|
||||
{0x368a, 0x04},
|
||||
@@ -276,8 +276,8 @@ const struct i2c_random_wr_payload init_array_os04c10[] = {
|
||||
{0x3816, 0x03},
|
||||
{0x3817, 0x01},
|
||||
|
||||
{0x380c, 0x0b}, {0x380d, 0xac}, // HTS (line length)
|
||||
{0x380e, 0x06}, {0x380f, 0x9c}, // VTS (frame length)
|
||||
{0x380c, 0x0b}, {0x380d, 0xac}, // HTS
|
||||
{0x380e, 0x06}, {0x380f, 0x9c}, // VTS
|
||||
|
||||
{0x3820, 0xb3},
|
||||
{0x3821, 0x01},
|
||||
@@ -309,17 +309,17 @@ const struct i2c_random_wr_payload init_array_os04c10[] = {
|
||||
// initialize exposure
|
||||
{0x3503, 0x88},
|
||||
|
||||
// long exposure
|
||||
// long
|
||||
{0x3500, 0x00}, {0x3501, 0x00}, {0x3502, 0x10},
|
||||
{0x3508, 0x00}, {0x3509, 0x80},
|
||||
{0x350a, 0x04}, {0x350b, 0x00},
|
||||
|
||||
// short exposure
|
||||
// short
|
||||
{0x3510, 0x00}, {0x3511, 0x00}, {0x3512, 0x40},
|
||||
{0x350c, 0x00}, {0x350d, 0x80},
|
||||
{0x350e, 0x04}, {0x350f, 0x00},
|
||||
|
||||
// white balance
|
||||
// wb
|
||||
// b
|
||||
{0x5100, 0x06}, {0x5101, 0x7e},
|
||||
{0x5140, 0x06}, {0x5141, 0x7e},
|
||||
@@ -332,7 +332,7 @@ const struct i2c_random_wr_payload init_array_os04c10[] = {
|
||||
};
|
||||
|
||||
const struct i2c_random_wr_payload ife_downscale_override_array_os04c10[] = {
|
||||
// based on OS04C10_AA_00_02_17_wAO_2688x1524_MIPI728Mbps_Linear12bit_20FPS_4Lane_MCLK24MHz
|
||||
// OS04C10_AA_00_02_17_wAO_2688x1524_MIPI728Mbps_Linear12bit_20FPS_4Lane_MCLK24MHz
|
||||
{0x3c8c, 0x40},
|
||||
{0x3714, 0x24},
|
||||
{0x37c2, 0x04},
|
||||
|
||||
@@ -1,7 +1,6 @@
|
||||
#include <cmath>
|
||||
|
||||
#include "system/camerad/sensors/sensor.h"
|
||||
#include "third_party/linux/include/msm_camsensor_sdk.h"
|
||||
|
||||
namespace {
|
||||
|
||||
@@ -41,8 +40,8 @@ OX03C10::OX03C10() {
|
||||
probe_expected_data = 0x5803;
|
||||
bits_per_pixel = 12;
|
||||
mipi_format = CAM_FORMAT_MIPI_RAW_12;
|
||||
frame_data_type = CSI_RAW12;
|
||||
mclk_frequency = 24000000; // Hz
|
||||
frame_data_type = 0x2c; // one is 0x2a, two are 0x2b
|
||||
mclk_frequency = 24000000; //Hz
|
||||
|
||||
readout_time_ns = 14697000;
|
||||
|
||||
|
||||
@@ -7,6 +7,7 @@
|
||||
#include <string>
|
||||
#include <algorithm> // for std::clamp
|
||||
|
||||
#include "common/params.h"
|
||||
#include "common/util.h"
|
||||
#include "system/hardware/base.h"
|
||||
|
||||
|
||||
@@ -16,7 +16,6 @@ from openpilot.common.basedir import BASEDIR
|
||||
from openpilot.common.params import Params
|
||||
from openpilot.common.timeout import Timeout
|
||||
from openpilot.system.hardware.hw import Paths
|
||||
from openpilot.system.hardware import TICI
|
||||
from openpilot.system.loggerd.xattr_cache import getxattr
|
||||
from openpilot.system.loggerd.deleter import PRESERVE_ATTR_NAME, PRESERVE_ATTR_VALUE
|
||||
from openpilot.system.manager.process_config import managed_processes
|
||||
@@ -222,16 +221,13 @@ class TestLoggerd:
|
||||
assert abs(boot.wallTimeNanos - time.time_ns()) < 5*1e9 # within 5s
|
||||
assert boot.launchLog == launch_log
|
||||
|
||||
if TICI:
|
||||
for fn in ["console-ramoops", "pmsg-ramoops-0"]:
|
||||
path = Path(os.path.join("/sys/fs/pstore/", fn))
|
||||
if path.is_file():
|
||||
with open(path, "rb") as f:
|
||||
expected_val = f.read()
|
||||
bootlog_val = [e.value for e in boot.pstore.entries if e.key == fn][0]
|
||||
assert expected_val == bootlog_val
|
||||
else:
|
||||
assert len(boot.pstore.entries) == 0
|
||||
for fn in ["console-ramoops", "pmsg-ramoops-0"]:
|
||||
path = Path(os.path.join("/sys/fs/pstore/", fn))
|
||||
if path.is_file():
|
||||
with open(path, "rb") as f:
|
||||
expected_val = f.read()
|
||||
bootlog_val = [e.value for e in boot.pstore.entries if e.key == fn][0]
|
||||
assert expected_val == bootlog_val
|
||||
|
||||
# next one should increment by one
|
||||
bl1 = re.match(RE.LOG_ID_V2, bootlog_path.name)
|
||||
|
||||
@@ -14,7 +14,7 @@ from openpilot.system.version import get_build_metadata
|
||||
MAX_CACHE_SIZE = 4e9 if "CI" in os.environ else 2e9
|
||||
CACHE_DIR = Path("/data/scons_cache" if AGNOS else "/tmp/scons_cache")
|
||||
|
||||
TOTAL_SCONS_NODES = 2705
|
||||
TOTAL_SCONS_NODES = 2280
|
||||
MAX_BUILD_PROGRESS = 100
|
||||
|
||||
def build(spinner: Spinner, dirty: bool = False, minimal: bool = False) -> None:
|
||||
|
||||
@@ -9,7 +9,6 @@ import traceback
|
||||
from cereal import log
|
||||
import cereal.messaging as messaging
|
||||
import openpilot.system.sentry as sentry
|
||||
from openpilot.common.utils import atomic_write
|
||||
from openpilot.common.params import Params, ParamKeyFlag
|
||||
from openpilot.common.text_window import TextWindow
|
||||
from openpilot.system.hardware import HARDWARE
|
||||
@@ -169,7 +168,7 @@ def manager_thread() -> None:
|
||||
# kick AGNOS power monitoring watchdog
|
||||
try:
|
||||
if sm.all_checks(['deviceState']):
|
||||
with atomic_write("/var/tmp/power_watchdog", "w", overwrite=True) as f:
|
||||
with open("/var/tmp/power_watchdog", "w") as f:
|
||||
f.write(str(time.monotonic()))
|
||||
except Exception:
|
||||
pass
|
||||
|
||||
@@ -67,7 +67,6 @@ class ManagerProcess(ABC):
|
||||
enabled = True
|
||||
name = ""
|
||||
shutting_down = False
|
||||
restart_if_crash = False
|
||||
|
||||
@abstractmethod
|
||||
def prepare(self) -> None:
|
||||
@@ -168,14 +167,13 @@ class NativeProcess(ManagerProcess):
|
||||
|
||||
|
||||
class PythonProcess(ManagerProcess):
|
||||
def __init__(self, name, module, should_run, enabled=True, sigkill=False, restart_if_crash=False):
|
||||
def __init__(self, name, module, should_run, enabled=True, sigkill=False):
|
||||
self.name = name
|
||||
self.module = module
|
||||
self.should_run = should_run
|
||||
self.enabled = enabled
|
||||
self.sigkill = sigkill
|
||||
self.launcher = launcher
|
||||
self.restart_if_crash = restart_if_crash
|
||||
|
||||
def prepare(self) -> None:
|
||||
if self.enabled:
|
||||
@@ -254,9 +252,6 @@ def ensure_running(procs: ValuesView[ManagerProcess], started: bool, params=None
|
||||
running = []
|
||||
for p in procs:
|
||||
if p.enabled and p.name not in not_run and p.should_run(started, params, CP):
|
||||
if p.restart_if_crash and p.proc is not None and not p.proc.is_alive():
|
||||
cloudlog.error(f'Restarting {p.name} (exitcode {p.proc.exitcode})')
|
||||
p.restart()
|
||||
running.append(p)
|
||||
else:
|
||||
p.stop(block=False)
|
||||
|
||||
Some files were not shown because too many files have changed in this diff Show More
Reference in New Issue
Block a user