mirror of
https://github.com/dragonpilot/dragonpilot.git
synced 2026-10-14 18:24:00 +08:00
openpilot v0.9.7 release
date: 2024-06-11T01:36:39
master commit: f8cb04e4a8
This commit is contained in:
 Vehicle Researcher
@@ -0,0 +1,2 @@
|
||||
transformations
|
||||
transformations.cpp
|
||||
@@ -0,0 +1,70 @@
|
||||
|
||||
Reference Frames
|
||||
------
|
||||
Many reference frames are used throughout. This
|
||||
folder contains all helper functions needed to
|
||||
transform between them. Generally this is done
|
||||
by generating a rotation matrix and multiplying.
|
||||
|
||||
|
||||
| Name | [x, y, z] | Units | Notes |
|
||||
| :-------------: |:-------------:| :-----:| :----: |
|
||||
| Geodetic | [Latitude, Longitude, Altitude] | geodetic coordinates | Sometimes used as [lon, lat, alt], avoid this frame. |
|
||||
| ECEF | [x, y, z] | meters | We use **ITRF14 (IGS14)**, NOT NAD83. <br> This is the global Mesh3D frame. |
|
||||
| NED | [North, East, Down] | meters | Relative to earth's surface, useful for visualizing. |
|
||||
| Device | [Forward, Right, Down] | meters | This is the Mesh3D local frame. <br> Relative to camera, **not imu.** <br> 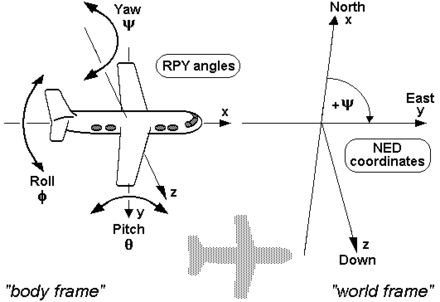|
|
||||
| Calibrated | [Forward, Right, Down] | meters | This is the frame the model outputs are in. <br> More details below. <br>|
|
||||
| Car | [Forward, Right, Down] | meters | This is useful for estimating position of points on the road. <br> More details below. <br>|
|
||||
| View | [Right, Down, Forward] | meters | Like device frame, but according to camera conventions. |
|
||||
| Camera | [u, v, focal] | pixels | Like view frame, but 2d on the camera image.|
|
||||
| Normalized Camera | [u / focal, v / focal, 1] | / | |
|
||||
| Model | [u, v, focal] | pixels | The sampled rectangle of the full camera frame the model uses. |
|
||||
| Normalized Model | [u / focal, v / focal, 1] | / | |
|
||||
|
||||
|
||||
|
||||
|
||||
Orientation Conventions
|
||||
------
|
||||
Quaternions, rotation matrices and euler angles are three
|
||||
equivalent representations of orientation and all three are
|
||||
used throughout the code base.
|
||||
|
||||
For euler angles the preferred convention is [roll, pitch, yaw]
|
||||
which corresponds to rotations around the [x, y, z] axes. All
|
||||
euler angles should always be in radians or radians/s unless
|
||||
for plotting or display purposes. For quaternions the hamilton
|
||||
notations is preferred which is [q<sub>w</sub>, q<sub>x</sub>, q<sub>y</sub>, q<sub>z</sub>]. All quaternions
|
||||
should always be normalized with a strictly positive q<sub>w</sub>. **These
|
||||
quaternions are a unique representation of orientation whereas euler angles
|
||||
or rotation matrices are not.**
|
||||
|
||||
To rotate from one frame into another with euler angles the
|
||||
convention is to rotate around roll, then pitch and then yaw,
|
||||
while rotating around the rotated axes, not the original axes.
|
||||
|
||||
|
||||
Car frame
|
||||
------
|
||||
Device frame is aligned with the road-facing camera used by openpilot. However, when controlling the vehicle it is helpful to think in a reference frame aligned with the vehicle. These two reference frames can be different.
|
||||
|
||||
The orientation of car frame is defined to be aligned with the car's direction of travel and the road plane when the vehicle is driving on a flat road and not turning. The origin of car frame is defined to be directly below device frame (in car frame), such that it is on the road plane. The position and orientation of this frame is not necessarily always aligned with the direction of travel or the road plane due to suspension movements and other effects.
|
||||
|
||||
|
||||
Calibrated frame
|
||||
------
|
||||
It is helpful for openpilot's driving model to take in images that look similar when mounted differently in different cars. To achieve this we "calibrate" the images by transforming it into calibrated frame. Calibrated frame is defined to be aligned with car frame in pitch and yaw, and aligned with device frame in roll. It also has the same origin as device frame.
|
||||
|
||||
|
||||
Example
|
||||
------
|
||||
To transform global Mesh3D positions and orientations (positions_ecef, quats_ecef) into the local frame described by the
|
||||
first position and orientation from Mesh3D one would do:
|
||||
```
|
||||
ecef_from_local = rot_from_quat(quats_ecef[0])
|
||||
local_from_ecef = ecef_from_local.T
|
||||
positions_local = np.einsum('ij,kj->ki', local_from_ecef, postions_ecef - positions_ecef[0])
|
||||
rotations_global = rot_from_quat(quats_ecef)
|
||||
rotations_local = np.einsum('ij,kjl->kil', local_from_ecef, rotations_global)
|
||||
eulers_local = euler_from_rot(rotations_local)
|
||||
```
|
||||
@@ -1,55 +1,74 @@
|
||||
import itertools
|
||||
import numpy as np
|
||||
from dataclasses import dataclass
|
||||
|
||||
import openpilot.common.transformations.orientation as orient
|
||||
|
||||
## -- hardcoded hardware params --
|
||||
eon_f_focal_length = 910.0
|
||||
eon_d_focal_length = 650.0
|
||||
tici_f_focal_length = 2648.0
|
||||
tici_e_focal_length = tici_d_focal_length = 567.0 # probably wrong? magnification is not consistent across frame
|
||||
@dataclass(frozen=True)
|
||||
class CameraConfig:
|
||||
width: int
|
||||
height: int
|
||||
focal_length: float
|
||||
|
||||
eon_f_frame_size = (1164, 874)
|
||||
eon_d_frame_size = (816, 612)
|
||||
tici_f_frame_size = tici_e_frame_size = tici_d_frame_size = (1928, 1208)
|
||||
@property
|
||||
def size(self):
|
||||
return (self.width, self.height)
|
||||
|
||||
# aka 'K' aka camera_frame_from_view_frame
|
||||
eon_fcam_intrinsics = np.array([
|
||||
[eon_f_focal_length, 0.0, float(eon_f_frame_size[0])/2],
|
||||
[0.0, eon_f_focal_length, float(eon_f_frame_size[1])/2],
|
||||
[0.0, 0.0, 1.0]])
|
||||
eon_intrinsics = eon_fcam_intrinsics # xx
|
||||
@property
|
||||
def intrinsics(self):
|
||||
# aka 'K' aka camera_frame_from_view_frame
|
||||
return np.array([
|
||||
[self.focal_length, 0.0, float(self.width)/2],
|
||||
[0.0, self.focal_length, float(self.height)/2],
|
||||
[0.0, 0.0, 1.0]
|
||||
])
|
||||
|
||||
eon_dcam_intrinsics = np.array([
|
||||
[eon_d_focal_length, 0.0, float(eon_d_frame_size[0])/2],
|
||||
[0.0, eon_d_focal_length, float(eon_d_frame_size[1])/2],
|
||||
[0.0, 0.0, 1.0]])
|
||||
@property
|
||||
def intrinsics_inv(self):
|
||||
# aka 'K_inv' aka view_frame_from_camera_frame
|
||||
return np.linalg.inv(self.intrinsics)
|
||||
|
||||
tici_fcam_intrinsics = np.array([
|
||||
[tici_f_focal_length, 0.0, float(tici_f_frame_size[0])/2],
|
||||
[0.0, tici_f_focal_length, float(tici_f_frame_size[1])/2],
|
||||
[0.0, 0.0, 1.0]])
|
||||
@dataclass(frozen=True)
|
||||
class _NoneCameraConfig(CameraConfig):
|
||||
width: int = 0
|
||||
height: int = 0
|
||||
focal_length: float = 0
|
||||
|
||||
tici_dcam_intrinsics = np.array([
|
||||
[tici_d_focal_length, 0.0, float(tici_d_frame_size[0])/2],
|
||||
[0.0, tici_d_focal_length, float(tici_d_frame_size[1])/2],
|
||||
[0.0, 0.0, 1.0]])
|
||||
@dataclass(frozen=True)
|
||||
class DeviceCameraConfig:
|
||||
fcam: CameraConfig
|
||||
dcam: CameraConfig
|
||||
ecam: CameraConfig
|
||||
|
||||
tici_ecam_intrinsics = tici_dcam_intrinsics
|
||||
def all_cams(self):
|
||||
for cam in ['fcam', 'dcam', 'ecam']:
|
||||
if not isinstance(getattr(self, cam), _NoneCameraConfig):
|
||||
yield cam, getattr(self, cam)
|
||||
|
||||
# aka 'K_inv' aka view_frame_from_camera_frame
|
||||
eon_fcam_intrinsics_inv = np.linalg.inv(eon_fcam_intrinsics)
|
||||
eon_intrinsics_inv = eon_fcam_intrinsics_inv # xx
|
||||
_ar_ox_fisheye = CameraConfig(1928, 1208, 567.0) # focal length probably wrong? magnification is not consistent across frame
|
||||
_os_fisheye = CameraConfig(2688, 1520, 567.0 / 2 * 3)
|
||||
_ar_ox_config = DeviceCameraConfig(CameraConfig(1928, 1208, 2648.0), _ar_ox_fisheye, _ar_ox_fisheye)
|
||||
_os_config = DeviceCameraConfig(CameraConfig(2688, 1520, 2648.0 * 2 / 3), _os_fisheye, _os_fisheye)
|
||||
_neo_config = DeviceCameraConfig(CameraConfig(1164, 874, 910.0), CameraConfig(816, 612, 650.0), _NoneCameraConfig())
|
||||
|
||||
tici_fcam_intrinsics_inv = np.linalg.inv(tici_fcam_intrinsics)
|
||||
tici_ecam_intrinsics_inv = np.linalg.inv(tici_ecam_intrinsics)
|
||||
DEVICE_CAMERAS = {
|
||||
# A "device camera" is defined by a device type and sensor
|
||||
|
||||
# sensor type was never set on eon/neo/two
|
||||
("neo", "unknown"): _neo_config,
|
||||
# unknown here is AR0231, field was added with OX03C10 support
|
||||
("tici", "unknown"): _ar_ox_config,
|
||||
|
||||
FULL_FRAME_SIZE = tici_f_frame_size
|
||||
FOCAL = tici_f_focal_length
|
||||
fcam_intrinsics = tici_fcam_intrinsics
|
||||
|
||||
W, H = FULL_FRAME_SIZE[0], FULL_FRAME_SIZE[1]
|
||||
# before deviceState.deviceType was set, assume tici AR config
|
||||
("unknown", "ar0231"): _ar_ox_config,
|
||||
("unknown", "ox03c10"): _ar_ox_config,
|
||||
|
||||
# simulator (emulates a tici)
|
||||
("pc", "unknown"): _ar_ox_config,
|
||||
}
|
||||
prods = itertools.product(('tici', 'tizi', 'mici'), (('ar0231', _ar_ox_config), ('ox03c10', _ar_ox_config), ('os04c10', _os_config)))
|
||||
DEVICE_CAMERAS.update({(d, c[0]): c[1] for d, c in prods})
|
||||
|
||||
# device/mesh : x->forward, y-> right, z->down
|
||||
# view : x->right, y->down, z->forward
|
||||
@@ -93,7 +112,7 @@ def roll_from_ke(m):
|
||||
-(m[0, 0] - m[0, 1] * m[2, 0] / m[2, 1]))
|
||||
|
||||
|
||||
def normalize(img_pts, intrinsics=fcam_intrinsics):
|
||||
def normalize(img_pts, intrinsics):
|
||||
# normalizes image coordinates
|
||||
# accepts single pt or array of pts
|
||||
intrinsics_inv = np.linalg.inv(intrinsics)
|
||||
@@ -106,7 +125,7 @@ def normalize(img_pts, intrinsics=fcam_intrinsics):
|
||||
return img_pts_normalized[:, :2].reshape(input_shape)
|
||||
|
||||
|
||||
def denormalize(img_pts, intrinsics=fcam_intrinsics, width=np.inf, height=np.inf):
|
||||
def denormalize(img_pts, intrinsics, width=np.inf, height=np.inf):
|
||||
# denormalizes image coordinates
|
||||
# accepts single pt or array of pts
|
||||
img_pts = np.array(img_pts)
|
||||
@@ -123,7 +142,7 @@ def denormalize(img_pts, intrinsics=fcam_intrinsics, width=np.inf, height=np.inf
|
||||
return img_pts_denormalized[:, :2].reshape(input_shape)
|
||||
|
||||
|
||||
def get_calib_from_vp(vp, intrinsics=fcam_intrinsics):
|
||||
def get_calib_from_vp(vp, intrinsics):
|
||||
vp_norm = normalize(vp, intrinsics)
|
||||
yaw_calib = np.arctan(vp_norm[0])
|
||||
pitch_calib = -np.arctan(vp_norm[1]*np.cos(yaw_calib))
|
||||
|
||||
@@ -1,19 +1,11 @@
|
||||
import numpy as np
|
||||
|
||||
from openpilot.common.transformations.orientation import rot_from_euler
|
||||
from openpilot.common.transformations.camera import (
|
||||
FULL_FRAME_SIZE, get_view_frame_from_calib_frame, view_frame_from_device_frame,
|
||||
eon_fcam_intrinsics, tici_ecam_intrinsics, tici_fcam_intrinsics)
|
||||
from openpilot.common.transformations.camera import get_view_frame_from_calib_frame, view_frame_from_device_frame
|
||||
|
||||
# segnet
|
||||
SEGNET_SIZE = (512, 384)
|
||||
|
||||
def get_segnet_frame_from_camera_frame(segnet_size=SEGNET_SIZE, full_frame_size=FULL_FRAME_SIZE):
|
||||
return np.array([[float(segnet_size[0]) / full_frame_size[0], 0.0],
|
||||
[0.0, float(segnet_size[1]) / full_frame_size[1]]])
|
||||
segnet_frame_from_camera_frame = get_segnet_frame_from_camera_frame() # xx
|
||||
|
||||
|
||||
# MED model
|
||||
MEDMODEL_INPUT_SIZE = (512, 256)
|
||||
MEDMODEL_YUV_SIZE = (MEDMODEL_INPUT_SIZE[0], MEDMODEL_INPUT_SIZE[1] * 3 // 2)
|
||||
@@ -63,16 +55,9 @@ calib_from_medmodel = np.linalg.inv(medmodel_frame_from_calib_frame[:, :3])
|
||||
calib_from_sbigmodel = np.linalg.inv(sbigmodel_frame_from_calib_frame[:, :3])
|
||||
|
||||
# This function is verified to give similar results to xx.uncommon.utils.transform_img
|
||||
def get_warp_matrix(device_from_calib_euler: np.ndarray, wide_camera: bool = False, bigmodel_frame: bool = False, tici: bool = True) -> np.ndarray:
|
||||
if tici and wide_camera:
|
||||
cam_intrinsics = tici_ecam_intrinsics
|
||||
elif tici:
|
||||
cam_intrinsics = tici_fcam_intrinsics
|
||||
else:
|
||||
cam_intrinsics = eon_fcam_intrinsics
|
||||
|
||||
def get_warp_matrix(device_from_calib_euler: np.ndarray, intrinsics: np.ndarray, bigmodel_frame: bool = False) -> np.ndarray:
|
||||
calib_from_model = calib_from_sbigmodel if bigmodel_frame else calib_from_medmodel
|
||||
device_from_calib = rot_from_euler(device_from_calib_euler)
|
||||
camera_from_calib = cam_intrinsics @ view_frame_from_device_frame @ device_from_calib
|
||||
camera_from_calib = intrinsics @ view_frame_from_device_frame @ device_from_calib
|
||||
warp_matrix: np.ndarray = camera_from_calib @ calib_from_model
|
||||
return warp_matrix
|
||||
|
||||
@@ -1,5 +1,5 @@
|
||||
import numpy as np
|
||||
from typing import Callable
|
||||
from collections.abc import Callable
|
||||
|
||||
from openpilot.common.transformations.transformations import (ecef_euler_from_ned_single,
|
||||
euler2quat_single,
|
||||
|
||||
@@ -0,0 +1,104 @@
|
||||
import numpy as np
|
||||
|
||||
import openpilot.common.transformations.coordinates as coord
|
||||
|
||||
geodetic_positions = np.array([[37.7610403, -122.4778699, 115],
|
||||
[27.4840915, -68.5867592, 2380],
|
||||
[32.4916858, -113.652821, -6],
|
||||
[15.1392514, 103.6976037, 24],
|
||||
[24.2302229, 44.2835412, 1650]])
|
||||
|
||||
ecef_positions = np.array([[-2711076.55270557, -4259167.14692758, 3884579.87669935],
|
||||
[ 2068042.69652729, -5273435.40316622, 2927004.89190746],
|
||||
[-2160412.60461669, -4932588.89873832, 3406542.29652851],
|
||||
[-1458247.92550567, 5983060.87496612, 1654984.6099885 ],
|
||||
[ 4167239.10867871, 4064301.90363223, 2602234.6065749 ]])
|
||||
|
||||
ecef_positions_offset = np.array([[-2711004.46961115, -4259099.33540613, 3884605.16002147],
|
||||
[ 2068074.30639499, -5273413.78835412, 2927012.48741131],
|
||||
[-2160344.53748176, -4932586.20092211, 3406636.2962545 ],
|
||||
[-1458211.98517094, 5983151.11161276, 1655077.02698447],
|
||||
[ 4167271.20055269, 4064398.22619263, 2602238.95265847]])
|
||||
|
||||
|
||||
ned_offsets = np.array([[78.722153649976391, 24.396208657446344, 60.343017506838436],
|
||||
[10.699003365155221, 37.319278617604269, 4.1084100025050407],
|
||||
[95.282646251726959, 61.266689955574428, -25.376506058505054],
|
||||
[68.535769283630003, -56.285970011848889, -100.54840137956515],
|
||||
[-33.066609321880179, 46.549821994306861, -84.062540548335591]])
|
||||
|
||||
ecef_init_batch = np.array([2068042.69652729, -5273435.40316622, 2927004.89190746])
|
||||
ecef_positions_offset_batch = np.array([[ 2068089.41454771, -5273434.46829148, 2927074.04783672],
|
||||
[ 2068103.31628647, -5273393.92275431, 2927102.08725987],
|
||||
[ 2068108.49939636, -5273359.27047121, 2927045.07091581],
|
||||
[ 2068075.12395611, -5273381.69432566, 2927041.08207992],
|
||||
[ 2068060.72033399, -5273430.6061505, 2927094.54928305]])
|
||||
|
||||
ned_offsets_batch = np.array([[ 53.88103168, 43.83445935, -46.27488057],
|
||||
[ 93.83378995, 71.57943024, -30.23113187],
|
||||
[ 57.26725796, 89.05602684, 23.02265814],
|
||||
[ 49.71775195, 49.79767572, 17.15351015],
|
||||
[ 78.56272609, 18.53100158, -43.25290759]])
|
||||
|
||||
|
||||
class TestNED:
|
||||
def test_small_distances(self):
|
||||
start_geodetic = np.array([33.8042184, -117.888593, 0.0])
|
||||
local_coord = coord.LocalCoord.from_geodetic(start_geodetic)
|
||||
|
||||
start_ned = local_coord.geodetic2ned(start_geodetic)
|
||||
np.testing.assert_array_equal(start_ned, np.zeros(3,))
|
||||
|
||||
west_geodetic = start_geodetic + [0, -0.0005, 0]
|
||||
west_ned = local_coord.geodetic2ned(west_geodetic)
|
||||
assert np.abs(west_ned[0]) < 1e-3
|
||||
assert west_ned[1] < 0
|
||||
|
||||
southwest_geodetic = start_geodetic + [-0.0005, -0.002, 0]
|
||||
southwest_ned = local_coord.geodetic2ned(southwest_geodetic)
|
||||
assert southwest_ned[0] < 0
|
||||
assert southwest_ned[1] < 0
|
||||
|
||||
def test_ecef_geodetic(self):
|
||||
# testing single
|
||||
np.testing.assert_allclose(ecef_positions[0], coord.geodetic2ecef(geodetic_positions[0]), rtol=1e-9)
|
||||
np.testing.assert_allclose(geodetic_positions[0, :2], coord.ecef2geodetic(ecef_positions[0])[:2], rtol=1e-9)
|
||||
np.testing.assert_allclose(geodetic_positions[0, 2], coord.ecef2geodetic(ecef_positions[0])[2], rtol=1e-9, atol=1e-4)
|
||||
|
||||
np.testing.assert_allclose(geodetic_positions[:, :2], coord.ecef2geodetic(ecef_positions)[:, :2], rtol=1e-9)
|
||||
np.testing.assert_allclose(geodetic_positions[:, 2], coord.ecef2geodetic(ecef_positions)[:, 2], rtol=1e-9, atol=1e-4)
|
||||
np.testing.assert_allclose(ecef_positions, coord.geodetic2ecef(geodetic_positions), rtol=1e-9)
|
||||
|
||||
|
||||
def test_ned(self):
|
||||
for ecef_pos in ecef_positions:
|
||||
converter = coord.LocalCoord.from_ecef(ecef_pos)
|
||||
ecef_pos_moved = ecef_pos + [25, -25, 25]
|
||||
ecef_pos_moved_double_converted = converter.ned2ecef(converter.ecef2ned(ecef_pos_moved))
|
||||
np.testing.assert_allclose(ecef_pos_moved, ecef_pos_moved_double_converted, rtol=1e-9)
|
||||
|
||||
for geo_pos in geodetic_positions:
|
||||
converter = coord.LocalCoord.from_geodetic(geo_pos)
|
||||
geo_pos_moved = geo_pos + np.array([0, 0, 10])
|
||||
geo_pos_double_converted_moved = converter.ned2geodetic(converter.geodetic2ned(geo_pos) + np.array([0, 0, -10]))
|
||||
np.testing.assert_allclose(geo_pos_moved[:2], geo_pos_double_converted_moved[:2], rtol=1e-9, atol=1e-6)
|
||||
np.testing.assert_allclose(geo_pos_moved[2], geo_pos_double_converted_moved[2], rtol=1e-9, atol=1e-4)
|
||||
|
||||
def test_ned_saved_results(self):
|
||||
for i, ecef_pos in enumerate(ecef_positions):
|
||||
converter = coord.LocalCoord.from_ecef(ecef_pos)
|
||||
np.testing.assert_allclose(converter.ned2ecef(ned_offsets[i]),
|
||||
ecef_positions_offset[i],
|
||||
rtol=1e-9, atol=1e-4)
|
||||
np.testing.assert_allclose(converter.ecef2ned(ecef_positions_offset[i]),
|
||||
ned_offsets[i],
|
||||
rtol=1e-9, atol=1e-4)
|
||||
|
||||
def test_ned_batch(self):
|
||||
converter = coord.LocalCoord.from_ecef(ecef_init_batch)
|
||||
np.testing.assert_allclose(converter.ecef2ned(ecef_positions_offset_batch),
|
||||
ned_offsets_batch,
|
||||
rtol=1e-9, atol=1e-7)
|
||||
np.testing.assert_allclose(converter.ned2ecef(ned_offsets_batch),
|
||||
ecef_positions_offset_batch,
|
||||
rtol=1e-9, atol=1e-7)
|
||||
@@ -0,0 +1,61 @@
|
||||
import numpy as np
|
||||
|
||||
from openpilot.common.transformations.orientation import euler2quat, quat2euler, euler2rot, rot2euler, \
|
||||
rot2quat, quat2rot, \
|
||||
ned_euler_from_ecef
|
||||
|
||||
eulers = np.array([[ 1.46520501, 2.78688383, 2.92780854],
|
||||
[ 4.86909526, 3.60618161, 4.30648981],
|
||||
[ 3.72175965, 2.68763705, 5.43895988],
|
||||
[ 5.92306687, 5.69573614, 0.81100357],
|
||||
[ 0.67838374, 5.02402037, 2.47106426]])
|
||||
|
||||
quats = np.array([[ 0.66855182, -0.71500939, 0.19539353, 0.06017818],
|
||||
[ 0.43163717, 0.70013301, 0.28209145, 0.49389021],
|
||||
[ 0.44121991, -0.08252646, 0.34257534, 0.82532207],
|
||||
[ 0.88578382, -0.04515356, -0.32936046, 0.32383617],
|
||||
[ 0.06578165, 0.61282835, 0.07126891, 0.78424163]])
|
||||
|
||||
ecef_positions = np.array([[-2711076.55270557, -4259167.14692758, 3884579.87669935],
|
||||
[ 2068042.69652729, -5273435.40316622, 2927004.89190746],
|
||||
[-2160412.60461669, -4932588.89873832, 3406542.29652851],
|
||||
[-1458247.92550567, 5983060.87496612, 1654984.6099885 ],
|
||||
[ 4167239.10867871, 4064301.90363223, 2602234.6065749 ]])
|
||||
|
||||
ned_eulers = np.array([[ 0.46806039, -0.4881889 , 1.65697808],
|
||||
[-2.14525969, -0.36533066, 0.73813479],
|
||||
[-1.39523364, -0.58540761, -1.77376356],
|
||||
[-1.84220435, 0.61828016, -1.03310421],
|
||||
[ 2.50450101, 0.36304151, 0.33136365]])
|
||||
|
||||
|
||||
class TestOrientation:
|
||||
def test_quat_euler(self):
|
||||
for i, eul in enumerate(eulers):
|
||||
np.testing.assert_allclose(quats[i], euler2quat(eul), rtol=1e-7)
|
||||
np.testing.assert_allclose(quats[i], euler2quat(quat2euler(quats[i])), rtol=1e-6)
|
||||
for i, eul in enumerate(eulers):
|
||||
np.testing.assert_allclose(quats[i], euler2quat(list(eul)), rtol=1e-7)
|
||||
np.testing.assert_allclose(quats[i], euler2quat(quat2euler(list(quats[i]))), rtol=1e-6)
|
||||
np.testing.assert_allclose(quats, euler2quat(eulers), rtol=1e-7)
|
||||
np.testing.assert_allclose(quats, euler2quat(quat2euler(quats)), rtol=1e-6)
|
||||
|
||||
def test_rot_euler(self):
|
||||
for eul in eulers:
|
||||
np.testing.assert_allclose(euler2quat(eul), euler2quat(rot2euler(euler2rot(eul))), rtol=1e-7)
|
||||
for eul in eulers:
|
||||
np.testing.assert_allclose(euler2quat(eul), euler2quat(rot2euler(euler2rot(list(eul)))), rtol=1e-7)
|
||||
np.testing.assert_allclose(euler2quat(eulers), euler2quat(rot2euler(euler2rot(eulers))), rtol=1e-7)
|
||||
|
||||
def test_rot_quat(self):
|
||||
for quat in quats:
|
||||
np.testing.assert_allclose(quat, rot2quat(quat2rot(quat)), rtol=1e-7)
|
||||
for quat in quats:
|
||||
np.testing.assert_allclose(quat, rot2quat(quat2rot(list(quat))), rtol=1e-7)
|
||||
np.testing.assert_allclose(quats, rot2quat(quat2rot(quats)), rtol=1e-7)
|
||||
|
||||
def test_euler_ned(self):
|
||||
for i in range(len(eulers)):
|
||||
np.testing.assert_allclose(ned_eulers[i], ned_euler_from_ecef(ecef_positions[i], eulers[i]), rtol=1e-7)
|
||||
#np.testing.assert_allclose(eulers[i], ecef_euler_from_ned(ecef_positions[i], ned_eulers[i]), rtol=1e-7)
|
||||
# np.testing.assert_allclose(ned_eulers, ned_euler_from_ecef(ecef_positions, eulers), rtol=1e-7)
|
||||
Reference in New Issue
Block a user